Hollow-Shaft Direct Drive Motor for Heavy-Duty Precision Positioning and Industrial Automation
Introduction
In heavy-duty automation, precision positioning is often limited not by the control system itself, but by the mechanical transmission used between the motor and the load. Traditional servo motors combined with gearboxes, belts, or other transmission mechanisms introduce additional mechanical components, which can create backlash, transmission errors, mechanical losses, and maintenance requirements. These limitations become increasingly noticeable when equipment needs to perform repeated indexing, continuous rotation, or high-precision positioning under heavy loads.
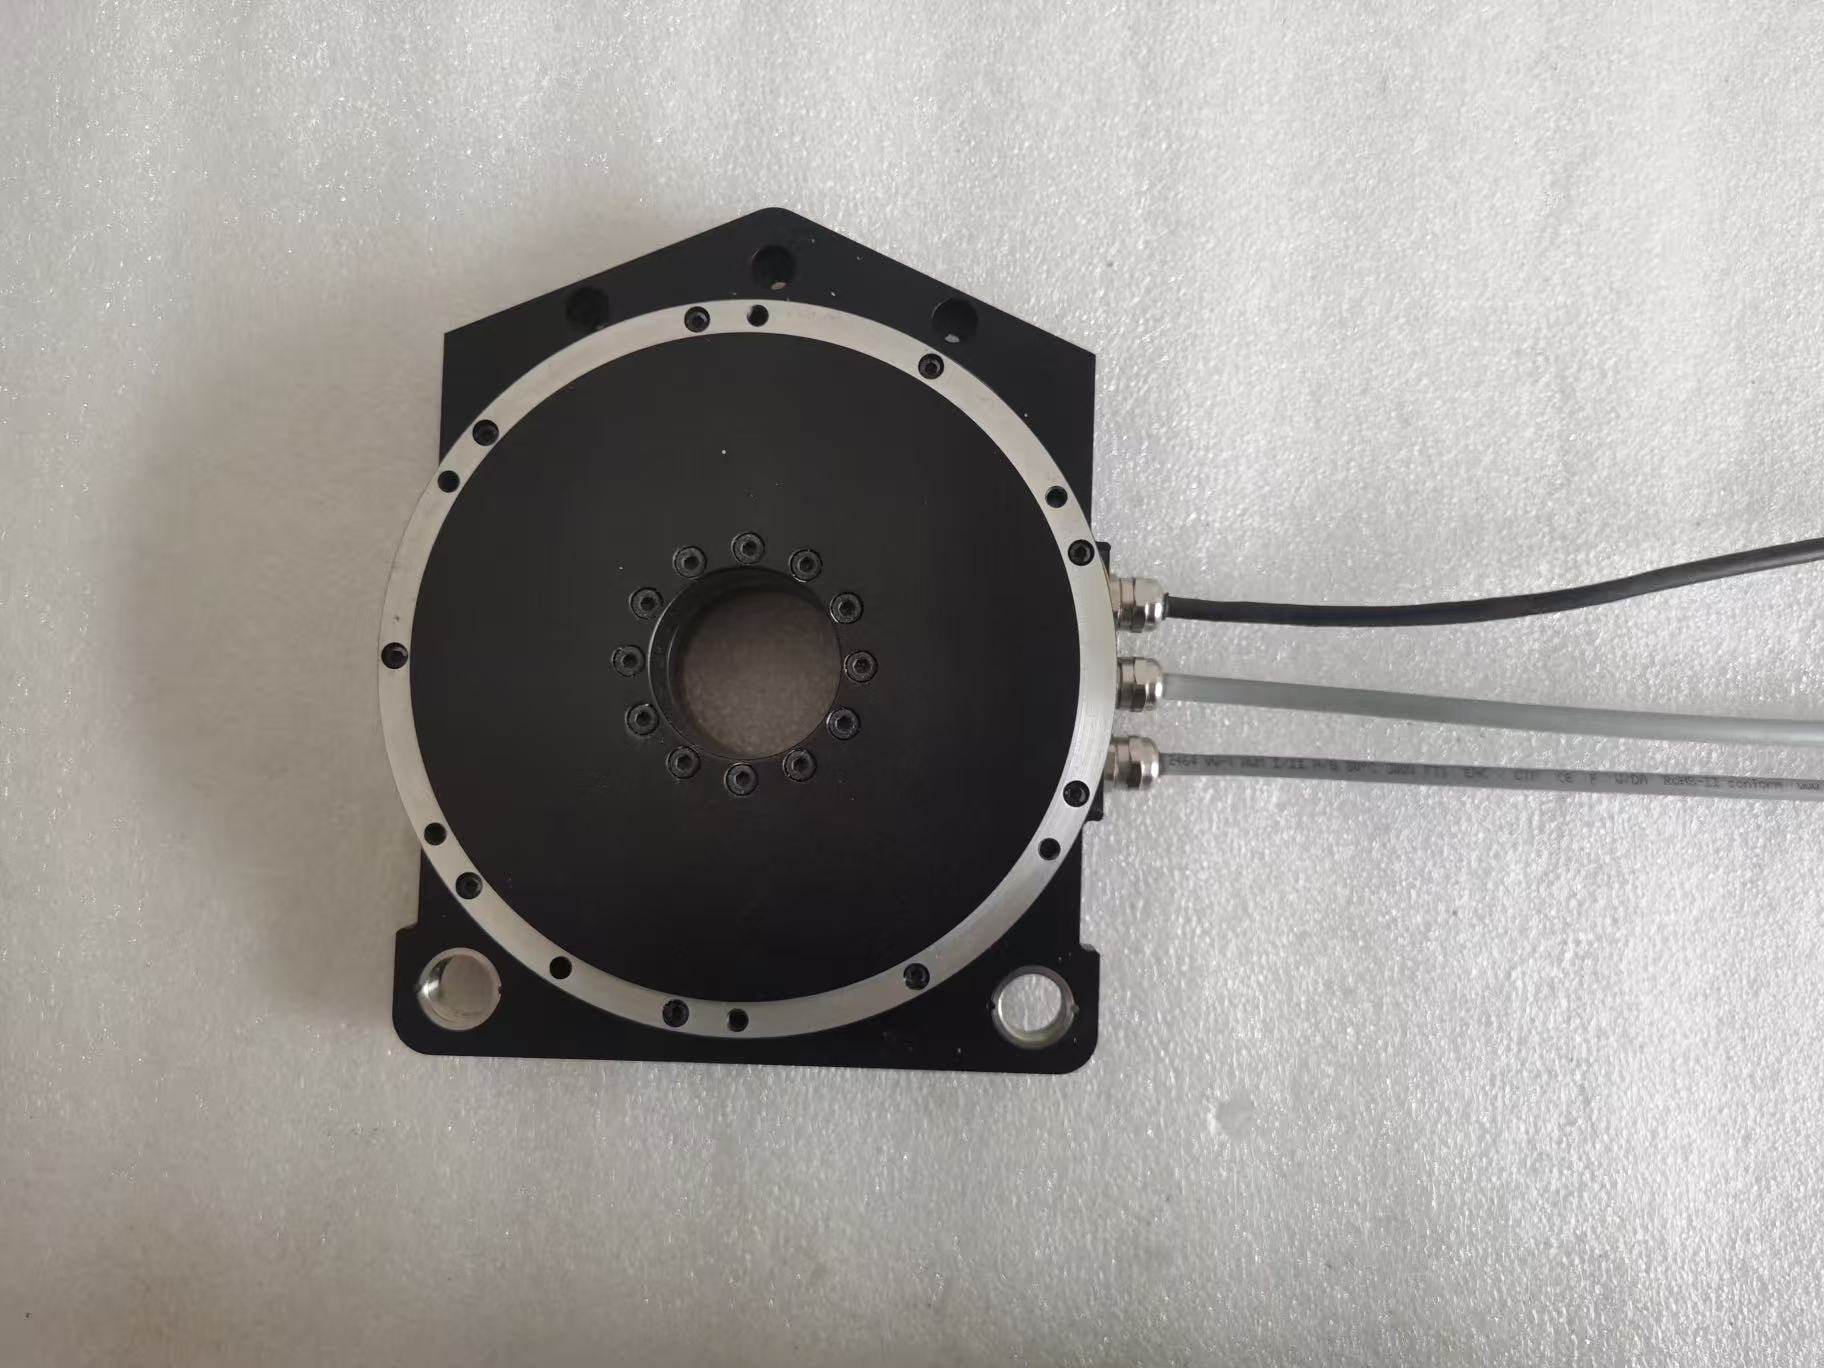
A Direct Drive Motor takes a fundamentally different approach. Instead of generating torque through a separate mechanical transmission stage, the motor drives the rotating load directly. This eliminates the need for intermediate gears and allows torque to be transferred directly to the output shaft. For applications requiring stable positioning, high repeatability, smooth low-speed motion, and continuous heavy-duty operation, a Direct Drive Torque Motorcan provide a more efficient mechanical architecture.
For industrial equipment designers, however, direct drive alone is not enough. The motor must also match the actual load, inertia, positioning requirements, installation space, cable routing, and operating cycle of the machine. This is why hollow-shaft direct drive motors are becoming particularly valuable in CNC equipment, lithium battery manufacturing, photovoltaic equipment, optical processing, semiconductor inspection, and other automated production systems.
Why Traditional Mechanical Transmission Can Become a Limitation?
When a conventional servo motor is connected to a gearbox or other transmission mechanism, the final positioning performance depends on the entire mechanical transmission chain rather than the motor alone. Every additional transmission component introduces potential sources of error, including backlash, elastic deformation, friction, assembly tolerance, and wear.
These effects may be manageable in conventional automation, but they become more significant when the machine repeatedly performs small-angle positioning or operates under high load for thousands of hours.
For example, a heavy workpiece may need to rotate to multiple processing positions during CNC machining. If the transmission system contains backlash or mechanical compliance, reversing the rotation direction can produce a small positioning error before the load actually begins moving. The controller may already have reached the commanded position while the workpiece has not completely followed it.
A Direct Drive Torque Motor removes much of this mechanical complexity because the motor torque is applied directly to the rotating load. With fewer mechanical transmission components between the motor and the workpiece, the system can achieve smoother motion, reduced mechanical error, and more direct control of the output position.
This is particularly important for equipment where repeatability and long-term positioning stability matter more than simply achieving a high rotational speed.
When a Direct Drive Motor Is More Suitable for Heavy Loads?
The biggest misconception about direct drive systems is that they are only suitable for small, high-precision mechanisms. In reality, large torque motors can be designed specifically for heavy loads and continuous industrial operation.
The key consideration is not simply motor power, but the relationship between output torque, load inertia, acceleration, duty cycle, and required positioning accuracy.
In a heavy-duty application, the motor may need to repeatedly accelerate a large fixture, stop at a defined angular position, reverse direction, and continue this cycle throughout the production process. A conventional motor with a high-ratio gearbox can provide sufficient output torque, but the gearbox also becomes a critical component in the transmission chain.
A properly sized Direct Drive Motor can generate torque directly at the rotating shaft, reducing the number of mechanical interfaces between the motor and the load. This can simplify the mechanical architecture while improving the responsiveness of the positioning system.
For equipment manufacturers, this means the design objective changes from simply asking, “What gear ratio should we use?” to a more useful question: “Can the direct drive motor provide the required continuous torque, peak torque, acceleration, and positioning performance for the actual load?”
That approach is especially valuable when designing customized automation equipment.
Hollow-Shaft Design Solves More Than Cable Routing
For industrial automation, the hollow shaft is not simply a structural feature. It can directly affect the overall architecture of the machine.
A conventional solid-shaft motor requires cables, pneumatic lines, vacuum tubes, sensors, or other utilities to be routed around the rotating mechanism. As the number of components increases, the external wiring becomes more complicated and can interfere with the movement of the equipment.
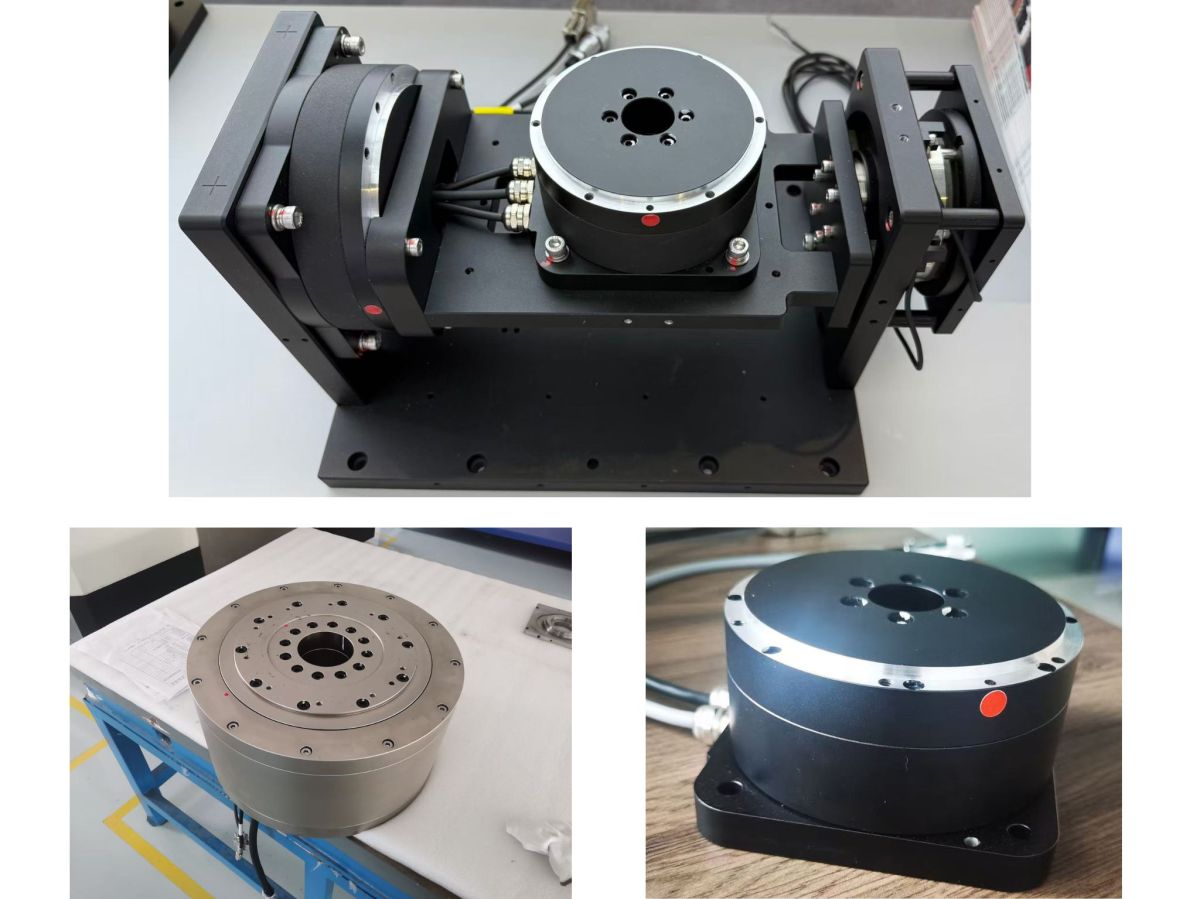
A Hollow Shaft Direct Drive Motor provides an internal passage through the rotating shaft. Cables, pneumatic tubing, vacuum lines, optical components, and other utilities can potentially pass through the center of the motor and directly reach the rotating tooling.
This becomes particularly valuable in equipment such as photovoltaic manufacturing systems, optical inspection equipment, heavy-duty indexing mechanisms, and automated assembly machines.
For example, in a large-format photovoltaic printing process, the rotating mechanism may need to change the orientation of the workpiece while maintaining precise positioning. With a hollow-shaft architecture, cables and pneumatic lines can be routed through the center rather than around the rotating mechanism. This can reduce external interference and make the overall equipment structure cleaner and easier to maintain.
The same principle applies to automated machining and inspection systems where vacuum fixtures, sensors, lighting systems, or other auxiliary components must be integrated around the rotating load.
Direct Drive Motors for Lithium Battery Manufacturing
Lithium battery production is a good example of an application where torque, repeatability, continuous operation, and mechanical reliability must be considered simultaneously.
During processes such as battery cell stacking and welding, production equipment may need to repeatedly position relatively heavy fixtures or battery modules at different angular positions. The rotation mechanism must maintain stable positioning throughout a large number of operating cycles.
A Direct Drive Motor can directly drive the rotating mechanism without relying on a conventional gearbox. This reduces the number of transmission components and allows the motor to respond directly to position commands.
For high-volume production lines, another advantage is long-term mechanical consistency. When the transmission chain contains gears, belts, or other wear components, mechanical performance can gradually change over time. A direct-drive architecture reduces these transmission elements, which can help simplify maintenance and improve long-term positioning stability.
For battery manufacturing equipment operating continuously, this difference can become important because even small positioning deviations can affect subsequent welding, assembly, or inspection processes.
Direct Drive Torque Motors for Photovoltaic Equipment
Photovoltaic manufacturing equipment often involves large workpieces, precision alignment, and continuous automated operation. The rotation mechanism therefore needs to combine high torque capacity with stable angular positioning.
A Direct Drive Torque Motor is particularly suitable when the rotating load is large and the machine requires frequent indexing or orientation changes.
The direct torque output allows the motor to control the rotating load without introducing an additional reduction stage. When combined with a hollow-shaft design, the center of the rotating mechanism can also be used for cable and pneumatic routing.
This architecture is useful for photovoltaic inspection, printing, alignment, and other automated processes where the workpiece needs to be accurately positioned before the next manufacturing operation.
Instead of designing the machine around an external gearbox and then finding a way to accommodate the wiring, equipment designers can integrate the motor directly into the rotating mechanism and use the hollow shaft as part of the machine's internal routing architecture.
Direct Drive Motor for CNC Machining and Heavy-Duty Positioning
CNC machining represents another important application for high-torque direct-drive systems.
During milling, drilling, grinding, or multi-angle machining, the workpiece or tooling may need to rotate repeatedly while maintaining a stable angular position. The rotation mechanism must withstand cutting forces while maintaining positioning accuracy.
Traditional geared systems can provide high output torque, but backlash and transmission compliance become increasingly important when the system frequently changes direction.
A Direct Drive Motor can provide a more direct connection between the motor and the rotating load. With no intermediate reduction gear, the system can respond rapidly to position commands and avoid conventional gearbox backlash.
For heavy-duty CNC positioning applications, however, motor selection must consider the complete load profile. The required continuous torque, peak torque, acceleration, stopping time, workpiece inertia, and external machining forces all need to be evaluated together.
This is where a customized direct-drive solution can provide greater value than simply selecting a motor according to rated torque.
Optical and Semiconductor Equipment: Precision Without Unnecessary Transmission
The requirements of optical inspection and semiconductor equipment are different from those of heavy machining, but the same direct-drive principle can be valuable.
In optical alignment, wafer inspection, defect detection, and precision calibration equipment, the mechanism may need to perform extremely small angular movements while maintaining smooth motion.
A conventional transmission system can introduce mechanical clearance and friction that make very small movements more difficult to control. A direct-drive architecture places the motor directly at the rotational axis, allowing the controller to regulate the actual rotational motion more directly.
For compact inspection equipment, the hollow-shaft configuration also provides another advantage. The center passage can be used to integrate cables, optical components, vacuum lines, or other system elements without significantly increasing the external dimensions of the mechanism.
This makes a Hollow Shaft Direct Drive Motor particularly interesting for compact precision automation where both mechanical integration and positioning performance are important.
How to Choose a Direct Drive Motor for Your Application?
Selecting a direct drive motor should start with the application rather than the motor specification sheet.
Evaluate Continuous and Peak Torque
The first question is the actual load torque. The motor must provide sufficient continuous torque for normal operation and sufficient peak torque for acceleration, deceleration, emergency stops, and transient loads.
Consider Load Inertia and Acceleration
The second consideration is load inertia. A heavy workpiece may require substantially more torque during acceleration than during steady-state rotation. Therefore, a motor with a high rated torque is not necessarily suitable if its dynamic response does not match the required acceleration profile.
Match the Positioning Requirements
Positioning requirements are equally important. If the equipment requires frequent direction changes and high repeatability, eliminating mechanical transmission backlash can provide a significant advantage.
Consider Hollow-Shaft Integration
Installation requirements should also be considered early in the design process. If cables, pneumatic lines, vacuum pipes, or optical components need to pass through the center of the rotating mechanism, a hollow-shaft direct drive motor can simplify the entire mechanical structure.
Evaluate Duty Cycle and Operating Environment
Finally, the operating environment and duty cycle should be evaluated. Continuous 24-hour production, heavy loads, high acceleration, and frequent indexing place very different demands on the motor compared with laboratory equipment.
From Motor Selection to Complete Motion Solutions
For equipment manufacturers, choosing a Direct Drive Motor is not simply a matter of replacing a servo motor and gearbox with another motor.
The real objective is to develop a motion system that matches the application's torque, inertia, positioning accuracy, speed, mechanical structure, and operating cycle.
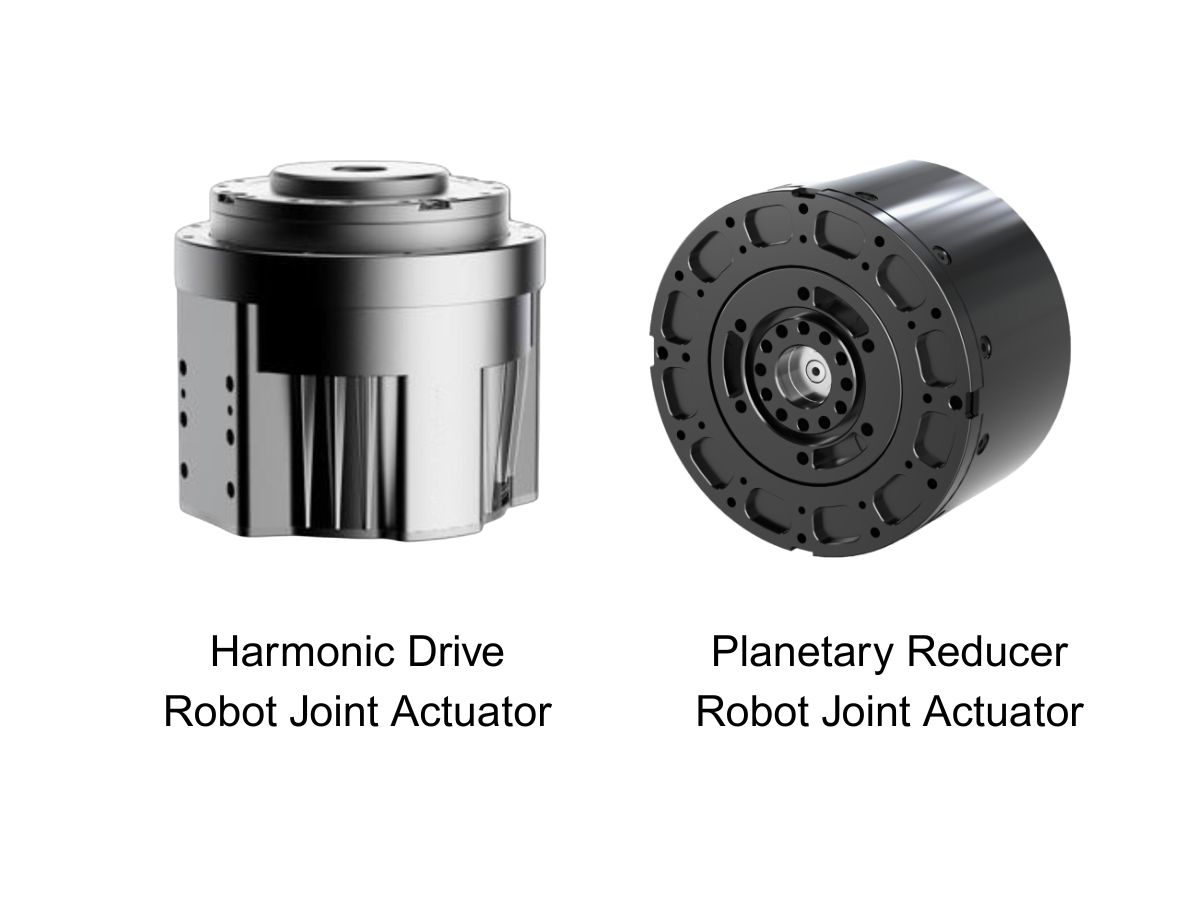
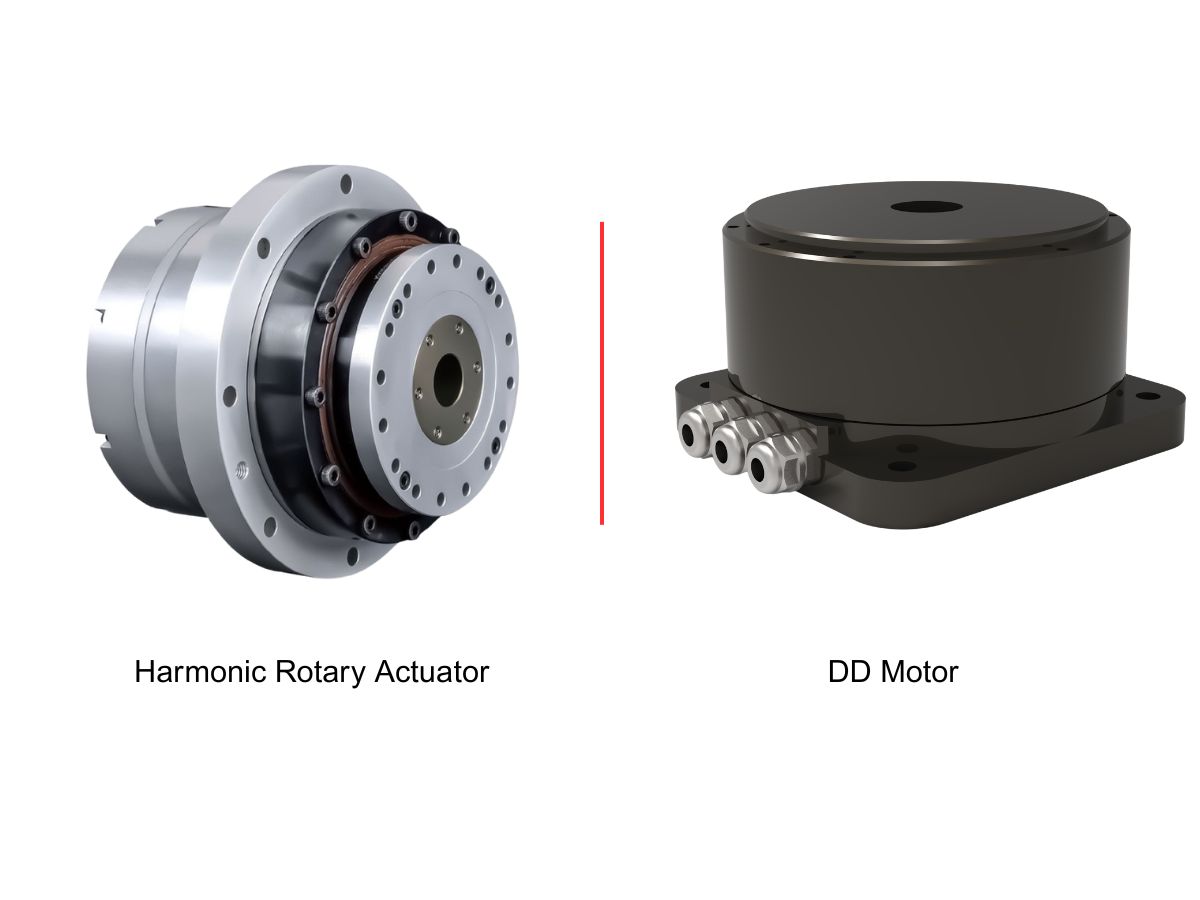
This is where different drive architectures can be compared according to the actual machine requirements. A direct drive motor can be an excellent choice when the application benefits from direct torque transmission, low mechanical complexity, smooth motion, and high positioning stability. A harmonic actuator or planetary joint module may be more appropriate when the machine requires compact geared transmission, high torque multiplication, or integrated robot joint functionality.
For this reason, HONPINE does not focus on a single motion architecture. Its product portfolio covers direct drive motors, harmonic actuators, harmonic joint modules, and planetary joint modules, allowing engineers to select the appropriate motion solution according to the mechanical requirements of the equipment.
Why Work With HONPINE for Customized Motion Solutions?
Many automation projects do not fit neatly into a standard product category. A CNC positioning mechanism may require a high-torque direct drive motor, while a robotic axis may require a harmonic joint module with an integrated encoder and drive system. A compact medical mechanism may prioritize low weight and hollow-shaft integration, while a heavy industrial axis may prioritize continuous torque and rigidity.
This is why application-based selection is often more effective than simply choosing a product from a catalog.
HONPINE can evaluate the load characteristics, required speed, positioning accuracy, installation space, shaft configuration, communication requirements, and operating conditions to help customers determine the appropriate motion architecture.
For heavy-duty precision rotation, a hollow-shaft Direct Drive Motor can eliminate unnecessary transmission components while providing direct torque output. For robotic joints requiring compact integration, sensing, braking, and closed-loop control, an integrated harmonic joint module can provide a more complete solution. For applications requiring high reduction ratios and compact planetary transmission, a planetary joint module can offer another architecture.
The goal is not to use the same motor for every application. The goal is to select the right motion architecture for the machine.
Conclusion
As industrial automation continues to demand higher positioning accuracy, faster response, greater load capacity, and simpler mechanical integration, the role of the motor itself is becoming increasingly important.
A Direct Drive Motor eliminates the need for a conventional mechanical reduction stage and transfers torque directly to the load. For heavy-duty positioning, CNC machining, lithium battery manufacturing, photovoltaic equipment, optical inspection, semiconductor equipment, and other precision automation applications, this architecture can reduce mechanical complexity while improving motion responsiveness and long-term positioning stability.
When a hollow shaft is added, the motor becomes more than a drive component. It can become an important part of the machine's mechanical architecture, providing a central passage for cables, pneumatic lines, vacuum systems, and other auxiliary components.
For engineers developing customized automation equipment, the most important question is therefore not simply whether a Direct Drive Motor is powerful enough. The more important question is whether the complete motion architecture is optimized for the application's load, inertia, accuracy, speed, installation requirements, and production cycle.
HONPINE provides multiple motion solutions, from Direct Drive Motors and Direct Drive Torque Motors to harmonic joint modules and planetary joint modules, helping equipment manufacturers move from individual components toward application-specific motion solutions.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 How to Choose a Reliable Robot Joint Motor Manufacturer for Humanoid Robots?Choosing a reliable robot joint motor manufacturer is a critical step when developing humanoid robots and other advanced robotic systems. A robotic joint must balance torque, speed, precision, torque density, thermal performance, feedback, mechanical stiffness, and long-term reliability within a compact structure. For B2B robotics companies, supplier evaluation should therefore go beyond a product datasheet and consider engineering capability, manufacturing capacity, joint integration, testing, and production scalability. In this article, Allen Li, Founder of HONPINE, explains the key factors to consider when selecting a robot joint motor manufacturer and how integrated harmonic robot joint technology can support humanoid robot development.
 Lightweight Humanoid Robots Start with Precision TransmissionAs humanoid robots move from experimental prototypes toward practical applications, lightweight design, energy efficiency, motion performance, and long-term reliability are becoming increasingly important. At the center of these challenges is precision transmission. From harmonic reducers and lightweight robot joints to integrated development kits, the design of each core component directly affects the overall performance of a humanoid robot. In this article, Allen Li, Founder of HONPINE, shares his perspective on how precision transmission technology can support the development of lightweight humanoid robots and how HONPINE is extending its expertise from harmonic reducers toward lightweight robot joints and integrated robotics solutions.
 Hollow-Shaft Direct Drive Motor for Heavy-Duty Precision Positioning and Industrial AutomationIn heavy-duty automation, precision positioning depends not only on the motor but also on the mechanical transmission between the motor and the load. A hollow shaft direct drive motor delivers torque directly to the load while providing a central passage for cables, pneumatic lines and other components. This makes it a practical solution for CNC machining, photovoltaic, lithium battery, optical inspection and semiconductor equipment.
 Harmonic Rotary Actuators for Semiconductor Equipment: Precision Motion, Hollow-Shaft Design and FOC ControlHello everyone, I’m Theodore Li, Technical Director at HONPINE. In semiconductor manufacturing equipment, rotary motion is not simply about making a mechanism rotate. Limited installation space, cable and tube routing, low-speed stability, precise positioning and continuously adjustable motion profiles can all influence the performance of the machine. This is why harmonic rotary actuators are becoming an important motion solution for semiconductor equipment. In this article, I will discuss how harmonic transmission, FOC-based motor control, encoder feedback, large hollow-shaft design and flexible mechanical interfaces work together to meet practical semiconductor motion requirements, based on our experience with developing equipment, overhead transport, wafer handling, cleaning and crystal-growth applications.
 Miniature Harmonic Drive for Minimally Invasive Surgical RobotsMinimally invasive surgical robots require highly compact transmission systems that can deliver precise motion within extremely limited mechanical spaces. As robotic instruments become smaller and more dexterous, conventional transmission architectures can face challenges related to size, tendon elasticity, friction, hysteresis, and mechanical integration. A miniature harmonic drive offers one potential approach by providing high-ratio precision transmission, low backlash, and compact dimensions in a small mechanical envelope. In this article, I will explain why miniature harmonic transmission is relevant to surgical robotics, compare external tendon-driven and distal transmission architectures, and discuss the key engineering considerations behind HONPINE’s CSF-mini miniature harmonic reducer for compact robotic joints, flexible robotic instruments, and other precision mechanisms.
 How to Choose a Robot Joint Actuator: 3 Key Criteria Engineers Should Check?Choosing a robot joint actuator is an engineering decision that affects not only torque and motion performance, but also control stability, mechanical integration, and development time. For industrial robots, collaborative robots, humanoid robots, and other robotic systems, the right actuator must match the actual requirements of each joint while remaining compatible with the robot’s motor, encoder, controller, communication network, and power architecture. In this article, I will explain three key criteria engineers should evaluate when selecting a robot joint actuator: torque and gear ratio matching, encoder and communication compatibility, and the manufacturer’s technical documentation and engineering support.




Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 How to Choose a Reliable Robot Joint Motor Manufacturer for Humanoid Robots?Choosing a reliable robot joint motor manufacturer is a critical step when developing humanoid robots and other advanced robotic systems. A robotic joint must balance torque, speed, precision, torque density, thermal performance, feedback, mechanical stiffness, and long-term reliability within a compact structure. For B2B robotics companies, supplier evaluation should therefore go beyond a product datasheet and consider engineering capability, manufacturing capacity, joint integration, testing, and production scalability. In this article, Allen Li, Founder of HONPINE, explains the key factors to consider when selecting a robot joint motor manufacturer and how integrated harmonic robot joint technology can support humanoid robot development.
 Lightweight Humanoid Robots Start with Precision TransmissionAs humanoid robots move from experimental prototypes toward practical applications, lightweight design, energy efficiency, motion performance, and long-term reliability are becoming increasingly important. At the center of these challenges is precision transmission. From harmonic reducers and lightweight robot joints to integrated development kits, the design of each core component directly affects the overall performance of a humanoid robot. In this article, Allen Li, Founder of HONPINE, shares his perspective on how precision transmission technology can support the development of lightweight humanoid robots and how HONPINE is extending its expertise from harmonic reducers toward lightweight robot joints and integrated robotics solutions.
 Hollow-Shaft Direct Drive Motor for Heavy-Duty Precision Positioning and Industrial AutomationIn heavy-duty automation, precision positioning depends not only on the motor but also on the mechanical transmission between the motor and the load. A hollow shaft direct drive motor delivers torque directly to the load while providing a central passage for cables, pneumatic lines and other components. This makes it a practical solution for CNC machining, photovoltaic, lithium battery, optical inspection and semiconductor equipment.
 How to Choose a Robot Joint Actuator: 3 Key Criteria Engineers Should Check?Choosing a robot joint actuator is an engineering decision that affects not only torque and motion performance, but also control stability, mechanical integration, and development time. For industrial robots, collaborative robots, humanoid robots, and other robotic systems, the right actuator must match the actual requirements of each joint while remaining compatible with the robot’s motor, encoder, controller, communication network, and power architecture. In this article, I will explain three key criteria engineers should evaluate when selecting a robot joint actuator: torque and gear ratio matching, encoder and communication compatibility, and the manufacturer’s technical documentation and engineering support.
 Outdoor Robot Joint Solution: Harmonic Joint Module with Built-in Torque SensorHello everyone, I’m Theodore Li, Technical Director at HONPINE. As robots move beyond controlled factory environments, outdoor robotic applications are creating new requirements for robot joint design. Rain, dust, humidity, temperature fluctuations, low-temperature conditions, and unpredictable external loads can all affect how a robotic joint performs in the field. In these environments, a joint needs to provide more than precise rotation. It also needs reliable torque feedback, suitable environmental protection, stable operation under changing temperatures, and practical mechanical integration. In this article, I will explain the key engineering considerations behind our outdoor robot joint solution, including the harmonic joint module, built-in torque sensor, IP65 protection, low-temperature lubrication, cable outlet protection, and mechanical integration, based on our experience with outdoor robotic applications such as solar panel installation, construction, and cleaning robots.
 RV Reducer for Welding Positioners: Selection and Torque Calculation for Heavy-Duty Welding ApplicationsSelecting the right RV reducer for a welding positioner requires more than simply matching the reducer to the workpiece weight. A heavy-duty welding positioner must provide sufficient output torque, high torsional rigidity, stable low-speed rotation, accurate positioning, and reliable performance during acceleration, deceleration, and reversing. In this article, we explain how to select an RV reducer and servo motor for a welding positioner by calculating output speed, reduction ratio, workpiece inertia, gravity load torque, acceleration torque, motor torque, and peak torque. A practical 500 kg welding positioner example is also used to show how these parameters affect RV reducer selection.
 Types of Robot Joint Motors: Model Selection, Advantages and DisadvantagesRobot joint motors are one of the key components that determine the performance, precision, efficiency, and load capacity of a robot. Depending on the application, robot joints can use electric, hydraulic, pneumatic, or other drive technologies. Among them, electric-drive solutions have become the mainstream choice for modern robots, especially humanoid robots, industrial robots, collaborative robots, and mobile robots. Electric robot joint motors can be further divided according to their transmission methods, including harmonic drive, planetary reducer, cycloidal reducer, ball screw, and direct drive solutions. Each type has its own advantages and disadvantages in terms of precision, torque density, efficiency, impact resistance, size, cost, and backdrivability. Understanding these differences is essential for selecting the right robot joint motor for a specific application.
 Hollow Rotary Platform vs. Harmonic Rotary Actuator: Application Comparison and InterchangeabilityHello everyone, I’m Theodore Li, Technical Director at HONPINE. For engineers designing precision rotary stations for industrial automation, one question often comes up: when a machine requires high-precision rotation, indexing, or rotary positioning, should you choose a hollow rotary platform or a harmonic rotary actuator? Can they be used interchangeably? Although both are precision rotary motion solutions, their mechanical structures and application characteristics are quite different. In actual equipment, choosing the wrong solution can lead to insufficient load capacity, inadequate rigidity, vibration, speed limitations, or reduced service life. In this article, I’ll compare their application characteristics and explain where they can be used interchangeably, where one is more suitable than the other, and what engineers should check before making a replacement.
 How HONPINE Manufactures Precision Harmonic Reducers: Technology, Quality and Manufacturing Challenges?A precision harmonic reducer is more than a compact high-ratio transmission component. Its actual performance depends on how accurately every critical component is designed, manufactured, assembled, and tested. Tooth profile accuracy, flexspline material, heat treatment, machining tolerances, wave generator geometry, assembly precision, and production consistency can all influence backlash, torsional stiffness, efficiency, durability, and positioning accuracy. For robotics, CNC equipment, semiconductor manufacturing, optical inspection, and other precision automation applications, these factors become even more important. This article explores how HONPINE manufactures precision harmonic reducers, the key technologies and manufacturing challenges involved, and why stable production capability is essential for achieving reliable transmission performance at scale.