Current tag:honpine
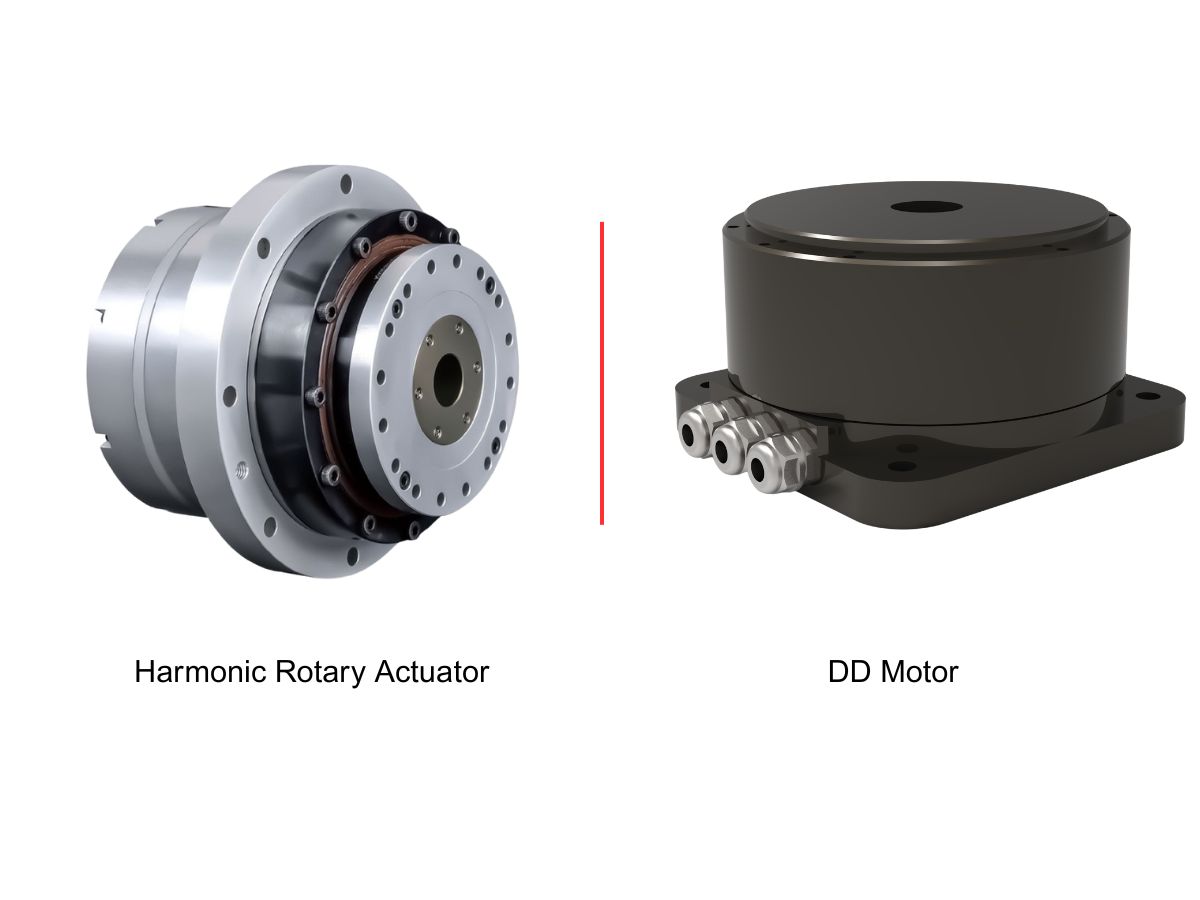
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
- DD Motor Servo System: How to Understand Mechanical Resonance and Solve Machine Vibration?This article explains the relationship between DD motor servo tuning, mechanical resonance, and servo bandwidth in direct drive motion systems. It examines why vibration and instability can occur even after repeated servo parameter adjustments, and explains how mechanical stiffness, moving mass, bearing conditions, load distribution, and structural geometry affect resonance frequency. The article also compares approaches for high- and low-frequency resonance, explains when digital notch filtering can be effective, and provides a practical tuning strategy for engineers working with DD motors, direct drive torque motors, and linear motors.
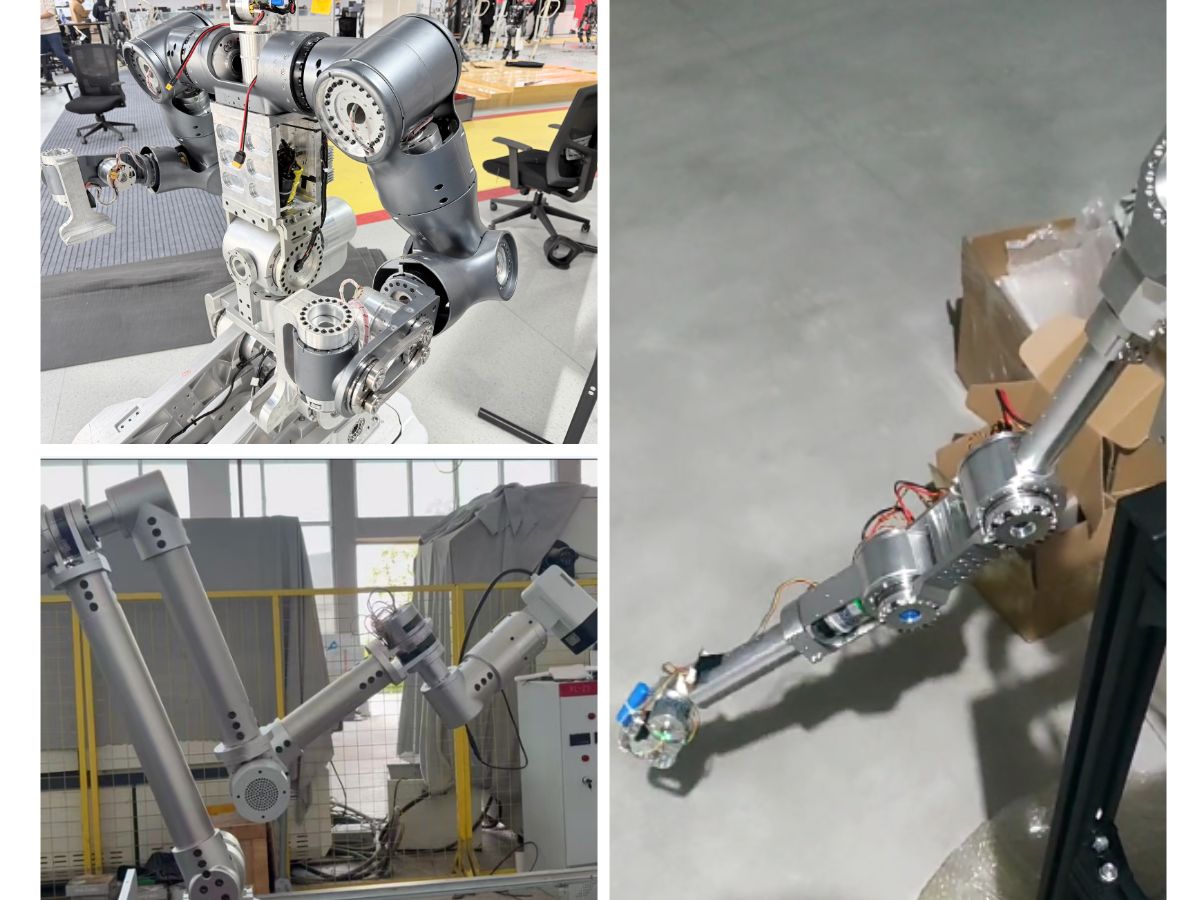
- High Precision Harmonic Drive Robot Joint Actuator Solution for Robotic ElbowsThe robotic elbow joint plays a critical role in arm flexion, posture adjustment, and end-effector positioning. As humanoid robots, collaborative robots, and robotic arms become more capable, elbow actuators need to deliver high torque and precise motion within increasingly limited installation spaces. A high precision harmonic drive robot joint actuator integrates the harmonic reducer, motor, encoder, brake, and drive system into a compact unit, providing low backlash, high stiffness, high torque density, and accurate motion control. In this article, HONPINE introduces three joint actuator series suitable for robotic elbow applications, covering different requirements for size, torque, speed, precision, and integration.
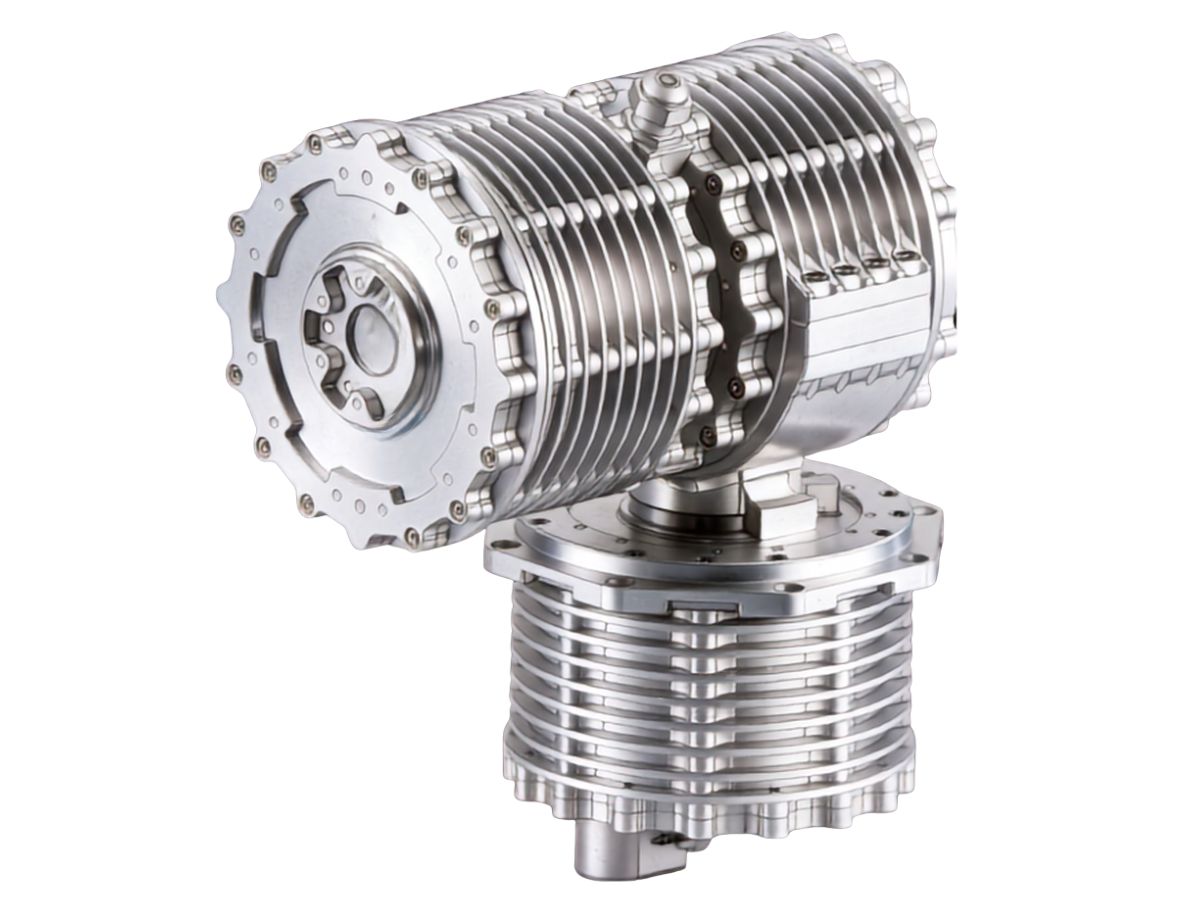
- Explosion-Proof Robot Joint Solution for Chemical Inspection Quadruped Robots: Planetary Joint Actuator with Up to 500 N·m Peak TorqueIn petrochemical, mining, power, and other hazardous environments, inspection robots are moving beyond simple monitoring toward practical operations such as tool handling, equipment inspection, and emergency response. This shift places higher demands on robot joint actuators, particularly in explosion protection, torque output, thermal management, environmental resistance, and mobility. HONPINE's explosion-proof robot joint actuator is designed for quadruped inspection robots and other hazardous-environment robotic platforms, integrating high-load planetary transmission with explosion-proof design and reliable motion performance. With up to 500 N·m peak torque per joint, optional IP67 protection, and Ex db IIB T4 Gb certification, the solution is designed to support demanding robotic applications in high-risk industrial environments.