High Precision Harmonic Drive Robot Joint Actuator Solution for Robotic Elbows
The robotic elbow joint is a critical motion joint that connects the upper arm and forearm. It is mainly responsible for arm flexion and extension, posture adjustment, and changes in the position of the end effector. In humanoid robots, collaborative robots, and robotic arms, the elbow joint must not only withstand the torque generated by the forearm and end-effector loads, but also achieve high-precision, fast, and stable motion within a limited installation space. Therefore, the structural dimensions, output torque, positioning accuracy, stiffness, backlash, and dynamic response of the elbow joint directly affect the robot arm's range of motion, control accuracy, and operating capability.
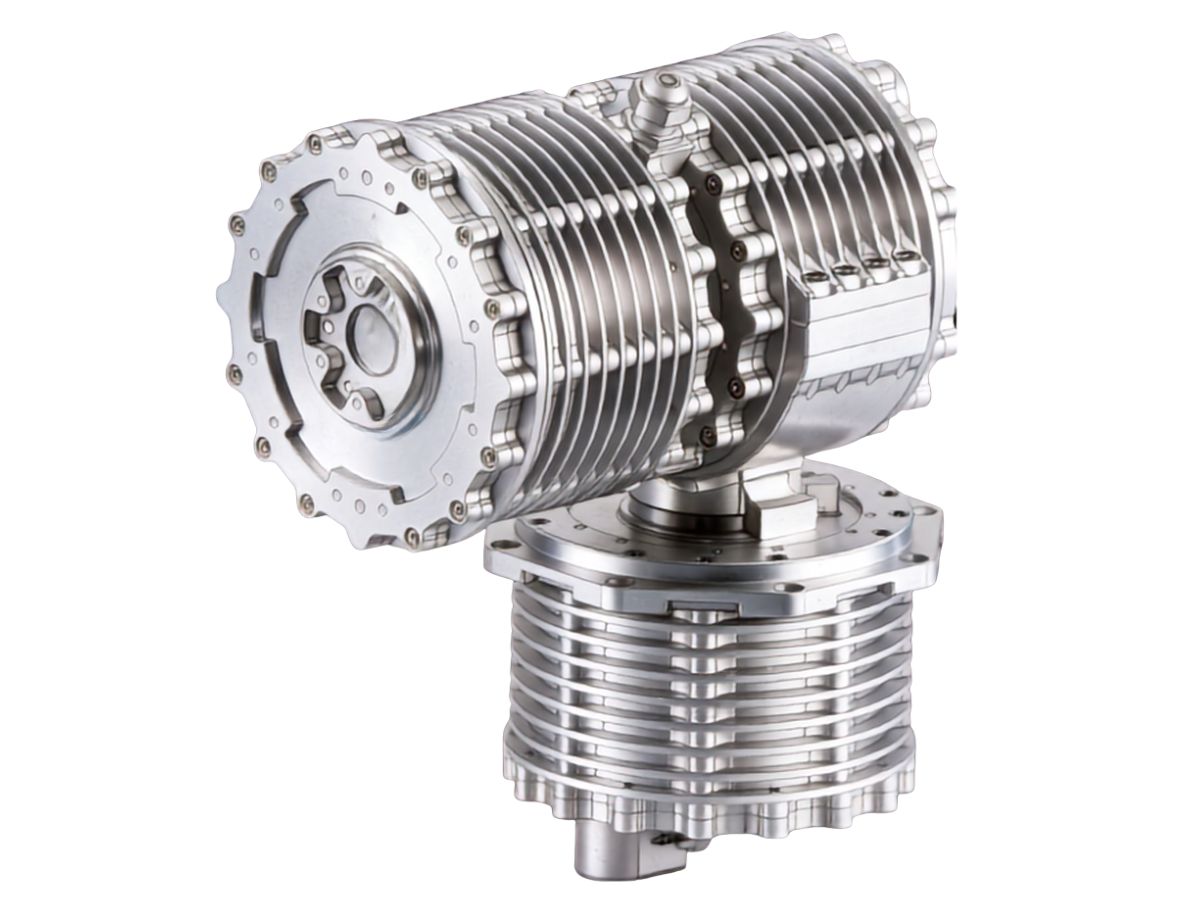
A harmonic drive robot joint actuator integrates key components such as a high-precision harmonic drive reducer, servo motor, high-resolution encoder, brake, and drive control system into a compact unit. It provides a high reduction ratio, high torque density, and compact structure within the limited space available in a robotic elbow, while also delivering low backlash, high positioning accuracy, high stiffness, and excellent repeatability.
For humanoid robots, collaborative robots, and high-precision robotic arms, this integrated design can reduce joint size and system integration complexity while simplifying cable routing and mechanical connections. This enables the elbow joint to maintain stable, fast, and controllable motion during frequent start-stop operations, posture adjustments, and precision movements.
This article introduces three HONPINE models for robotic elbow joint applications.
HPJM Series (40–52)
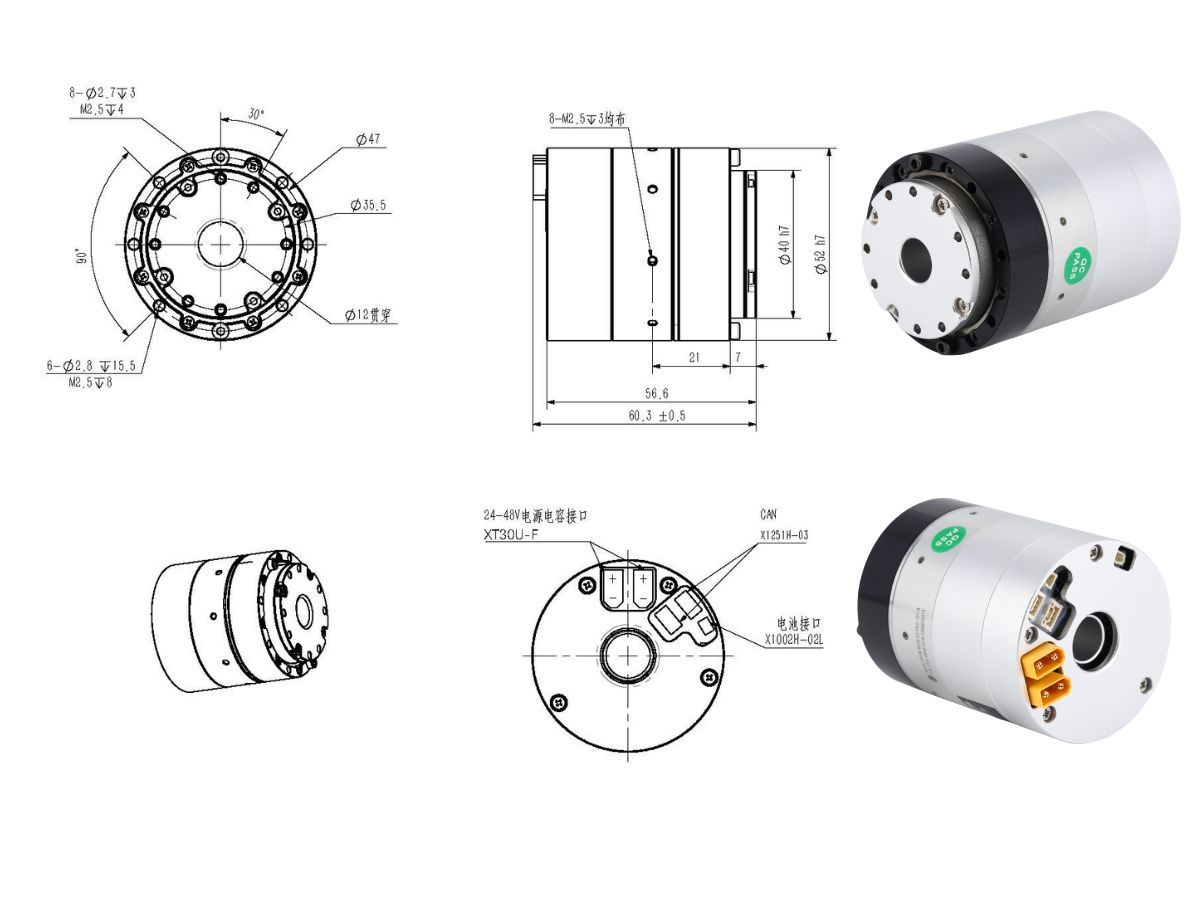
The HPJM-RE40-52-PRO-XX is a high-performance integrated joint module from the PRO Series. It features a compact 40 mm outer diameter and a 52 mm hollow cable-routing passage. The module is designed for collaborative robots, lightweight robotic arms, and precision automation equipment.
Gear Ratio: 51:101
Rated Torque: 4 N·m at 2,000 RPM
Maximum Allowable Torque: 5.5 N·m under average load / 8.9 N·m peak
Impact Torque: 8.3 N·m at 1/2 of rated torque
Speed Performance:
Rated Speed: 80 RPM
Peak Speed: 118 RPM
Click Here:Explore More HPJM Harmonic Drive Robot Joint Actuator Models
TCHL Series (11, 14)
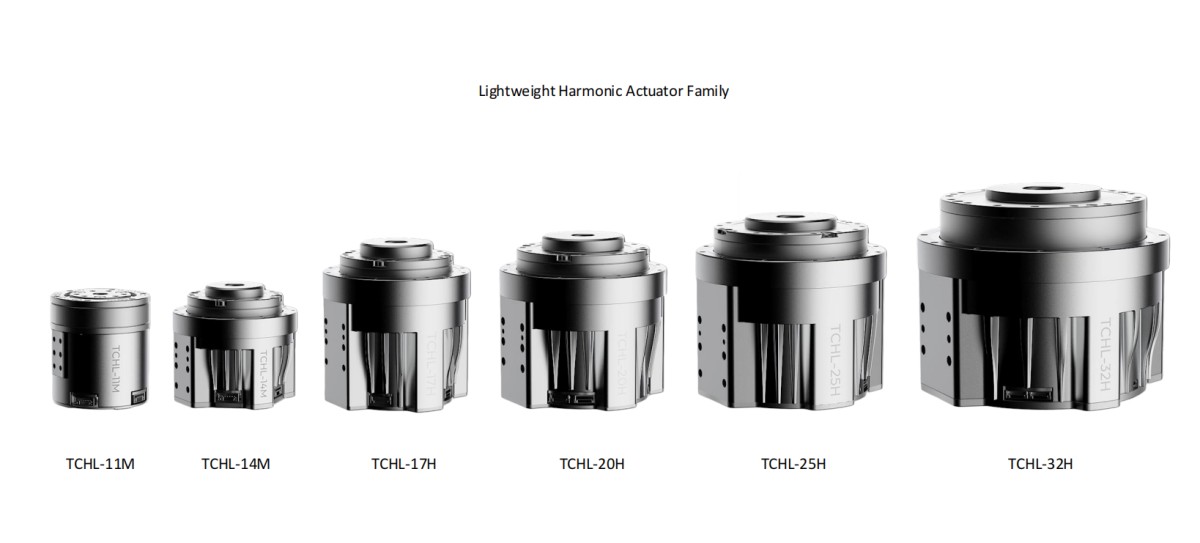
The TCHL Series joint modules cover a broad specification range from miniature precision joints to higher-load industrial applications.
The TCHL-11 (φ52) is the smallest and lightest joint module in the series. Without the brake, it weighs only 0.37 kg, while delivering a rated torque of 3.6 N·m and a peak torque of 25 N·m with a 100:1 reduction ratio. It also features an 8 mm hollow cable-routing passage, making it suitable for extremely lightweight applications such as dexterous hands, miniature collaborative robots, and medical and research equipment.
The TCHL-32 (φ131) is a heavy-duty configuration in the series. With a 101:1 reduction ratio, it delivers up to 267 N·m of rated torque and 799 N·m of peak torque. It also provides a 210 N·m allowable overturning moment and a 22 mm large-diameter hollow shaft, making it suitable as a core drive for heavy-duty industrial robotic arms and large automated rotary platforms.
Although the two models differ significantly in size and torque capacity, both are based on the same highly integrated joint technology platform. They are equipped with 17-bit dual encoders, support EtherCAT and CAN FD communication, and provide IP54 protection, with IP65 available as an option. The operating temperature range is -20°C to 50°C. Torque sensors and brakes are also available according to application requirements.
This integrated technology platform enables high-precision and highly integrated joint drive solutions for different robotic load requirements.
Click Here:Explore More TCHL Harmonic Drive Robot Joint Actuator Models
HAG / HAU Series (11, 14, 17)
The HAG Series harmonic joint motors includes three frame sizes: HAG-11, HAG-14, and HAG-17. All models are based on a 48 VDC power supply platform and offer three reduction ratio options: 51, 81, and 101.
The series is equipped with high-precision absolute BISS-C encoders, providing 22-bit single-turn and 22-bit multi-turn resolution. It also integrates a high-response torque sensor with an 8 kHz sampling frequency and supports an optional power-off brake.
The series provides positioning accuracy of ≤75 arcsec, which can be customized to ≤20 arcsec, with repeat positioning accuracy of ≤10 arcsec.
The HAG-11, as the compact model, provides a rated torque range of 4.6–7.3 N·m and a peak torque range of 11.4–18 N·m, while weighing only 0.51–0.55 kg.
The HAG-14 and HAG-17 have highly similar mechanical dimensions and core electrical parameters, while offering higher torque performance. Their rated torque ranges from 10.5 to 21 N·m, with peak torque ranging from 23 to 35 N·m. Their weight is 0.875–0.92 kg, and they can be equipped with brakes providing a holding torque of ≥0.65 N·m. The HAG-11 brake provides a holding torque of ≥0.2 N·m.
Together, these models provide highly integrated, high-stiffness, and high-precision joint drive solutions for collaborative robots, humanoid robots, and precision automation equipment with different load requirements.
Click Here:Explore More HAG Harmonic Drive Robot Joint Actuator Models
Contact HONPINE for Robotic Elbow Joint Actuator Solutions
HONPINE provides high-precision harmonic drive robot joint actuator solutions for robotic elbow joints and other robotic joint applications. Contact HONPINE to discuss your application requirements and select a suitable harmonic joint module for your robot.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
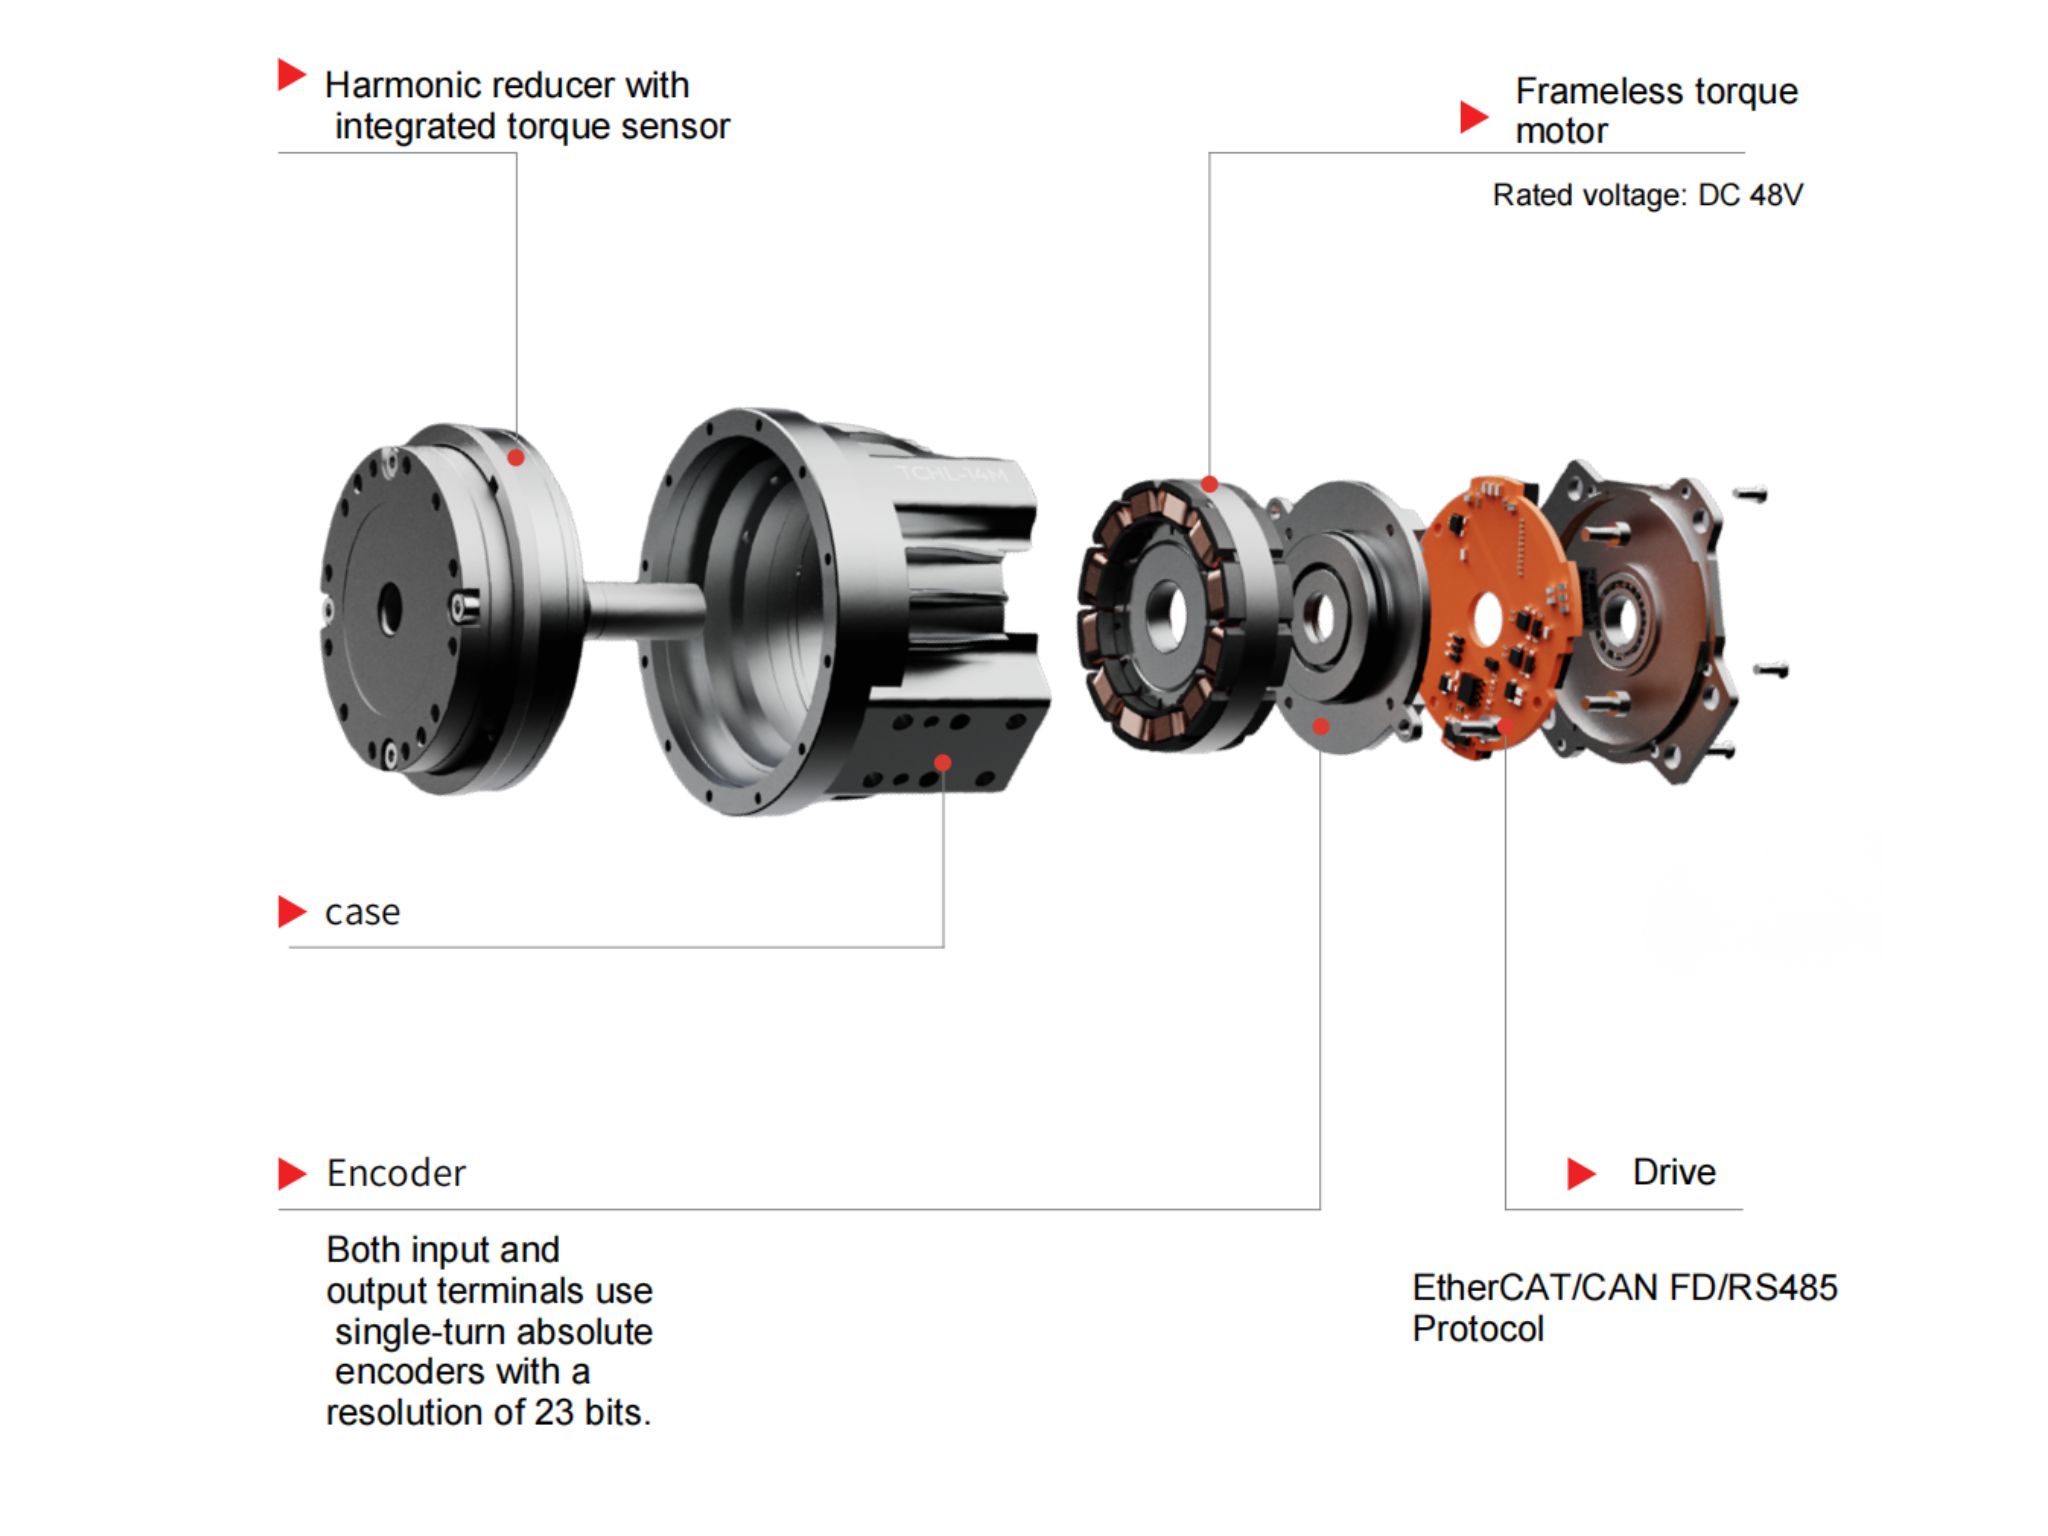
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 High Precision Harmonic Drive Robot Joint Actuator Solution for Robotic ElbowsThe robotic elbow joint plays a critical role in arm flexion, posture adjustment, and end-effector positioning. As humanoid robots, collaborative robots, and robotic arms become more capable, elbow actuators need to deliver high torque and precise motion within increasingly limited installation spaces. A high precision harmonic drive robot joint actuator integrates the harmonic reducer, motor, encoder, brake, and drive system into a compact unit, providing low backlash, high stiffness, high torque density, and accurate motion control. In this article, HONPINE introduces three joint actuator series suitable for robotic elbow applications, covering different requirements for size, torque, speed, precision, and integration.
 Explosion-Proof Robot Joint Solution for Chemical Inspection Quadruped Robots: Planetary Joint Actuator with Up to 500 N·m Peak TorqueIn petrochemical, mining, power, and other hazardous environments, inspection robots are moving beyond simple monitoring toward practical operations such as tool handling, equipment inspection, and emergency response. This shift places higher demands on robot joint actuators, particularly in explosion protection, torque output, thermal management, environmental resistance, and mobility. HONPINE's explosion-proof robot joint actuator is designed for quadruped inspection robots and other hazardous-environment robotic platforms, integrating high-load planetary transmission with explosion-proof design and reliable motion performance. With up to 500 N·m peak torque per joint, optional IP67 protection, and Ex db IIB T4 Gb certification, the solution is designed to support demanding robotic applications in high-risk industrial environments.
 Planetary Drive Actuator for AGV Wheel Hub Motors: Solving Torque, Turning Radius and Drive Integration ChallengesHello everyone, I’m Theodore Li, Technical Director at HONPINE. Today, I’d like to discuss how a planetary drive actuator can solve practical challenges in AGV wheel hub motor systems. AGVs and AMRs require sufficient wheel torque for heavy-load starting, acceleration, slope climbing, and frequent reversing, while the drive system must remain compact enough for limited chassis space. A planetary drive actuator combines a motor with a planetary reduction mechanism to convert high-speed motor output into the lower-speed, higher-torque motion required at the wheel. In this article, I will examine the relationship between planetary drive actuators and AGV wheel hub motors, including torque, gear ratio, wheel diameter, climbing ability, turning radius, direct-drive systems, and harmonic drive actuators.
 How to Choose a Reliable Robot Joint Motor Manufacturer for Humanoid Robots?Choosing a reliable robot joint motor manufacturer is a critical step when developing humanoid robots and other advanced robotic systems. A robotic joint must balance torque, speed, precision, torque density, thermal performance, feedback, mechanical stiffness, and long-term reliability within a compact structure. For B2B robotics companies, supplier evaluation should therefore go beyond a product datasheet and consider engineering capability, manufacturing capacity, joint integration, testing, and production scalability. In this article, Allen Li, Founder of HONPINE, explains the key factors to consider when selecting a robot joint motor manufacturer and how integrated harmonic robot joint technology can support humanoid robot development.
 Lightweight Humanoid Robots Start with Precision TransmissionAs humanoid robots move from experimental prototypes toward practical applications, lightweight design, energy efficiency, motion performance, and long-term reliability are becoming increasingly important. At the center of these challenges is precision transmission. From harmonic reducers and lightweight robot joints to integrated development kits, the design of each core component directly affects the overall performance of a humanoid robot. In this article, Allen Li, Founder of HONPINE, shares his perspective on how precision transmission technology can support the development of lightweight humanoid robots and how HONPINE is extending its expertise from harmonic reducers toward lightweight robot joints and integrated robotics solutions.
 Hollow-Shaft Direct Drive Motor for Heavy-Duty Precision Positioning and Industrial AutomationIn heavy-duty automation, precision positioning depends not only on the motor but also on the mechanical transmission between the motor and the load. A hollow shaft direct drive motor delivers torque directly to the load while providing a central passage for cables, pneumatic lines and other components. This makes it a practical solution for CNC machining, photovoltaic, lithium battery, optical inspection and semiconductor equipment.


Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 High Precision Harmonic Drive Robot Joint Actuator Solution for Robotic ElbowsThe robotic elbow joint plays a critical role in arm flexion, posture adjustment, and end-effector positioning. As humanoid robots, collaborative robots, and robotic arms become more capable, elbow actuators need to deliver high torque and precise motion within increasingly limited installation spaces. A high precision harmonic drive robot joint actuator integrates the harmonic reducer, motor, encoder, brake, and drive system into a compact unit, providing low backlash, high stiffness, high torque density, and accurate motion control. In this article, HONPINE introduces three joint actuator series suitable for robotic elbow applications, covering different requirements for size, torque, speed, precision, and integration.
 Explosion-Proof Robot Joint Solution for Chemical Inspection Quadruped Robots: Planetary Joint Actuator with Up to 500 N·m Peak TorqueIn petrochemical, mining, power, and other hazardous environments, inspection robots are moving beyond simple monitoring toward practical operations such as tool handling, equipment inspection, and emergency response. This shift places higher demands on robot joint actuators, particularly in explosion protection, torque output, thermal management, environmental resistance, and mobility. HONPINE's explosion-proof robot joint actuator is designed for quadruped inspection robots and other hazardous-environment robotic platforms, integrating high-load planetary transmission with explosion-proof design and reliable motion performance. With up to 500 N·m peak torque per joint, optional IP67 protection, and Ex db IIB T4 Gb certification, the solution is designed to support demanding robotic applications in high-risk industrial environments.
 Planetary Drive Actuator for AGV Wheel Hub Motors: Solving Torque, Turning Radius and Drive Integration ChallengesHello everyone, I’m Theodore Li, Technical Director at HONPINE. Today, I’d like to discuss how a planetary drive actuator can solve practical challenges in AGV wheel hub motor systems. AGVs and AMRs require sufficient wheel torque for heavy-load starting, acceleration, slope climbing, and frequent reversing, while the drive system must remain compact enough for limited chassis space. A planetary drive actuator combines a motor with a planetary reduction mechanism to convert high-speed motor output into the lower-speed, higher-torque motion required at the wheel. In this article, I will examine the relationship between planetary drive actuators and AGV wheel hub motors, including torque, gear ratio, wheel diameter, climbing ability, turning radius, direct-drive systems, and harmonic drive actuators.
 How to Choose a Reliable Robot Joint Motor Manufacturer for Humanoid Robots?Choosing a reliable robot joint motor manufacturer is a critical step when developing humanoid robots and other advanced robotic systems. A robotic joint must balance torque, speed, precision, torque density, thermal performance, feedback, mechanical stiffness, and long-term reliability within a compact structure. For B2B robotics companies, supplier evaluation should therefore go beyond a product datasheet and consider engineering capability, manufacturing capacity, joint integration, testing, and production scalability. In this article, Allen Li, Founder of HONPINE, explains the key factors to consider when selecting a robot joint motor manufacturer and how integrated harmonic robot joint technology can support humanoid robot development.
 Lightweight Humanoid Robots Start with Precision TransmissionAs humanoid robots move from experimental prototypes toward practical applications, lightweight design, energy efficiency, motion performance, and long-term reliability are becoming increasingly important. At the center of these challenges is precision transmission. From harmonic reducers and lightweight robot joints to integrated development kits, the design of each core component directly affects the overall performance of a humanoid robot. In this article, Allen Li, Founder of HONPINE, shares his perspective on how precision transmission technology can support the development of lightweight humanoid robots and how HONPINE is extending its expertise from harmonic reducers toward lightweight robot joints and integrated robotics solutions.
 Hollow-Shaft Direct Drive Motor for Heavy-Duty Precision Positioning and Industrial AutomationIn heavy-duty automation, precision positioning depends not only on the motor but also on the mechanical transmission between the motor and the load. A hollow shaft direct drive motor delivers torque directly to the load while providing a central passage for cables, pneumatic lines and other components. This makes it a practical solution for CNC machining, photovoltaic, lithium battery, optical inspection and semiconductor equipment.
 How to Choose a Robot Joint Actuator: 3 Key Criteria Engineers Should Check?Choosing a robot joint actuator is an engineering decision that affects not only torque and motion performance, but also control stability, mechanical integration, and development time. For industrial robots, collaborative robots, humanoid robots, and other robotic systems, the right actuator must match the actual requirements of each joint while remaining compatible with the robot’s motor, encoder, controller, communication network, and power architecture. In this article, I will explain three key criteria engineers should evaluate when selecting a robot joint actuator: torque and gear ratio matching, encoder and communication compatibility, and the manufacturer’s technical documentation and engineering support.
 Outdoor Robot Joint Solution: Harmonic Joint Module with Built-in Torque SensorHello everyone, I’m Theodore Li, Technical Director at HONPINE. As robots move beyond controlled factory environments, outdoor robotic applications are creating new requirements for robot joint design. Rain, dust, humidity, temperature fluctuations, low-temperature conditions, and unpredictable external loads can all affect how a robotic joint performs in the field. In these environments, a joint needs to provide more than precise rotation. It also needs reliable torque feedback, suitable environmental protection, stable operation under changing temperatures, and practical mechanical integration. In this article, I will explain the key engineering considerations behind our outdoor robot joint solution, including the harmonic joint module, built-in torque sensor, IP65 protection, low-temperature lubrication, cable outlet protection, and mechanical integration, based on our experience with outdoor robotic applications such as solar panel installation, construction, and cleaning robots.
 RV Reducer for Welding Positioners: Selection and Torque Calculation for Heavy-Duty Welding ApplicationsSelecting the right RV reducer for a welding positioner requires more than simply matching the reducer to the workpiece weight. A heavy-duty welding positioner must provide sufficient output torque, high torsional rigidity, stable low-speed rotation, accurate positioning, and reliable performance during acceleration, deceleration, and reversing. In this article, we explain how to select an RV reducer and servo motor for a welding positioner by calculating output speed, reduction ratio, workpiece inertia, gravity load torque, acceleration torque, motor torque, and peak torque. A practical 500 kg welding positioner example is also used to show how these parameters affect RV reducer selection.