










Current tag:honpine
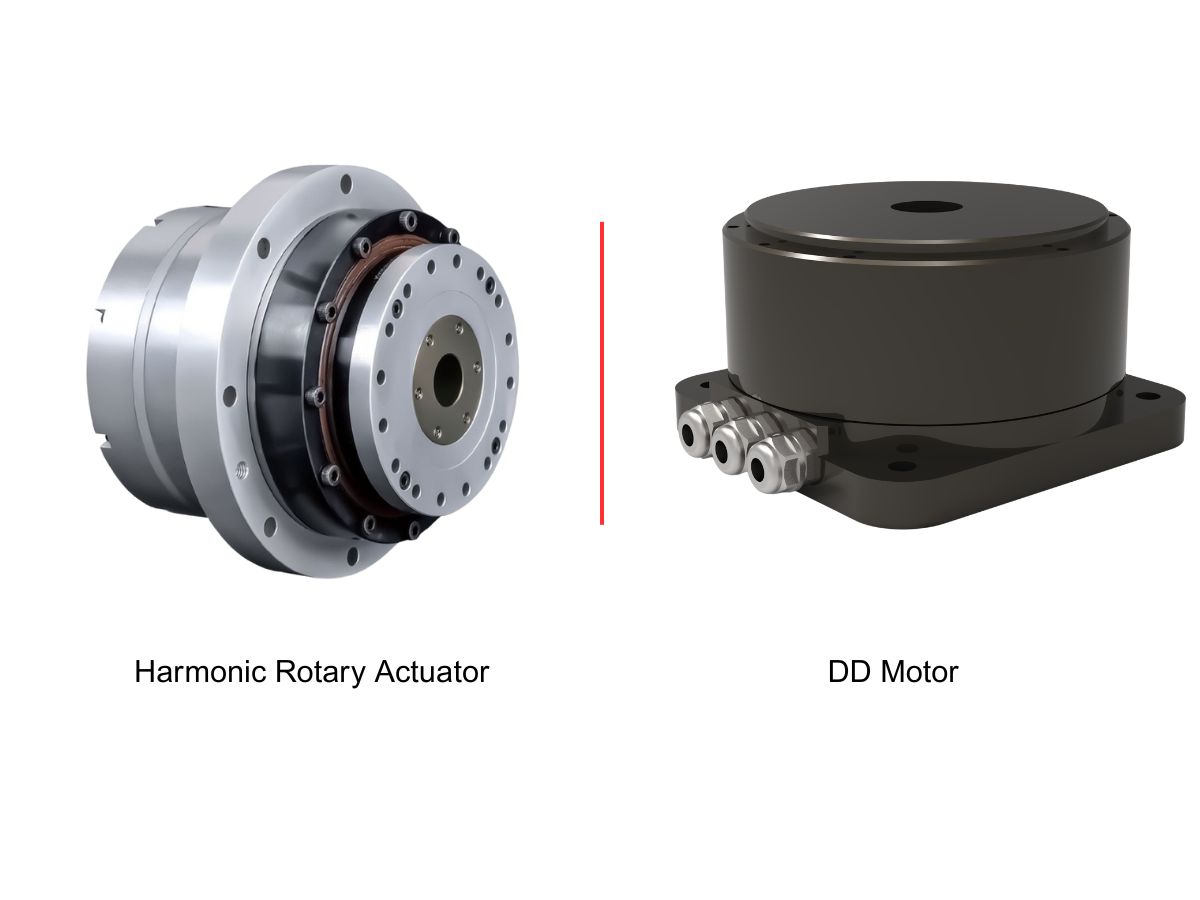
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 Top 10 Humanoid Robot Joint Motor ManufacturersThe rapid development of humanoid robotics is driving demand for high-performance joint motors and integrated actuator modules. From harmonic and planetary joint modules to frameless torque motors and intelligent drive systems, manufacturers are developing different solutions to meet the requirements of humanoid robot joints. But which supplier should you choose? In this article, we introduce 10 humanoid robot joint motor manufacturers from China and Japan, comparing their product portfolios, technical features, torque capabilities, and application areas to help robotics developers and manufacturers make more informed sourcing decisions.
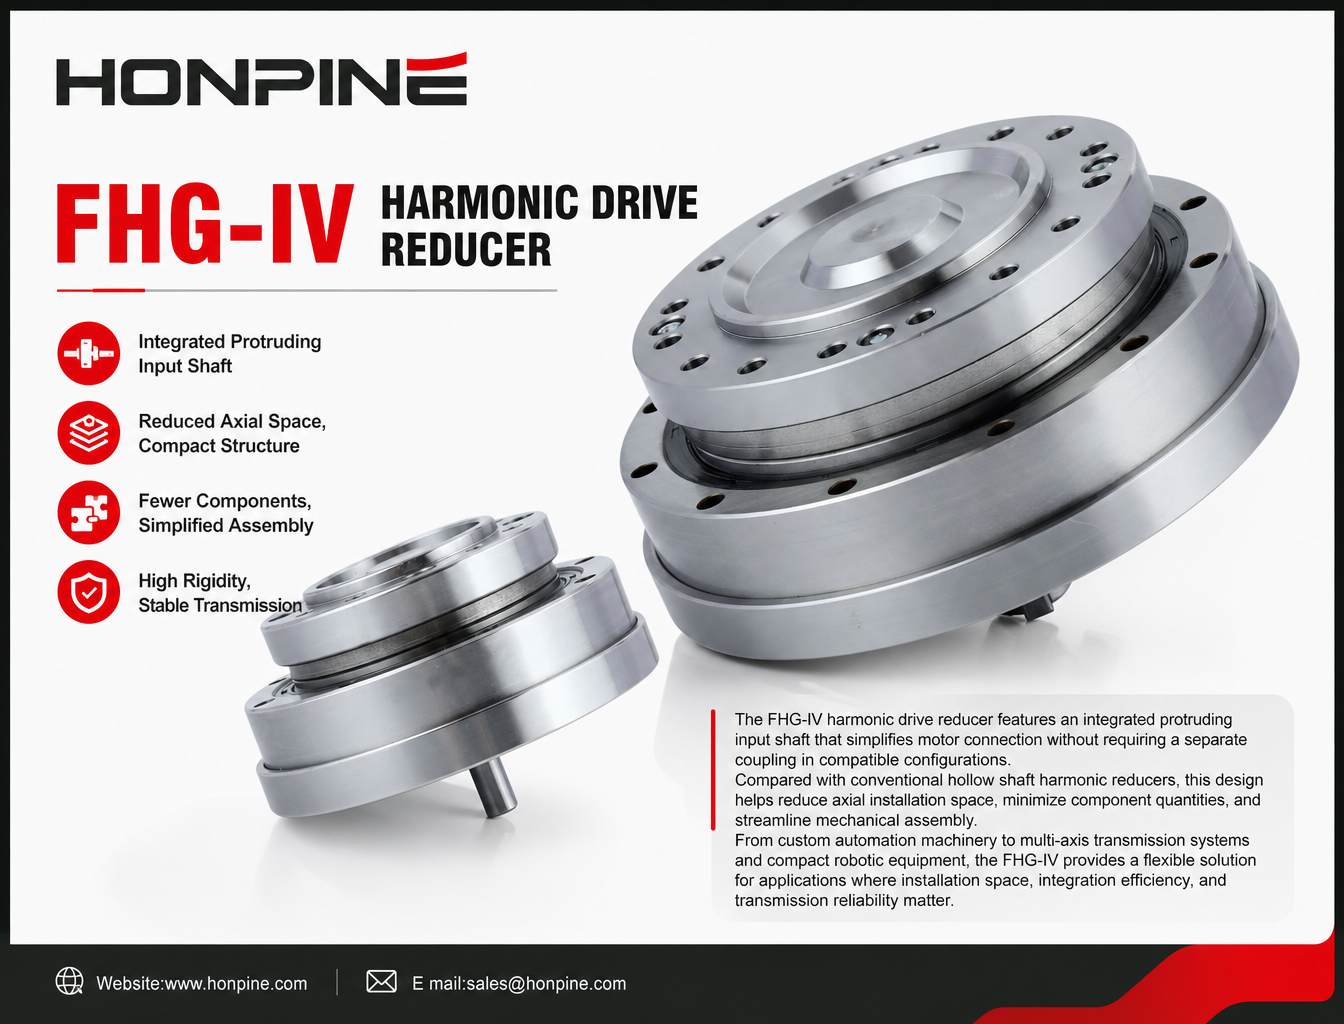
- FHG-IV Harmonic Drive Reducer: Eliminate the Coupling for a More Compact DesignThe FHG-IV harmonic drive reducer features an integrated protruding input shaft that simplifies motor connection without requiring a separate coupling in compatible configurations. Compared with conventional hollow shaft harmonic reducers, this design helps reduce axial installation space, minimize component quantities, and streamline mechanical assembly. From custom automation machinery to multi-axis transmission systems and compact robotic equipment, the FHG-IV provides a flexible solution for applications where installation space, integration efficiency, and transmission reliability matter.
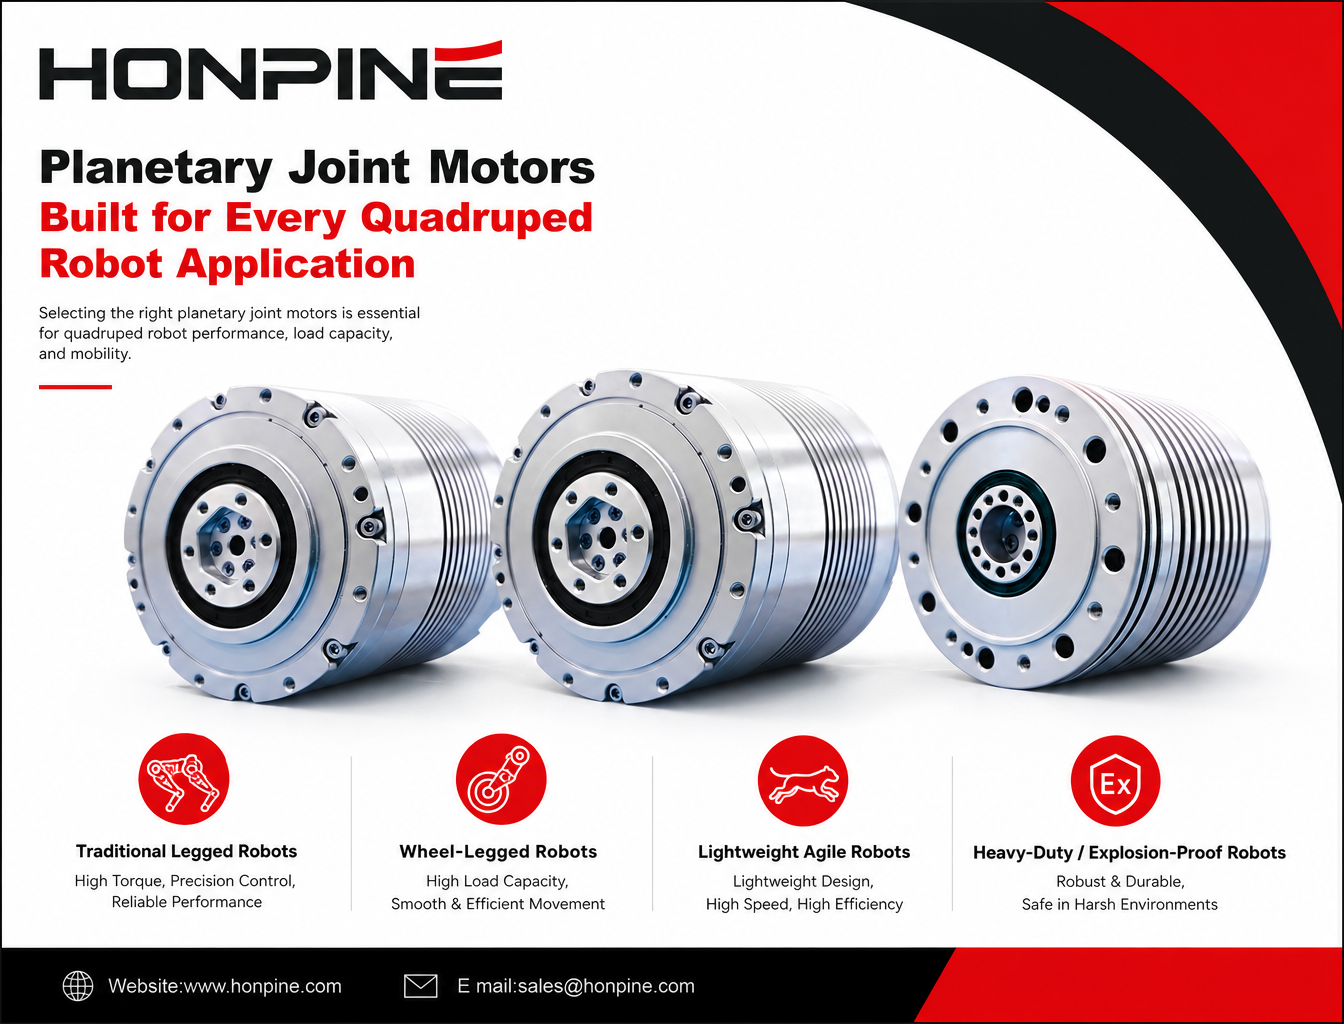
- How to Select Planetary Joint Motors for Quadruped Robots?Selecting the right planetary joint motors is essential for quadruped robot performance, load capacity, and mobility. This guide explores motor selection for traditional legged robots, wheel-legged robots, lightweight agile robots, and heavy-duty or explosion-proof quadruped robots. Learn how to match HONPINE JRM planetary joint modules to different joint positions based on rated torque, peak torque, rotational speed, voltage, and weight requirements.

{item.title}
{item.description}




