Types of Robot Joint Motors: Model Selection, Advantages and Disadvantages
Robot joint motors can be classified by their driving methods into electric drive, hydraulic drive, pneumatic drive, and some less common drive methods such as shape memory alloy actuators that have not yet reached mass production.
Hydraulic drive has been used less and less because of its large size and the risk of oil leakage. Boston Dynamics used hydraulic systems in some of its earlier robots, but newer humanoid robots have also moved toward electric drive systems. Pneumatic drive is also not widely adopted because of its relatively difficult control, and it is mainly used in systems designed by research institutions.
In this article, I will explain how to select an electric-drive robot joint motorand introduce the main types currently used in robotic systems.
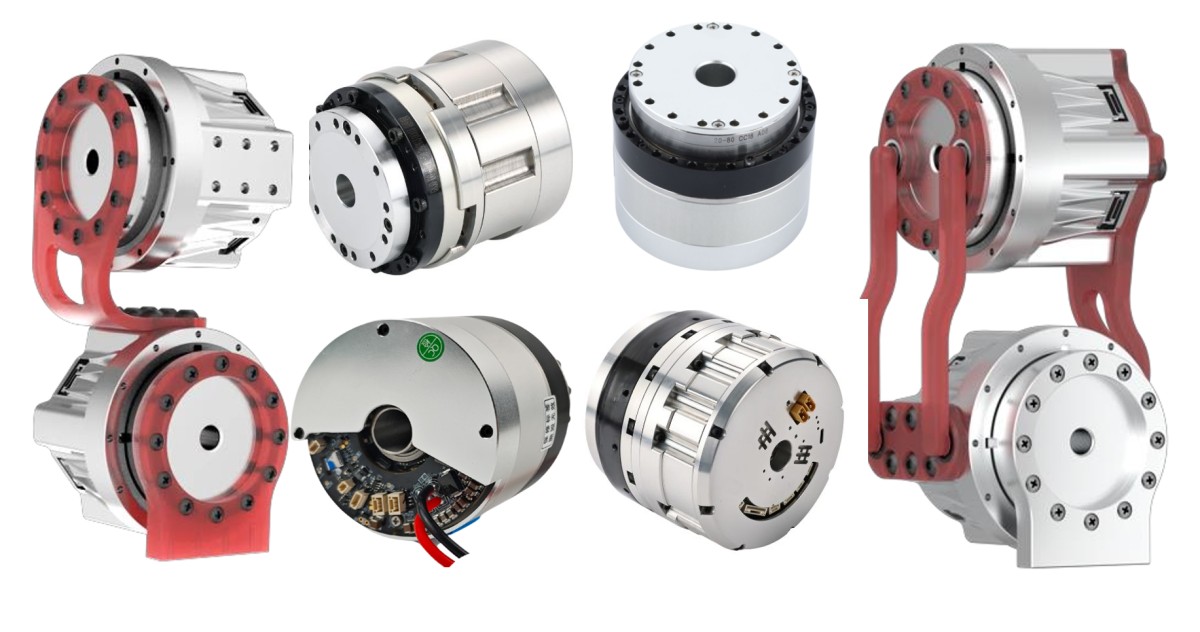
Electric-drive joint modules can be classified according to their reduction methods into harmonic drive robot joint motor, planetary reducer robot joint motor, cycloidal robot joint motor, ball screw robot joint motor, and direct drive robot joint motor.
1. Harmonic Drive Robot Joint Motor
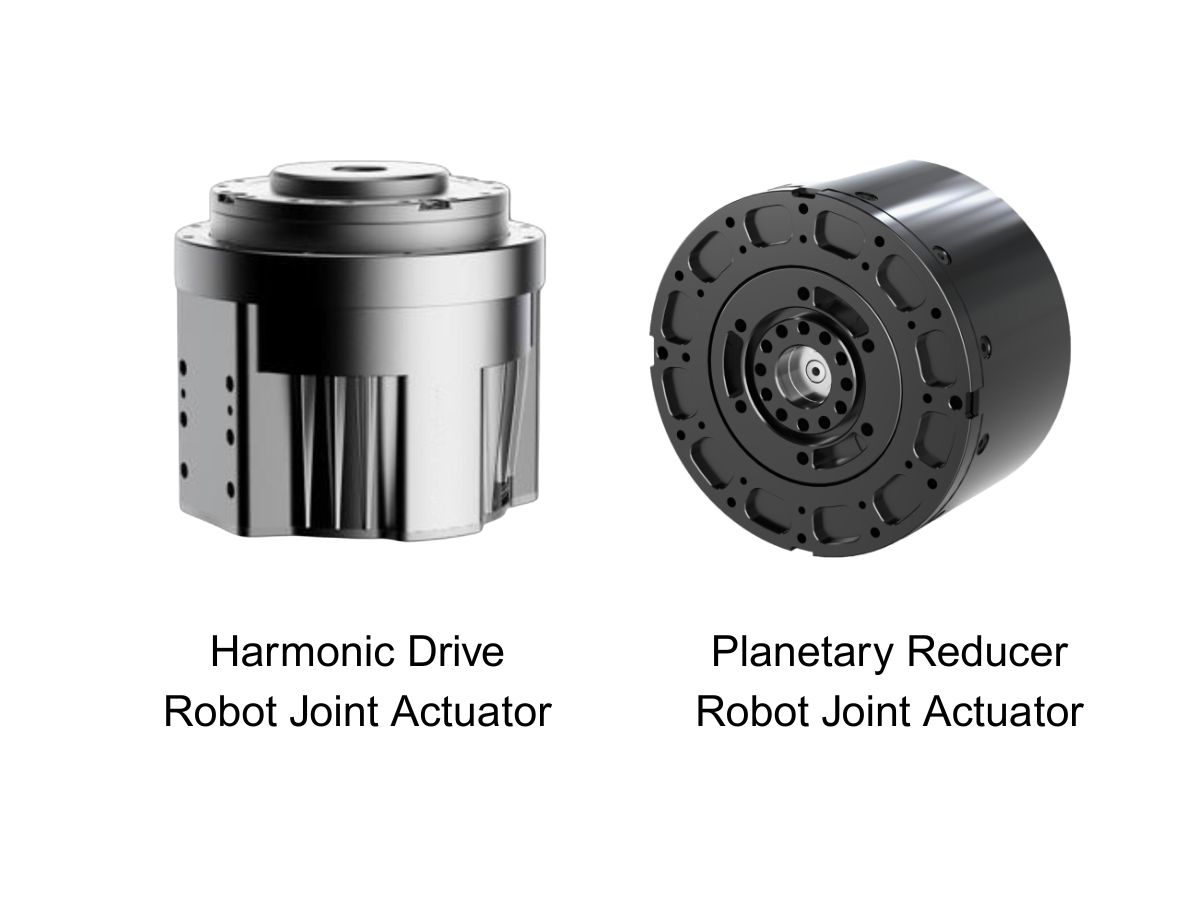
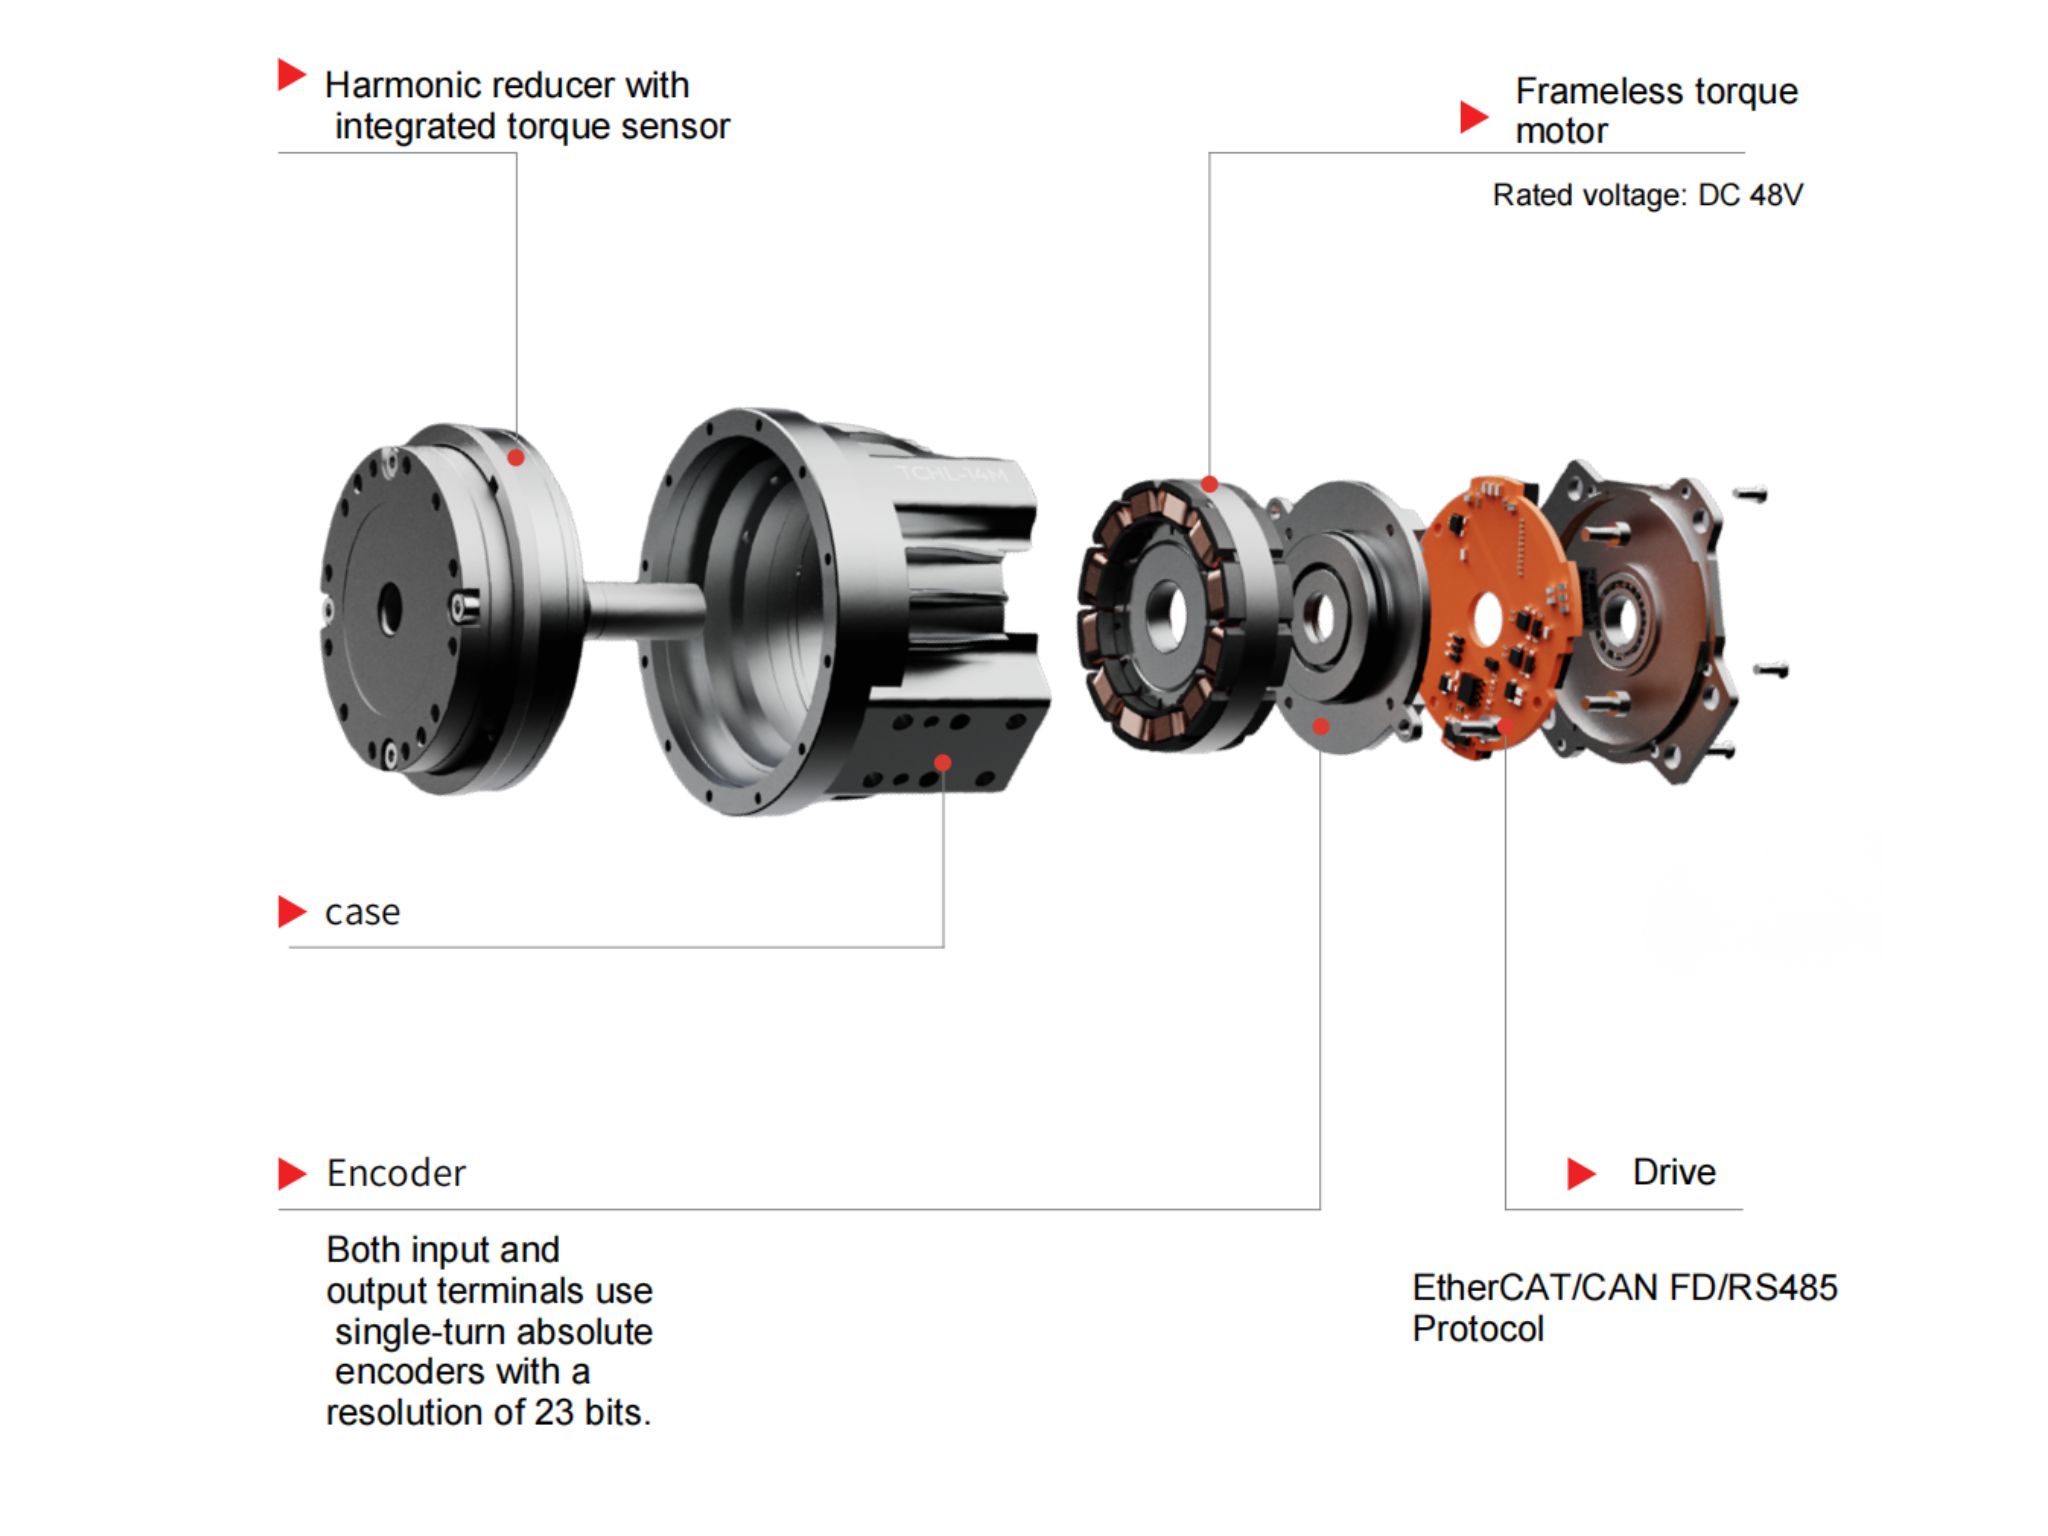
The harmonic drive robot joint motor integrates a harmonic drive reducer into the joint motor design, giving it the advantages of high precision, high reduction ratio, high torque density, a compact coaxial structure, and low backlash.
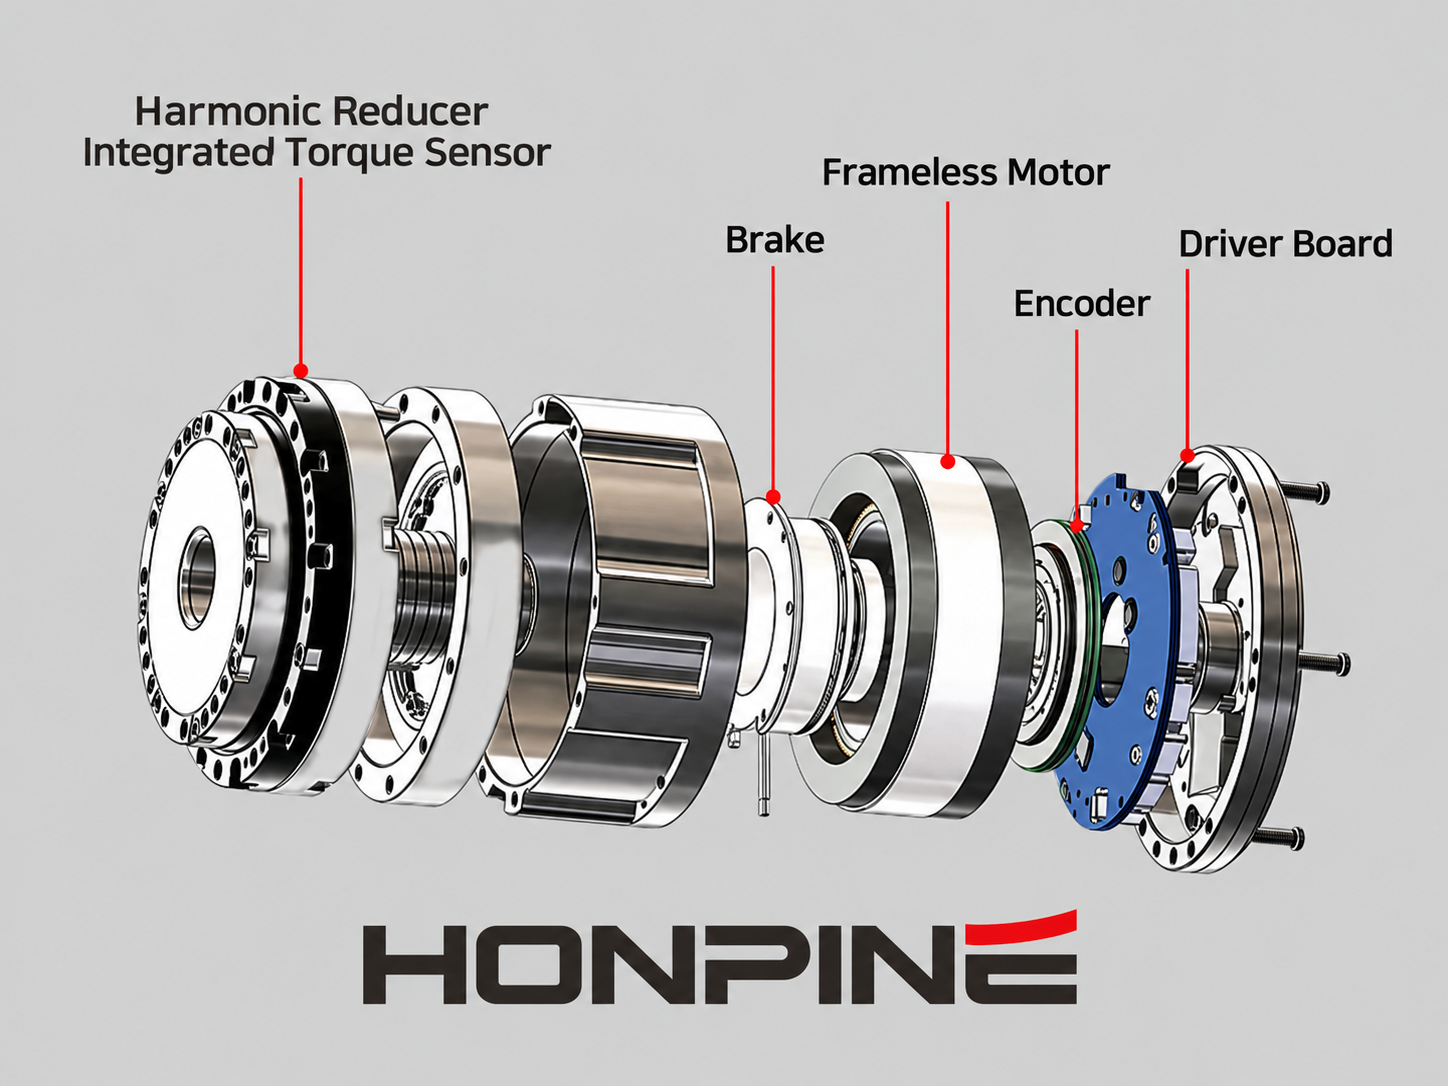
HONPINE harmonic drive robot joint motors can also be integrated with dual encoders, torque sensors, and other components, enabling a safer, lighter, and highly integrated joint design.
The main disadvantage of a harmonic drive robot joint motor is that its cost is slightly higher compared with a planetary reducer robot joint motor. In applications involving high impact loads and frequent collisions, the peak torque and overload capacity of the reducer need to be considered carefully. Its transmission efficiency is also generally lower than that of a direct drive motor.
2. Planetary Reducer Robot Joint Motor
The planetary reducer robot joint motor generally has a slightly lower cost than a harmonic drive robot joint motor. It offers high transmission efficiency and strong impact resistance, and is commonly used in industrial robots, heavy-load robots, AGVs/AMRs, mobile robots, construction robots, and other joints that require high efficiency and load capacity.
Planetary reducer robot joint motors can also cover a relatively wide range of reduction ratios and torque requirements.
The disadvantage is that planetary reducers generally have a certain amount of backlash. Therefore, they may not be suitable for applications that require extremely high positioning accuracy and very low backlash.
3. Cycloidal Robot Joint Motor
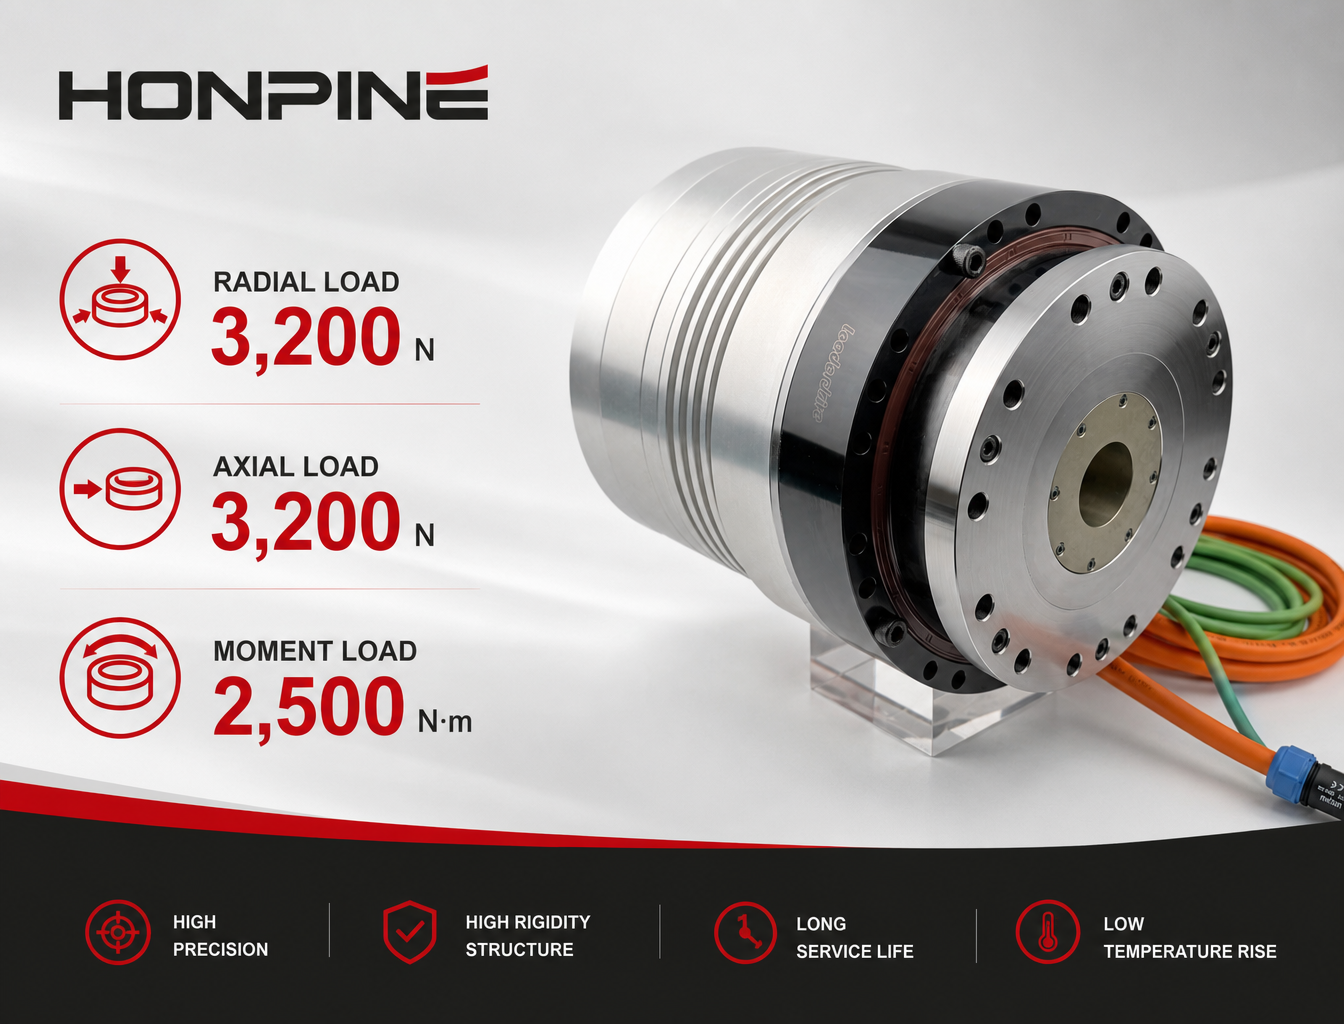
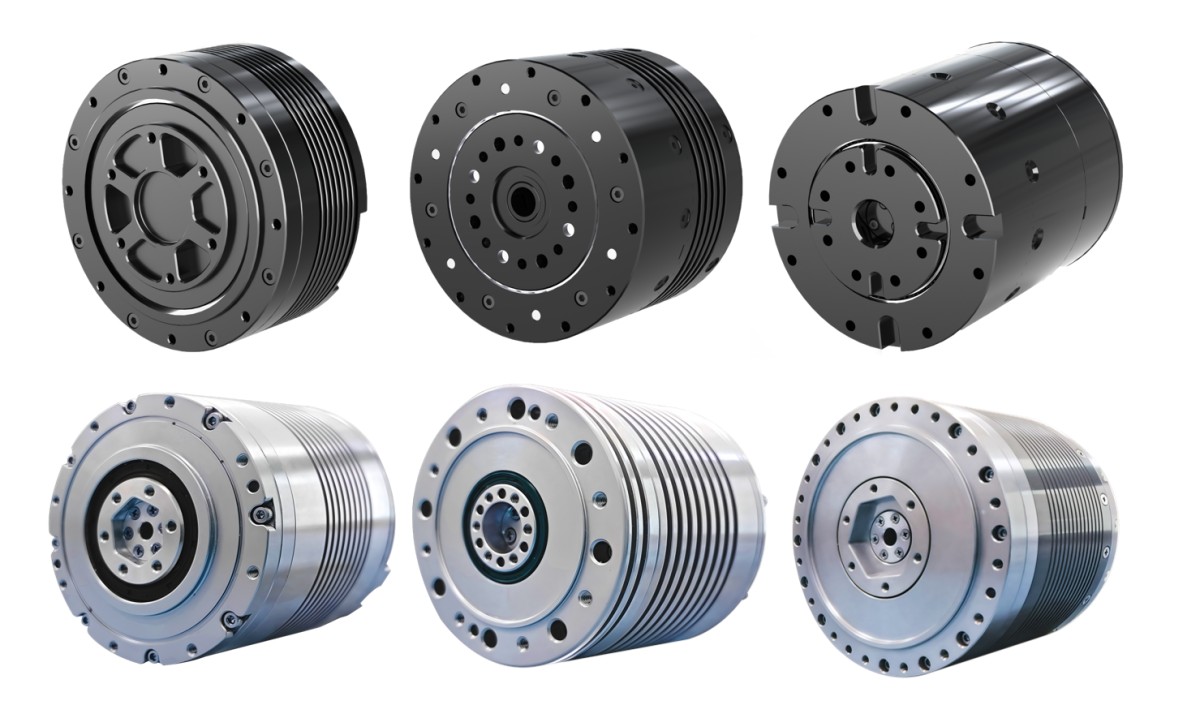
The biggest advantage of a cycloidal robot joint motor is its excellent impact resistance. It also features high structural rigidity, while the output side can withstand relatively large radial and axial loads.
Cycloidal robot joint motors are commonly used in heavy-load robots, industrial robots, construction machinery, heavy-duty robotic arms, and other robotic applications that require high impact resistance.
The disadvantage is that, compared with harmonic drive and planetary reducer solutions, cycloidal robot joint motors are currently used less frequently in humanoid robots. Further optimization of materials and mechanical structures is still required to better meet the requirements of humanoid robot applications.
In addition, the manufacturing process and machining accuracy requirements of cycloidal reducers can result in relatively high production costs.
4. Ball Screw Robot Joint Motor
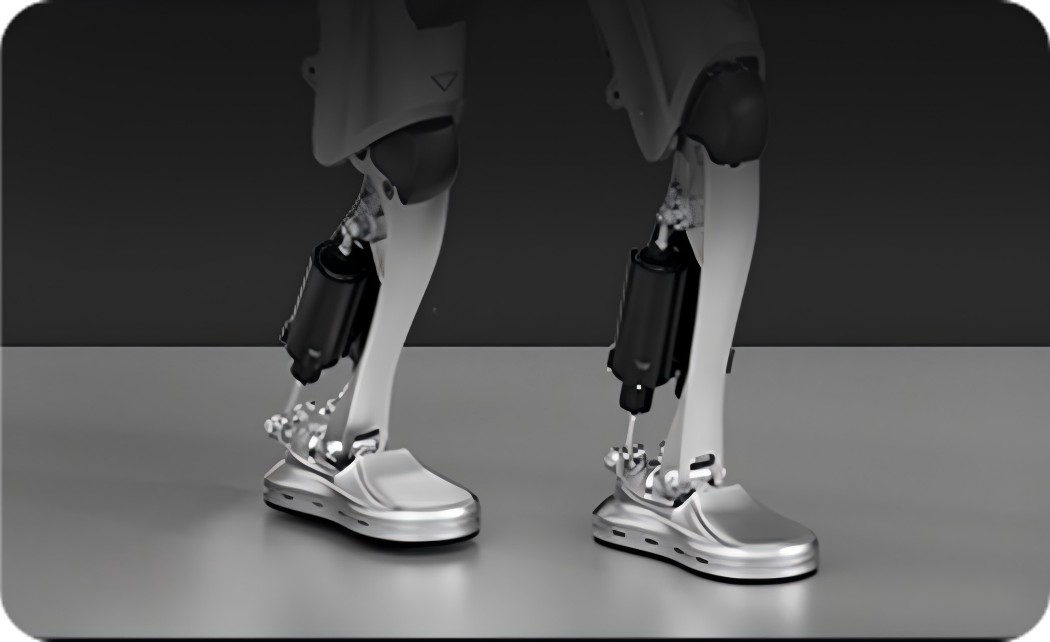
A ball screw robot joint motor, also known as a linear joint module, is a solution that can simultaneously meet four important requirements: compact size, high force output, high precision, and long service life.
It is particularly valuable in robotic mechanisms that require high thrust, such as robot legs and knee joints.
The disadvantage is that the mechanical structure is relatively complex, making the overall design more difficult. In addition, the cost of this type of joint module is relatively high.
5. Direct Drive Robot Joint Motor
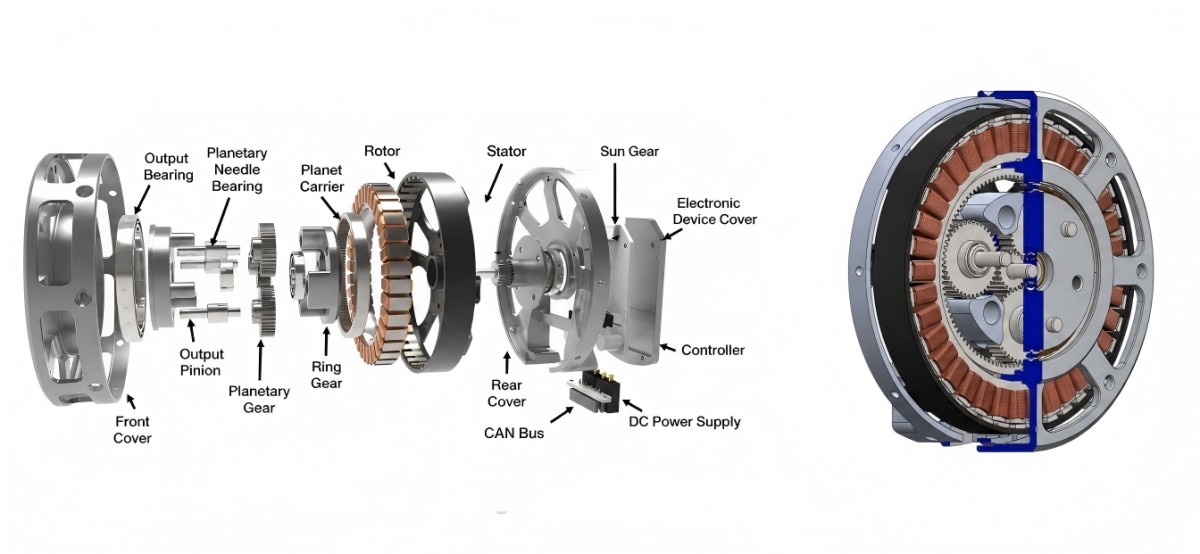
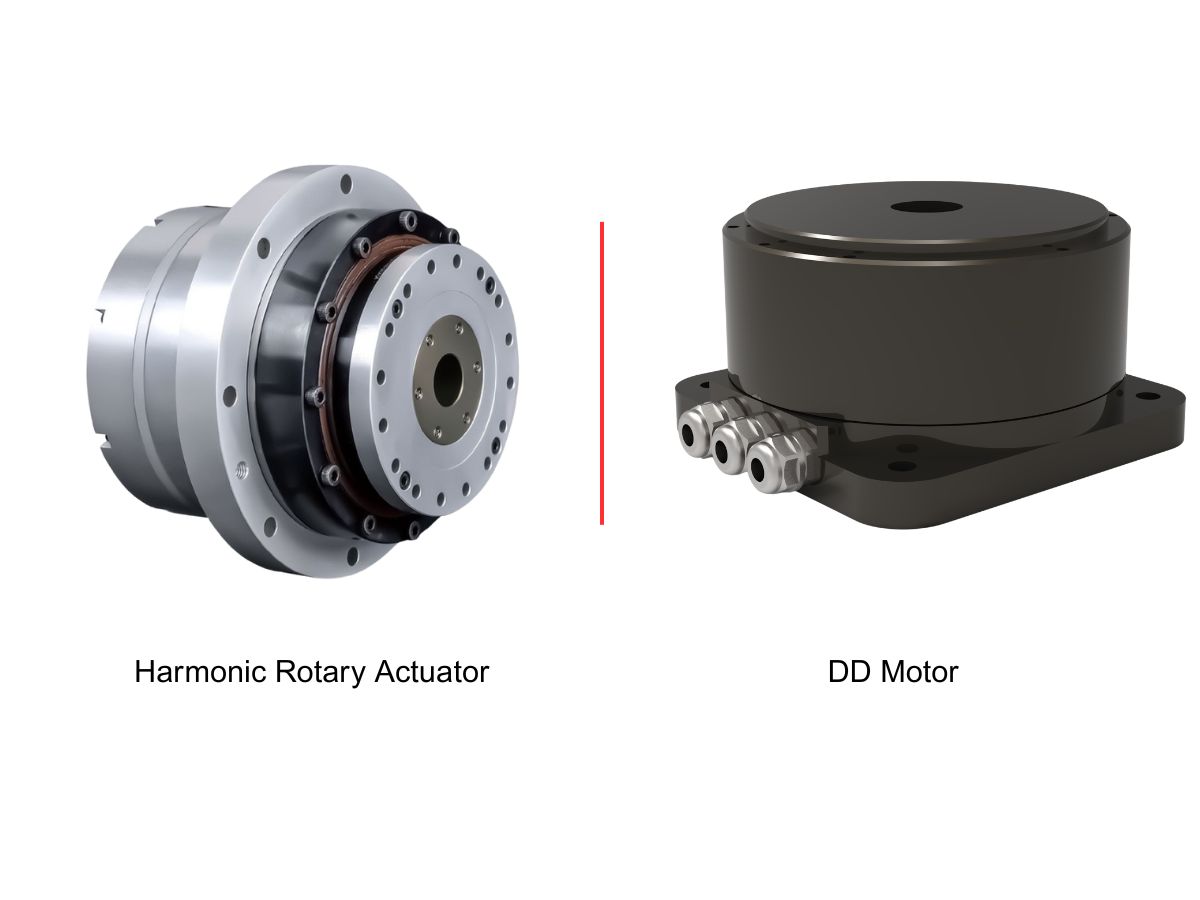
The direct drive robot joint motor does not contain a reducer inside the motor. Therefore, it does not have the backlash introduced by a reduction mechanism. It provides fast response during reverse motion and high mechanical efficiency.
Direct drive robot joint motors are suitable for high-speed dynamic robots, collaborative robots, force-controlled robots, gimbals, precision rotary platforms, and low-speed high-response joints.
The disadvantages are that the motor is generally larger and heavier, and heat dissipation can be a major challenge. The overall cost is also relatively high.
Conclusion
With the development of robot joint motor technology, the classification of joint motors is becoming increasingly diverse. Some semi-enclosed joint modules have also appeared on the market, as well as miniaturized joint modules designed for robotic hands and other compact mechanisms. However, some of these technologies are still relatively immature and have not yet reached widespread mass production.
When selecting a robot joint motor, it is important to choose the most suitable solution according to the specific application, rather than simply choosing the most advanced or most expensive technology.
If you have questions about robot joint motor selection, contact HONPINE. Our technical team can assist you in selecting a suitable joint motor solution according to your application requirements.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Harmonic Reducer vs. Harmonic Rotary Actuator: Which Is Better for CNC Machine Tools?Choosing between a harmonic reducer and a harmonic rotary actuator is an important decision in CNC machine tool design. Both solutions offer high-precision motion control, but they differ in integration, installation requirements, rigidity, and system flexibility. For CNC fourth-axis rotary tables and compact five-axis machining systems, selecting the right harmonic drive can significantly influence machine performance. In this article, HONPINE Technical Director Theodore Li compares harmonic reducers and harmonic rotary actuators to help engineers identify the most suitable solution for their CNC applications.
 How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?I'm Theodore Li, Technical Director at HONPINE. Choosing harmonic joint actuators for a 7-DOF robotic arm starts with the torque, weight, and installation needs of each joint. This guide uses a TCHL 20 shoulder and TCHL 14 wrist configuration as an example, then explores torque sensing, compliant control, and HAG Series considerations for demanding robotic applications.
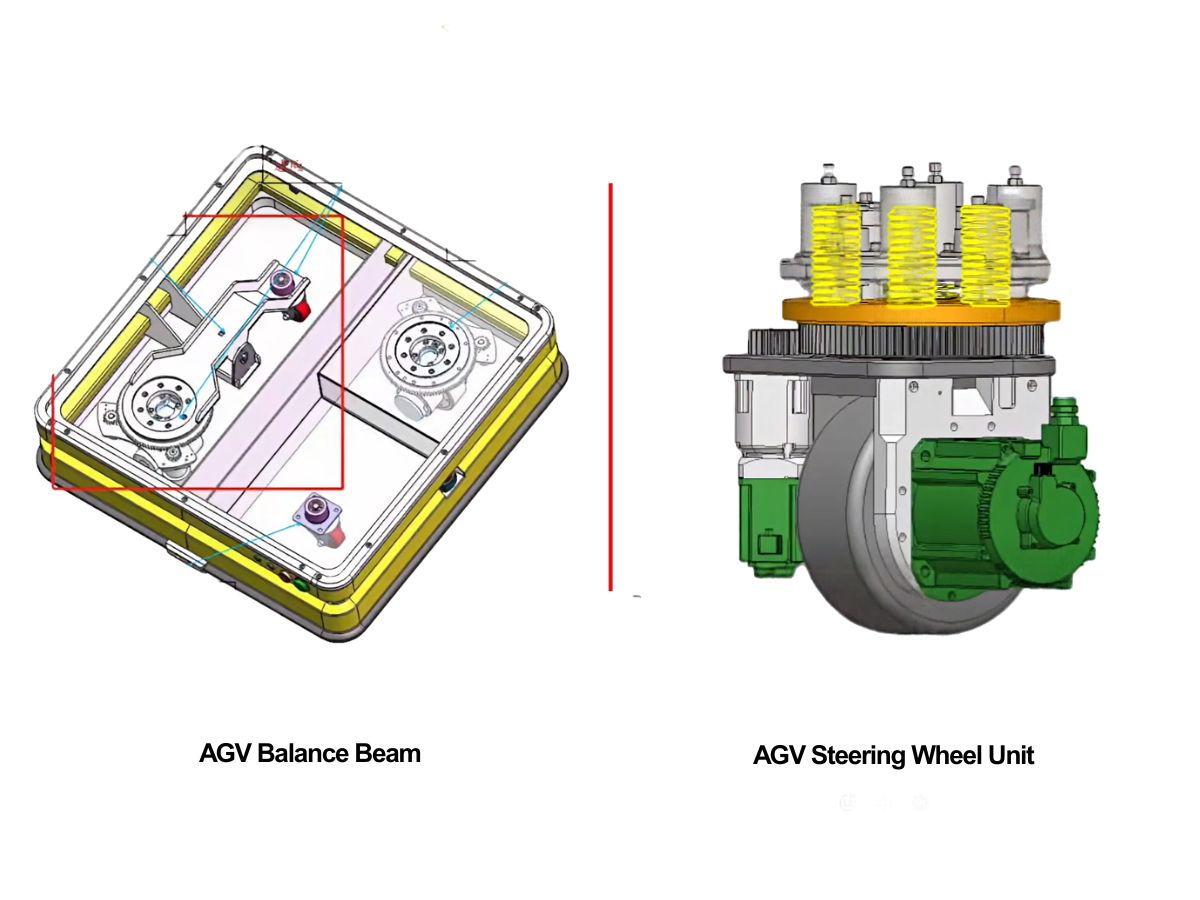
 AGV Suspension: Should You Choose a Balance Beam or a Spring-Loaded Steering Drive Unit?Choosing an AGV suspension system starts with the vehicle’s load range and floor conditions. Balance beams and spring-loaded steering drive units offer different approaches to maintaining wheel contact and managing wheel loads. This HONPINE guide compares both options and explains how to evaluate traction, suspension travel, installation space, and maintenance before choosing a configuration.
 Hollow Rotary Platform Motor Matching: A Complete GuideSelecting the right motor for a hollow rotary platform is essential for achieving precise positioning, stable operation, and efficient automation. This guide explains how to match servo motors, stepper motors, and brushless DC motors with hollow rotary platforms based on torque, speed, inertia, accuracy, and installation requirements. Explore practical motor selection guidelines, typical application combinations, and space-saving mounting solutions to find the right configuration for your automation project.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Harmonic Reducer vs. Harmonic Rotary Actuator: Which Is Better for CNC Machine Tools?Choosing between a harmonic reducer and a harmonic rotary actuator is an important decision in CNC machine tool design. Both solutions offer high-precision motion control, but they differ in integration, installation requirements, rigidity, and system flexibility. For CNC fourth-axis rotary tables and compact five-axis machining systems, selecting the right harmonic drive can significantly influence machine performance. In this article, HONPINE Technical Director Theodore Li compares harmonic reducers and harmonic rotary actuators to help engineers identify the most suitable solution for their CNC applications.
 How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?I'm Theodore Li, Technical Director at HONPINE. Choosing harmonic joint actuators for a 7-DOF robotic arm starts with the torque, weight, and installation needs of each joint. This guide uses a TCHL 20 shoulder and TCHL 14 wrist configuration as an example, then explores torque sensing, compliant control, and HAG Series considerations for demanding robotic applications.
 AGV Suspension: Should You Choose a Balance Beam or a Spring-Loaded Steering Drive Unit?Choosing an AGV suspension system starts with the vehicle’s load range and floor conditions. Balance beams and spring-loaded steering drive units offer different approaches to maintaining wheel contact and managing wheel loads. This HONPINE guide compares both options and explains how to evaluate traction, suspension travel, installation space, and maintenance before choosing a configuration.
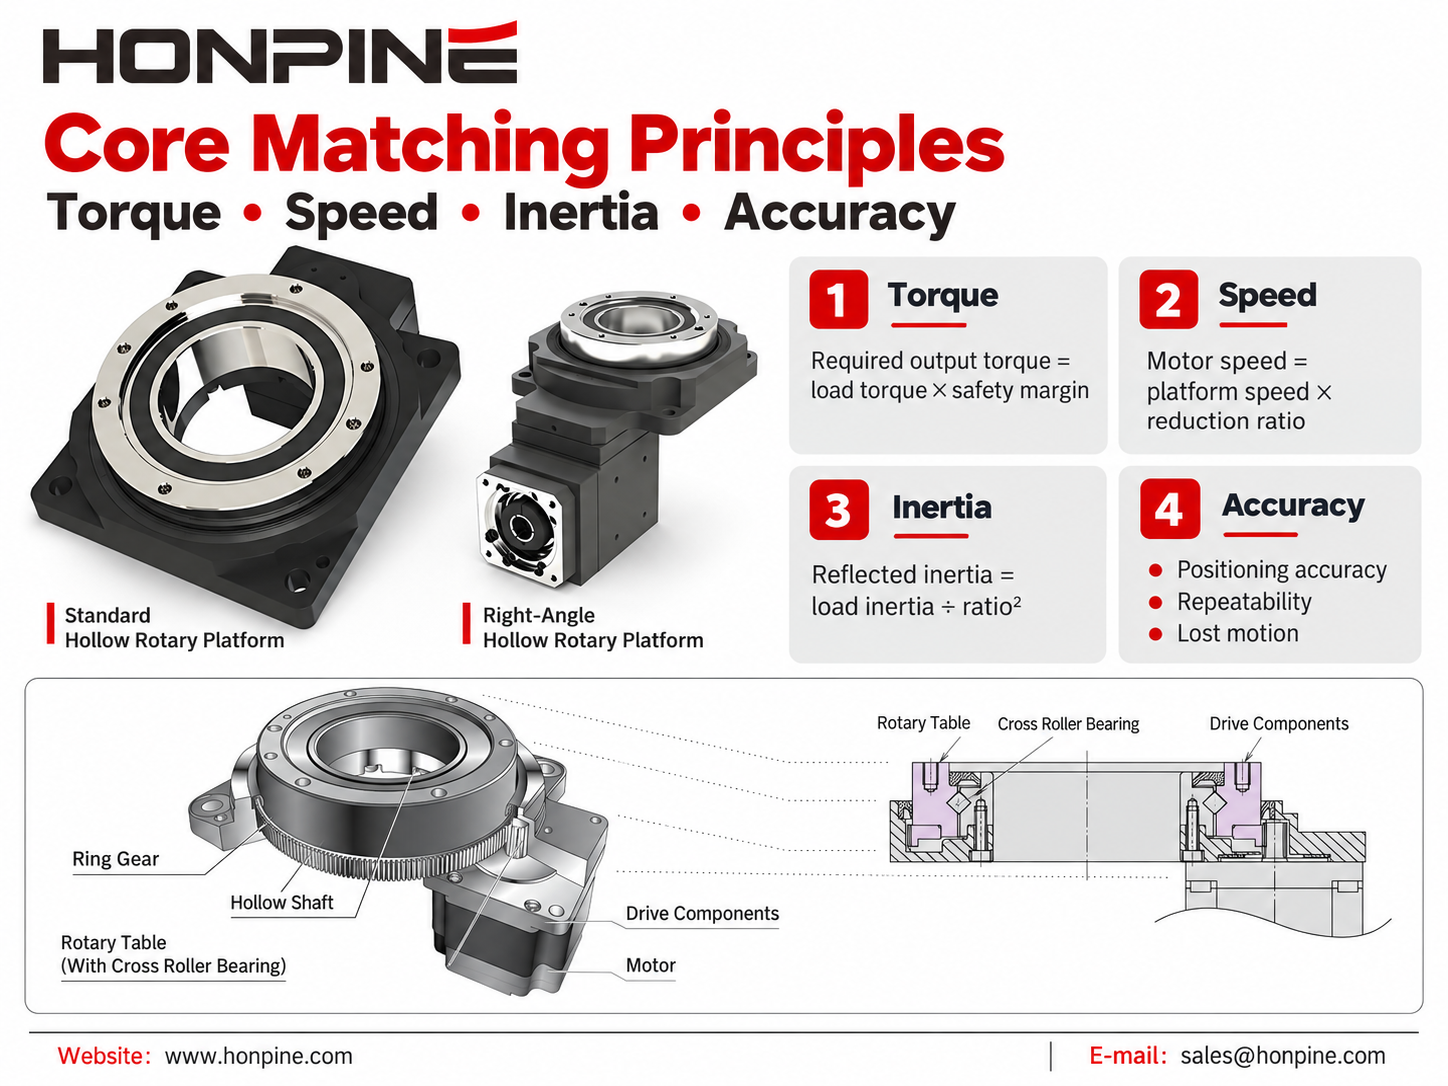
 Hollow Rotary Platform Motor Matching: A Complete GuideSelecting the right motor for a hollow rotary platform is essential for achieving precise positioning, stable operation, and efficient automation. This guide explains how to match servo motors, stepper motors, and brushless DC motors with hollow rotary platforms based on torque, speed, inertia, accuracy, and installation requirements. Explore practical motor selection guidelines, typical application combinations, and space-saving mounting solutions to find the right configuration for your automation project.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
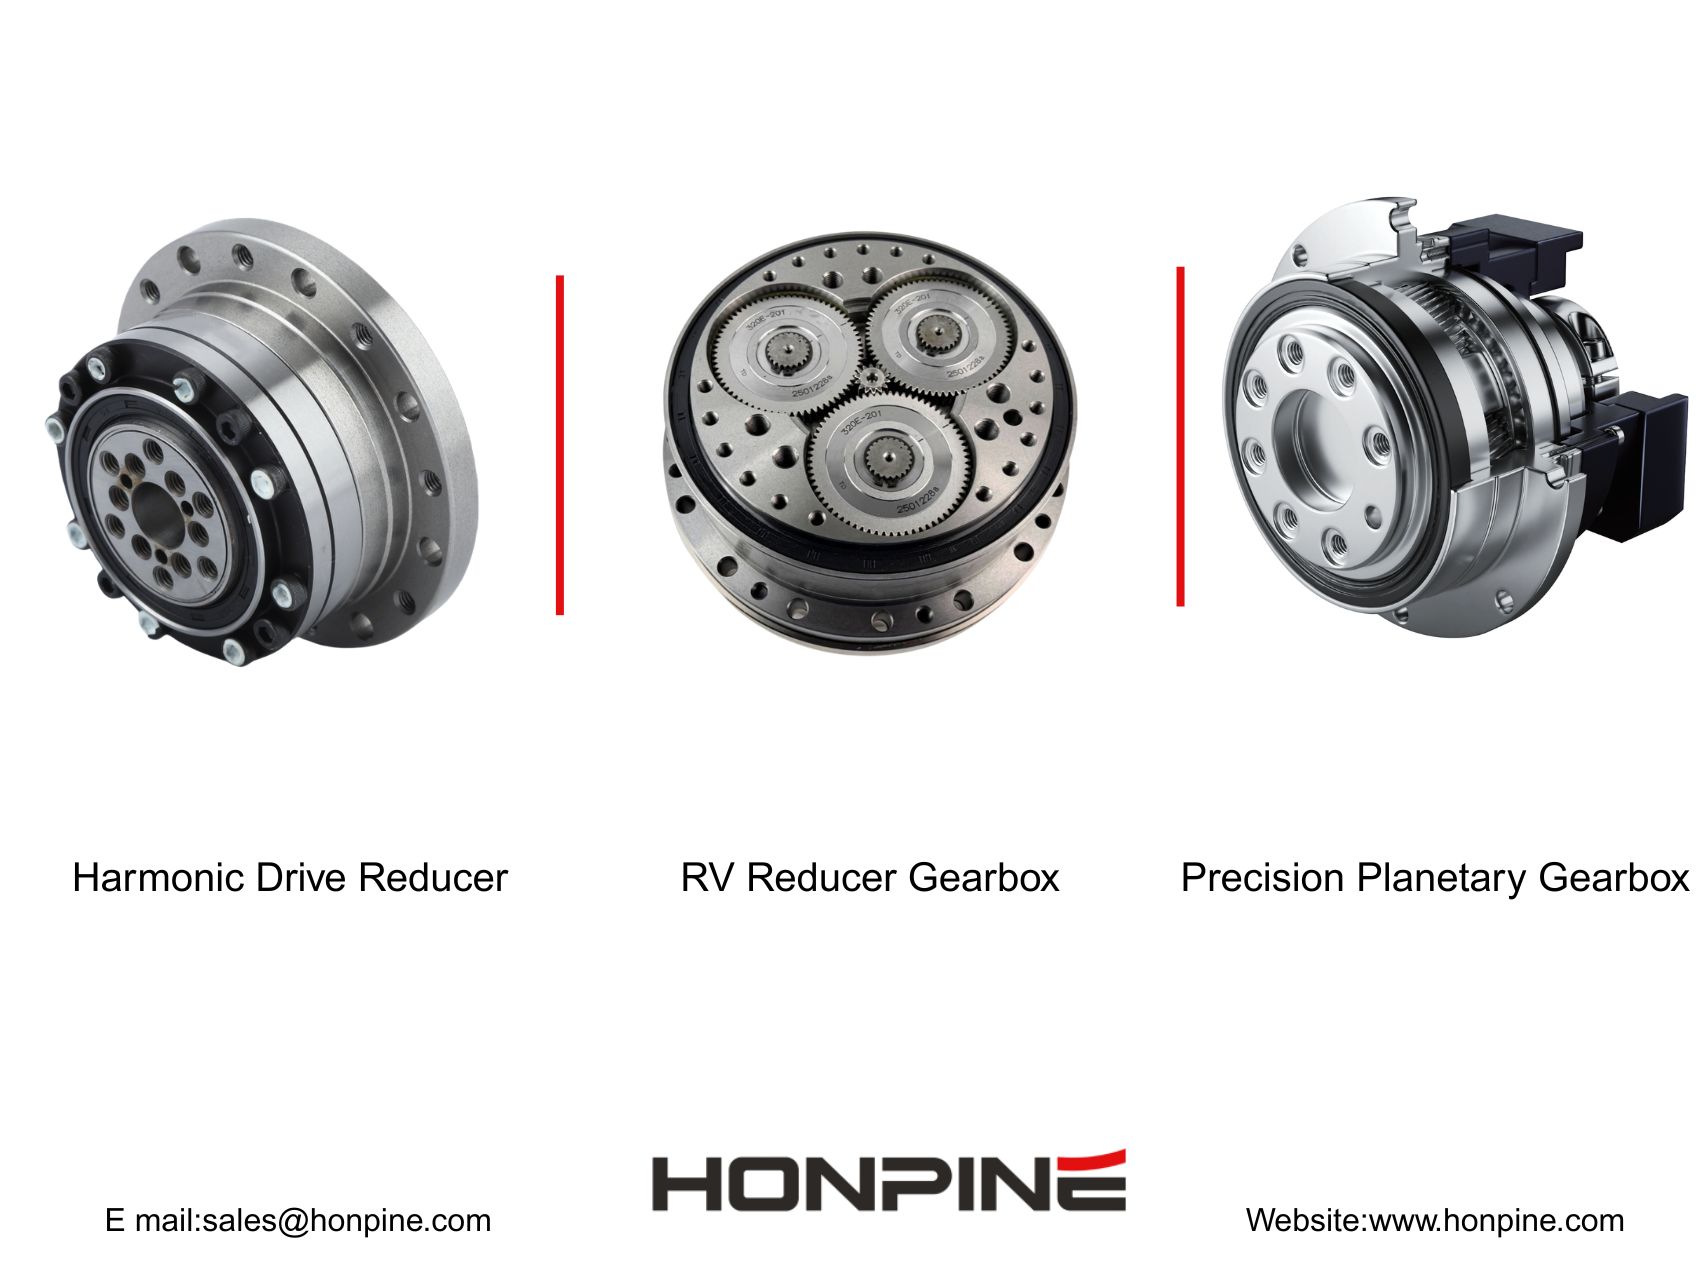
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.
 High-Precision Hollow Harmonic Rotary Actuator for CNC Machines and Heavy-Duty Rotary AxesHONPINE 58 Series Hollow Harmonic Rotary Actuator is designed for CNC rotary tables, precision rotary axes, laser processing equipment, and heavy-duty rotary positioning applications. With a 50 mm hollow bore, up to 2,722 N·m peak torque, integrated crossed roller bearing, multi-turn absolute encoder options, positioning accuracy below 30 arcsec, and repeat positioning accuracy below 5 arcsec, it combines high torque capacity with precision rotary motion and flexible mechanical integration.
 How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?HONPINE JRM planetary robot joint modules are designed for long-duration and high-load robotic operation. This article examines how motor electromagnetic optimization, high-efficiency planetary transmission, GaN-based drive technology, and system-level low-loss design help control temperature rise. Using the C6345 planetary robot joint module as a test example, HONPINE also presents full-load thermal validation under continuous operation, including motor efficiency up to 92%, planetary gearbox efficiency up to 97%, and a final equilibrium temperature of 61.42°C at a 25°C ambient temperature.
 Direct Drive Motor Sizing: A Complete Guide to Torque Calculation and SelectionSelecting a direct drive motor for a precision rotary system requires more than matching motor torque to the equipment weight. Engineers need to evaluate gravity torque, inertial torque, wind torque, friction, rotational inertia, speed, acceleration, duty cycle, and positioning requirements. In this guide, Theodore Li, Technical Director at HONPINE, explains a practical approach to direct drive motor sizing and torque calculation using an azimuth and elevation turntable as an engineering example. The article covers continuous and peak torque calculation, motor selection criteria, and the application of frameless direct drive motors in integrated rotary systems.