Harmonic Actuator for Lift Equipment: Precision, Torque Density and Compact Motion Control Introduction
Modern lift equipment is no longer designed simply to move a load from one height to another. As industrial automation, robotics, material handling, and precision machinery continue to evolve, lifting systems increasingly need to combine high load capacity with accurate positioning, compact mechanical integration, reliable motion control, and long-term operating stability.
This is particularly important when a lifting mechanism operates inside a limited installation space or forms part of a larger automated system. A robotic lift axis, AGV or AMR lifting module, semiconductor positioning mechanism, automated inspection platform, or specialized winch may need to repeatedly move a load while maintaining accurate positioning and stable motion under changing loads.
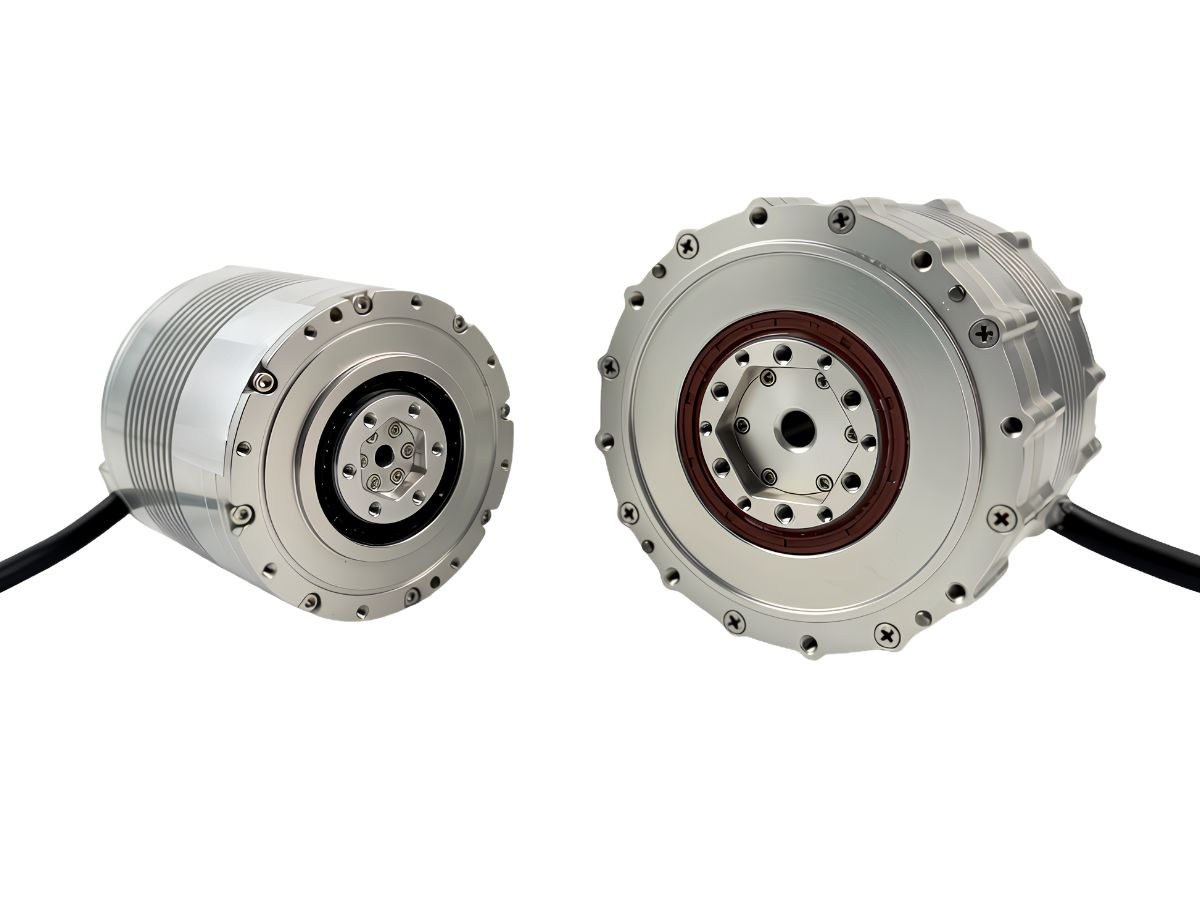
For these applications, the transmission system becomes just as important as the motor itself. A Harmonic Actuator, which integrates a harmonic drive reducer with a motor and, depending on the configuration, components such as encoders, brakes, and servo drives, provides a compact approach to high-precision rotary motion control.
Although harmonic actuators are widely associated with robotic joints, their advantages are not limited to robotics. When a lifting mechanism is driven through a rotary transmission, harmonic actuator technology can also provide a practical solution for lift equipment and specialized lifting systems that require high torque density, low backlash, high rigidity, precise positioning, and compact integration.
Why Lift Equipment Is Moving Toward More Integrated Motion Systems?
Traditional lifting equipment often uses a relatively straightforward architecture consisting of a motor, gearbox, coupling, brake, encoder, and external controller. This configuration can work well for conventional lifting applications, but as equipment becomes more compact and automated, the number of components required for each motion axis can become a significant design consideration.
For equipment manufacturers, every additional mechanical interface creates another requirement for mounting, alignment, wiring, commissioning, and maintenance. The motor and gearbox also need to be matched carefully, while the encoder and brake must be integrated into the overall control and safety architecture.
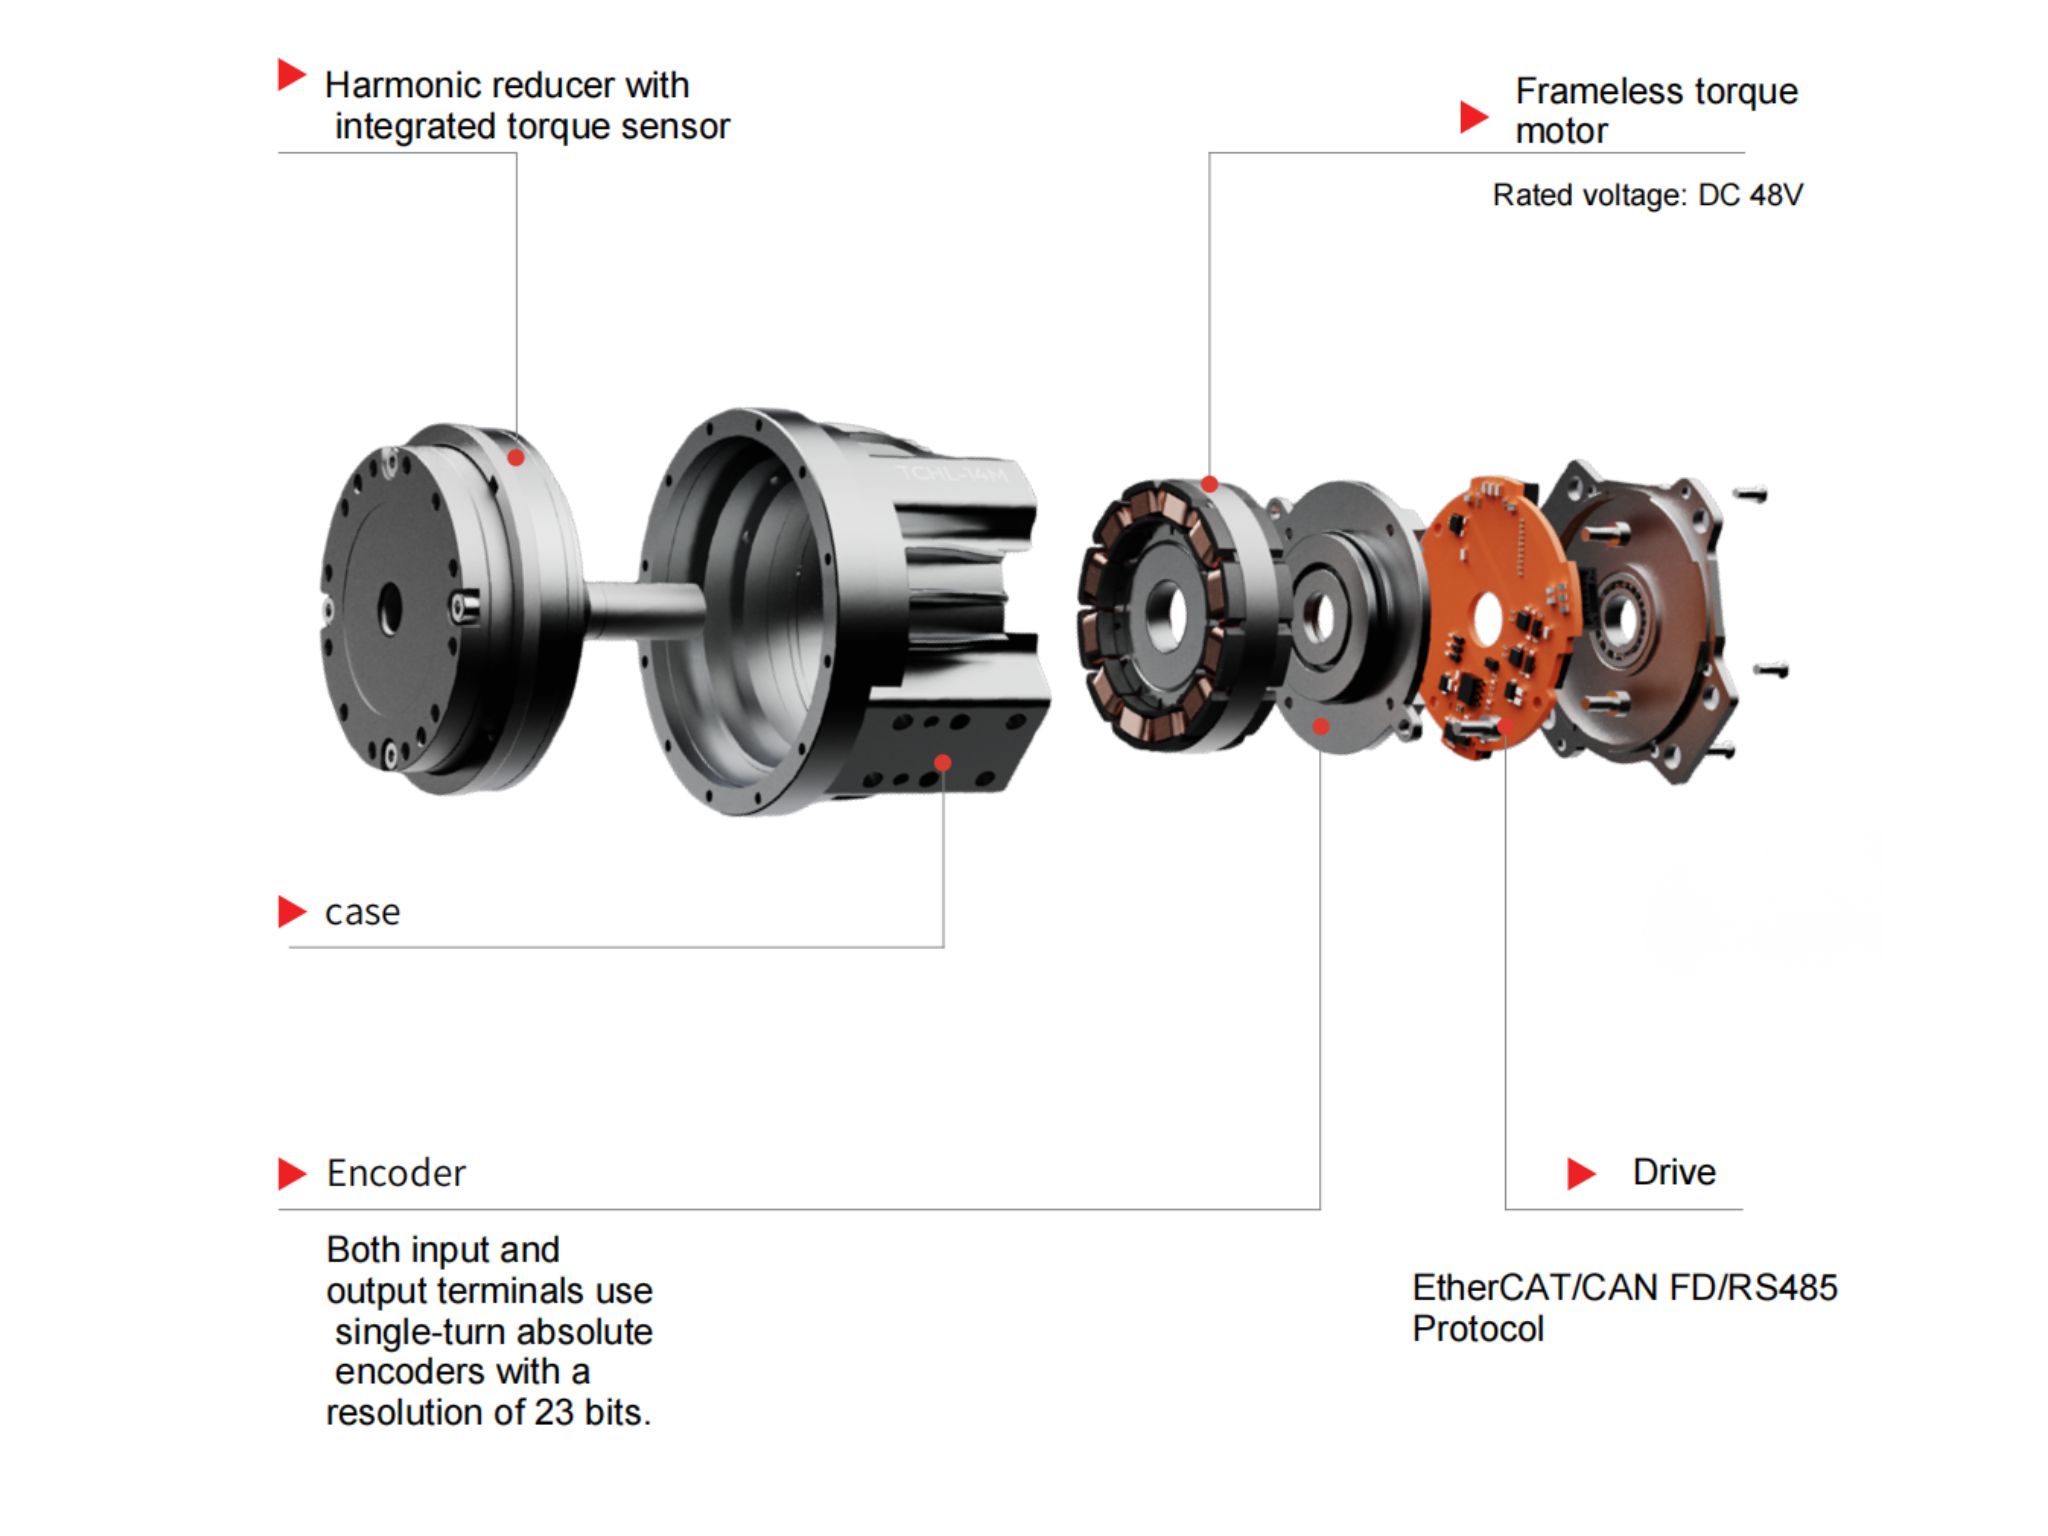
An integrated Harmonic Actuator takes a different approach by combining the transmission and motion-control components into a compact module. Depending on the actuator configuration, the harmonic drive, motor, encoder, brake, servo drive, and communication interfaces can be integrated into one system.
This approach is particularly attractive when the lifting mechanism must fit inside a restricted mechanical envelope or when the equipment manufacturer wants to standardize the drive architecture across multiple machine models.
The objective is not simply to reduce the number of components. More importantly, an integrated actuator can simplify the mechanical, electrical, and control interfaces between the drive system and the lifting mechanism, helping equipment manufacturers reduce integration work while maintaining precise motion performance.
Where Can Harmonic Actuators Be Used in Lift Equipment?
Harmonic actuators are most valuable in lifting applications where rotary motion is converted into linear movement or where lifting is combined with positioning, rotation, or robotic motion.
This makes them relevant to robotic vertical axes, AGV and AMR lift modules, semiconductor equipment, precision inspection systems, medical positioning equipment, automated platforms, and specialized winch mechanisms.
The important distinction is that a Harmonic Actuator is not necessarily a direct replacement for a linear actuator or ball screw system. Its primary function is to provide controlled rotary output. The mechanical system can then convert this rotary motion into vertical movement through a screw, drum, pulley, linkage, cam, or other transmission mechanism.
Therefore, the strongest application opportunity occurs when the equipment architecture already benefits from a compact, high-torque, precision rotary drive.
Harmonic Actuator for Robotic Lift Axes
Robotic lift axes are an important application for compact harmonic actuators. Industrial robots, collaborative robots, mobile manipulators, and other robotic systems may use vertical mechanisms to adjust the working height of the robot or extend its operating envelope.
In these systems, the lifting mechanism often needs to move repeatedly between predefined positions while supporting the weight of the robot, tooling, or payload. The actuator therefore needs to provide sufficient torque while maintaining positioning accuracy and structural stability.
A harmonic drive actuator can combine a high reduction ratio with low backlash and high torque density, allowing the drive system to generate substantial output torque within a relatively compact package. When combined with encoder feedback, it can provide the closed-loop motion control required for repeated vertical positioning.
For robotic equipment manufacturers, another advantage is integration. Instead of designing a complete drive assembly around a separate servo motor, harmonic reducer, encoder, and brake, an integrated actuator can serve as a standardized motion module within the robotic lift axis.
Harmonic Actuator for AGV and AMR Lift Modules
AGV and AMR platforms are increasingly equipped with lifting mechanisms for pallet handling, material transfer, automatic docking, and conveyor interaction. These lifting systems operate under particularly demanding space constraints because the actuator must share the limited internal space of the mobile robot with batteries, controllers, sensors, wheels, and structural components.
This makes torque density especially important.
A large motor and gearbox combination may provide sufficient torque but consume valuable space and add unnecessary weight to the mobile platform. A compact harmonic actuator can provide a high reduction ratio and high output torque while maintaining a relatively small mechanical footprint.
Low backlash can also be beneficial when the lifting module must align a payload with another piece of equipment. For example, an AGV may need to raise a pallet to a specific height before transferring it to a conveyor. The more accurately the lifting system can control its position, the easier it becomes to achieve repeatable docking and material transfer.
For this reason, harmonic actuator technology can be considered for AGV and AMR lifting systems where compact dimensions, torque density, positioning accuracy, and integrated control are more important than simply maximizing lifting speed.
Harmonic Actuator for Semiconductor Lift and Positioning Equipment
Semiconductor manufacturing equipment places particularly demanding requirements on motion components. Wafer handling, inspection, alignment, positioning, and process equipment may require extremely stable and repeatable movement while operating within tightly constrained mechanical spaces.
In these applications, the lifting mechanism may not have a large stroke, but the required positioning accuracy can be significantly higher than that of conventional industrial lifting equipment.
A harmonic actuator can be used to drive a rotary mechanism that produces controlled vertical movement or to provide a combined lifting and positioning function. The low-backlash characteristics of harmonic transmission help reduce mechanical clearance during direction changes, while the high rigidity of the transmission contributes to stable motion under load.
The compact structure can also help equipment designers optimize the available installation space around other components such as sensors, optical systems, cables, and process modules.
For semiconductor equipment manufacturers, the benefit therefore goes beyond torque transmission. The actuator becomes part of the overall precision motion-control architecture.
Harmonic Actuator for Precision Inspection and Positioning Lift Systems
Automated inspection equipment frequently requires vertical adjustment of cameras, optical components, sensors, inspection heads, fixtures, or workpieces.
Although these mechanisms may not require extremely high lifting forces, they can require very precise and repeatable positioning. A small positioning error can influence inspection results, optical alignment, or the consistency of the manufacturing process.
When the mechanical design converts rotary motion into vertical movement, a harmonic actuator can provide a precise rotary input with low backlash and high repeatability.
This approach can also be useful when the equipment requires both height adjustment and rotary positioning. Instead of using completely independent drive systems, the mechanical architecture can be designed around compact rotary actuators that provide controlled movement for multiple axes.
This is particularly relevant to precision automation systems where installation space, motion accuracy, and system integration are closely related design requirements.
Real Application: Harmonic Actuator Used in a Winch System
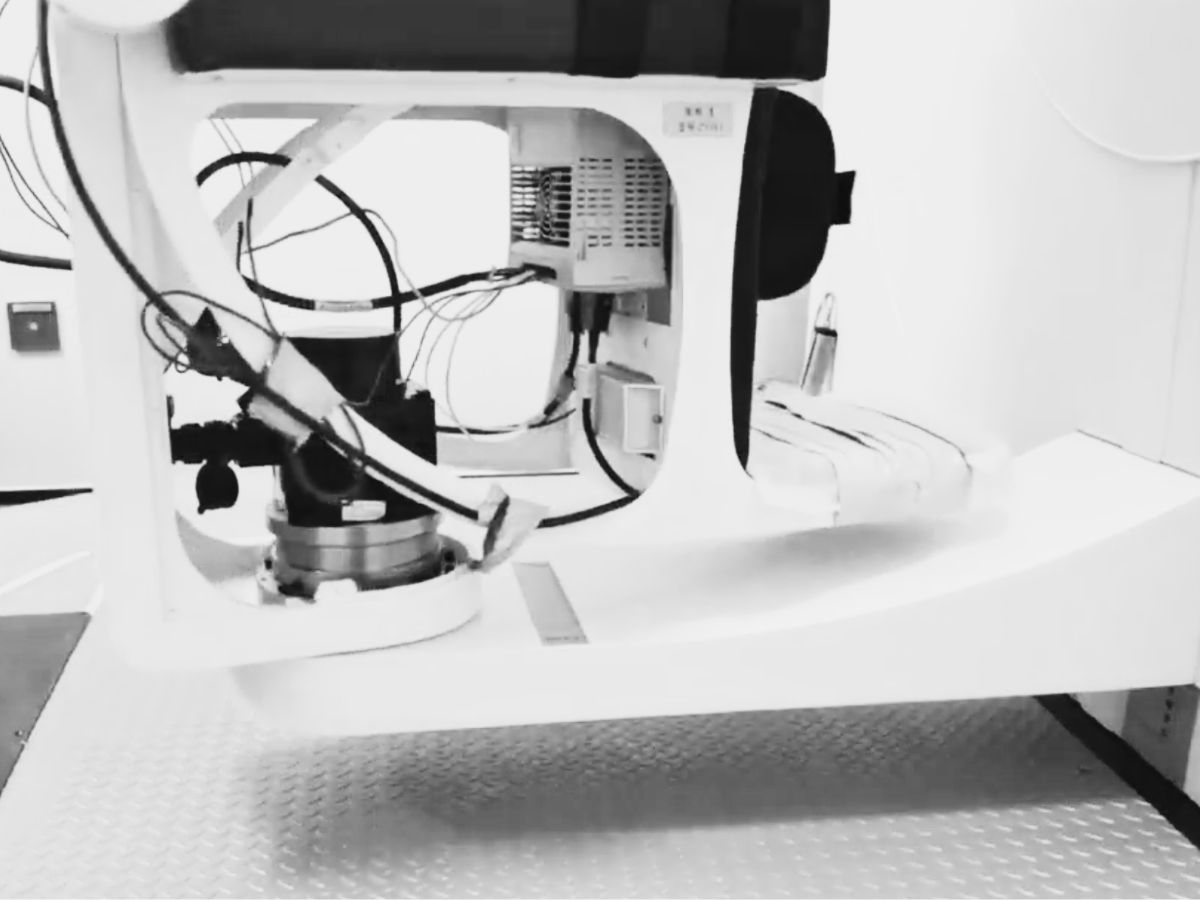
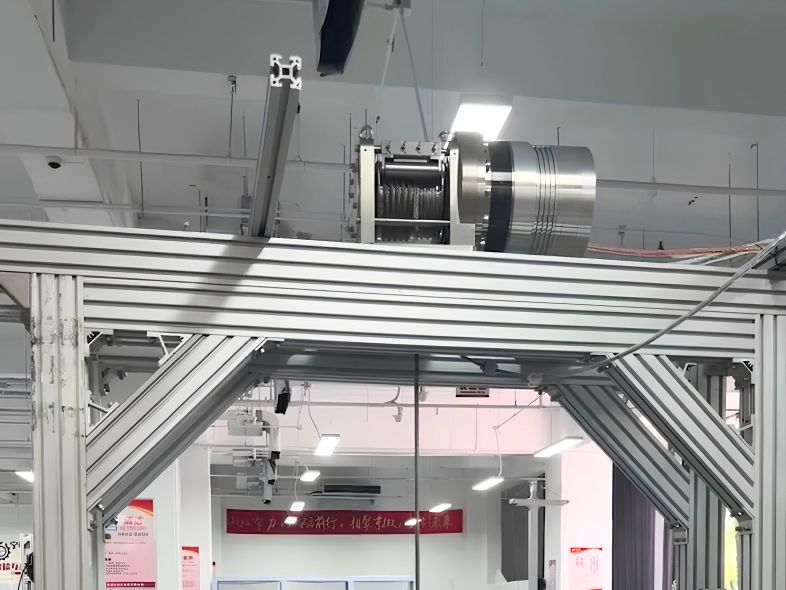
The application of harmonic actuators is not limited to robotic joints and precision automation. HONPINE has also applied harmonic actuator technology to a winch system, demonstrating how an integrated harmonic drive solution can be used for specialized lifting and load-handling equipment.
In a winch mechanism, the drive system needs to generate sufficient output torque to rotate the winding mechanism while maintaining controlled movement under load. The motor, reduction mechanism, brake, and feedback components must work together to provide stable lifting performance.
In this application, the harmonic actuator is used to drive the winch mechanism and control its rotary motion. The high reduction capability of the harmonic drive enables the motor to produce the required output torque within a compact transmission structure, while the low-backlash transmission supports more accurate and repeatable motion control.
Another important consideration is system integration. Compared with a conventional architecture that uses a separate motor, gearbox, coupling, encoder, and other components, an integrated harmonic actuator can reduce the number of mechanical interfaces and simplify the overall drive structure. This can be particularly useful when the winch or lifting mechanism has limited installation space.
The winch application also demonstrates an important point for equipment designers: harmonic actuators are not limited to robotic applications. Their combination of high torque density, low backlash, compact construction, and precise rotary motion can also be valuable in specialized lifting and load-handling mechanisms.
The video below shows a real-world HONPINE harmonic actuator application in a winch system.
Harmonic Actuator Application in Winch and Lifting Equipment
Video: HONPINE Harmonic Actuator used in a winch system
Why High Torque Density Matters in Lift Equipment?
Torque density becomes particularly important when a lifting system must deliver high output torque within a limited installation space.
Simply increasing motor size is not always a practical solution. A larger motor increases the volume and weight of the drive system and may require a larger supporting structure. For mobile equipment, additional weight can also increase energy consumption and reduce overall system efficiency.
A harmonic drive uses a high reduction ratio to multiply motor torque within a compact transmission. When this transmission is combined with an appropriately sized motor, the resulting actuator can provide a high output torque relative to its overall size.
This is one reason harmonic actuators are attractive for robotic lift axes, AGV and AMR lifting modules, compact winches, and other lifting mechanisms where available space is limited.
The design advantage becomes even more significant when the actuator must also accommodate an encoder, brake, driver, or communication interface. An integrated actuator can provide these functions without requiring each component to occupy a separate installation position.
Why Low Backlash Matters for Lifting and Positioning?
Backlash may not be a major concern in a basic lifting mechanism that only needs to move a load between two approximate positions. However, it becomes much more important when the lifting system is part of an automated positioning process.
Consider a lifting mechanism that repeatedly performs the following sequence: raising a platform, stopping at a defined position, lowering it, and then returning to the original position. Every change in direction introduces the possibility that mechanical clearance within the transmission will influence the final position.
Low-backlash harmonic transmission minimizes this mechanical clearance and helps create a more predictable relationship between commanded movement and actual output movement.
This can be particularly valuable for robotic lift axes, semiconductor equipment, inspection systems, and automated positioning platforms where repeatability is more important than simply achieving a lifting stroke.
High Rigidity Is Important When the Actuator Supports External Loads
Lifting equipment often exposes the transmission system to more than pure rotational torque. Depending on the mechanical configuration, the actuator may also experience radial forces, axial forces, and overturning moments.
For example, if a lifting platform carries a robotic arm or an offset payload, the distance between the load center and the actuator output can generate a significant overturning moment.
Under these conditions, the rigidity and bearing capacity of the actuator become important selection criteria.
A high-rigidity harmonic actuator can help maintain stable output motion under external loading. However, equipment designers should not evaluate rigidity only from the reducer specification. The complete mechanical system, including the output bearing, mounting structure, load position, and support mechanism, must be considered.
This is particularly important for heavy-load robotic lift systems and precision lifting platforms.
Integrated Harmonic Actuator vs. Conventional Motor and Gearbox
The traditional architecture for a precision lifting axis often consists of a servo motor, harmonic reducer, encoder, brake, coupling, and external servo drive. Each component must be selected and integrated into the system, and the mechanical interfaces between these components can influence installation accuracy and assembly time.
An integrated Harmonic Actuator combines several of these functions into one module. This can reduce the number of interfaces between the drive and machine while simplifying wiring, assembly, and commissioning.
For equipment manufacturers, the real advantage is therefore not simply component reduction. It is the ability to treat the drive system as a standardized motion-control module rather than designing every lifting axis from individual components.
This can be especially valuable for manufacturers developing multiple machine configurations or robotic platforms that use similar motion architectures.
Harmonic Actuator vs. Ball Screw for Lift Applications
A Harmonic Actuator and a ball screw actuator should not be considered direct substitutes in every lifting application because they perform different primary functions.
A ball screw is designed specifically to convert rotary motion into linear motion and is therefore a natural choice for conventional linear lifting axes. It is particularly suitable when the machine requires a long linear stroke and the mechanical architecture is already based on a screw-driven axis.
A Harmonic Actuator is more attractive when the system requires a high-precision rotary drive that can be converted into linear motion through a drum, screw, pulley, linkage, cam, or other mechanism. It becomes particularly interesting when the application also requires high torque density, low backlash, high rigidity, compact integration, or a combination of lifting and rotary motion.
Therefore, the correct question for an equipment manufacturer is not simply “Which actuator is better?” but rather:
Which transmission architecture best matches the load, motion profile, installation space, positioning requirements, and control architecture of the lifting system?
How to Select a Harmonic Actuator for Lift Equipment?
Selecting a harmonic actuator for lifting equipment requires more than matching the rated torque to the load.
The first step is to calculate the actual output torque required by the mechanism. Load weight, lever arm, acceleration, friction, mechanical efficiency, external forces, and safety factors should all be included. For mechanisms with offset loads, the resulting radial forces and overturning moments should also be considered.
The reduction ratio should then be selected according to the required output speed and torque rather than simply choosing the highest available ratio. A higher reduction ratio can increase torque multiplication and reduce output speed, but the ideal ratio must still match the motor's operating range and the dynamic requirements of the lifting system.
Backlash and torsional rigidity should be evaluated according to the required positioning performance. A system that frequently reverses direction or performs precision positioning will generally benefit more from low backlash than a simple lifting mechanism with limited positioning requirements.
Encoder configuration is another important consideration for closed-loop lifting systems. Depending on the control architecture, a single encoder may be sufficient, while applications requiring more detailed motor-side and output-side feedback may benefit from a dual-encoder configuration.
For vertical loads, the brake configuration also deserves particular attention. The brake should be selected according to the actual load-holding and safety requirements of the machine rather than treating it simply as another actuator specification.
Finally, the duty cycle, operating temperature, expected service life, installation orientation, environmental conditions, and communication interface should all be considered before final actuator selection.
Why Equipment Manufacturers Are Choosing More Integrated Actuators?
The increasing adoption of integrated actuators is closely related to the changing priorities of equipment manufacturers.
Machine builders are under pressure to make equipment smaller while increasing automation, precision, and functionality. At the same time, reducing assembly time and simplifying maintenance have become important factors in controlling manufacturing costs.
An integrated harmonic actuator can address several of these challenges simultaneously.
Instead of integrating a motor, reducer, encoder, brake, and driver as separate components, the equipment manufacturer can work with a pre-engineered actuator module. This reduces the number of mechanical interfaces and can make the design of the motion axis more standardized.
For manufacturers producing multiple equipment platforms, this modular approach can also simplify engineering changes and spare-parts management.
The trend is particularly visible in robotics, mobile robots, semiconductor equipment, precision automation, and other industries where compact motion systems are becoming increasingly important.
Harmonic Actuator for Next-Generation Lifting and Robotic Systems
The future of lifting equipment is closely connected to the development of intelligent and automated machines.
A modern lifting mechanism may no longer operate as an isolated vertical axis. It may become part of a robotic system in which height, position, force, and motion need to be coordinated with other axes.
A mobile robot may need to lift a payload while accurately aligning it with another machine. A robotic manipulator may need to adjust its height while maintaining the position of its end effector. A semiconductor system may need to combine vertical movement with highly precise rotary positioning.
These applications place greater demands on the drive system.
The actuator must provide sufficient torque, but it must also deliver precision, rigidity, feedback, compactness, and reliable communication within the available mechanical space.
This is where integrated harmonic actuator technology can provide a meaningful advantage.
Conclusion
Harmonic actuators are not designed to replace every type of lifting actuator. Their strongest value appears when a lifting system also requires high torque density, low backlash, high positioning accuracy, high rigidity, compact installation, and integrated motion control.
For robotic lift axes, AGV and AMR lifting modules, semiconductor equipment, precision positioning systems, automated inspection equipment, and specialized winch systems, the harmonic actuator can provide a compact and highly integrated approach to rotary motion control.
The real-world winch application demonstrates that harmonic actuator technology can extend beyond conventional robotic joints into specialized lifting and load-handling equipment. When the mechanical architecture benefits from rotary drive transmission, high reduction ratios, accurate positioning, and compact integration, a harmonic actuator can become an effective alternative to a conventional motor-and-gearbox configuration.
For equipment manufacturers, the most important consideration is not simply whether a Harmonic Actuator can provide enough torque. The more important question is whether its torque density, backlash, rigidity, integration level, feedback configuration, and mechanical architecture match the actual requirements of the lifting system.
When these factors align, an integrated Harmonic Actuator can help equipment manufacturers build lifting systems that are more compact, easier to integrate, more precise, and better suited to next-generation automated machinery.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Harmonic Rotary Actuator for Lithium Battery Roller Press EquipmentLithium battery manufacturing equipment requires higher precision, stability, and integration efficiency as production processes continue to evolve. In roller press equipment, accurate roller positioning, pressure control, and dynamic response are critical for ensuring electrode quality and consistency.
HONPINE harmonic rotary actuators provide high precision, high rigidity, fast response, and compact integration for lithium battery roller press equipment. With near-zero backlash, high torque density, and reliable motion control performance, they help improve equipment accuracy and production stability. How Integrated Robot Joint Modules Are Reshaping Robot Wiring and Control Architecture?Integrated robot joint modules are changing how robots are designed by combining the motor, reducer, drive, encoder, and sensing components into a compact motion unit. Compared with traditional distributed architectures, this integrated approach can reduce cable complexity, simplify power and communication connections, and support more compact robot structures. As humanoid robots demand higher levels of motion coordination, response speed, precision, and integration, robot joint modules are becoming an increasingly important interface between intelligent control systems and physical movement. This article explains how integrated robot joint modules reshape robot wiring and control architecture, using the HONPINE TCHL harmonic drive robot joint module as an example.
 Harmonic Actuator for Lift Equipment: Precision, Torque Density and Compact Motion Control IntroductionModern lifting equipment requires more than simply moving a load vertically. Robotic lift axes, AGV and AMR lift modules, semiconductor equipment, inspection platforms, and specialized winches increasingly demand high torque density, precise positioning, low backlash, high rigidity, and compact motion control. A harmonic actuator integrates a harmonic drive with a motor and, depending on the configuration, encoders, brakes, servo drives, and communication interfaces into a compact motion module. This article explores how harmonic actuators can be applied to different lifting systems and why their combination of precision, torque density, rigidity, and integration makes them suitable for automated lifting and positioning applications.
 Force-Controlled Harmonic Joint Modules: A Key Solution for Robot CommercializationAs robots move from precise positioning toward physical interaction, joint-level torque feedback is becoming increasingly important. A force-controlled robot joint module allows the robot to sense changes in output torque and respond more appropriately to external loads, supporting compliant motion, contact detection, and force-controlled applications. HONPINE HAG and HAU harmonic joint modules integrate torque sensing directly into the joint, enabling torque closed-loop control, 360° continuous output rotation, less than 1% torque control accuracy, and a 50 Hz torque bandwidth. This integrated design also maintains consistent dimensions between force-controlled and non-force-controlled configurations, providing a flexible joint platform for robot manufacturers.
 6 Key Advantages of the HONPINE JRM Planetary Joint ModuleHigh-performance quadruped robots require joint modules that can respond quickly, maintain precise positioning, withstand repeated impacts, and deliver stable torque under demanding operating conditions. The HONPINE JRM planetary joint module combines high positioning accuracy, low backlash, fast three-loop response, high static rigidity, strong overload capability, and a wide operating temperature range. With clearly defined continuous and overload operating limits, the JRM is designed to balance dynamic performance with long-term reliability. This article introduces six key advantages of the HONPINE JRM planetary joint module and explains why it is suitable for industrial inspection quadrupeds, specialized inspection robots, explosion-proof quadruped robots, and other high-performance robotic platforms.
 Robot Joint Module Solutions for Humanoid Robot Arms and LegsHumanoid robots require different joint characteristics across the shoulder, elbow, wrist, hip, knee, and ankle. Smaller joints prioritize low weight and fast response, while larger joints require higher torque density, load capacity, and reliability. A suitable robot joint module should therefore be matched to the specific torque, weight, range of motion, and control requirements of each joint. In this article, HONPINE uses the HPJM harmonic joint module series as an example to present a joint configuration solution for humanoid robot upper and lower limbs, covering torque requirements from small wrist and finger joints to high-load hip joints.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Harmonic Rotary Actuator for Lithium Battery Roller Press EquipmentLithium battery manufacturing equipment requires higher precision, stability, and integration efficiency as production processes continue to evolve. In roller press equipment, accurate roller positioning, pressure control, and dynamic response are critical for ensuring electrode quality and consistency.
HONPINE harmonic rotary actuators provide high precision, high rigidity, fast response, and compact integration for lithium battery roller press equipment. With near-zero backlash, high torque density, and reliable motion control performance, they help improve equipment accuracy and production stability. Harmonic Actuator for Lift Equipment: Precision, Torque Density and Compact Motion Control IntroductionModern lifting equipment requires more than simply moving a load vertically. Robotic lift axes, AGV and AMR lift modules, semiconductor equipment, inspection platforms, and specialized winches increasingly demand high torque density, precise positioning, low backlash, high rigidity, and compact motion control. A harmonic actuator integrates a harmonic drive with a motor and, depending on the configuration, encoders, brakes, servo drives, and communication interfaces into a compact motion module. This article explores how harmonic actuators can be applied to different lifting systems and why their combination of precision, torque density, rigidity, and integration makes them suitable for automated lifting and positioning applications.
 Harmonic Rotary Actuators for Semiconductor Equipment: Precision Motion, Hollow-Shaft Design and FOC ControlHello everyone, I’m Theodore Li, Technical Director at HONPINE. In semiconductor manufacturing equipment, rotary motion is not simply about making a mechanism rotate. Limited installation space, cable and tube routing, low-speed stability, precise positioning and continuously adjustable motion profiles can all influence the performance of the machine. This is why harmonic rotary actuators are becoming an important motion solution for semiconductor equipment. In this article, I will discuss how harmonic transmission, FOC-based motor control, encoder feedback, large hollow-shaft design and flexible mechanical interfaces work together to meet practical semiconductor motion requirements, based on our experience with developing equipment, overhead transport, wafer handling, cleaning and crystal-growth applications.
 Miniature Harmonic Drive for Minimally Invasive Surgical RobotsMinimally invasive surgical robots require highly compact transmission systems that can deliver precise motion within extremely limited mechanical spaces. As robotic instruments become smaller and more dexterous, conventional transmission architectures can face challenges related to size, tendon elasticity, friction, hysteresis, and mechanical integration. A miniature harmonic drive offers one potential approach by providing high-ratio precision transmission, low backlash, and compact dimensions in a small mechanical envelope. In this article, I will explain why miniature harmonic transmission is relevant to surgical robotics, compare external tendon-driven and distal transmission architectures, and discuss the key engineering considerations behind HONPINE’s CSF-mini miniature harmonic reducer for compact robotic joints, flexible robotic instruments, and other precision mechanisms.
 Why Laser Wobble Welding Systems Need a High-Precision Harmonic Rotary Actuator?Laser wobble welding is increasingly used in battery manufacturing, busbar welding, electronics, medical devices, robotic welding, and other precision manufacturing applications where beam movement must remain accurate and repeatable. In mechanical wobble welding systems, however, weld quality depends not only on laser parameters but also on the precision of the rotary motion mechanism driving the wobble head. Backlash, insufficient torsional rigidity, limited torque density, and positioning errors can directly affect the actual beam trajectory and molten pool stability. This is why a high-precision rotary motion solution is becoming an important part of modern laser wobble welding equipment. A Harmonic Rotary Actuator combines precision transmission, high rigidity, low backlash, and compact integration, making it well suited for mechanical wobble heads that require controlled rotary motion under dynamic loads.
 When Does Outboard Motor Steering Require a Harmonic Rotary Actuator?Electric outboard motor steering is evolving from a simple mechanical function into a precision motion-control application. This article explains when a Harmonic Rotary Actuator becomes a suitable solution and examines the role of precision transmission, low backlash, high torque density, encoder feedback, and compact mechanical integration. It also explores applications in electric boats, autonomous surface vessels, unmanned boats, marine robotics, and electric marine propulsion, helping engineers understand how to select the right rotary actuator according to steering torque, speed, positioning accuracy, operating conditions, and installation requirements.
 How to Choose the Right Robot Joint Actuator for Specialized Robotic Applications?Choosing the right robot joint actuator is no longer simply a matter of comparing torque specifications or selecting a motor and gearbox separately. As humanoid robots, collaborative robots, industrial robotic arms, medical robots, mobile manipulators, and specialized robotic systems become more diverse, robot manufacturers must balance torque, speed, precision, stiffness, weight, installation space, feedback, communication, and safety at the same time. This article explains how engineers can select the right harmonic joint actuator or robot joint motor by starting with the actual application problem and building a joint-level solution that matches the mechanical structure and control requirements of the complete robot.
 Harmonic Rotary Actuator for CNC Rotary Axis: A Precision Solution for Engraving MachinesDiscover how harmonic rotary actuators improve CNC rotary-axis performance for 4-axis and 5-axis engraving machines with precise positioning, low backlash, high rigidity and compact integration.
 12 Tips for Choosing the Right CNC Rotary Table Transmission: Harmonic Reducer, Harmonic Rotary Actuator, DD Motor and Planetary ReducerLearn how to choose the right CNC rotary table transmission based on accuracy, backlash, torque, speed, rigidity, thermal stability and integration. Compare harmonic reducers, harmonic rotary actuators, DD motors, RV reducers and planetary reducers.