Why Is the HONPINE TCHL Harmonic Joint Module Suitable for Exoskeleton Robots?
When developing or upgrading a wearable robotic system, exoskeleton engineers need to carefully consider several factors, including human biomechanics, overall wearing weight, human-robot interaction forces, joint alignment, and long-term wearing comfort.
The HONPINE TCHL Harmonic Joint Module with a built-in torque sensor is designed to address these engineering challenges and provide a suitable joint drive solution for exoskeleton applications.
Why Is the Lightweight Design of a Harmonic Joint Module Important for Exoskeleton Development?
Unlike industrial robots that are fixed to the ground, exoskeleton robots are directly worn on the human body.
Therefore, the weight of each joint module directly affects the physical burden on the wearer during movement.
This is particularly important for lower-limb exoskeletons, where hip, knee, and ankle joints are installed at different positions, and the impact of their weight on human movement varies accordingly.
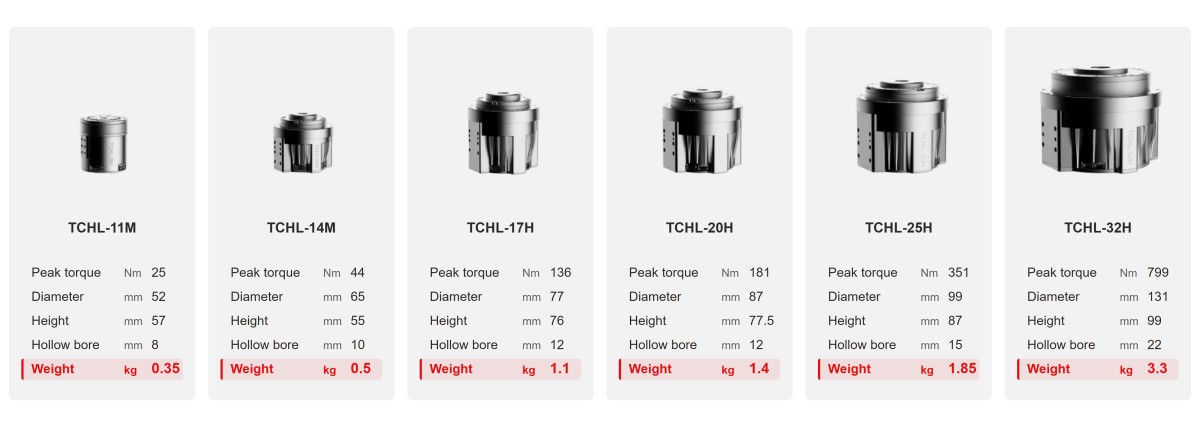
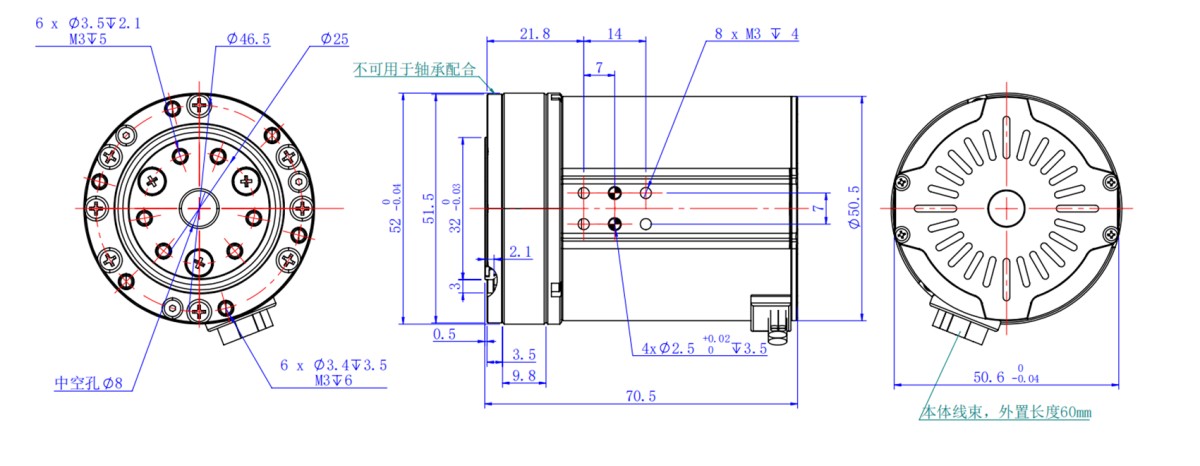
The HONPINE TCHL Harmonic Joint Moduleis lighter than most joint modules available on the market. Its Size 14 model weighs only 0.5 kg.
In practical applications, its lightweight design helps reduce limb movement inertia and the additional load on the drive system, making it easier for users to wear the device for extended periods without excessive physical strain caused by heavy equipment.
How Does an Integrated Design Benefit Exoskeleton Development?
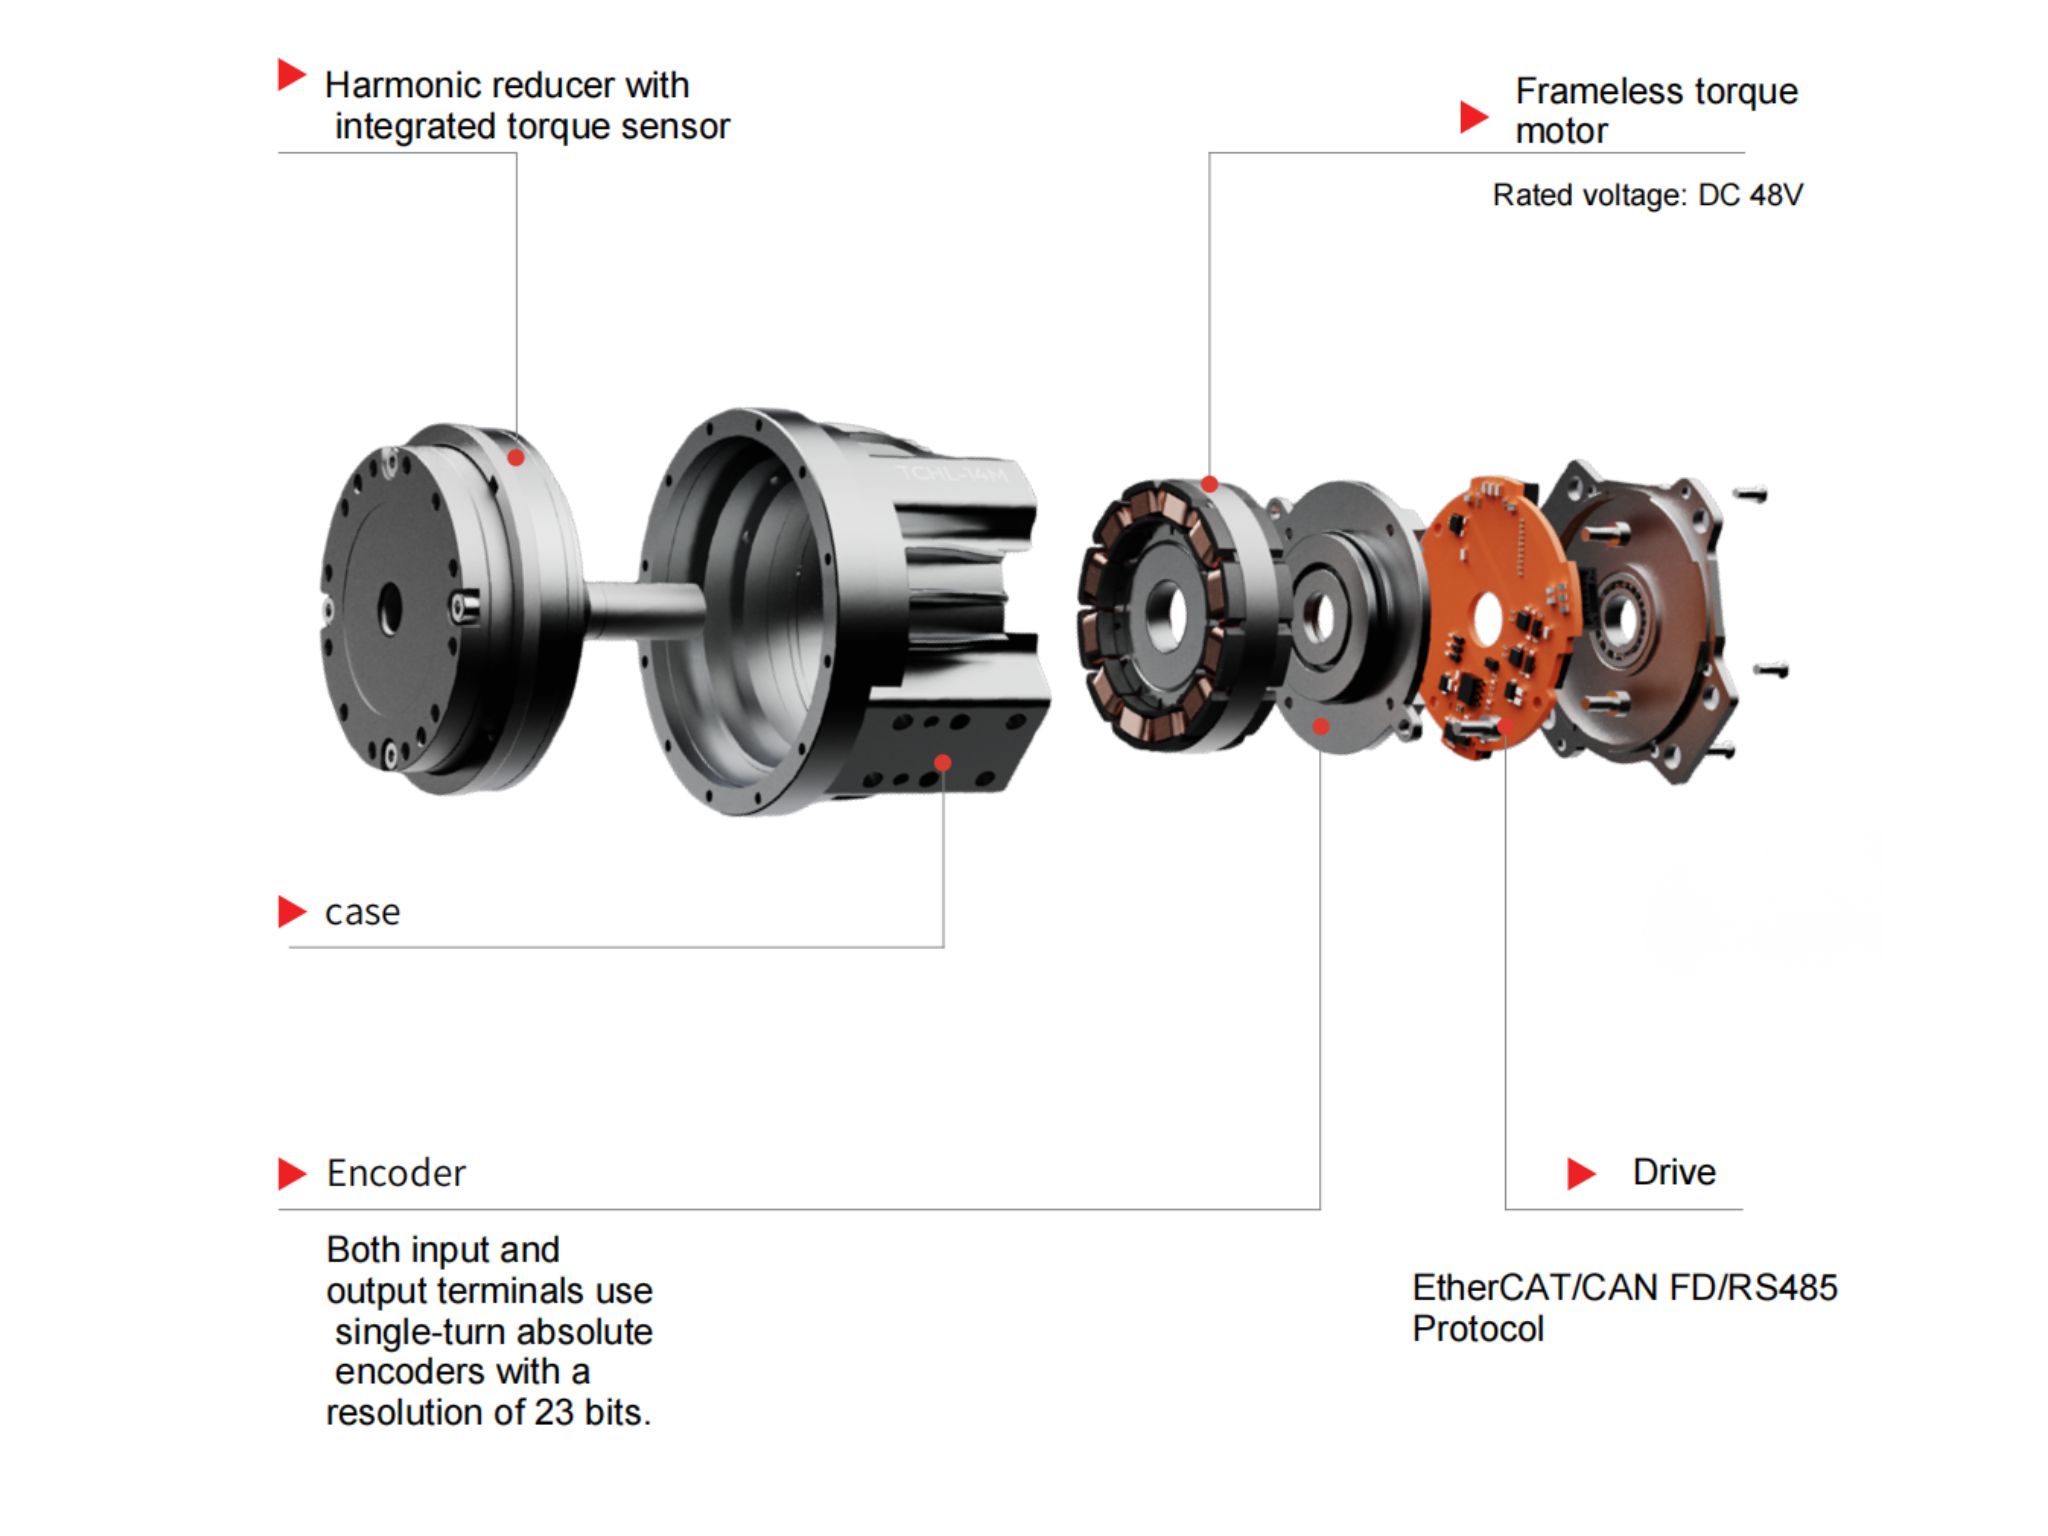
The highly integrated design of the TCHL Harmonic Joint Module helps reduce the additional weight associated with separate motors, reducers, and external mounting structures.
Through structural integration and optimization, it also minimizes unnecessary mechanical space, providing exoskeleton developers with a more compact joint drive unit.
This is particularly beneficial for wearable robotic systems where installation space and overall weight are important design considerations.
How Does a Built-in Torque Sensor Enable On-Demand Assistance?
The torque sensor in the TCHL measures torque at the joint output side. When the user actively bends or extends their knee, or when external resistance changes, the torque at the joint output may also change accordingly.
The controller can use this feedback, together with joint angle, angular velocity, and data from human motion sensors, to identify the current movement state.
This is an important control approach worth considering in rehabilitation robotics.
Instead of continuously delivering the same assistance torque, the device can adjust its assistance level according to the user's physical capabilities and movement state.
How Do Multiple Connection Options Address Complex Exoskeleton Mechanical Layouts?
The standard HONPINE TCHL Harmonic Joint Moduleis available with multiple connection configurations and also supports customized opening designs.
The TCHL integrates cables and connectors into its design, reducing the number of independent connection components required and simplifying electrical connections between the joint module and external systems.
This helps reduce electrical assembly complexity and provides greater flexibility for cable routing in multi-joint devices.
What Types of Exoskeleton Robots Require Different Joint Module Solutions?
As exoskeleton robots continue to evolve and diversify, different application scenarios place different requirements on joint modules.
Lower-Limb Assistive Exoskeletons: Key considerations include the load requirements of the hip, knee, and ankle joints.
Upper-Limb Assistive Exoskeletons: Engineers need to consider the load requirements of the shoulder and elbow joints during lifting and supporting movements.
Rehabilitation Exoskeletons: Output torque needs to be adjusted according to patient weight, physical capabilities, and different rehabilitation stages.
Industrial Assistive Exoskeletons: Joint module selection needs to account for the weight of materials handled by workers, movement frequency, and continuous operating time.
Choosing the Right Joint Module Is Essential to Exoskeleton Robot Design
The selection of a joint module affects the overall design of an exoskeleton robot, including its mechanical structure, weight distribution, motion control, and electrical integration.
Contact HONPINE to learn more about the TCHL Harmonic Joint Module, request additional technical information, or explore other robot joint module solutions for your exoskeleton development projects.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
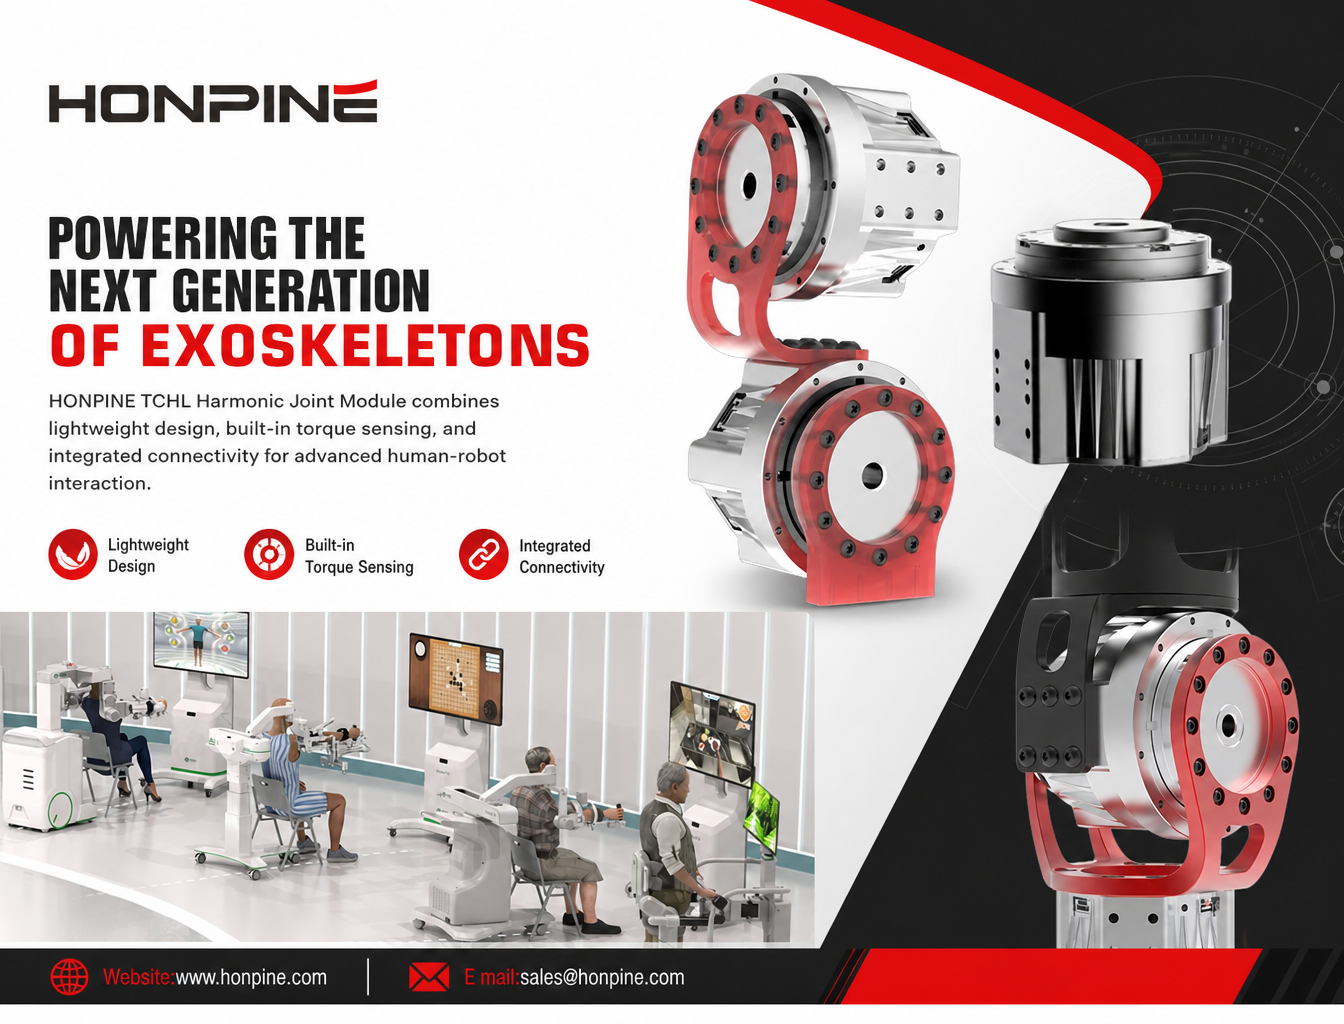
 Why Is the HONPINE TCHL Harmonic Joint Module Suitable for Exoskeleton Robots?The HONPINE TCHL Harmonic Joint Module is designed for exoskeleton robots that require lightweight construction, compact mechanical integration, and responsive human-robot interaction. Featuring a built-in output-side torque sensor, a highly integrated structure, and flexible connection configurations, the TCHL provides a joint drive solution for lower-limb exoskeletons, upper-limb assistive robots, rehabilitation equipment, and industrial wearable robots.
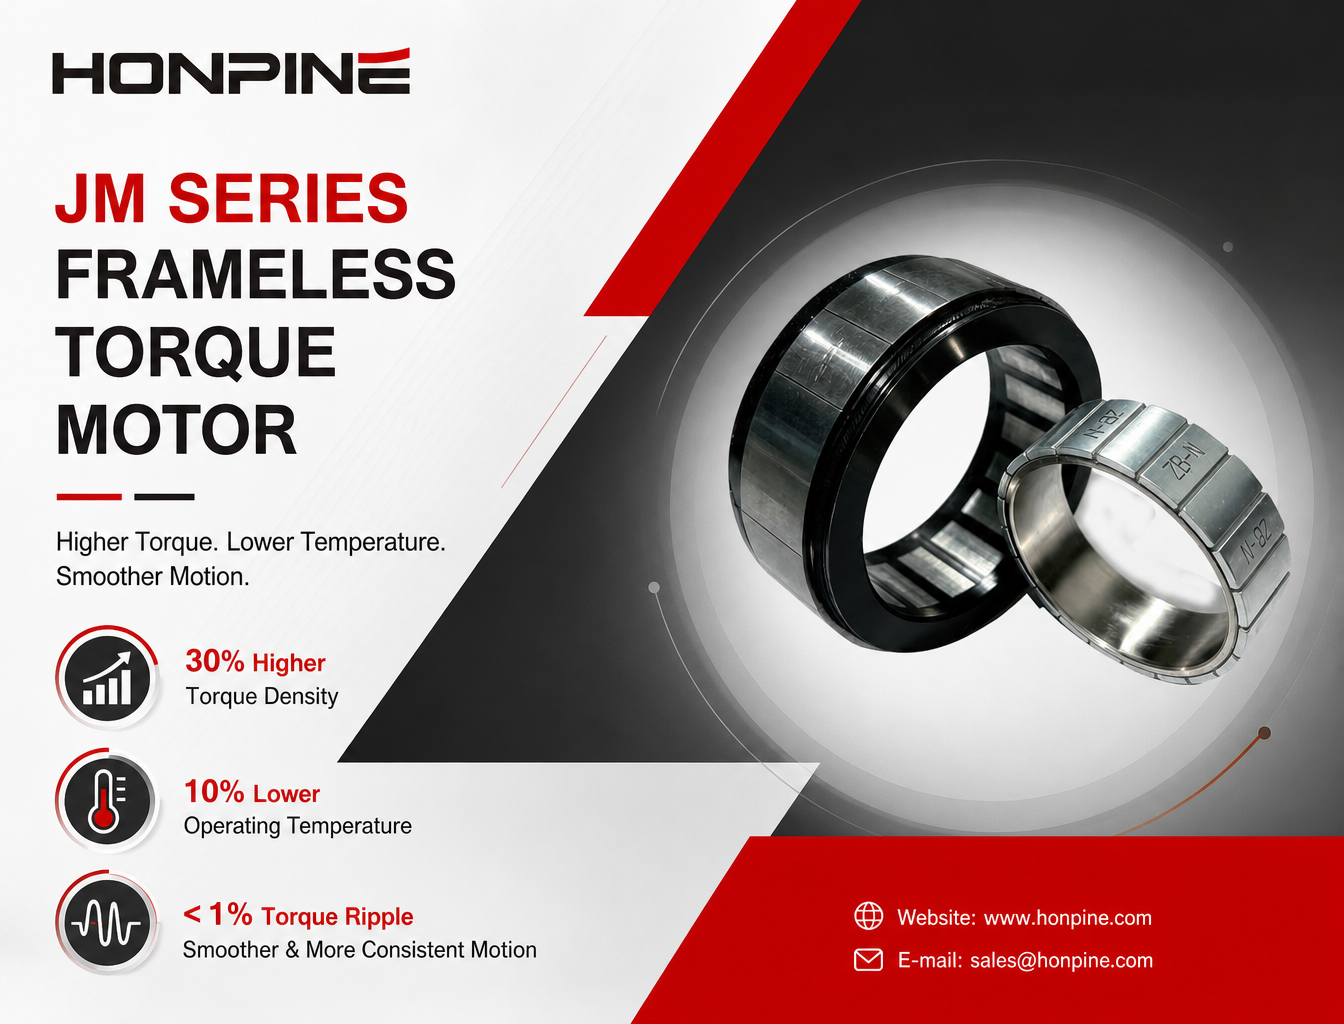
 HONPINE JM Fourth-Generation Frameless Torque Motor: 30% Higher Torque Density and 10% Lower Operating TemperatureAs robotics technology advances, frameless torque motors are facing increasingly demanding requirements for torque density, motion stability, and thermal management. The HONPINE JM fourth-generation frameless torque motor achieves 30% higher torque density and 10% lower operating temperature through improvements in electromagnetic design, core materials, and winding technology. With torque ripple controlled below 1%, it delivers smoother low-speed operation and improved motion consistency, making it suitable for demanding applications such as surgical robots, humanoid robots, and precision automation equipment. How does HONPINE achieve these performance improvements? Let's take a closer look.
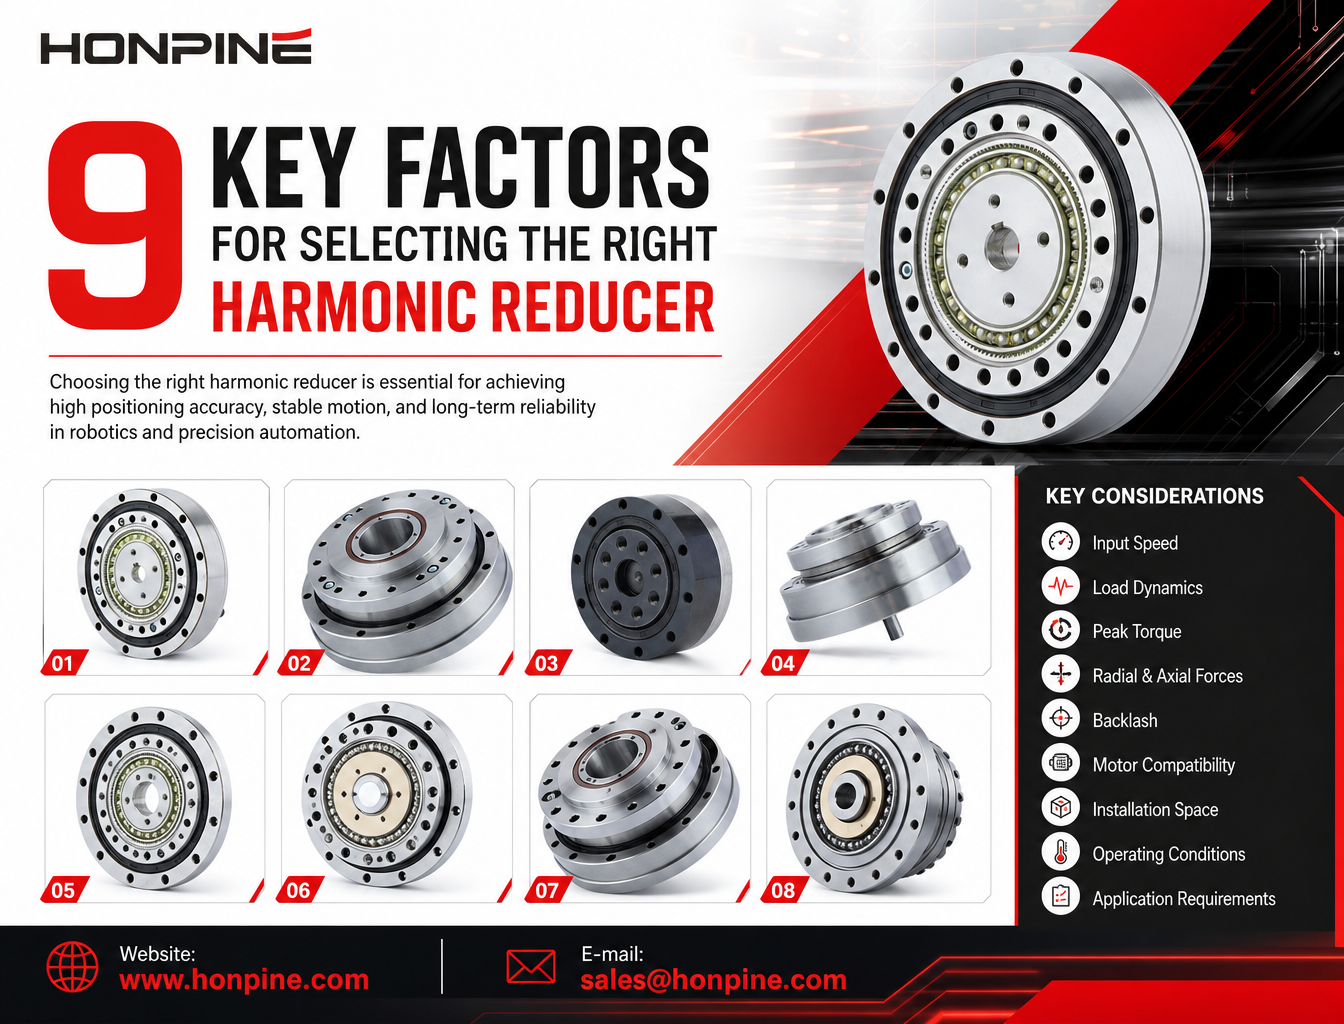
 How to Select a Harmonic Reducer: 9 Key Factors You Need to KnowWhy are more robotics companies choosing integrated robot joint modules instead of traditional distributed drive systems? As humanoid robots, collaborative robots, and rehabilitation exoskeletons continue to evolve, manufacturers are looking for more compact, lightweight, and easier-to-integrate motion solutions. An integrated robot joint module combines essential components such as a frameless torque motor, harmonic reducer, servo drive, encoders, and output bearing into a single assembly. This architecture can reduce mechanical complexity, simplify wiring, improve motion control integration, and shorten robot development cycles. In this article, Theodore Li, Technical Director at HONPINE, explains six key advantages of integrated robot joint modules and compares them with conventional distributed drive configurations.
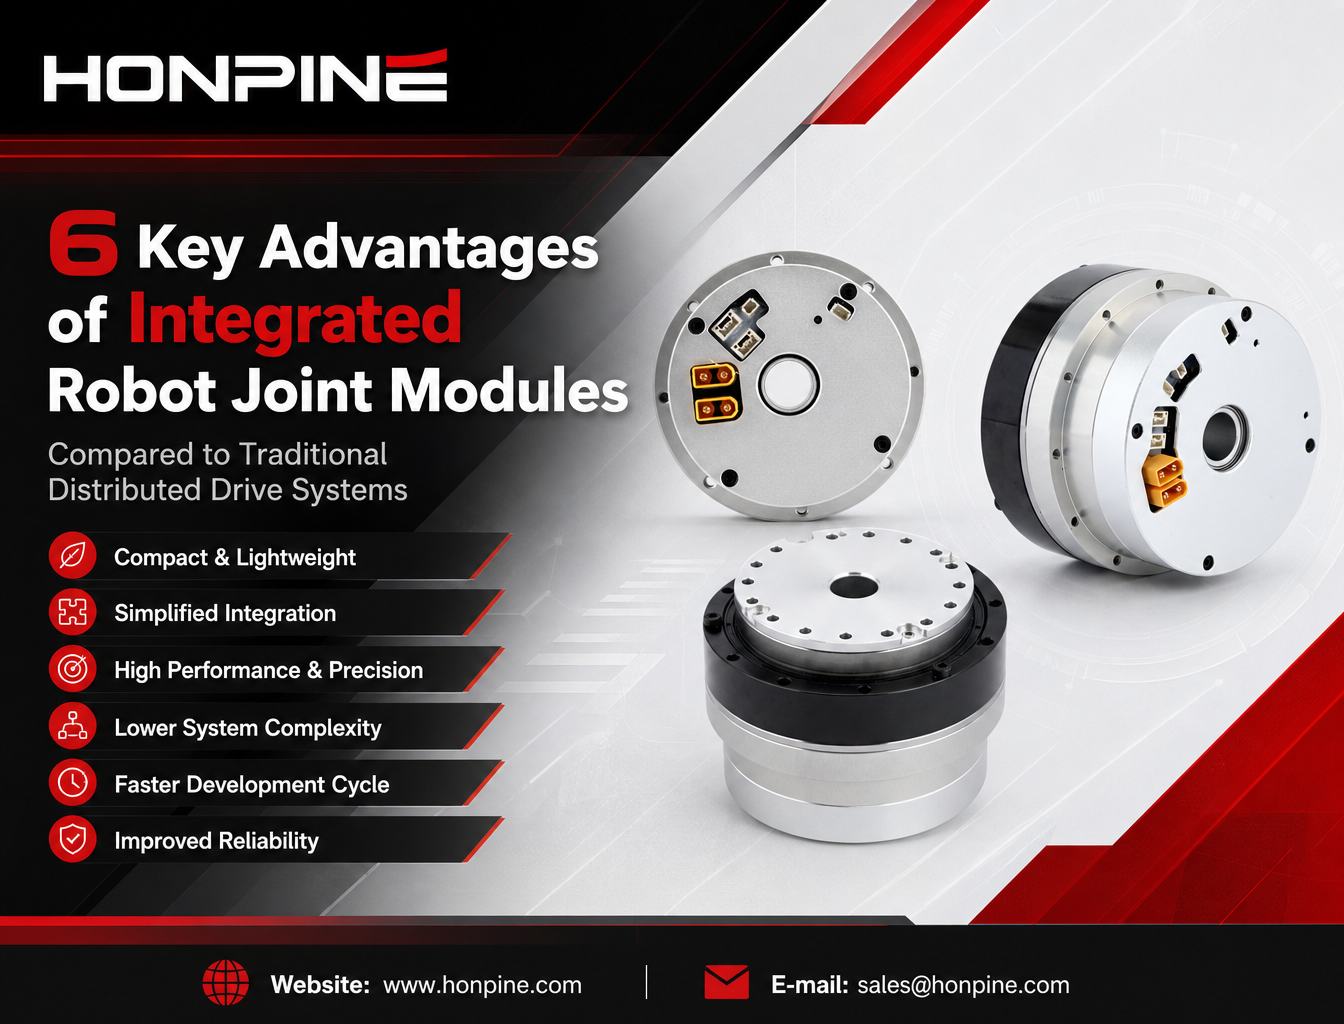
 Why Are More Companies Choosing Integrated Robot Joint Modules?Integrated robot joint modules combine motors, harmonic reducers, servo drives, encoders, and output bearings into compact units. This article compares integrated and distributed drive architectures, exploring their differences in torque density, mechanical reliability, motion control, development efficiency, and practical robotic applications.
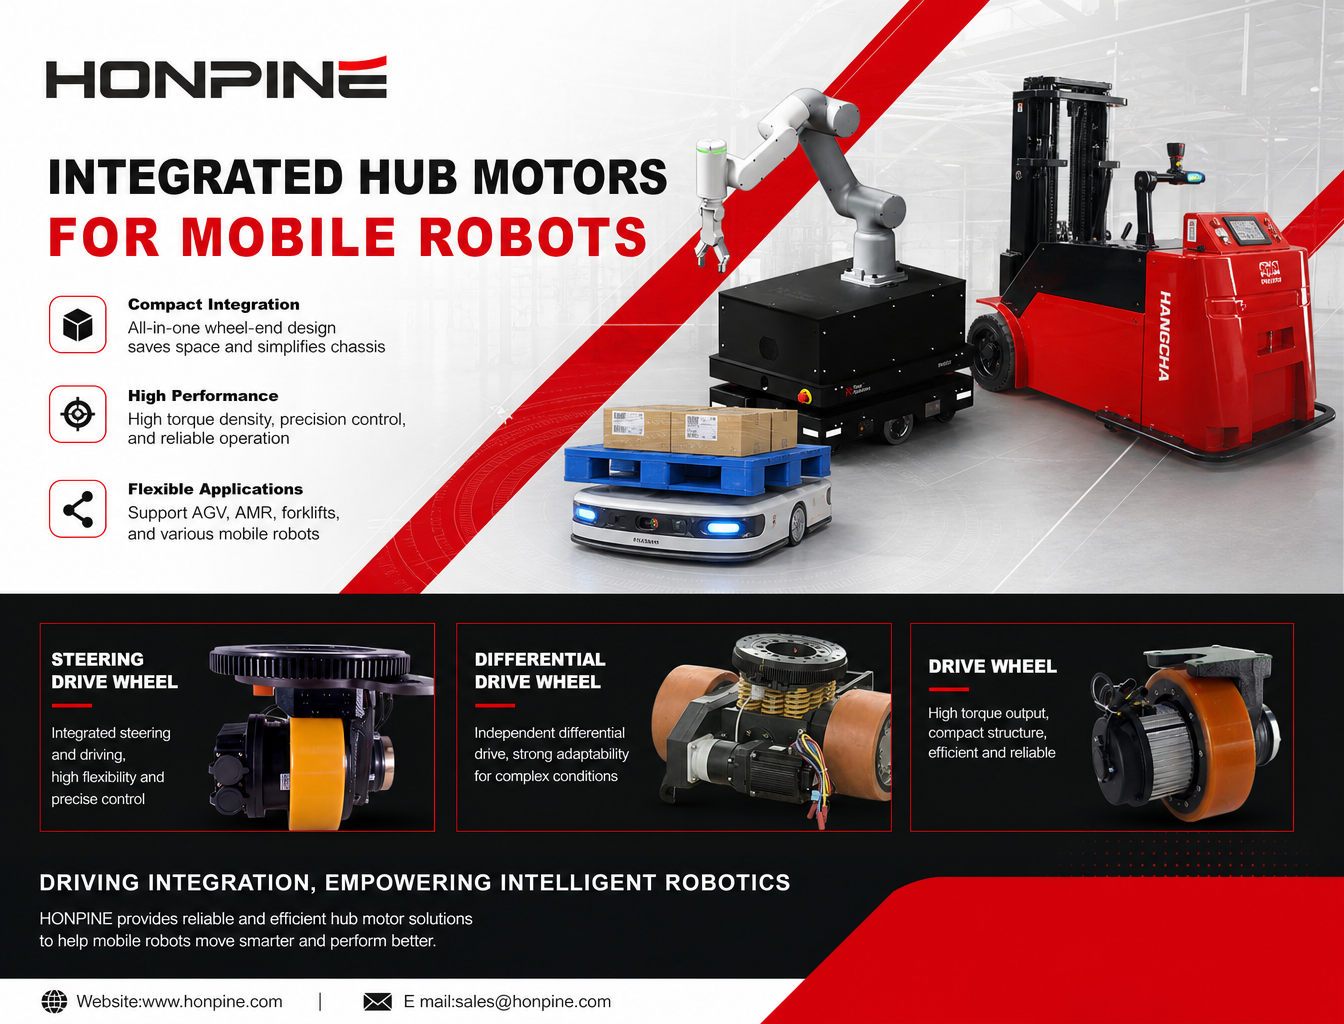
 Why Are More Robots Moving Away from Traditional Drive Systems to Integrated Hub Servo Motors?As mobile robots evolve toward autonomous navigation, flexible operation, and increasingly complex working environments, traditional distributed drive systems are facing new challenges. Separate motors, gearboxes, couplings, and transmission components can increase chassis complexity and limit available installation space. This is why more robot manufacturers are turning to integrated hub servo motors. By combining key drive components within a compact wheel-end unit, hub motors offer new possibilities for improving drive integration, motion control, and chassis design. In this article, we explore the key performance requirements of mobile robots, explain the advantages of integrated hub motors, and examine how HONPINE's Drive Wheels, Steering Drive Wheels, and Differential Drive Wheels support different AGV and AMR applications.
 How Can Precision Reducers, Harmonic Rotary Actuators, and Direct-Drive Motors Upgrade Precision Indexing Tables?How can manufacturers improve the accuracy, dynamic response, and integration of precision indexing tables? As flexible manufacturing continues to evolve, traditional transmission systems may face challenges such as backlash, long settling times, and complex mechanical integration. This article explores how harmonic drive reducers, harmonic rotary actuators, direct-drive (DD) torque motors, and planetary gearboxes provide practical upgrade solutions for different operating conditions. By matching the transmission architecture to positioning accuracy, indexing cycle time, load inertia, and installation constraints, manufacturers can develop more efficient and reliable precision indexing systems.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Why Is the HONPINE TCHL Harmonic Joint Module Suitable for Exoskeleton Robots?The HONPINE TCHL Harmonic Joint Module is designed for exoskeleton robots that require lightweight construction, compact mechanical integration, and responsive human-robot interaction. Featuring a built-in output-side torque sensor, a highly integrated structure, and flexible connection configurations, the TCHL provides a joint drive solution for lower-limb exoskeletons, upper-limb assistive robots, rehabilitation equipment, and industrial wearable robots.
 How Can Precision Reducers, Harmonic Rotary Actuators, and Direct-Drive Motors Upgrade Precision Indexing Tables?How can manufacturers improve the accuracy, dynamic response, and integration of precision indexing tables? As flexible manufacturing continues to evolve, traditional transmission systems may face challenges such as backlash, long settling times, and complex mechanical integration. This article explores how harmonic drive reducers, harmonic rotary actuators, direct-drive (DD) torque motors, and planetary gearboxes provide practical upgrade solutions for different operating conditions. By matching the transmission architecture to positioning accuracy, indexing cycle time, load inertia, and installation constraints, manufacturers can develop more efficient and reliable precision indexing systems.
 Why Bedside Physical Therapy Robots Need Force-Controlled Joint Modules?A therapy robot does not sell a robot arm; it sells a force applied to a human body. Pressure, rhythm and depth are the prescription, and position control cannot deliver them: soft tissue is compliant and time-varying, so one position command yields contact forces that differ several-fold between muscle and bone. Force-controlled harmonic joint modules turn contact force into a closed-loop variable - the only way to make dose repeatable, human contact safe and a therapist's technique teachable. Starting from one site photo of a bedside therapy robot, this article reads the configuration, sets out five reasons force control is unavoidable, settles HONPINE's TCHL-versus-HAG choice criterion by criterion, and gives the torque sensor resolution budget that picks the frame sizes.
 Harmonic Rotary Actuator for Lithium Battery Roller Press EquipmentLithium battery manufacturing equipment requires higher precision, stability, and integration efficiency as production processes continue to evolve. In roller press equipment, accurate roller positioning, pressure control, and dynamic response are critical for ensuring electrode quality and consistency.
HONPINE harmonic rotary actuators provide high precision, high rigidity, fast response, and compact integration for lithium battery roller press equipment. With near-zero backlash, high torque density, and reliable motion control performance, they help improve equipment accuracy and production stability. Harmonic Robot Joint Actuators for Pipeline Robots and Other Special-Purpose EquipmentPipeline robots operate in narrow and complex environments where limited installation space, high load requirements, cable routing, and precise motion control are critical challenges. A reliable joint actuator must provide high torque output, compact dimensions, and stable performance while adapting to demanding operating conditions. Harmonic robot joint actuators integrate precision transmission, motor drive, and sensing capabilities into a compact motion unit, making them suitable for pipeline robots and other special-purpose robotic systems. This article explores the key design requirements of pipeline robots and explains how HONPINE HPJM harmonic robot joint modules help achieve compact, high-performance, and reliable robotic solutions.
 Harmonic Actuator for Lift Equipment: Precision, Torque Density and Compact Motion Control IntroductionModern lifting equipment requires more than simply moving a load vertically. Robotic lift axes, AGV and AMR lift modules, semiconductor equipment, inspection platforms, and specialized winches increasingly demand high torque density, precise positioning, low backlash, high rigidity, and compact motion control. A harmonic actuator integrates a harmonic drive with a motor and, depending on the configuration, encoders, brakes, servo drives, and communication interfaces into a compact motion module. This article explores how harmonic actuators can be applied to different lifting systems and why their combination of precision, torque density, rigidity, and integration makes them suitable for automated lifting and positioning applications.
 Harmonic Rotary Actuators for Semiconductor Equipment: Precision Motion, Hollow-Shaft Design and FOC ControlHello everyone, I’m Theodore Li, Technical Director at HONPINE. In semiconductor manufacturing equipment, rotary motion is not simply about making a mechanism rotate. Limited installation space, cable and tube routing, low-speed stability, precise positioning and continuously adjustable motion profiles can all influence the performance of the machine. This is why harmonic rotary actuators are becoming an important motion solution for semiconductor equipment. In this article, I will discuss how harmonic transmission, FOC-based motor control, encoder feedback, large hollow-shaft design and flexible mechanical interfaces work together to meet practical semiconductor motion requirements, based on our experience with developing equipment, overhead transport, wafer handling, cleaning and crystal-growth applications.
 Miniature Harmonic Drive for Minimally Invasive Surgical RobotsMinimally invasive surgical robots require highly compact transmission systems that can deliver precise motion within extremely limited mechanical spaces. As robotic instruments become smaller and more dexterous, conventional transmission architectures can face challenges related to size, tendon elasticity, friction, hysteresis, and mechanical integration. A miniature harmonic drive offers one potential approach by providing high-ratio precision transmission, low backlash, and compact dimensions in a small mechanical envelope. In this article, I will explain why miniature harmonic transmission is relevant to surgical robotics, compare external tendon-driven and distal transmission architectures, and discuss the key engineering considerations behind HONPINE’s CSF-mini miniature harmonic reducer for compact robotic joints, flexible robotic instruments, and other precision mechanisms.
 Why Laser Wobble Welding Systems Need a High-Precision Harmonic Rotary Actuator?Laser wobble welding is increasingly used in battery manufacturing, busbar welding, electronics, medical devices, robotic welding, and other precision manufacturing applications where beam movement must remain accurate and repeatable. In mechanical wobble welding systems, however, weld quality depends not only on laser parameters but also on the precision of the rotary motion mechanism driving the wobble head. Backlash, insufficient torsional rigidity, limited torque density, and positioning errors can directly affect the actual beam trajectory and molten pool stability. This is why a high-precision rotary motion solution is becoming an important part of modern laser wobble welding equipment. A Harmonic Rotary Actuator combines precision transmission, high rigidity, low backlash, and compact integration, making it well suited for mechanical wobble heads that require controlled rotary motion under dynamic loads.