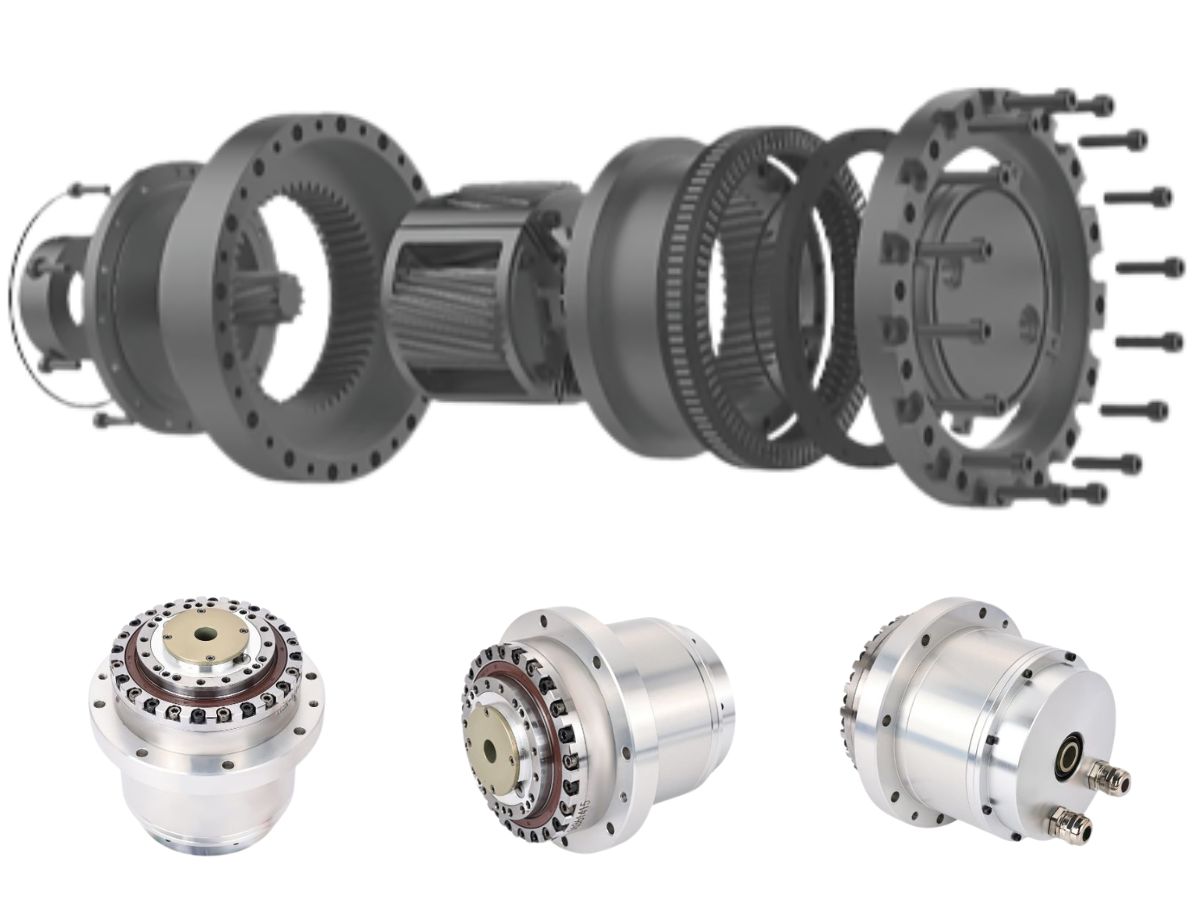
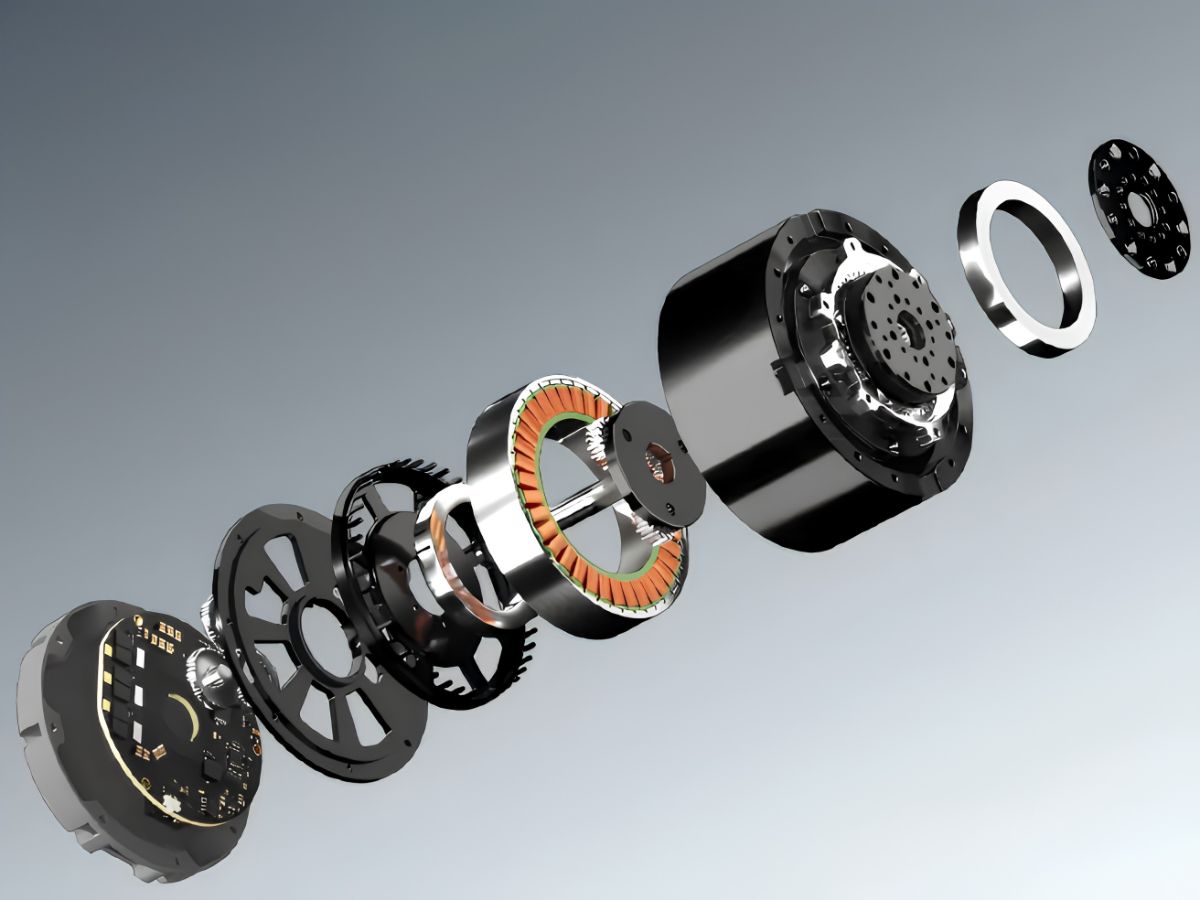
Robot Joint Module Solutions for Humanoid Robot Arms and Legs
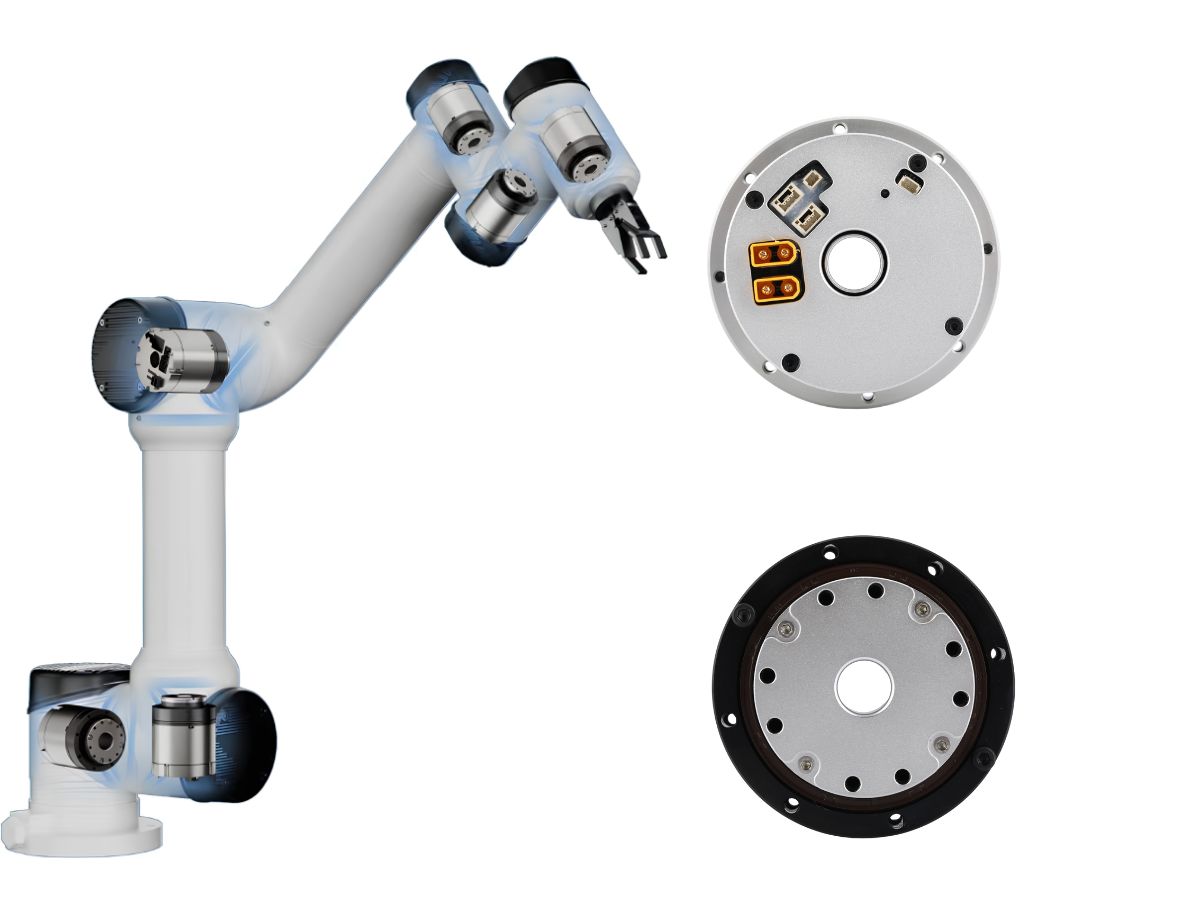
The application of robotic arms is expanding rapidly across a wide range of industries. A robotic upper body can form part of a complete humanoid robot, or it can be combined with a fixed robotic arm and mobile base, or a robotic arm with a dexterous hand, to perform tasks such as picking and placing components, screw fastening, connector insertion and removal, switch operation, box handling, power tool operation, vision-guided picking, warehouse picking, automotive assembly, 3C electronics assembly, laboratory operations, and medical assistance.
At the heart of these applications are robot joint modules, which play a critical role in delivering the required motion, torque, precision, and responsiveness.
Smaller joints generally prioritize low weight and fast response, while larger joints require higher torque density and reliability. A good joint solution is not simply a matter of scaling the same module up or down. Instead, each joint should be precisely matched to its specific load, range of motion, and control requirements.
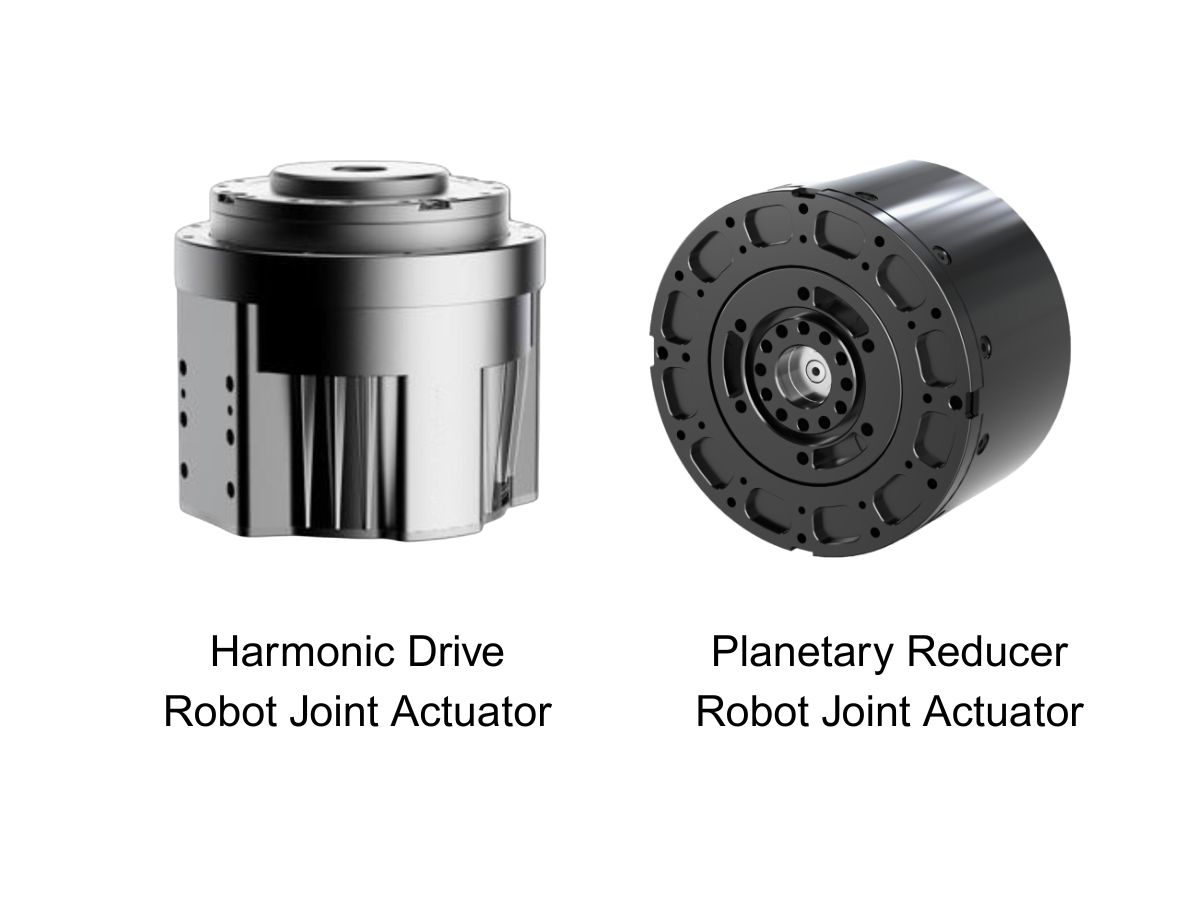
HONPINE's robot joint modules include four harmonic joint module series — HPJM, TCHL, HAU, and HAG — as well as planetary joint module series HPA and JRM.
In this article, we use the HONPINE HPJM series as an example to present a robot joint module solution for humanoid robot upper and lower limbs.
Humanoid Robot Upper Limb Joint Solution: Torque-Graded Configuration for the Shoulder, Elbow, and Wrist
Wrist and Fingers: 3–10 Nm
The wrist and finger joints are among the smallest joints in a humanoid robot. They require extremely low weight and fast response to achieve agile movements.
The HONPINE HPJM-RE30-40 series provides a peak torque of 3.3–4.8 Nm with a weight of only 0.19 kg, making it well suited for wrists, fingers, and other distal joints.
With a 24–48 V wide voltage range, CAN communication, and a highly integrated design, the module provides a compact solution for lightweight humanoid robot joints.
Elbow: 20–50 Nm
The elbow joint needs to support the load of the forearm and hand while providing sufficient range of motion.
The HONPINE HPJM-RE50-60 series provides up to 34 Nm peak torque with a weight of 0.45 kg. Reduction ratios of 51, 81, and 101 are available, making it a practical choice for humanoid robot elbow joints.
For applications requiring higher torque, the HPJM-RE60-70 series provides up to 66 Nm peak torque, supporting higher payload requirements.
Shoulder: 50–150 Nm
The shoulder is one of the largest joints in the upper limb. It needs to support the weight of the entire arm while providing a wide range of motion.
The HONPINE HPJM-RE70-80 series provides 69–108 Nm peak torque, while the HPJM-RE80-97 series delivers up to 217 Nm peak torque, covering a wide range of shoulder joint requirements from lightweight to higher-load applications.
The dual-encoder version supports both CAN and EtherCAT, enabling more precise synchronization and coordinated control across multiple robot joints.
Lightweight Design for Humanoid Robot Upper Limbs
A common priority across humanoid robot upper-limb joints is weight reduction.
Compared with the standard PRO series in the same size class, the HONPINE HPJM-REPRO-S series is approximately 15%–30% lighter. This can be particularly valuable for humanoid robots where controlling the overall system weight is critical.
Humanoid Robot Lower Limb Joint Solution: Balancing High Load and Lightweight Design
Lower-limb joints face significantly higher load and impact requirements than many upper-limb joints. The key challenge is to balance torque capacity, structural strength, responsiveness, and weight.
Ankle: 30–80 Nm
The ankle joint plays a critical role in maintaining balance and requires fast response combined with adequate torque capacity.
The HONPINE HPJM-RE50-70 and HPJM-RE60-70 series can be used for ankle applications, providing 34–66 Nm peak torque with weights of approximately 0.6–0.8 kg.
This provides a balance between response speed and load capacity for humanoid robot ankle joints.
Knee: 80–200 Nm
The knee joint experiences significant impact loads during walking, squatting, and other dynamic movements. It therefore requires high torque capacity and reliable operation.
The HONPINE HPJM-RE80-97 series provides 121–217 Nm peak torque, while the HPJM-RE80-110 series provides up to 217 Nm peak torque, making these series suitable for a range of humanoid robot knee applications.
The large hollow design, with a 27 mm through-hole, facilitates internal cable routing and the passage of pneumatic or hydraulic lines.
Hip: 150–800 Nm
The hip is one of the largest and most heavily loaded joints in a humanoid robot. It needs to support the robot's overall body weight while enabling multi-axis movement.
The HONPINE HPJM-RE100-120 series provides 267–459 Nm peak torque, while the HPJM-RE110-145 series delivers up to 491–800 Nm peak torque, providing high-torque options for heavy-duty hip joint applications.
The product is rated for more than 10,000 hours of service life while maintaining accuracy under specified continuous torque conditions, supporting long-term operating reliability.
Why Integrated Harmonic Joint Modules Matter for Humanoid Robots?
For humanoid robot lower limbs, one of the key engineering challenges is achieving the right balance between high load capacity and lightweight construction.
The HONPINE HPJM series combines a harmonic reducer with a frameless torque motor, providing high torque density in a compact package. A cross-roller bearing provides high axial and radial load capacity while offering strong resistance to impact loads.
This integrated architecture combines the major components required for a robot joint into a compact module, helping reduce the complexity and overall weight of the joint assembly.
Robot Joint Modules and the Working Envelope of Humanoid Robot Arms
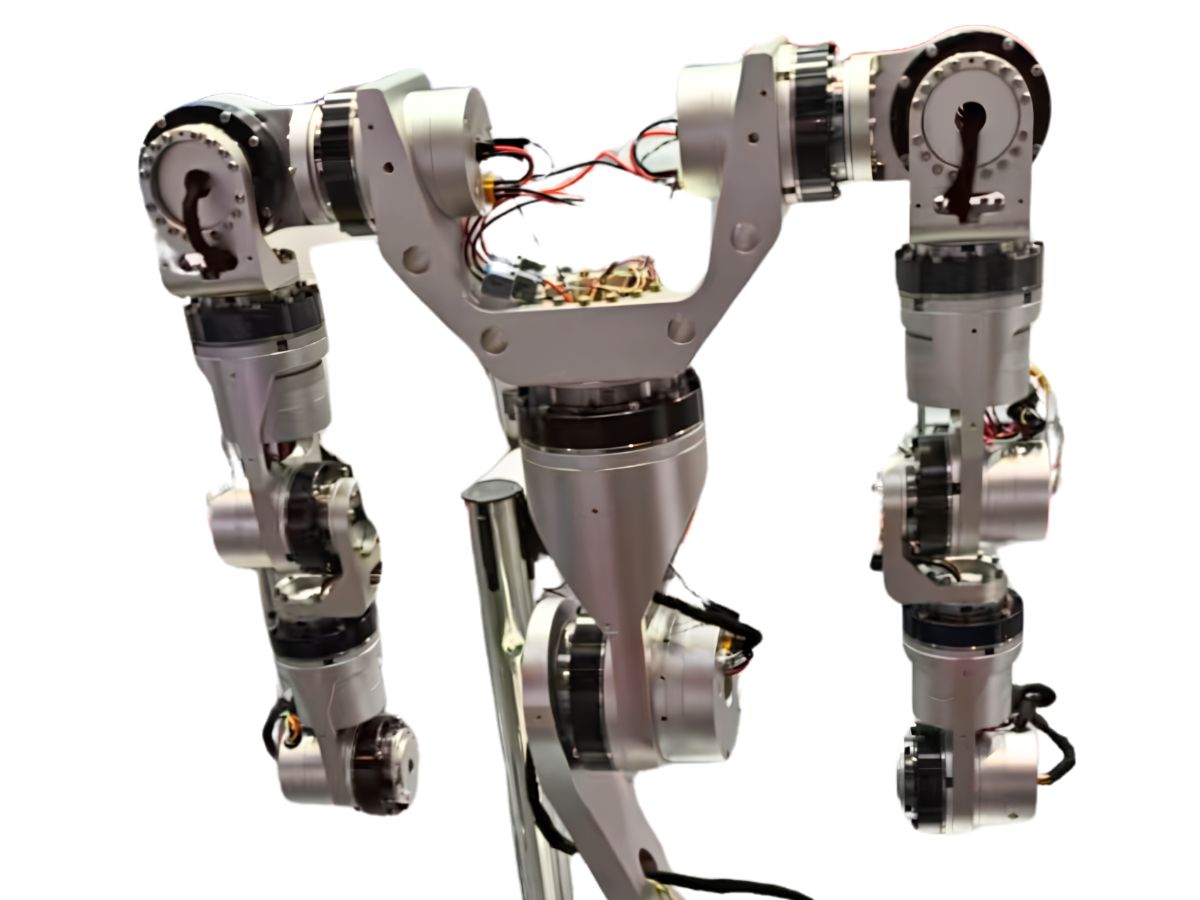
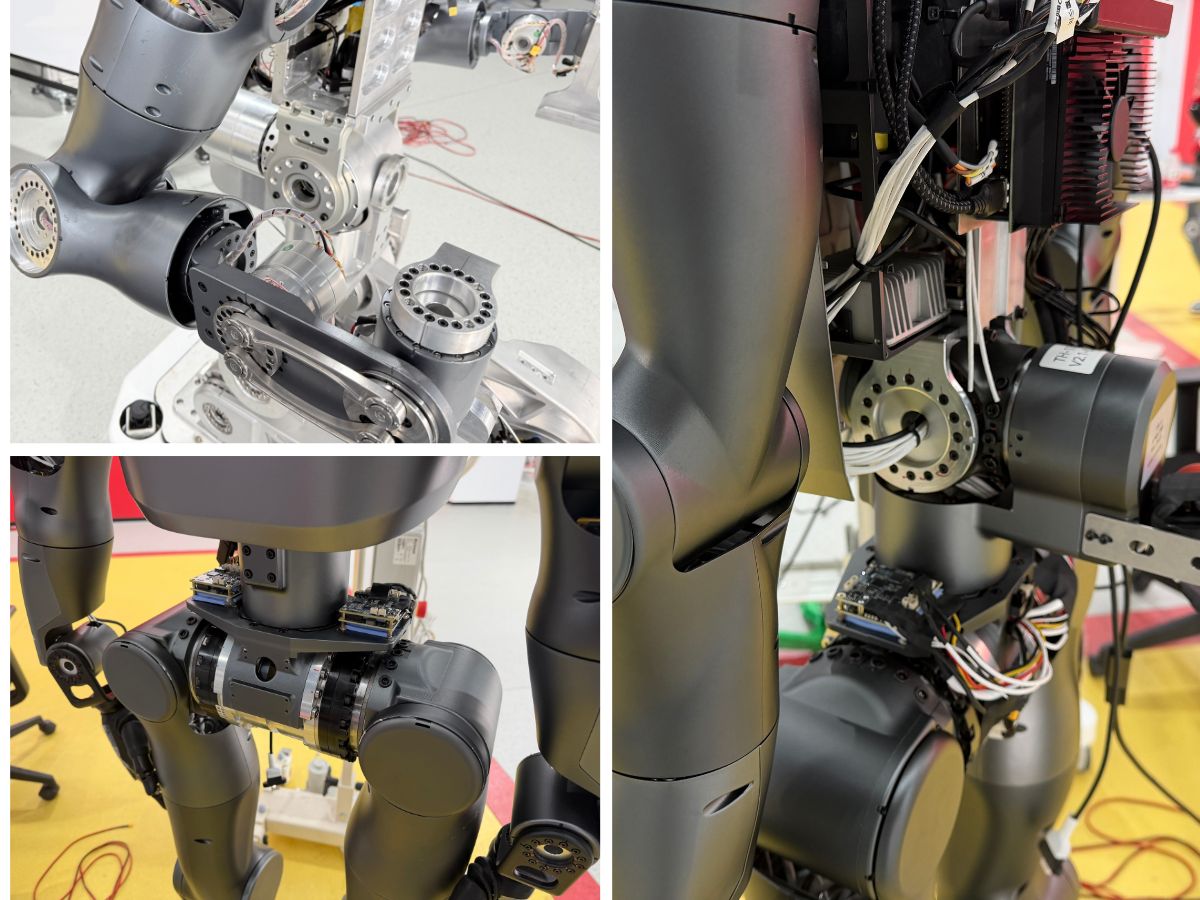
The most basic function of a robot arm is to reach outward. However, the real challenge is whether the arm can cover a sufficiently large workspace, reach targets with the appropriate posture, and coordinate effectively with the robot's vision system, torso, and lower limbs.
The upper limb acts as a distal cantilever and therefore creates a long-lever-arm load. On a humanoid robot, the weight of the arm itself can generate significant overturning moments on the hip, waist, and lower limbs.
An integrated robot joint module can help reduce the weight and complexity of each joint while maintaining the torque, control, and motion performance required for the application. This enables more compact and responsive humanoid robot arms while supporting coordinated full-body motion.
Contact HONPINE to learn more about our robot joint modules and discuss a suitable joint solution for your humanoid robot application.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
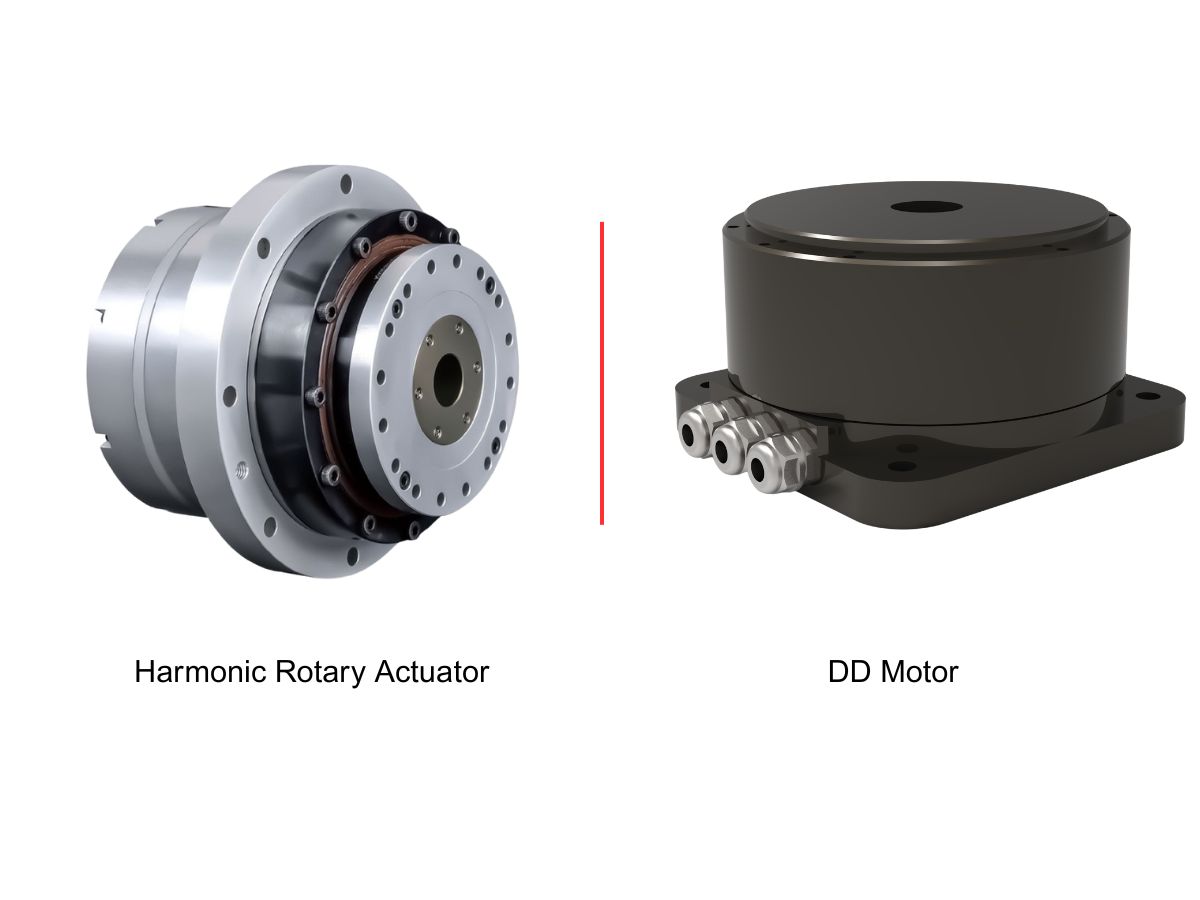
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
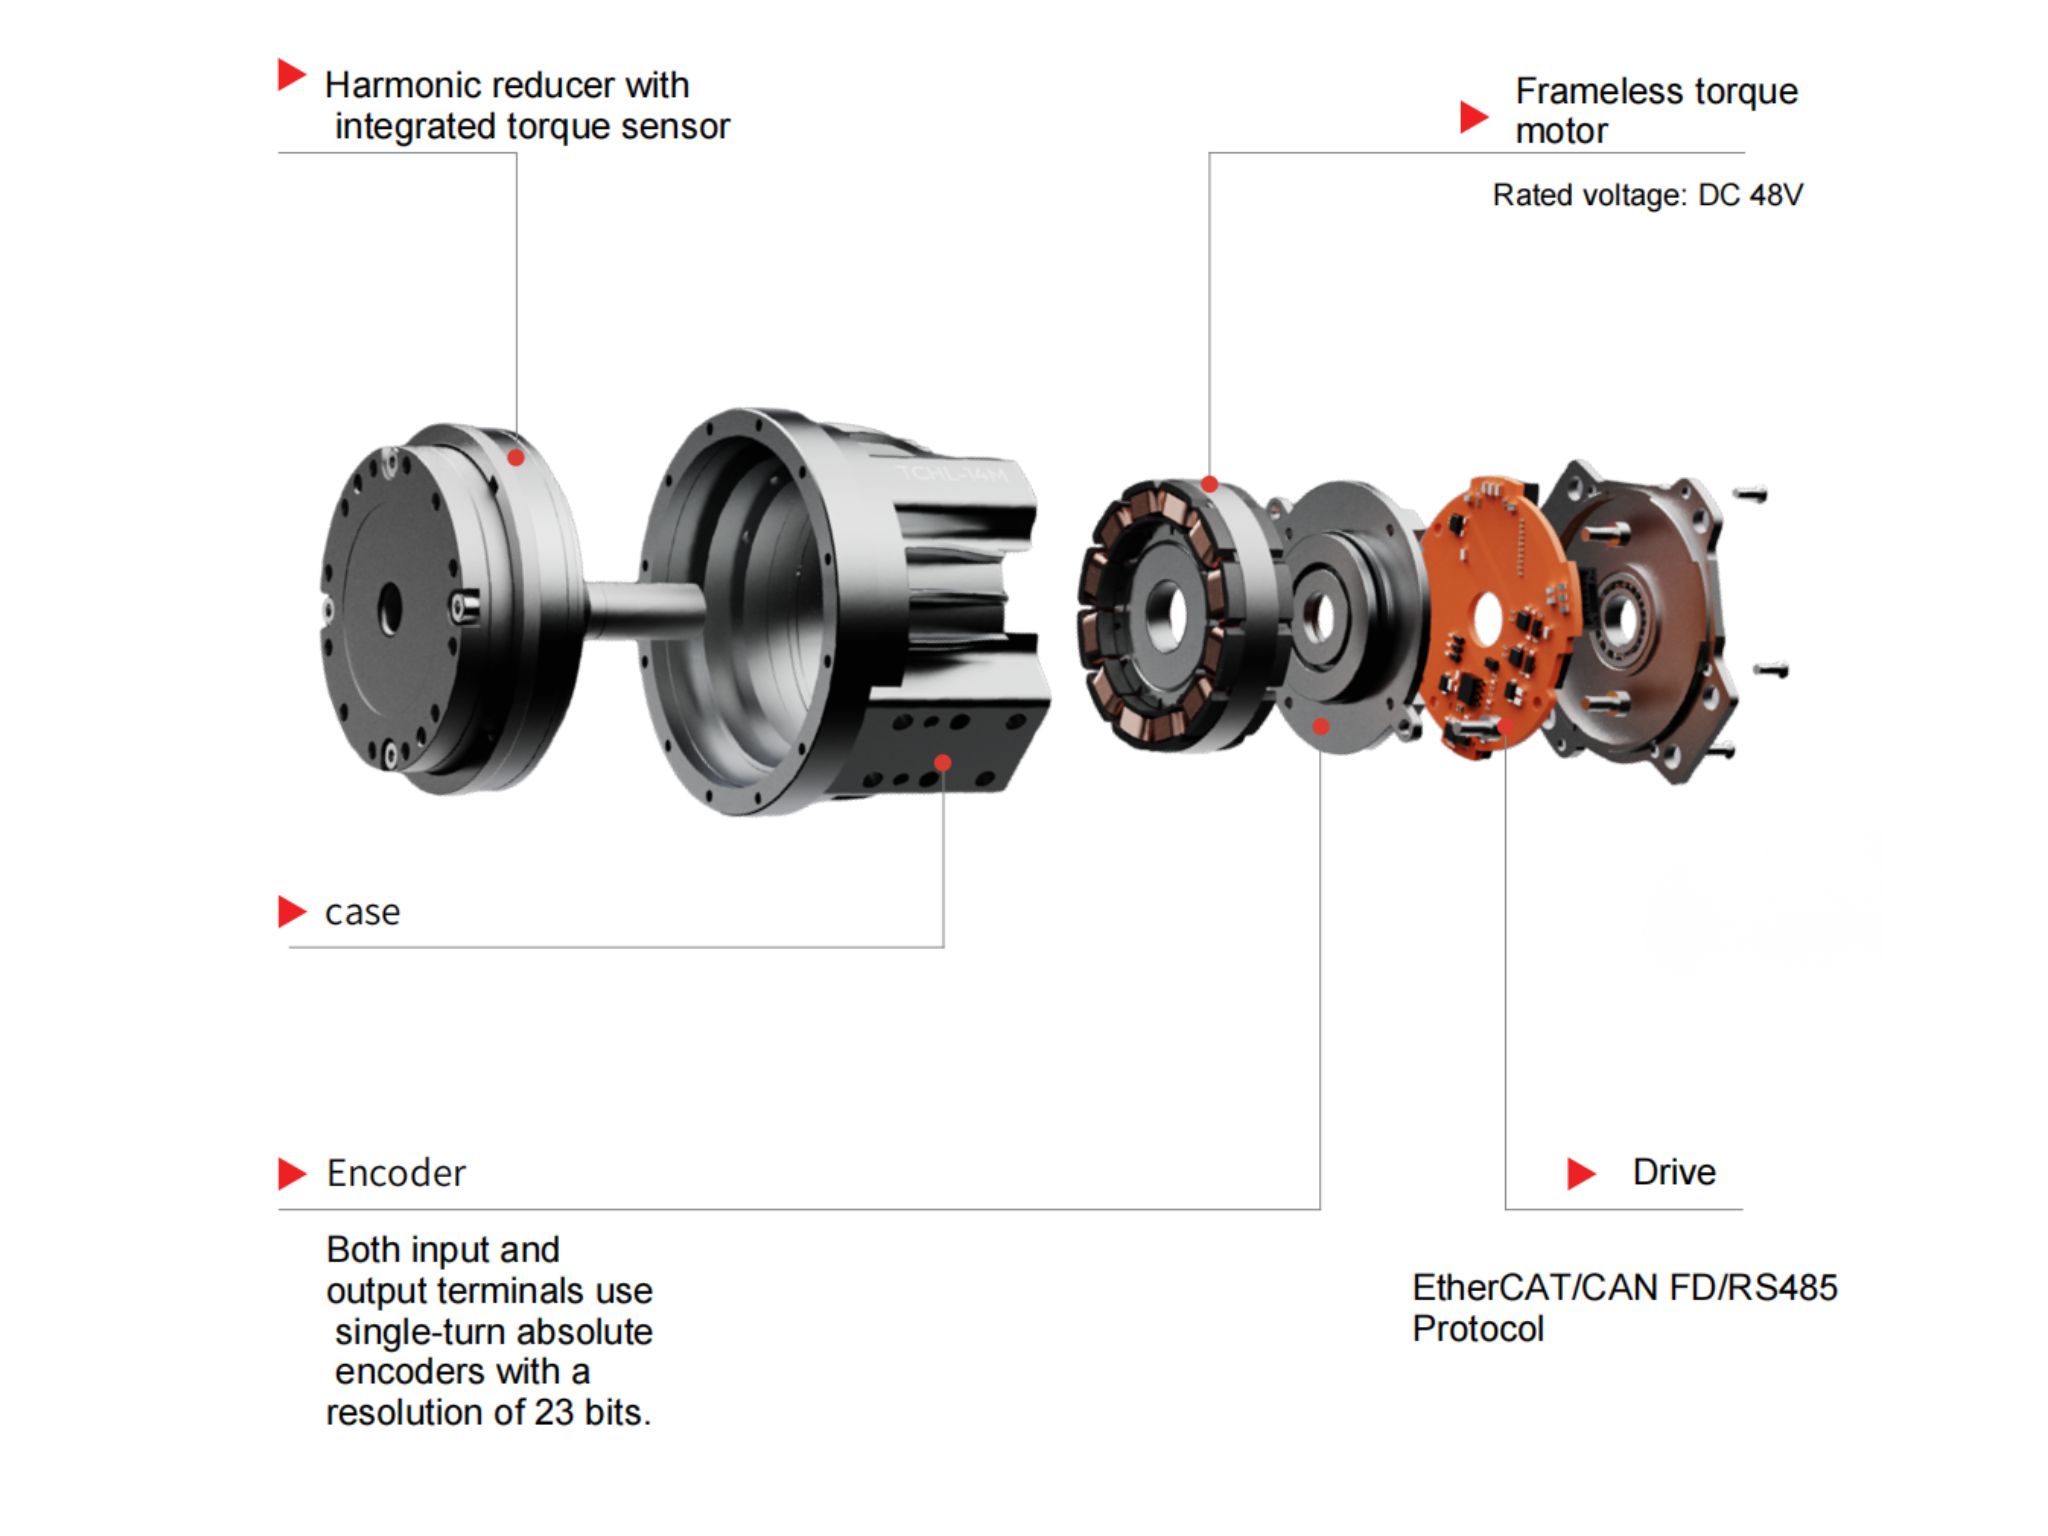
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
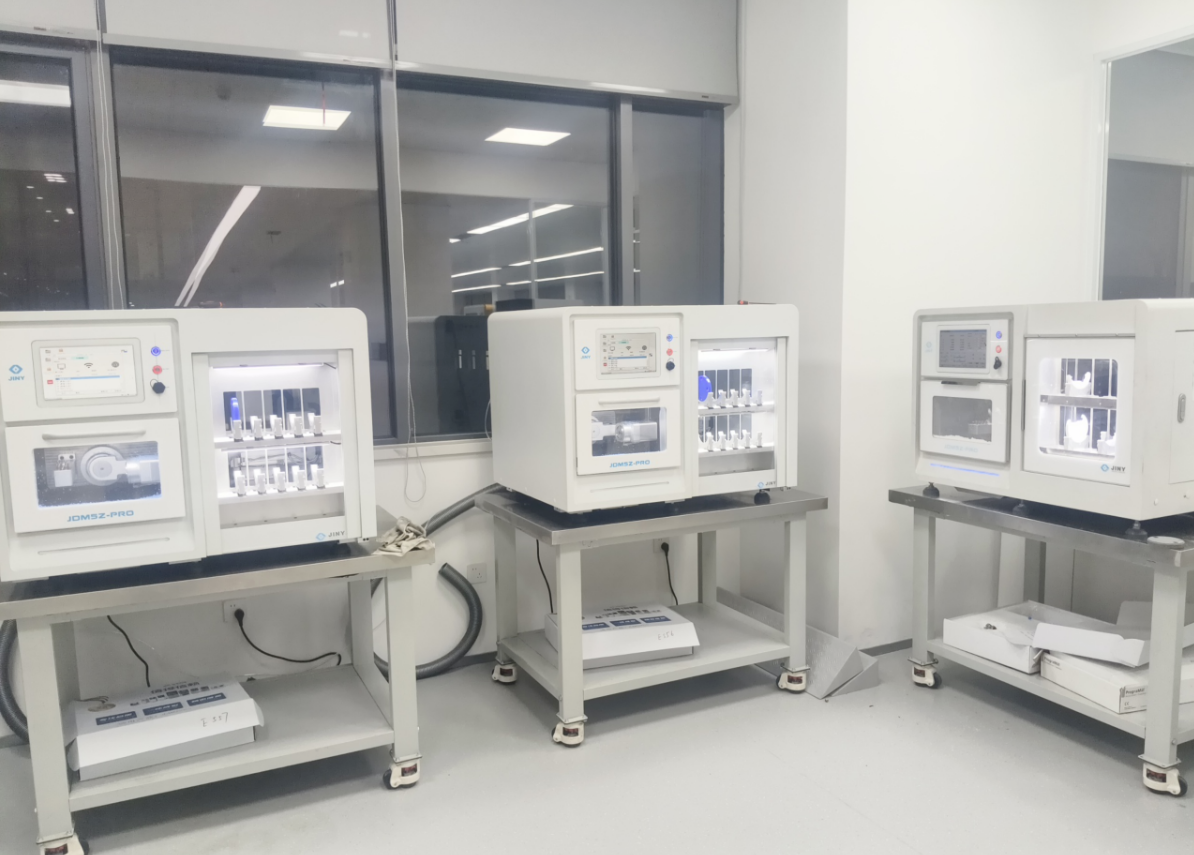
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Robot Joint Module Solutions for Humanoid Robot Arms and LegsHumanoid robots require different joint characteristics across the shoulder, elbow, wrist, hip, knee, and ankle. Smaller joints prioritize low weight and fast response, while larger joints require higher torque density, load capacity, and reliability. A suitable robot joint module should therefore be matched to the specific torque, weight, range of motion, and control requirements of each joint. In this article, HONPINE uses the HPJM harmonic joint module series as an example to present a joint configuration solution for humanoid robot upper and lower limbs, covering torque requirements from small wrist and finger joints to high-load hip joints.
 Why Does an RV Reducer Need Profile Modification? How to Further Reduce Backlash and Transmission Error?An RV Reducer is designed to deliver high torque, high stiffness, and precise motion for demanding applications such as robotic joints, industrial rotary tables, and precision machinery. However, achieving low backlash and stable transmission accuracy requires more than high-precision machining. Cycloidal profile modification must also account for manufacturing tolerances, assembly errors, load-induced deformation, thermal expansion, and lubrication conditions. In this article, we examine why RV reducers require profile modification, how different modification methods affect meshing, and how engineers can further control backlash and transmission error through profile design, error budgeting, structural analysis, precision manufacturing, and validation testing.
 How to Choose a Hollow Rotary Platform: A Complete Selection Guide?A hollow rotary platform is widely used in precision automation where rotary positioning, compact integration, and cable routing through the rotation axis are required. However, choosing the right platform involves more than comparing rated torque or maximum speed. Load, eccentricity, overturning moment, inertia, positioning accuracy, hollow bore, acceleration, duty cycle, and installation conditions all affect the actual performance of the rotary system. This guide explains the key parameters engineers should consider when selecting a hollow rotary platform for CNC indexing, wafer handling, vision inspection, laser processing, dispensing, and other precision rotary applications.
 Hollow Robot Joint Module: Why Cable Routing Matters in Robotic Joints?A hollow robot joint module provides an internal passage for power cables, signal lines, pneumatic tubes, and other end-effector connections. Compared with external cable routing, a hollow joint module can help reduce cable exposure, improve system integration, and create a cleaner motion path for robotic arms. This article explains why internal cable routing matters in robotic joints and what to consider when selecting a hollow joint module for robotic applications.
 Precision Reducers for Industrial Robots: From Conventional Transmission to Self-Compensating Backlash TechnologyHello everyone, I’m Theodore Li, Technical Director at HONPINE. Today, I would like to discuss precision reducers for industrial robots and the challenges of maintaining transmission accuracy over long-term operation. Harmonic, RV, cycloidal, and planetary transmissions each offer different combinations of precision, rigidity, torque density, and compactness, making reducer selection highly dependent on robot architecture and joint requirements. However, initial backlash is only part of the problem. As transmission components wear, changes in mechanical clearance can gradually affect positioning performance. This article examines the major precision transmission technologies used in industrial robots and introduces HONPINE’s self-compensating backlash technology, which is designed to address precision retention throughout the operating life of a transmission.
 Large-Bore Harmonic Joint Actuator for Humanoid Robot Waist Joints: A Practical Selection GuideThe humanoid robot waist joint is one of the most demanding motion joints in a humanoid robot. Unlike conventional robotic arm joints, it supports the upper body while handling bending, twisting, posture transitions, and continuously changing dynamic loads. At the same time, the limited internal space must accommodate power cables, signal lines, sensors, and structural components. These requirements make a large-bore harmonic joint actuator an important option for humanoid robot waist joints. This article explains how to select a suitable harmonic joint actuator by considering hollow bore size, dynamic torque, reduction ratio, mechanical rigidity, integration, and service life.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Robot Joint Module Solutions for Humanoid Robot Arms and LegsHumanoid robots require different joint characteristics across the shoulder, elbow, wrist, hip, knee, and ankle. Smaller joints prioritize low weight and fast response, while larger joints require higher torque density, load capacity, and reliability. A suitable robot joint module should therefore be matched to the specific torque, weight, range of motion, and control requirements of each joint. In this article, HONPINE uses the HPJM harmonic joint module series as an example to present a joint configuration solution for humanoid robot upper and lower limbs, covering torque requirements from small wrist and finger joints to high-load hip joints.
 Why Does an RV Reducer Need Profile Modification? How to Further Reduce Backlash and Transmission Error?An RV Reducer is designed to deliver high torque, high stiffness, and precise motion for demanding applications such as robotic joints, industrial rotary tables, and precision machinery. However, achieving low backlash and stable transmission accuracy requires more than high-precision machining. Cycloidal profile modification must also account for manufacturing tolerances, assembly errors, load-induced deformation, thermal expansion, and lubrication conditions. In this article, we examine why RV reducers require profile modification, how different modification methods affect meshing, and how engineers can further control backlash and transmission error through profile design, error budgeting, structural analysis, precision manufacturing, and validation testing.
 How to Choose a Hollow Rotary Platform: A Complete Selection Guide?A hollow rotary platform is widely used in precision automation where rotary positioning, compact integration, and cable routing through the rotation axis are required. However, choosing the right platform involves more than comparing rated torque or maximum speed. Load, eccentricity, overturning moment, inertia, positioning accuracy, hollow bore, acceleration, duty cycle, and installation conditions all affect the actual performance of the rotary system. This guide explains the key parameters engineers should consider when selecting a hollow rotary platform for CNC indexing, wafer handling, vision inspection, laser processing, dispensing, and other precision rotary applications.
 Hollow Robot Joint Module: Why Cable Routing Matters in Robotic Joints?A hollow robot joint module provides an internal passage for power cables, signal lines, pneumatic tubes, and other end-effector connections. Compared with external cable routing, a hollow joint module can help reduce cable exposure, improve system integration, and create a cleaner motion path for robotic arms. This article explains why internal cable routing matters in robotic joints and what to consider when selecting a hollow joint module for robotic applications.
 Precision Reducers for Industrial Robots: From Conventional Transmission to Self-Compensating Backlash TechnologyHello everyone, I’m Theodore Li, Technical Director at HONPINE. Today, I would like to discuss precision reducers for industrial robots and the challenges of maintaining transmission accuracy over long-term operation. Harmonic, RV, cycloidal, and planetary transmissions each offer different combinations of precision, rigidity, torque density, and compactness, making reducer selection highly dependent on robot architecture and joint requirements. However, initial backlash is only part of the problem. As transmission components wear, changes in mechanical clearance can gradually affect positioning performance. This article examines the major precision transmission technologies used in industrial robots and introduces HONPINE’s self-compensating backlash technology, which is designed to address precision retention throughout the operating life of a transmission.
 Large-Bore Harmonic Joint Actuator for Humanoid Robot Waist Joints: A Practical Selection GuideThe humanoid robot waist joint is one of the most demanding motion joints in a humanoid robot. Unlike conventional robotic arm joints, it supports the upper body while handling bending, twisting, posture transitions, and continuously changing dynamic loads. At the same time, the limited internal space must accommodate power cables, signal lines, sensors, and structural components. These requirements make a large-bore harmonic joint actuator an important option for humanoid robot waist joints. This article explains how to select a suitable harmonic joint actuator by considering hollow bore size, dynamic torque, reduction ratio, mechanical rigidity, integration, and service life.
 Nabtesco RV vs Harmonic Drive vs WITTENSTEIN: Why Backlash-Free Planetary Actuators Are EmergingNabtesco RV, Harmonic Drive, and WITTENSTEIN have each established proven transmission solutions for robotics, machine tools, automation, and precision motion control. However, applications requiring both arc-second-level positioning and high mechanical rigidity can expose different trade-offs between backlash, torsional stiffness, load capacity, and transmission accuracy. This has created growing interest in a backlash-free planetary actuator that combines the rigidity and torque density of planetary transmission with advanced backlash compensation. In this article, we compare the characteristics of Nabtesco RV, Harmonic Drive, and WITTENSTEIN precision planetary gearboxes, and examine where a backlash-free planetary actuator can provide an alternative solution.
 Robot Joint Actuator Selection: From Inertia Matching to System-Level OptimizationSelecting a robot joint actuator is not simply a matter of matching motor torque or achieving a suitable inertia ratio. In a real robotic system, reduction ratio, load spectrum, thermal performance, mechanical stiffness, transmission nonlinearity, encoder architecture, control bandwidth, and service life all interact to determine the final result. A joint may meet its peak torque requirement and still experience vibration, overheating, positioning errors, or premature wear in real operation. This article examines the engineering logic behind robot joint actuator selection and explains why moving from single-parameter matching to system-level optimization can lead to more reliable and predictable robotic joint performance.
 How to Choose a Small Harmonic Actuator?HONPINE Series 11 small harmonic actuators provide a compact, high-performance rotary motion solution for precision automation applications. Available with hollow or solid shafts, 48V or 220V options, optional brakes, absolute encoders, and different reduction ratios, the Series 11 is designed for applications requiring compact dimensions, controlled torque, and precise positioning.