What Are Rated, Intermittent, and Peak Torque in a Harmonic Actuator?
When selecting a harmonic actuator for a robot joint, engineers often focus on its maximum output torque. However, a single torque value cannot fully describe an actuator's operating capability. A robot joint may need to support a load continuously, generate higher torque during periodic movements, or withstand brief external impacts. These different operating conditions require different torque ratings.
Rated torque, intermittent torque, and peak torque represent three distinct aspects of a harmonic actuator's performance. Understanding their differences is essential for evaluating continuous load capacity, dynamic motion capability, and mechanical limits. For humanoid robots, quadruped robots, and robotic arms, selecting an actuator based only on peak torque can lead to overheating, accelerated component wear, and reduced service life.
1. Rated Torque: The Foundation of Continuous Operation
Rated torque is the output torque that a harmonic actuator can continuously deliver under the manufacturer's specified operating conditions. These conditions may include the allowable operating speed range, ambient temperature, cooling conditions, and other relevant specifications.
It represents the actuator's continuous operating capability and is closely related to its thermal design.
During operation, the frameless torque motor, harmonic reducer, bearings, encoder, and other internal components generate heat. The actuator must dissipate this heat effectively to keep component temperatures within their allowable limits.
When operating within its rated conditions, the actuator is designed to maintain stable performance over extended periods. This helps protect the motor, reducer, bearings, and other components from excessive thermal stress, supporting long-term reliability and consistent transmission performance.
Why Is Rated Torque Important for Long-Term Reliability?
If a harmonic actuator continuously operates above its rated torque, heat generation may exceed its heat dissipation capacity. As the temperature rises, the motor winding insulation, reducer lubrication, bearings, and electronic components may experience additional thermal stress.
Prolonged operation under excessive load can accelerate component aging, increase mechanical wear, and affect positioning performance over time.
Therefore, rated torque should be the primary reference when evaluating loads that must be maintained continuously.
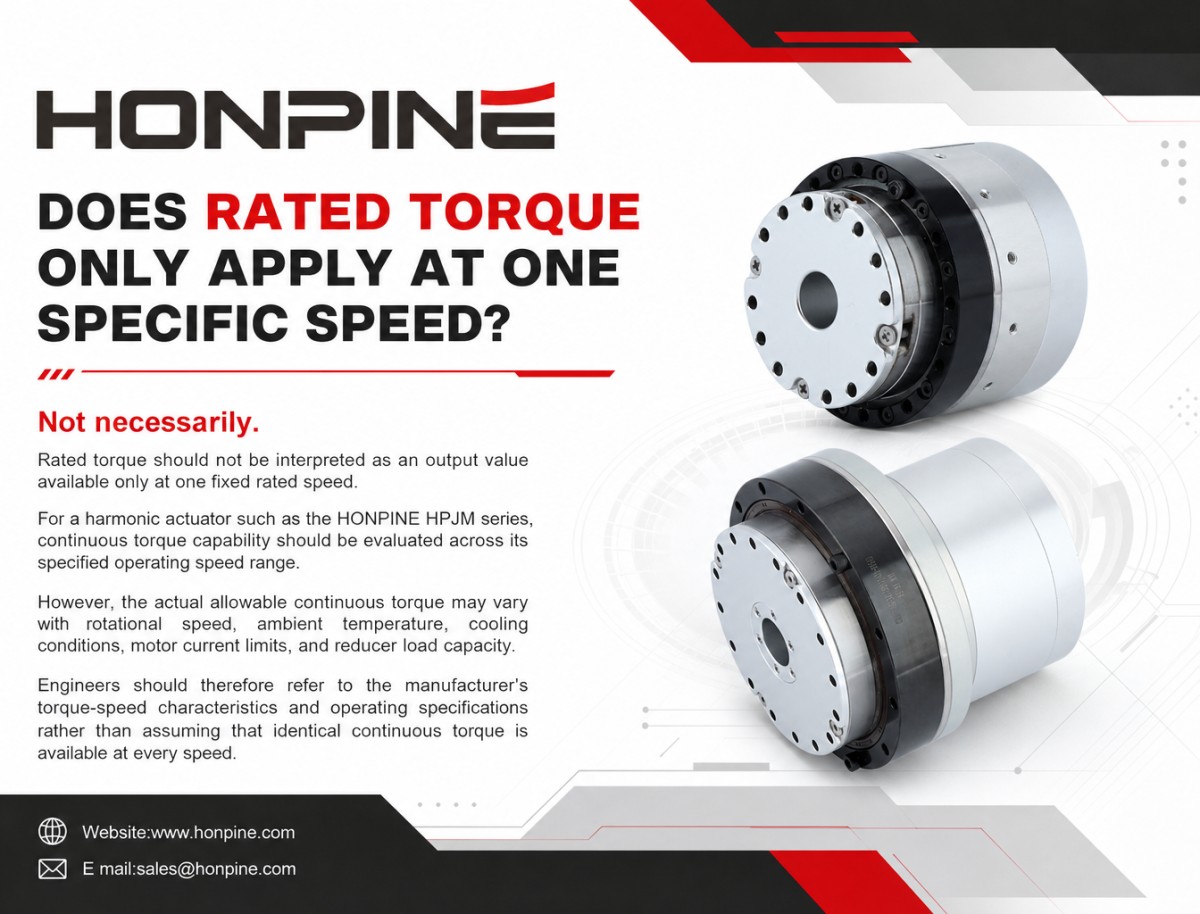
Does Rated Torque Only Apply at One Specific Speed?
Not necessarily. Rated torque should not be interpreted as an output value available only at one fixed rated speed.
For a harmonic actuator such as the HONPINEHPJM series, continuous torque capability should be evaluated across its specified operating speed range. However, the actual allowable continuous torque may vary with rotational speed, ambient temperature, cooling conditions, motor current limits, and reducer load capacity.
Engineers should therefore refer to the manufacturer's torque-speed characteristics and operating specifications rather than assuming that identical continuous torque is available at every speed.
Typical Applications of Rated Torque
Rated torque is particularly important in applications involving relatively stable loads and extended operating periods.
For example, humanoid robots require sufficient continuous joint torque to maintain standing postures. Conveyor systems and automated machinery may need to maintain stable output under relatively constant loads. Medical rehabilitation equipment may also require continuous operation within specified load conditions.
In these applications, the continuous operating load should generally remain within the actuator's rated torque under the specified conditions.
2. Intermittent Torque: Handling Periodic High-Load Movements
Intermittent torque refers to the higher output torque that a harmonic actuator can deliver for limited periods under specified duty-cycle conditions.
Unlike rated torque, intermittent torque is not intended for continuous full-load operation. It is designed for applications in which the joint periodically experiences higher loads, followed by lower-load periods or rest intervals.
This capability is particularly relevant to dynamic robotic systems, where joint torque changes throughout each movement cycle.
For example, a product datasheet may specify an intermittent torque value under an S3 intermittent duty cycle, with a defined duty cycle such as 10% or 25%.
The duty cycle indicates the proportion of the specified operating cycle during which the actuator operates under the defined load condition. The actual permissible operating duration and rest period must follow the manufacturer's specifications.
An intermittent torque rating must always be interpreted together with its duty cycle, cycle duration, and operating conditions.
Why Can't Intermittent Torque Be Used for Continuous Operation?
Higher output torque generally requires greater motor current, resulting in increased heat generation.
During intermittent operation, lower-load periods or rest intervals provide opportunities for the actuator to dissipate heat. This helps keep the average thermal load within the specified operating limits.
However, if the actuator continuously operates at its intermittent torque level, heat may accumulate faster than it can be dissipated. This can cause excessive temperature rise and accelerate the aging of motor insulation, reducer components, and bearings.
Repeated operation beyond the specified duty cycle may also increase mechanical stress and affect long-term positioning stability.
Therefore, intermittent torque should not be treated as an alternative to rated torque. Its use must comply with the specified duty cycle and thermal limitations.
Why Is Intermittent Torque Important for Humanoid Robots?
Humanoid robot joints experience significantly changing loads during walking, running, squatting, standing up, and other dynamic movements.
Consider the leg joints during a walking cycle. Different movement phases impose different torque requirements:
Stance phase: The leg joints support body weight and maintain balance.
Push-off phase: The joints generate higher torque to propel the body forward.
Swing phase: The leg moves forward, with a different load and torque profile.
Landing and impact absorption: The joints respond to changing external forces and dynamic loads.
The push-off and other high-load phases may require torque above the continuous operating level. Whether the actuator can support these repeated movements depends on its intermittent torque capability, duty cycle, thermal performance, and actual motion profile.
Similar requirements occur in quadruped robots during climbing, acceleration, and jumping, as well as in robotic arms that repeatedly lift and reposition workpieces.
For these applications, intermittent torque is an important parameter for evaluating dynamic joint performance.
3. Peak Torque: The Short-Duration Operating Limit
Peak torque is the maximum short-duration torque that a harmonic actuator is designed to deliver or withstand under specified conditions.
It represents a transient operating limit determined by the combined capabilities of the motor, harmonic reducer, output structure, bearings, and other mechanical and electrical components.
The peak torque capability is influenced by several factors, including:
Flexspline strength and allowable deformation in the harmonic reducer.
Mechanical strength of the output flange and shaft.
Motor current limits and electromagnetic characteristics.
Bearing load capacity.
Structural stress limits of the actuator assembly.
Unlike rated torque, peak torque is not a continuous thermal operating rating. It is generally associated with brief transient events, and its allowable duration and frequency must follow the manufacturer's specifications.
What Happens When Peak Torque Is Exceeded?
If the applied torque exceeds the actuator's specified peak torque limit, excessive mechanical or electromagnetic stress may damage internal components.
Depending on the magnitude and duration of the overload, possible consequences include permanent deformation or damage to the harmonic reducer's flexspline, excessive stress on the output flange, bearing damage, and deterioration of motor performance.
Severe overload conditions may also result in increased backlash and permanent loss of positioning accuracy.
Even if an actuator does not fail immediately, repeated overload events may cause cumulative mechanical damage and reduce its service life.
Peak torque should therefore be treated as a short-duration operating limit rather than a normal design target.
When Should Engineers Consider Peak Torque?
Peak torque is relevant when evaluating brief transient conditions, such as sudden external disturbances, short-duration impact loads, emergency deceleration, or unexpected contact.
For humanoid robots, engineers may need to consider transient loads caused by unexpected contact or impact during operation.
However, planned movements such as walking, running, jumping, and squatting should not rely on peak torque as their normal operating capability. These movements must be evaluated using the appropriate rated and intermittent torque specifications, together with the actual load profile.
4. Rated Torque vs. Intermittent Torque vs. Peak Torque: Understanding the Differences
Although all three parameters describe the torque capability of a harmonic actuator, they correspond to different operating conditions.
The fundamental difference is straightforward:
Rated torque defines the continuous output capability of the actuator.
Intermittent torque defines the higher torque available under specified duty-cycle conditions.
Peak torque defines the short-duration torque limit under specified transient conditions.
A harmonic actuator with a high peak torque rating does not necessarily have a high rated torque. Likewise, a high intermittent torque value does not mean that the actuator can maintain that output continuously.
When comparing different actuators, engineers should examine all three ratings and understand the conditions under which each value is specified.
5. How Should Engineers Select a Harmonic Actuator Based on Torque Requirements?
Selecting a harmonic actuator requires more than comparing maximum torque values. Engineers should evaluate the actual load profile of the robot joint throughout its operating cycle.
A practical evaluation involves three main considerations.
Evaluate the Continuous Load
First, calculate the torque required during long-duration operation.
For example, a humanoid robot may need to maintain a standing posture for an extended period. The leg joints must continuously support the body and maintain stability.
The calculated continuous load should be compared with the actuator's rated torque to ensure that the joint can operate within its specified thermal and mechanical limits.
Evaluate Periodic High-Load Movements
Next, identify the movement phases that require higher torque.
For humanoid robots, these may include push-off, squatting, and standing up. For robotic arms, they may include lifting and moving workpieces.
Engineers should evaluate the required torque, operating duration, cycle frequency, and duty cycle, then compare these conditions with the actuator's intermittent torque specifications.
Check Transient Loads
Finally, evaluate brief overloads caused by impacts, sudden external forces, or emergency deceleration.
The maximum transient torque should remain within the actuator's specified peak torque limit, with an appropriate engineering safety margin.
Peak torque should not be used as the basis for sizing a joint that needs to operate at high torque continuously or repeatedly.
Consider the Complete Operating Profile
Torque is only one part of harmonic actuator selection. Engineers should also consider operating speed, acceleration, motion profile, ambient temperature, cooling conditions, radial and axial loads, overturning moments, torsional stiffness, positioning accuracy, and reducer service life.
For dynamic robotic applications, thermal performance and mechanical load capacity must be evaluated together.
A suitable harmonic actuator should not only meet the joint's maximum torque requirement but also maintain reliable performance throughout the complete operating cycle.
Conclusion
Rated torque, intermittent torque, and peak torque describe three different aspects of a harmonic actuator's operating capability. Rated torque determines its continuous load capacity, intermittent torque addresses periodic high-load movements, and peak torque defines its short-duration transient limit.
For humanoid robots and other dynamic robotic systems, understanding these distinctions helps engineers avoid improper actuator sizing and excessive operating loads. Rather than selecting a harmonic actuator based solely on its maximum torque, engineers should evaluate the complete motion profile, duty cycle, thermal conditions, and mechanical requirements of the joint.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
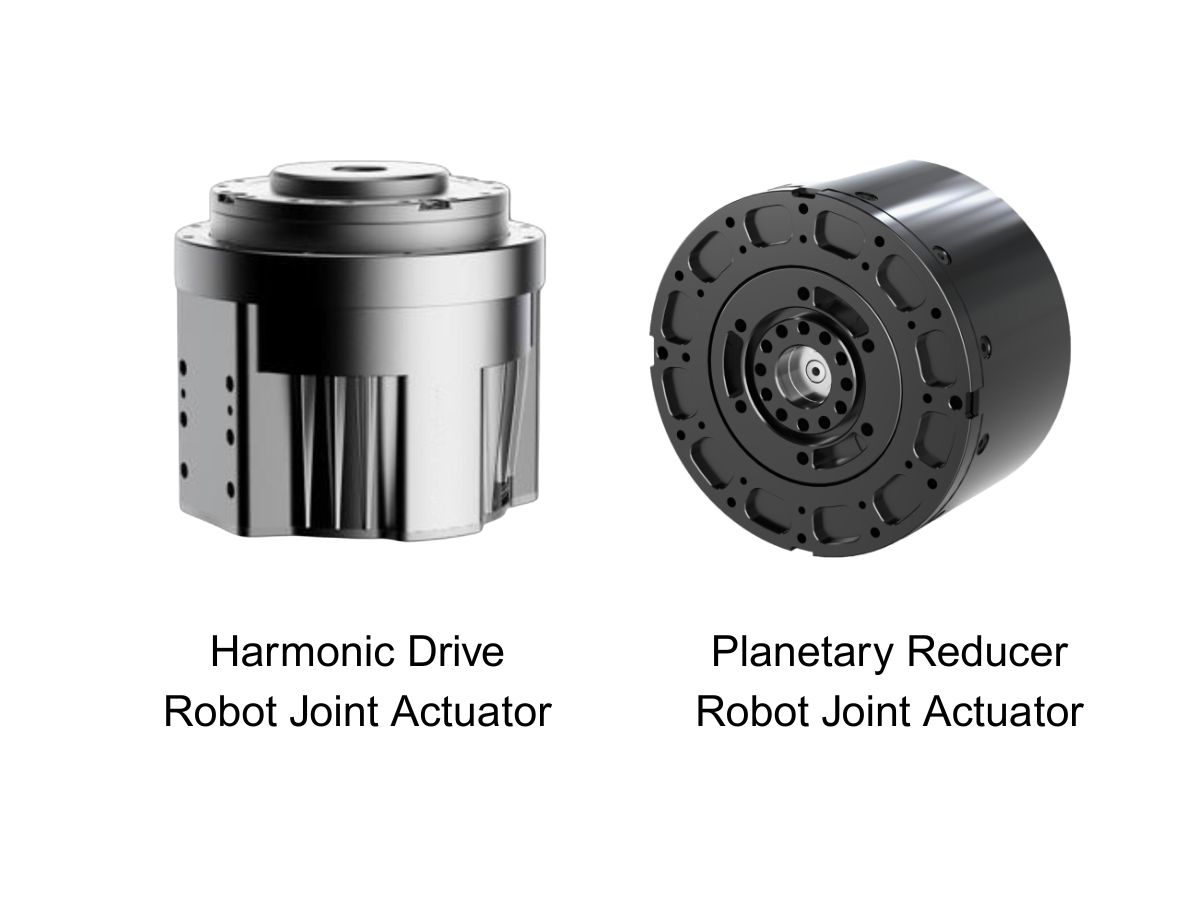
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
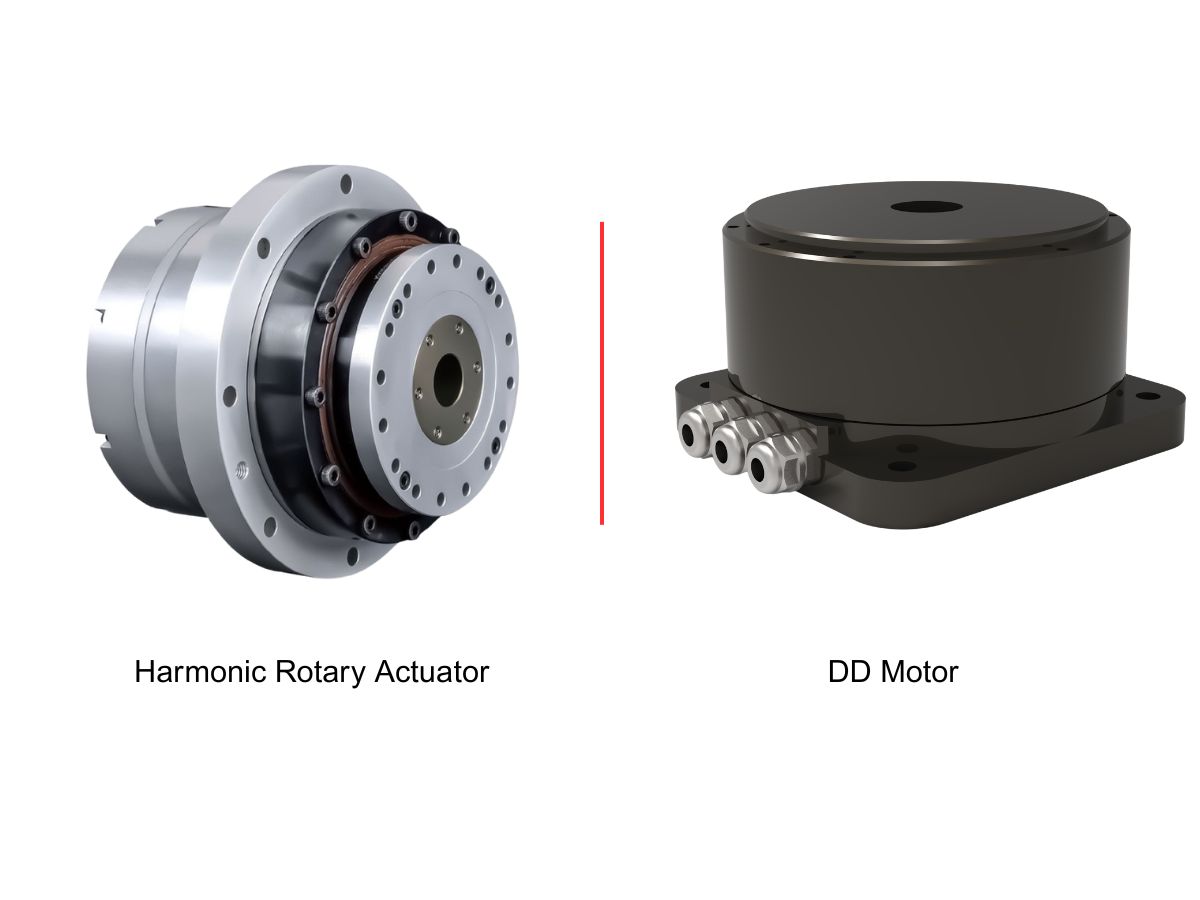
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
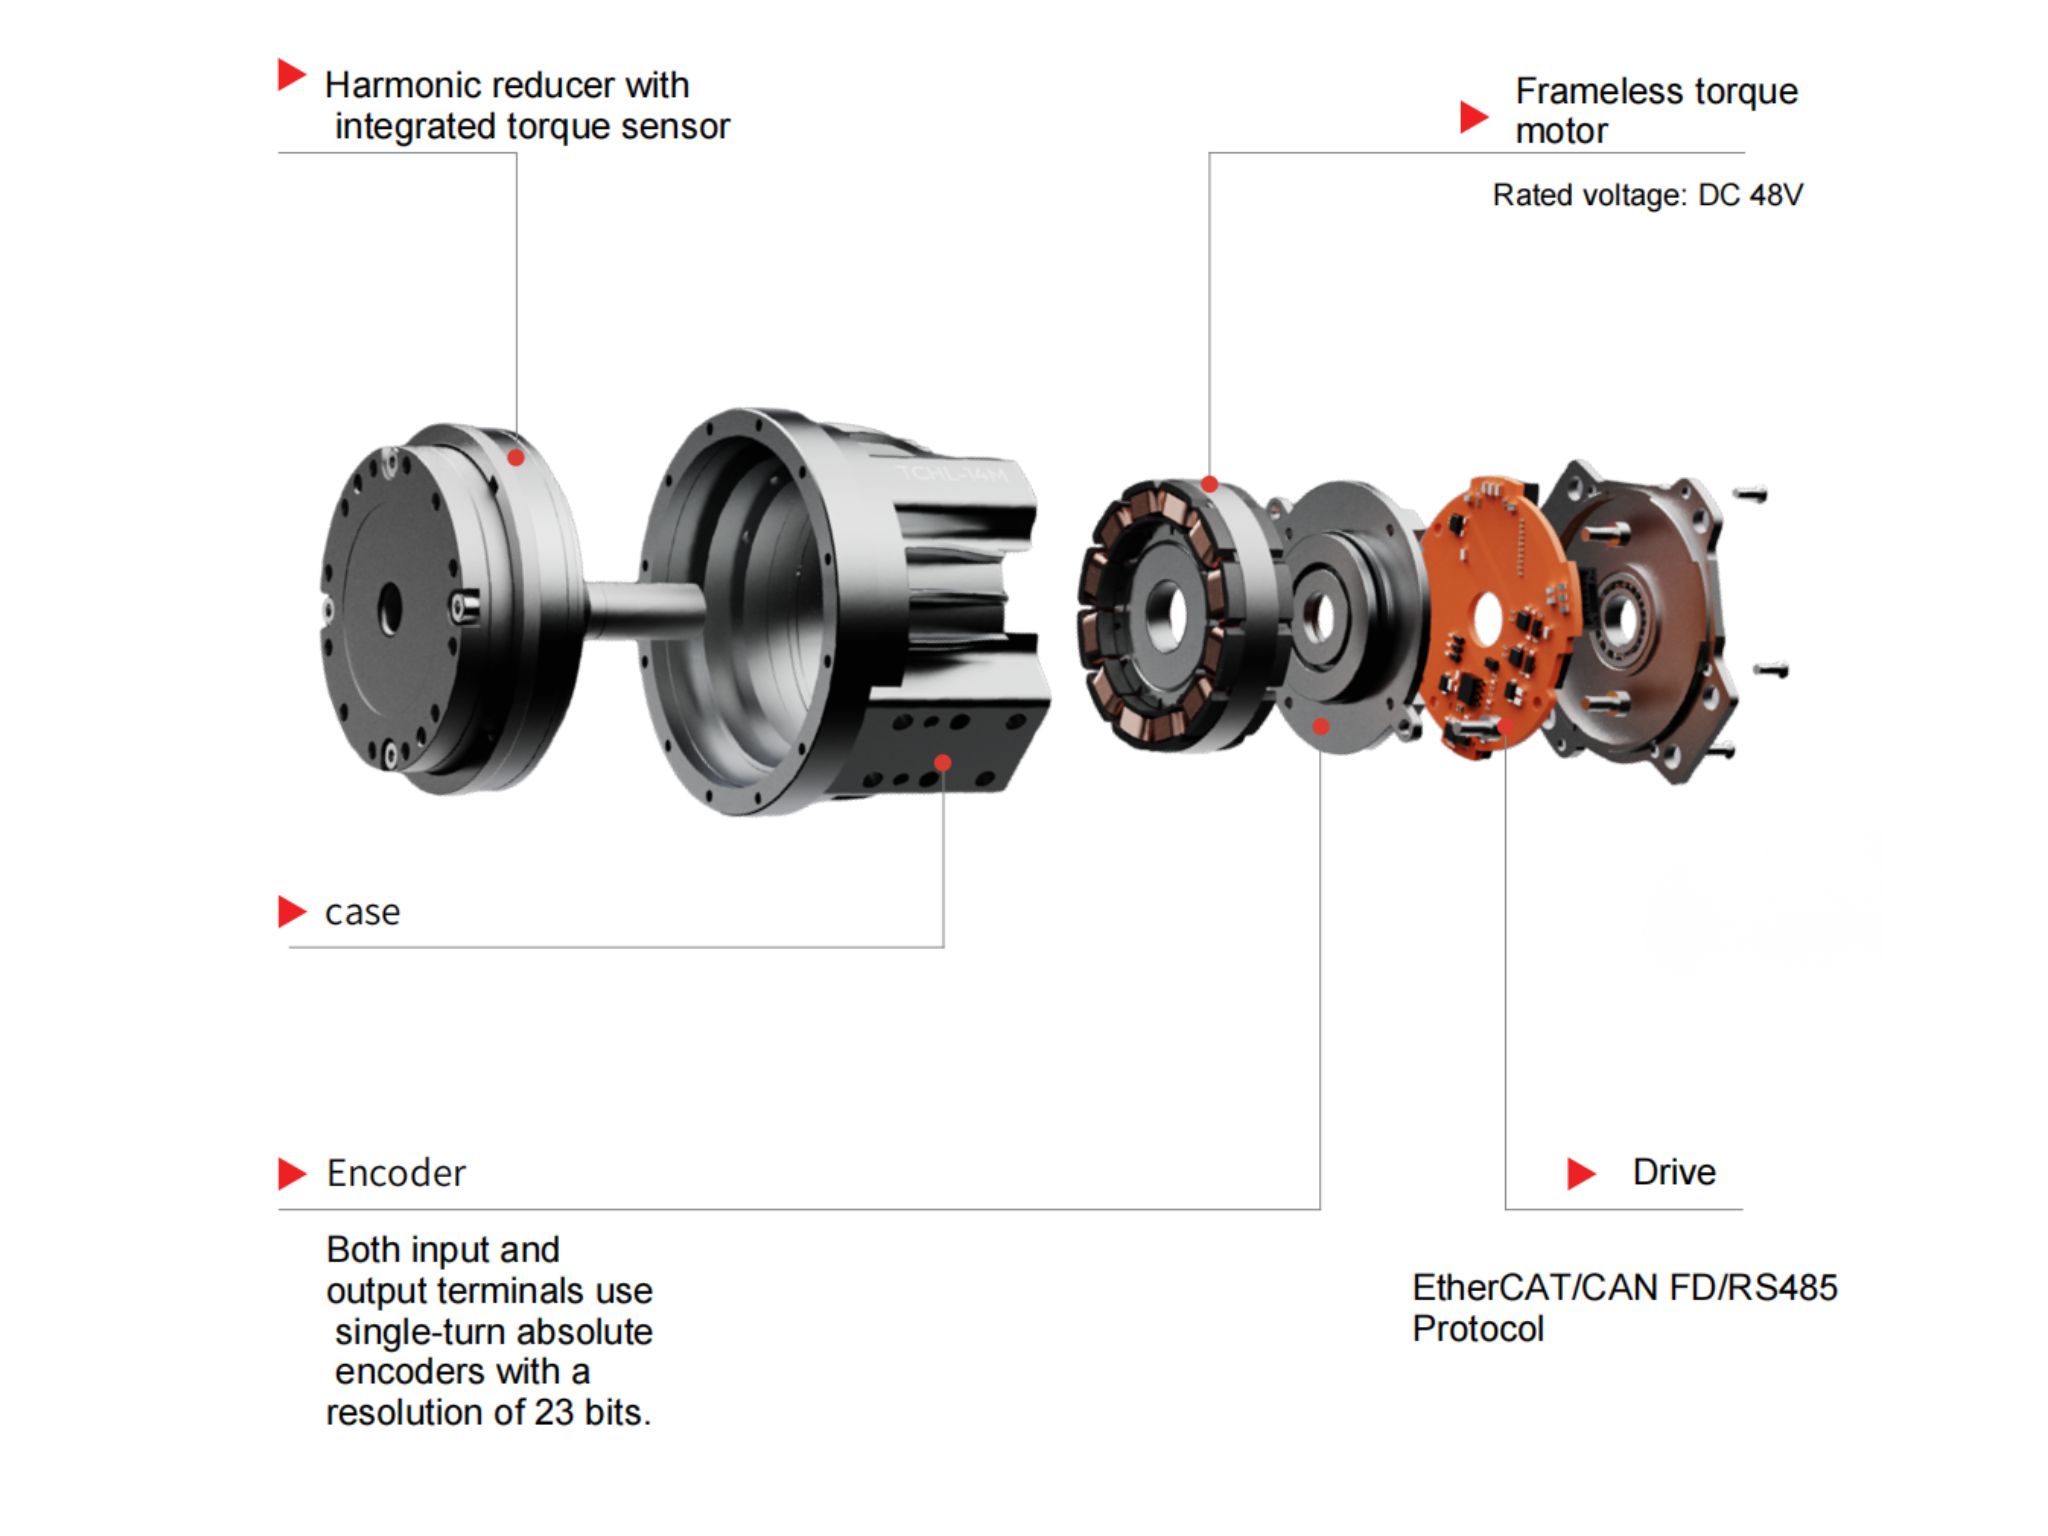
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 How to Match Planetary Gearboxes with Servo Motors from 6 Major Brands?Selecting the right planetary gearbox for a servo motor involves more than matching motor power and reduction ratio. Engineers must also consider output torque, load inertia, backlash, torsional stiffness, and mounting compatibility to ensure reliable transmission performance. Different servo motor brands, including Inovance, Estun, Panasonic, Mitsubishi, Yaskawa, and MOONS', may have different shaft dimensions and mounting interfaces. So, how can engineers identify the right planetary gearbox for each servo motor? This guide explores the key matching principles, essential calculations, and practical selection considerations to help you make an informed decision.
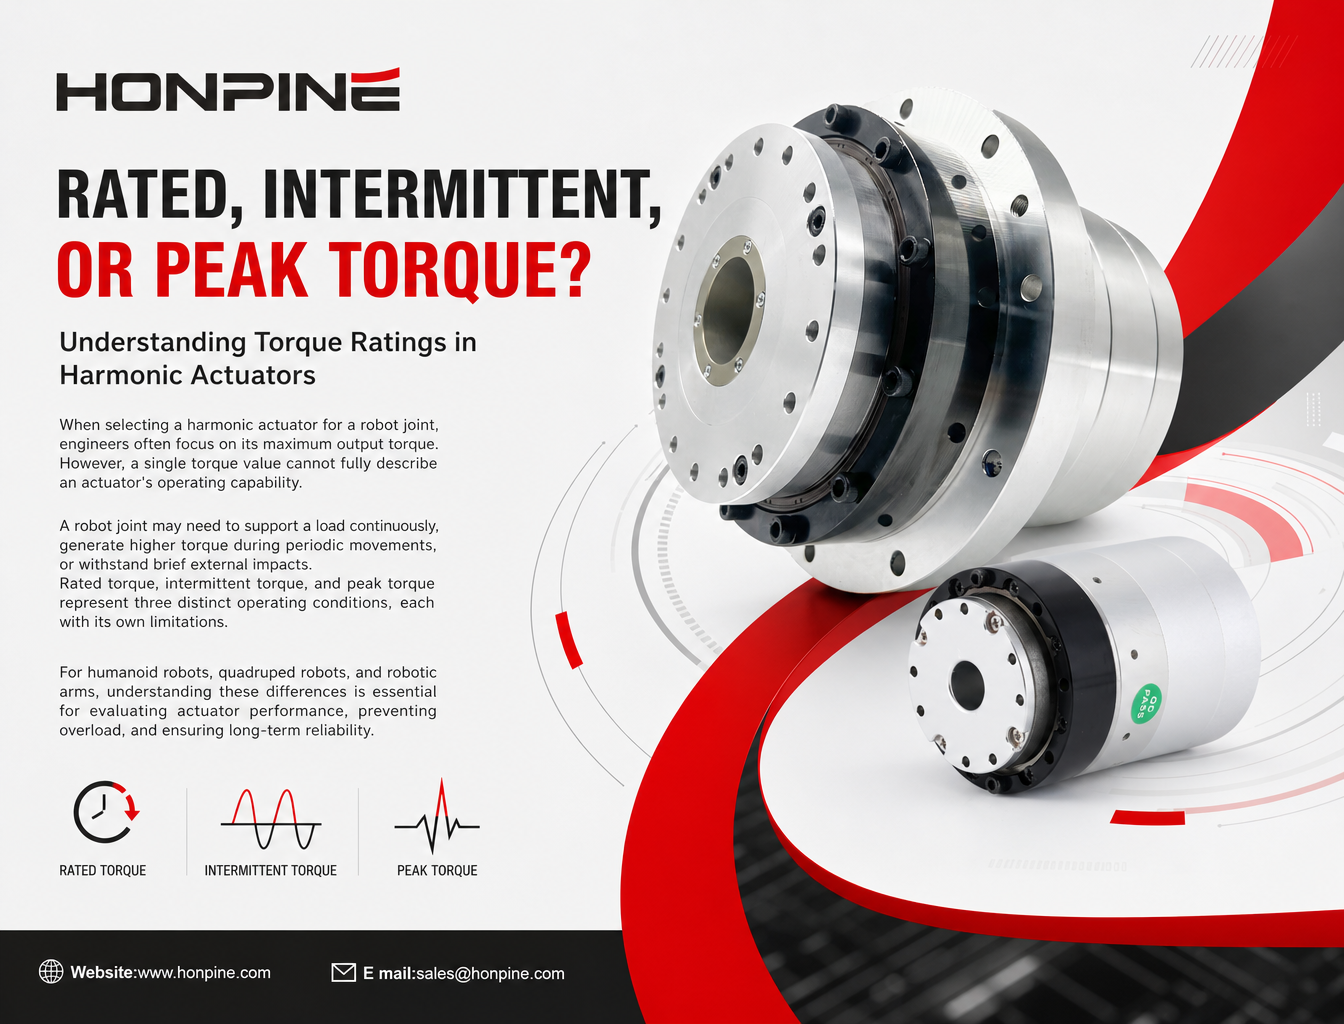
 What Are Rated, Intermittent, and Peak Torque in a Harmonic Actuator?When selecting a harmonic actuator for a robot joint, engineers often focus on its maximum output torque. However, a single torque value cannot fully describe an actuator's operating capability. A robot joint may need to support a load continuously, generate higher torque during periodic movements, or withstand brief external impacts. Rated torque, intermittent torque, and peak torque represent three distinct operating conditions, each with its own limitations. For humanoid robots, quadruped robots, and robotic arms, understanding these differences is essential for evaluating actuator performance, preventing overload, and ensuring long-term reliability.
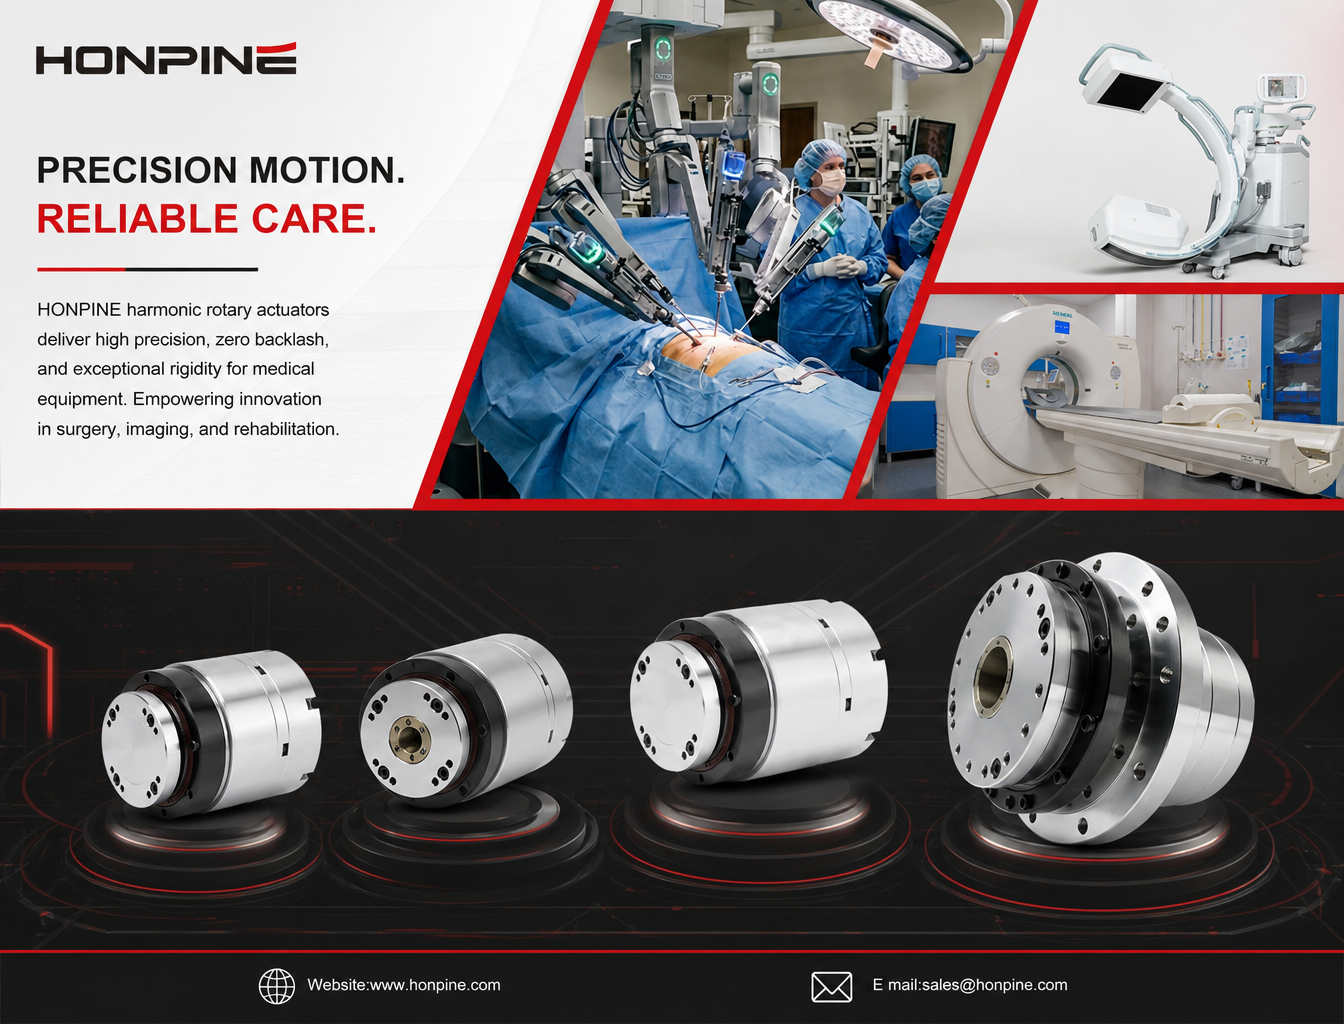
 Harmonic Rotary Actuator for Medical Equipment: ≤10 Arcsec Repeatability and High Overturning StiffnessMedical equipment demands exceptional precision, structural stability, and operational safety from its motion transmission systems. From surgical robots and CT imaging systems to rehabilitation equipment, actuators must deliver consistent positioning accuracy while supporting complex mechanical loads. How can manufacturers achieve both high repeatability and structural rigidity in medical applications? HONPINE harmonic rotary actuators offer repeatability of up to ≤10 arcsec, zero-backlash transmission, high overturning stiffness, and hollow-shaft configurations, providing reliable motion control solutions for next-generation medical equipment.
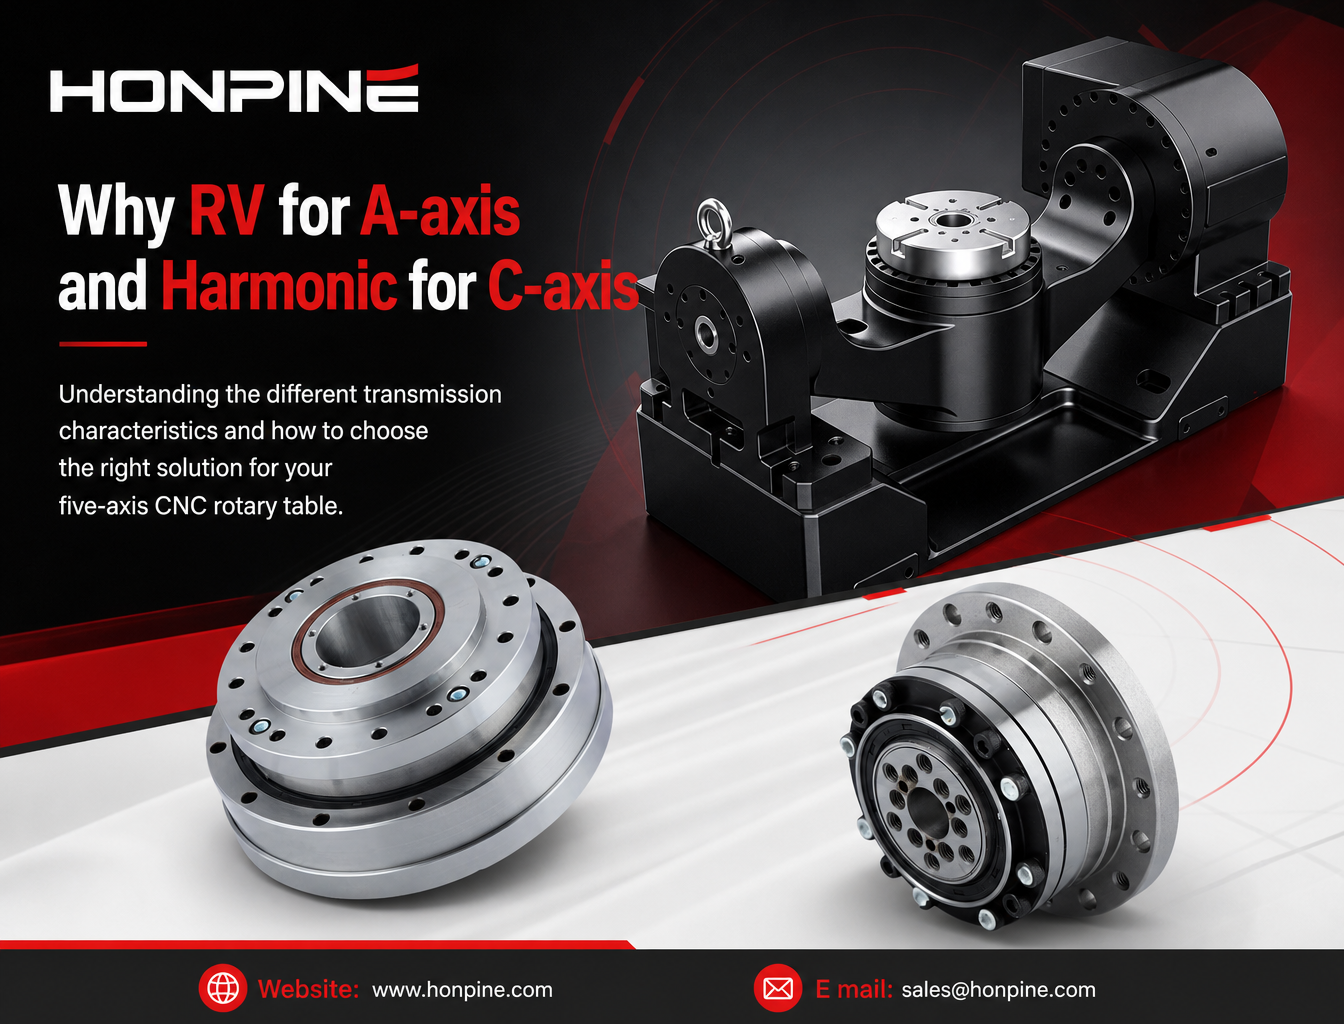
 Why Do Five-Axis CNC Rotary Tables Use Different Reducers for the A-Axis and C-Axis?Five-axis CNC rotary tables require different transmission characteristics for the A-axis and C-axis. While the A-axis often needs high torsional stiffness and load-bearing capacity to support the cradle assembly and workpiece, the C-axis places greater emphasis on low backlash, angular positioning accuracy, and dynamic response. This article explains why RV reducers are often considered for A-axis applications and harmonic reducers for C-axis applications, covering their working principles, mechanical advantages, output-side feedback, and key selection criteria for CNC machine tool manufacturers.
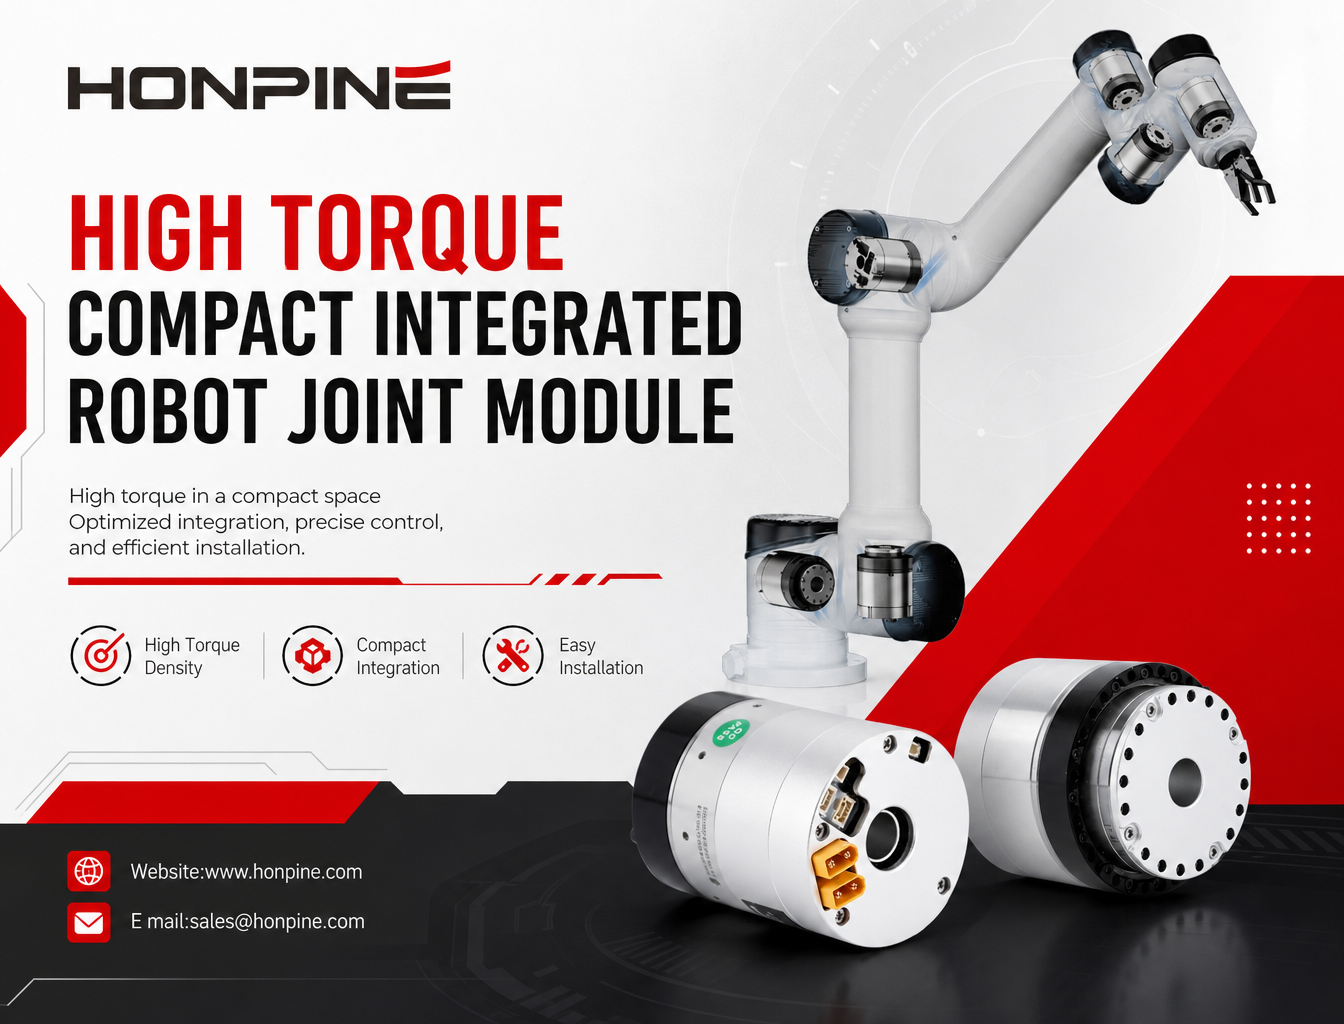
 How Does the HONPINE HPJM Integrated Robot Joint Module Deliver High Torque in a Compact Space?Learn how to optimize installation space while achieving high torque density in robotic joints. This article explores how the HONPINE HPJM integrated robot joint module uses integrated components, hollow-shaft cable routing, compact electrical connectors, and optimized mechanical mounting structures to reduce unnecessary space in humanoid robots and robotic arms.
 Harmonic Gear Motor vs. Harmonic Actuator: What Are the Differences?This article explains the differences between harmonic gear motors and harmonic actuators from the perspectives of product design, system integration, feedback and control functions, installation, and application requirements. Since manufacturers may use these product names differently, it also explores how to evaluate their actual configurations and select the right precision motion solution for robotics and industrial automation.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 How to Match Planetary Gearboxes with Servo Motors from 6 Major Brands?Selecting the right planetary gearbox for a servo motor involves more than matching motor power and reduction ratio. Engineers must also consider output torque, load inertia, backlash, torsional stiffness, and mounting compatibility to ensure reliable transmission performance. Different servo motor brands, including Inovance, Estun, Panasonic, Mitsubishi, Yaskawa, and MOONS', may have different shaft dimensions and mounting interfaces. So, how can engineers identify the right planetary gearbox for each servo motor? This guide explores the key matching principles, essential calculations, and practical selection considerations to help you make an informed decision.
 What Are Rated, Intermittent, and Peak Torque in a Harmonic Actuator?When selecting a harmonic actuator for a robot joint, engineers often focus on its maximum output torque. However, a single torque value cannot fully describe an actuator's operating capability. A robot joint may need to support a load continuously, generate higher torque during periodic movements, or withstand brief external impacts. Rated torque, intermittent torque, and peak torque represent three distinct operating conditions, each with its own limitations. For humanoid robots, quadruped robots, and robotic arms, understanding these differences is essential for evaluating actuator performance, preventing overload, and ensuring long-term reliability.
 Why Do Five-Axis CNC Rotary Tables Use Different Reducers for the A-Axis and C-Axis?Five-axis CNC rotary tables require different transmission characteristics for the A-axis and C-axis. While the A-axis often needs high torsional stiffness and load-bearing capacity to support the cradle assembly and workpiece, the C-axis places greater emphasis on low backlash, angular positioning accuracy, and dynamic response. This article explains why RV reducers are often considered for A-axis applications and harmonic reducers for C-axis applications, covering their working principles, mechanical advantages, output-side feedback, and key selection criteria for CNC machine tool manufacturers.
 How Does the HONPINE HPJM Integrated Robot Joint Module Deliver High Torque in a Compact Space?Learn how to optimize installation space while achieving high torque density in robotic joints. This article explores how the HONPINE HPJM integrated robot joint module uses integrated components, hollow-shaft cable routing, compact electrical connectors, and optimized mechanical mounting structures to reduce unnecessary space in humanoid robots and robotic arms.
 Harmonic Gear Motor vs. Harmonic Actuator: What Are the Differences?This article explains the differences between harmonic gear motors and harmonic actuators from the perspectives of product design, system integration, feedback and control functions, installation, and application requirements. Since manufacturers may use these product names differently, it also explores how to evaluate their actual configurations and select the right precision motion solution for robotics and industrial automation.
 HONPINE JM Fourth-Generation Frameless Torque Motor: 30% Higher Torque Density and 10% Lower Operating TemperatureAs robotics technology advances, frameless torque motors are facing increasingly demanding requirements for torque density, motion stability, and thermal management. The HONPINE JM fourth-generation frameless torque motor achieves 30% higher torque density and 10% lower operating temperature through improvements in electromagnetic design, core materials, and winding technology. With torque ripple controlled below 1%, it delivers smoother low-speed operation and improved motion consistency, making it suitable for demanding applications such as surgical robots, humanoid robots, and precision automation equipment. How does HONPINE achieve these performance improvements? Let's take a closer look.
 How to Select a Harmonic Reducer: 9 Key Factors You Need to KnowWhy are more robotics companies choosing integrated robot joint modules instead of traditional distributed drive systems? As humanoid robots, collaborative robots, and rehabilitation exoskeletons continue to evolve, manufacturers are looking for more compact, lightweight, and easier-to-integrate motion solutions. An integrated robot joint module combines essential components such as a frameless torque motor, harmonic reducer, servo drive, encoders, and output bearing into a single assembly. This architecture can reduce mechanical complexity, simplify wiring, improve motion control integration, and shorten robot development cycles. In this article, Theodore Li, Technical Director at HONPINE, explains six key advantages of integrated robot joint modules and compares them with conventional distributed drive configurations.
 Why Are More Companies Choosing Integrated Robot Joint Modules?Integrated robot joint modules combine motors, harmonic reducers, servo drives, encoders, and output bearings into compact units. This article compares integrated and distributed drive architectures, exploring their differences in torque density, mechanical reliability, motion control, development efficiency, and practical robotic applications.
 Why Are More Robots Moving Away from Traditional Drive Systems to Integrated Hub Servo Motors?As mobile robots evolve toward autonomous navigation, flexible operation, and increasingly complex working environments, traditional distributed drive systems are facing new challenges. Separate motors, gearboxes, couplings, and transmission components can increase chassis complexity and limit available installation space. This is why more robot manufacturers are turning to integrated hub servo motors. By combining key drive components within a compact wheel-end unit, hub motors offer new possibilities for improving drive integration, motion control, and chassis design. In this article, we explore the key performance requirements of mobile robots, explain the advantages of integrated hub motors, and examine how HONPINE's Drive Wheels, Steering Drive Wheels, and Differential Drive Wheels support different AGV and AMR applications.