










High Precision Robotic Harmonic Joint Actuator with High Positioning Accuracy
● Introduction
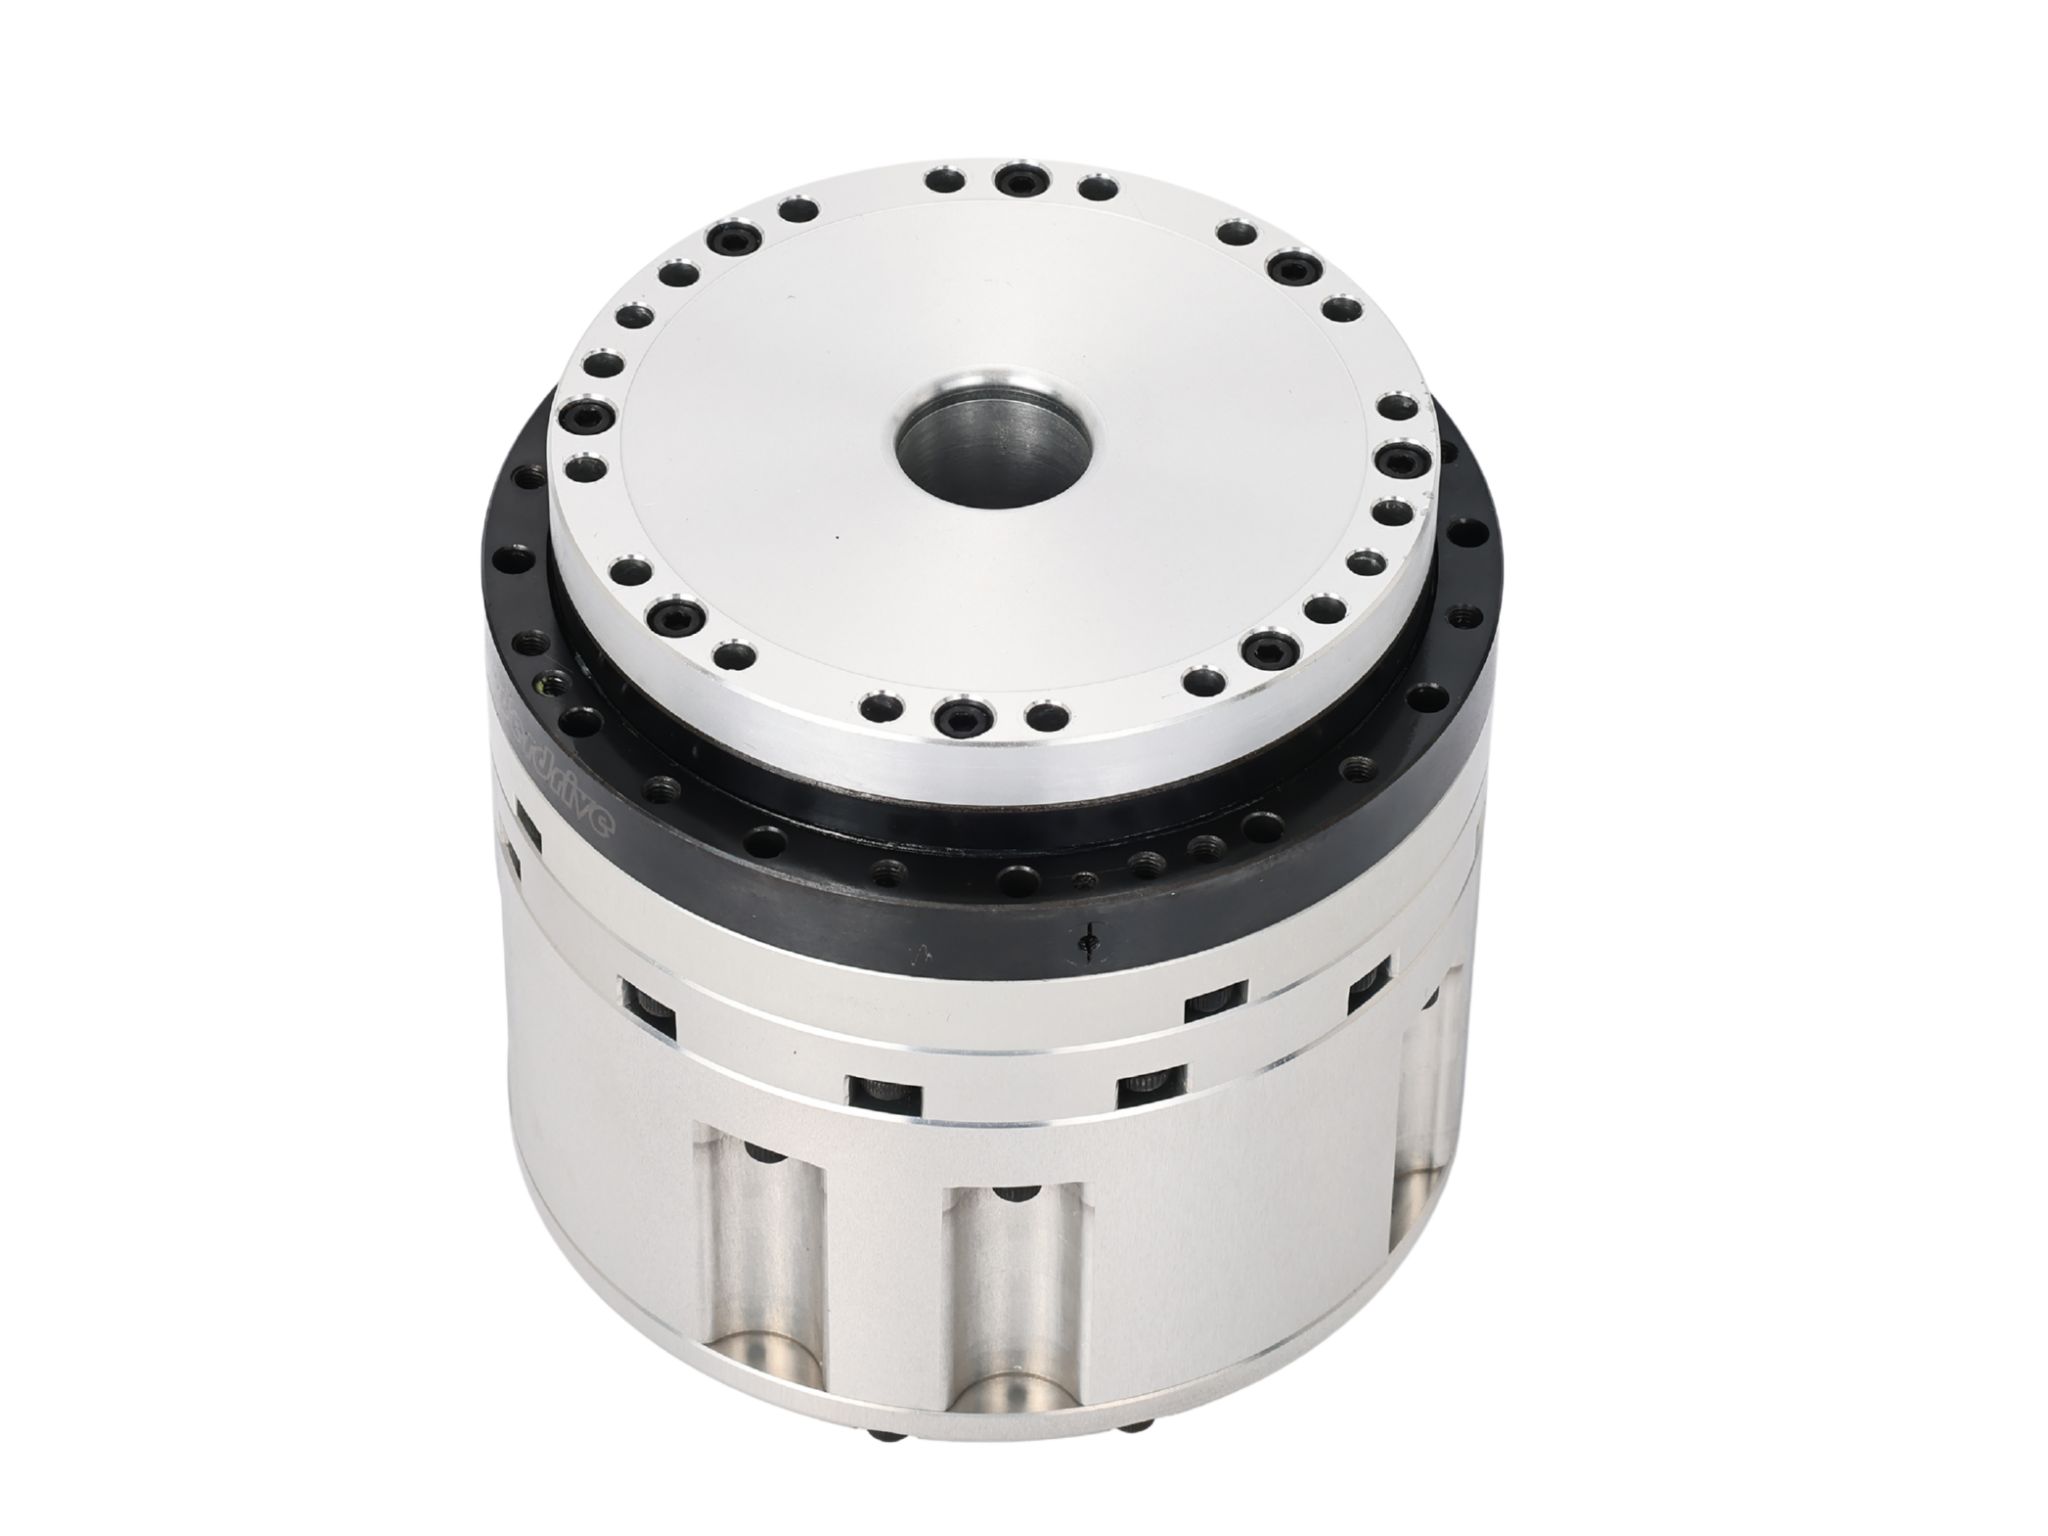
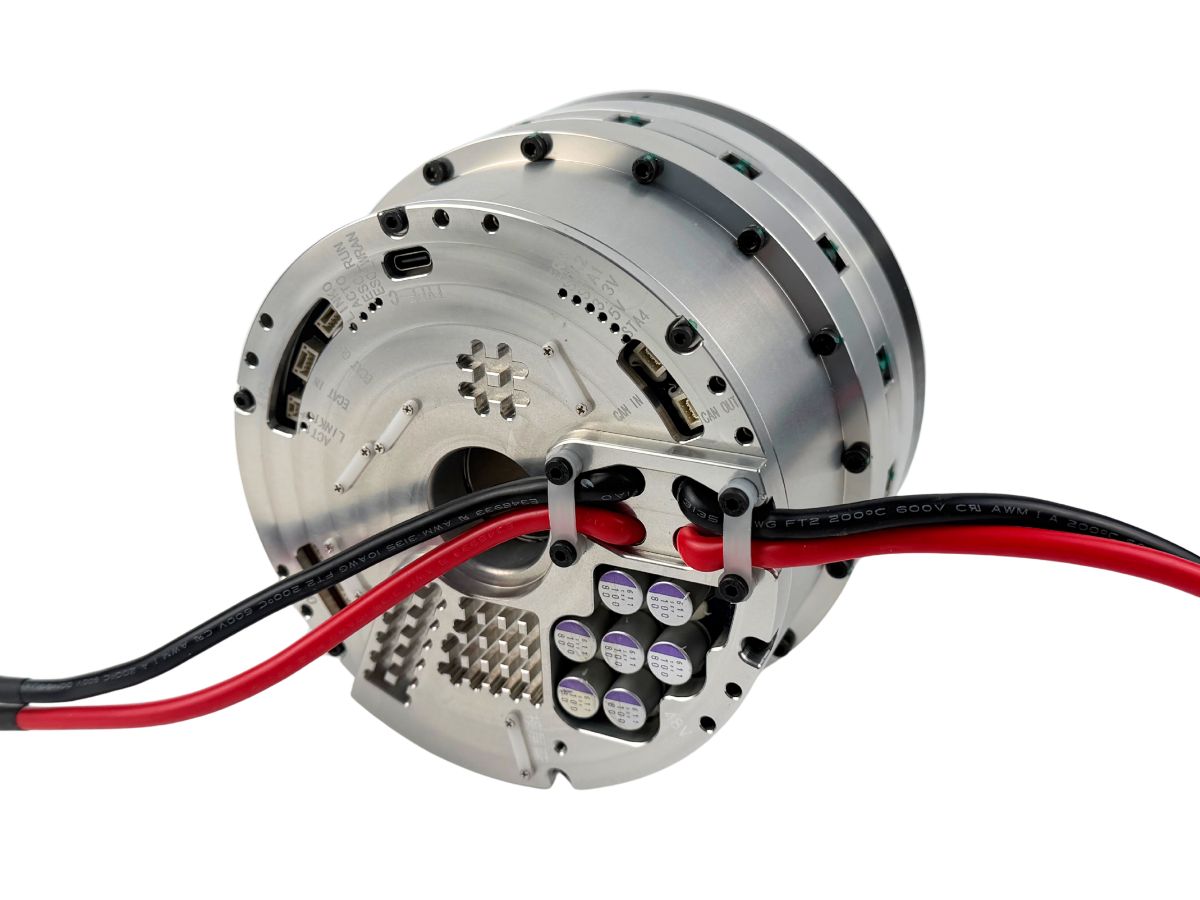
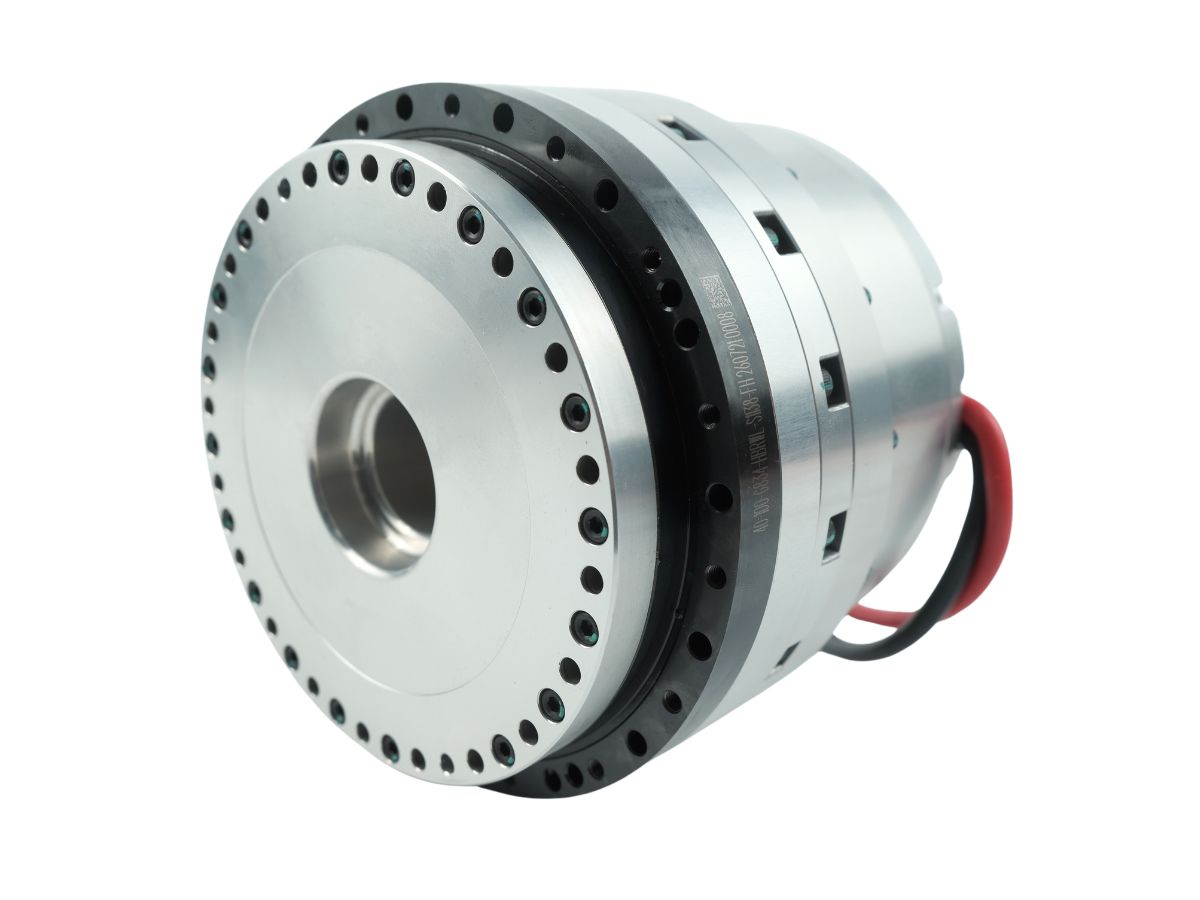
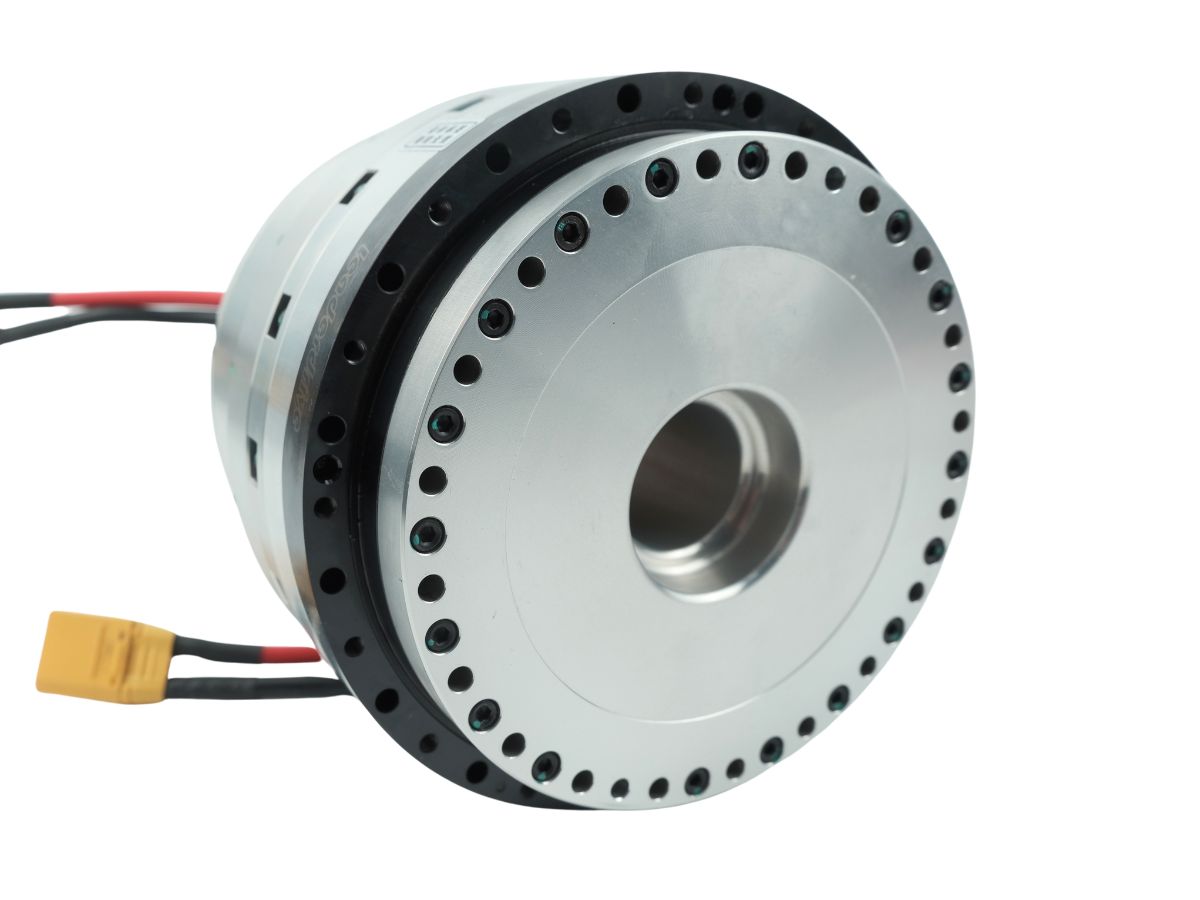
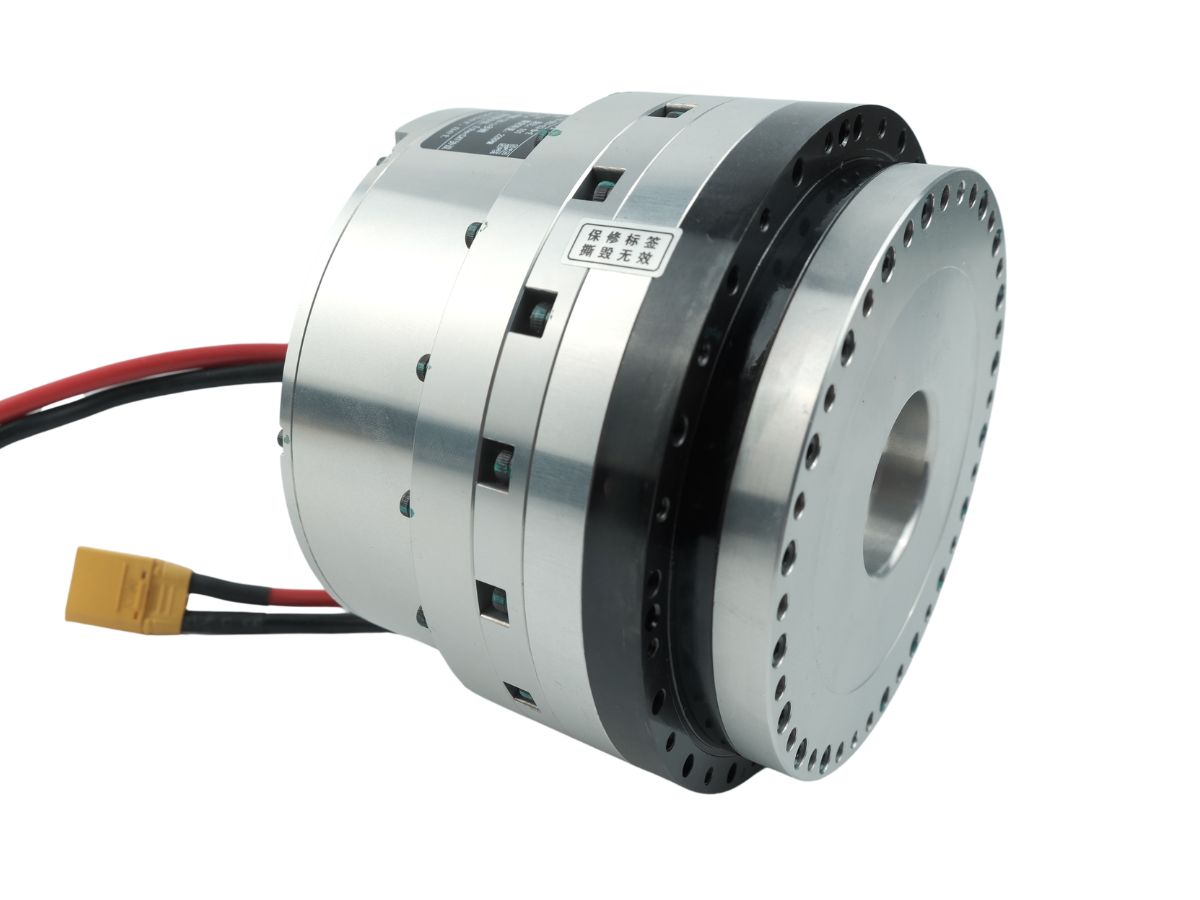
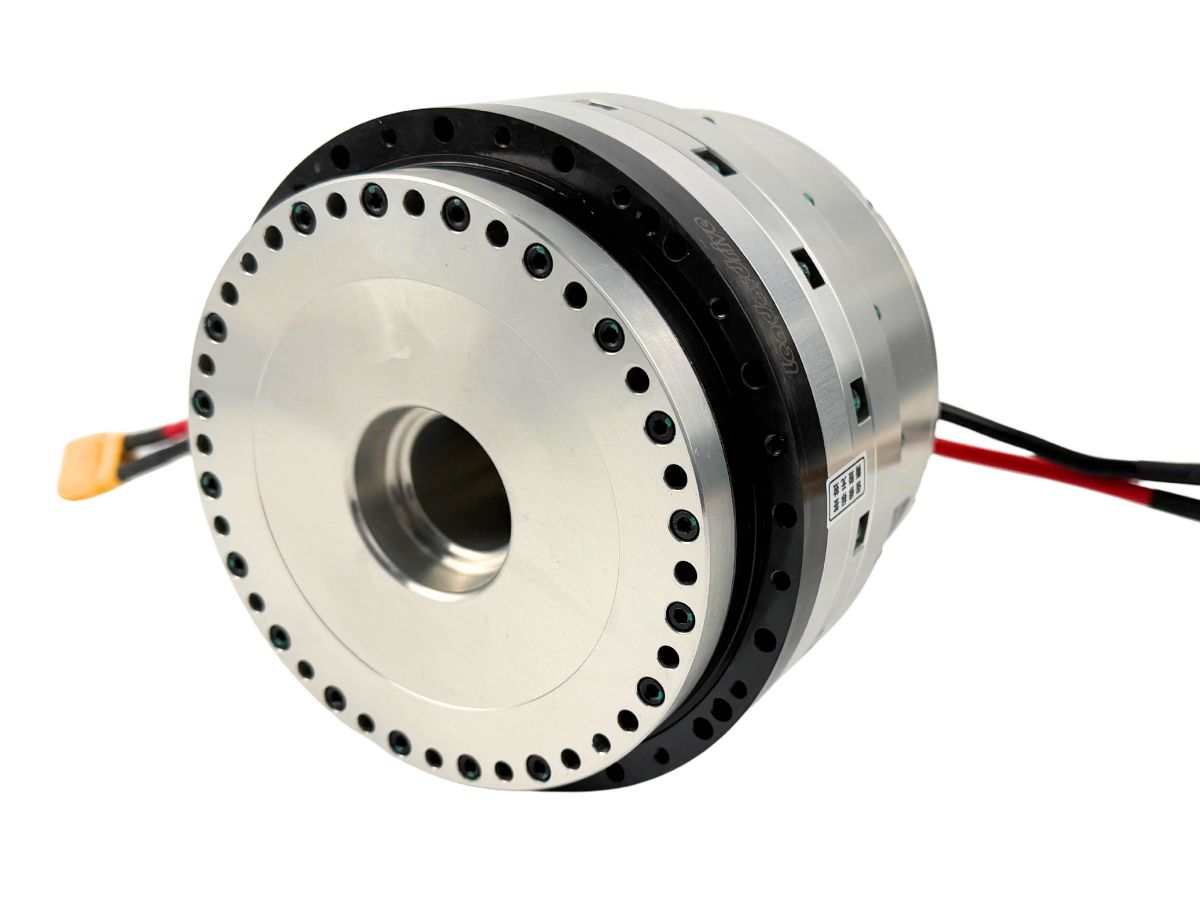
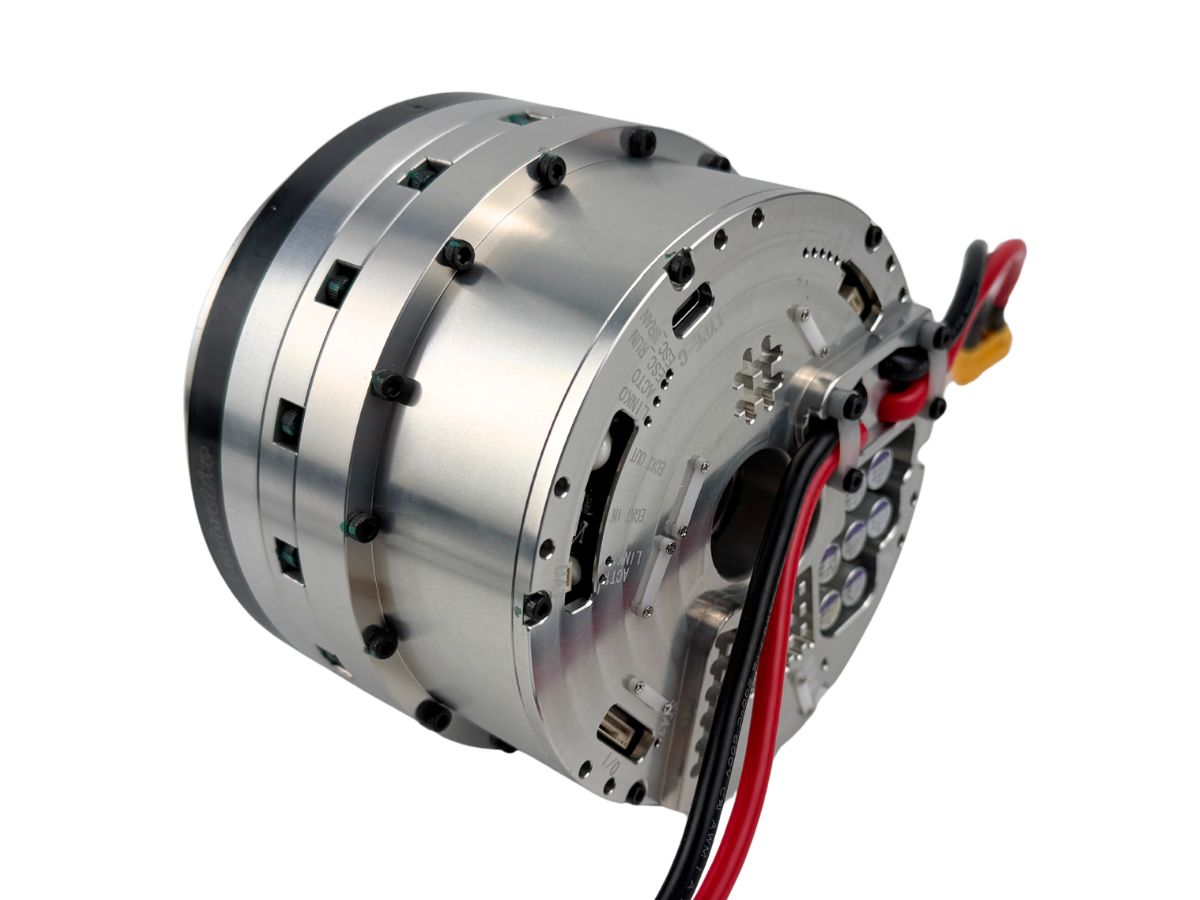
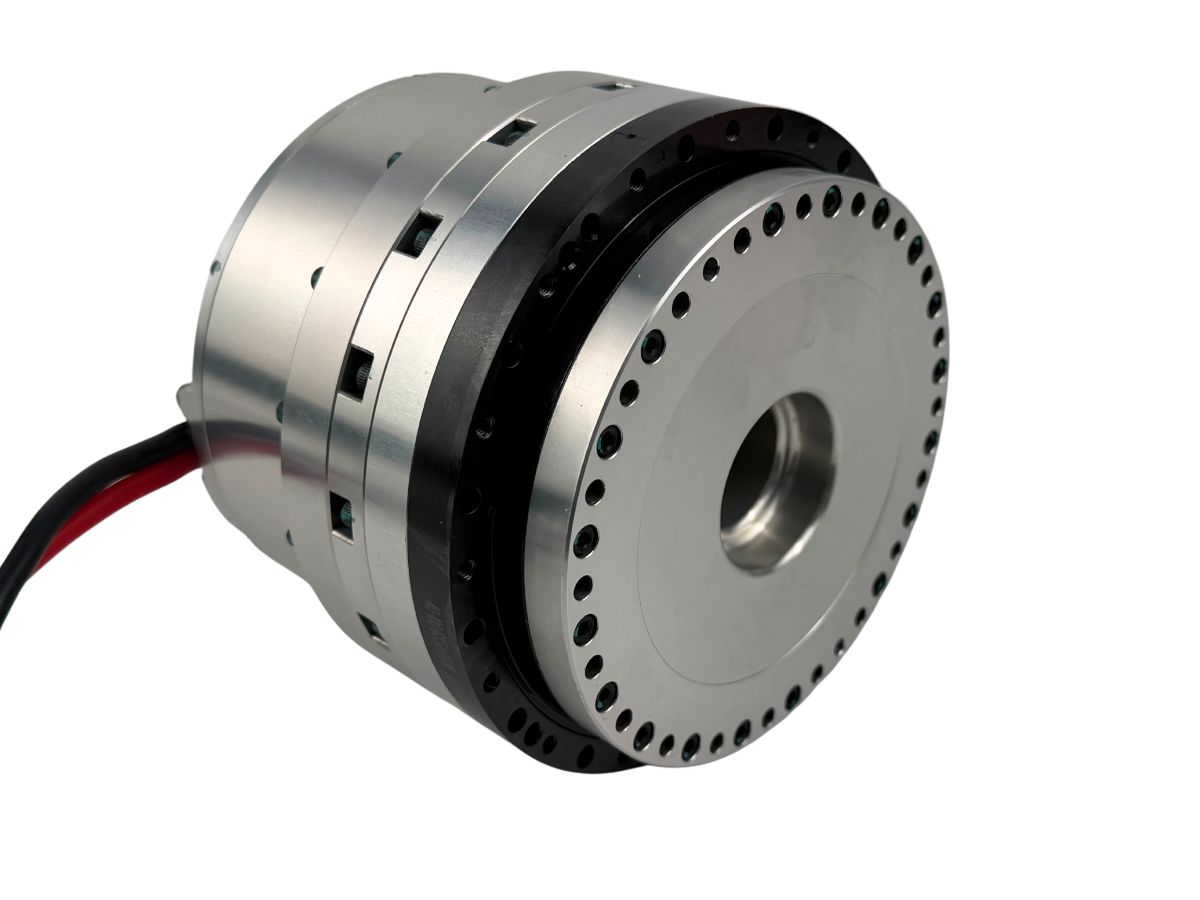
The HAU harmonic joint actuator is particularly suitable for high-precision humanoid robots, special-purpose robots, and robotic arms. By combining high positioning accuracy, industrial-grade overload performance, and a large hollow diameter, the HAU is designed to help robots achieve stable and precise motion in demanding applications.
Features
High Positioning Accuracy
The HONPINE HAU harmonic joint actuator achieves positioning accuracy of less than 15 arcsec and repeatability of less than 1.5 arcsec, providing precise motion control for robotic joints that require consistent positioning performance.
Compared with many similar harmonic joint actuators on the market, the HAU provides a high level of positioning accuracy while maintaining the mechanical strength required for practical robotic applications.
For projects with more demanding accuracy requirements, HONPINE can also provide customized harmonic joint actuator solutions with positioning accuracy below 15 arcsec according to the specific requirements of the application.
Industrial-Grade Overload Performance
The HONPINE HAU harmonic joint actuator is designed for demanding industrial applications, with sufficient mechanical and power redundancy to provide reliable performance under variable loads and dynamic operating conditions.
Its wide peak torque and speed operating range allows the actuator to maintain a more capable dynamic response across different motion speeds. For example, the HAU14 can deliver a peak torque of 35 N·m across a speed range of 0–4,000 rpm.
A wider usable torque-speed range gives the harmonic joint actuator greater flexibility when the robot operates under different motion profiles. Instead of being optimized for only a narrow operating range, the HAU is designed to provide more stable and responsive power output across a broader range of working conditions.
Large Hollow Design for Easier Cable Routing
Another important advantage of the HONPINE HAU harmonic joint actuator is its large hollow design. The hollow diameter ranges from 16.8 mm to 28 mm, which is larger than that of many comparable harmonic joint actuators.
The larger hollow passage provides additional space for routing power cables, signal lines, communication cables, and other wiring through the robot joint. This can simplify cable management and help reduce interference with the mechanical structure, particularly in humanoid robots and robotic arms with compact joint layouts.
For robotic systems where internal cable routing and compact mechanical integration are important, the large hollow design of the HAU provides greater flexibility during joint and robot design.
Specification
Sheet 1




