What’s the Difference Between Single and Dual Encoder Robot Joint Modules?
Should you choose a single or dual encoder robot joint module? The answer depends on your positioning requirements, transmission characteristics, force control strategy and budget.
A dual encoder system measures both the motor position and the actual joint output position. This additional feedback can improve control performance, but achieving those benefits requires suitable hardware, control algorithms and calibration.
This guide explains how dual encoder robot joint modules work, when a single encoder may be sufficient, and what dual feedback can contribute to precision, force estimation and functional safety.
What Is a Dual Encoder Robot Joint Module?
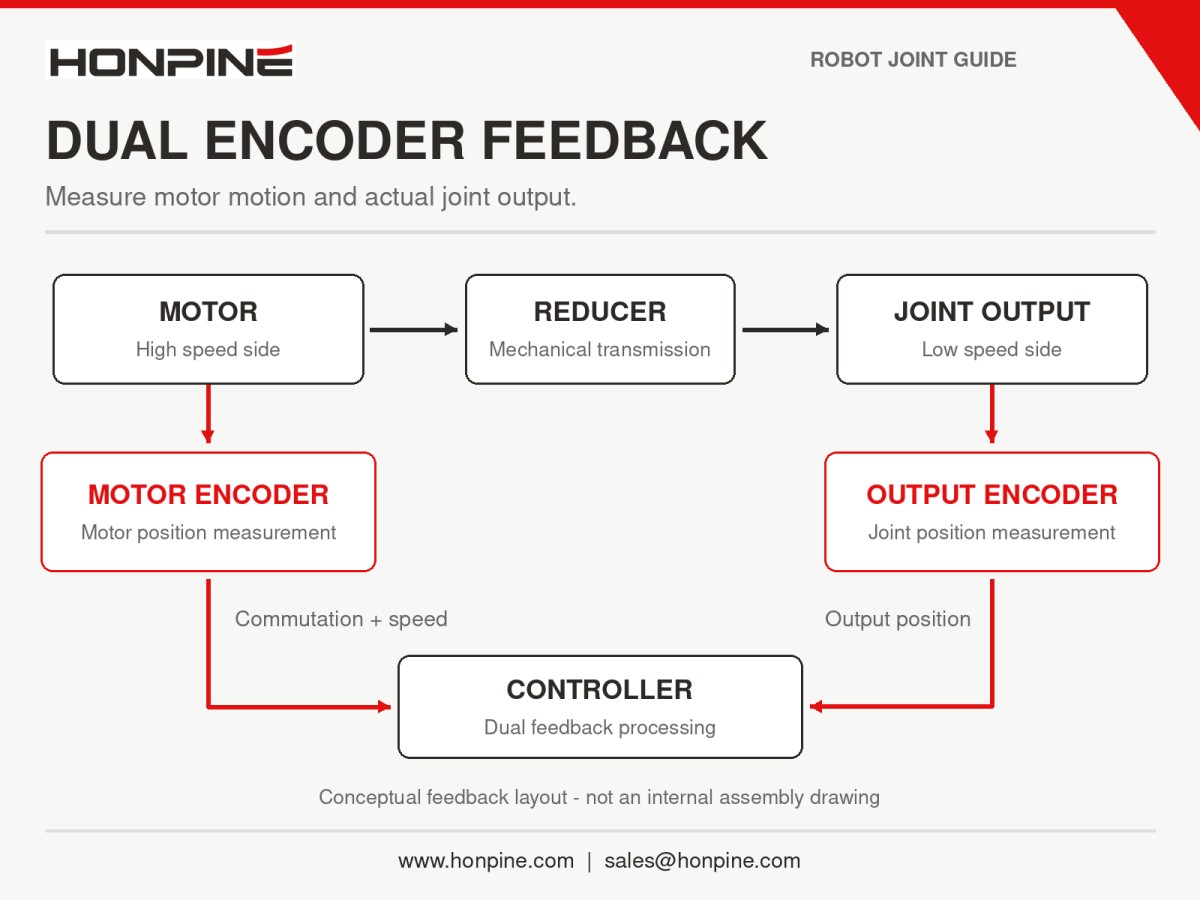
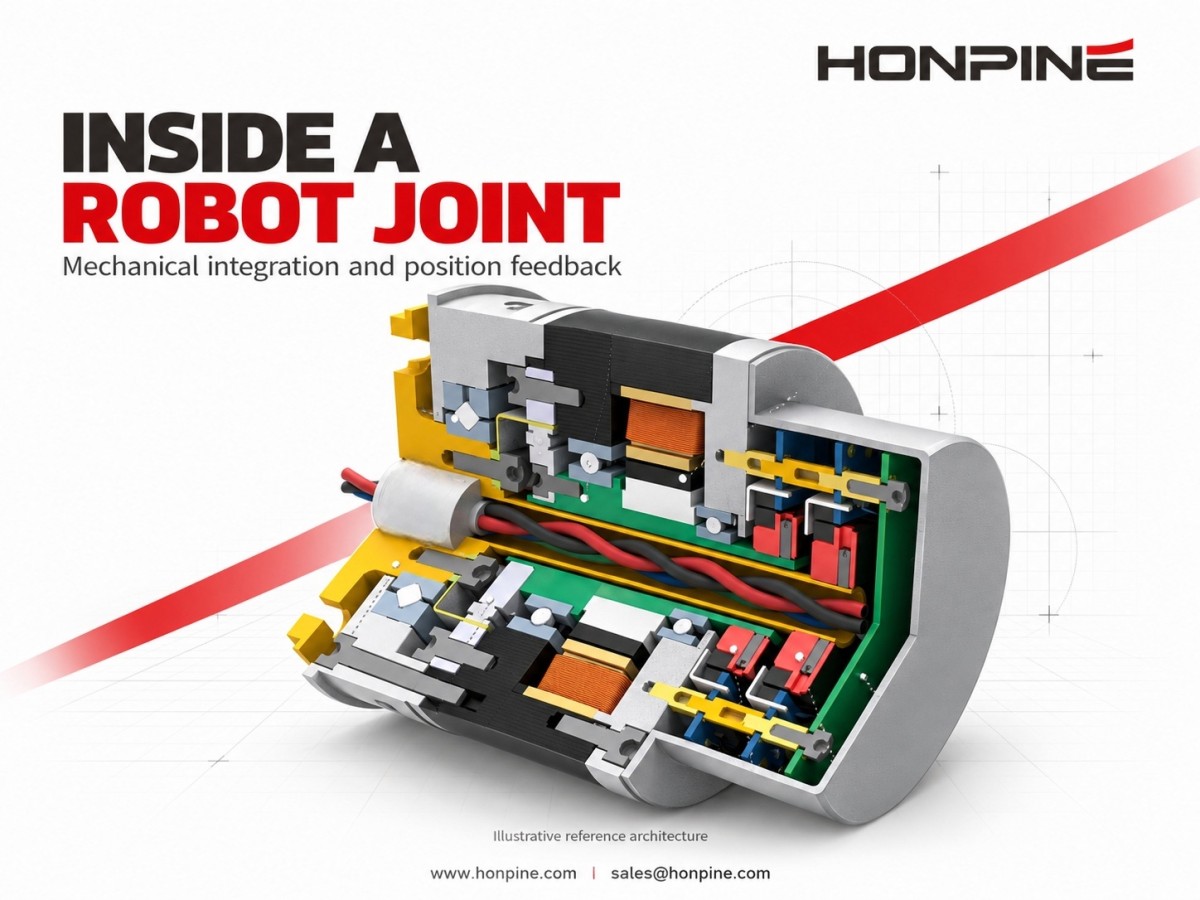
A dual encoder robot joint module typically includes two angular position sensors located on opposite sides of the transmission.
Motor-Side Encoder
The motor-side encoder measures the rotor angle at the motor shaft, on the high-speed side of the reducer.
Its feedback is commonly used for motor commutation and velocity control.
Output-Side Encoder
The output-side encoder measures the actual output angle at the reducer output shaft or joint output flange, on the low-speed side.
It provides direct feedback on the joint position rather than relying only on a calculation based on motor rotation.
Together, these encoders provide motor-side and load-side position information. With a compatible controller, they can support a dual-loop control architecture. Installing two encoders alone does not automatically establish dual-loop control.
What Are the Main Benefits of Dual Encoder Robot Joint Modules?
The main benefit is greater visibility into transmission behavior. By measuring the actual output position, the controller can reduce the effects of errors that a motor-side encoder cannot directly observe.
Common sources of transmission-related positioning error include:
Backlash and lost motion: During direction changes, motor movement may not immediately produce the expected output movement.
Elastic deformation: Reducers, belts, couplings and other transmission components can twist under load.
Transmission error: Manufacturing and assembly variations can cause deviations from ideal angular transmission, even when the nominal gear ratio is fixed.
Temperature and wear: Changes in operating conditions and component condition can affect transmission behavior.
With a single motor-side encoder, the output angle is estimated from motor position and the reduction ratio. For a reduction ratio defined as motor revolutions per output revolution:
Estimated output angle = Motor angle ÷ Reduction ratio
This calculation must also account for rotation direction and reference offsets. It does not directly measure load-side deflection or lost motion.
More Accurate Output Position Control
In a typical dual-loop arrangement, the output encoder supplies feedback to the outer position loop, while the motor encoder supports commutation and the inner velocity loop. Motor current feedback comes from current sensing, rather than from the encoder itself.
This arrangement allows the controller to respond to the measured output position and compensate for some transmission-related errors.
However, dual feedback does not eliminate every source of positioning error. Performance still depends on encoder accuracy, mounting quality, calibration, mechanical behavior and controller tuning.
It also cannot directly measure structural deflection occurring beyond the output encoder, such as bending in a robot link or end effector.
Compensation for Backlash and Elastic Deformation
After converting both encoder readings to the same reference frame, the controller can compare motor-derived output position with the measured output position.
The difference can help identify lost motion, elastic deflection and other transmission effects. Depending on the control strategy, this information can support feedback correction or model-based compensation.
The practical benefit is reduced positioning error. Mechanical backlash remains present, and reversal performance must still be verified under representative loads and speeds.
Torque Estimation in Suitable Joint Designs
In a joint with a known, calibrated elastic element, the angular deflection across that element can be used to estimate transmitted torque.
Dual encoder feedback can therefore support torque estimation in some compliant joints and series elastic actuators.
The estimate depends on the stiffness model, encoder accuracy, friction, hysteresis, temperature and dynamic behavior. An ordinary gearbox does not automatically become an accurate torque sensor simply because encoders are installed at both ends.
Where precise torque measurement is required, a dedicated joint torque sensor may still be appropriate.
Additional Diagnostic Information
Unexpected differences between motor-side and output-side measurements can indicate abnormal behavior, such as transmission slip, excessive deflection or certain sensor and mechanical faults.
These comparisons can support fault monitoring. They do not guarantee detection of every collision or failure, and safety-related use requires a validated diagnostic and response strategy.
Is a Dual Encoder Joint Module Always Better Than a Single Encoder Module?
No. Dual encoders provide additional feedback, but they also introduce costs and integration requirements.
The appropriate choice depends on whether direct output measurement provides a meaningful benefit for the application.
A single encoder robot joint module may be sufficient when the complete system meets its positioning, motion and safety requirements.
When Can a Single Encoder Be Sufficient?
1. Transmission errors remain within the application’s tolerance
A suitably selected precision reducer may provide adequate performance with motor-side feedback.
However, low backlash and high stiffness are different characteristics. A reducer can have very low backlash while still exhibiting significant torsional deflection under load.
Evaluate the actual reducer specifications and load conditions rather than assuming that every harmonic or RV reducer behaves the same way.
2. The required positioning performance is achievable without output feedback
Some handling, welding, spraying and repetitive automation tasks can be performed effectively with motor-side feedback.
The result must be verified on the complete robot. Encoder count alone cannot establish a particular end-effector accuracy, such as ±0.1 mm. Accuracy and repeatability must also be assessed separately.
3. Force control uses another measurement source
Some systems use an end-effector six-axis force/torque sensor to measure interaction forces while the joints operate primarily under position control.
In these applications, direct joint torque estimation from dual encoders may not be necessary.
4. Cost and integration simplicity are priorities
A second encoder can increase component cost, mechanical integration work, signal processing requirements and commissioning effort.
The actual cost difference depends on the encoder technology, module design and production volume. It should be evaluated from supplier quotations rather than a universal percentage.
5. Loads and operating conditions are predictable
If the load profile is stable and transmission errors remain acceptable throughout the operating cycle, the performance benefit of a second encoder may be limited.
Operating speed alone does not determine the answer. Dynamic behavior and control stability must also be considered.
Example: Force-Controlled Cleaning with a Mobile Manipulator
Consider a mobile manipulator that uses an end-effector six-axis force/torque sensor to regulate cleaning contact force.
The robot joints may operate in position control while an admittance controller adjusts the commanded motion using the measured contact force.
For this architecture, a single encoder joint module combined with a suitable reducer may be sufficient, provided that testing confirms acceptable tracking, contact-force regulation and stability.
If future requirements include hand-guided teaching or joint-space impedance control, additional feedback may be beneficial. Possible options include output encoders, dedicated joint torque sensors or other validated sensing and estimation approaches.
The choice should follow the intended control architecture and performance requirements.
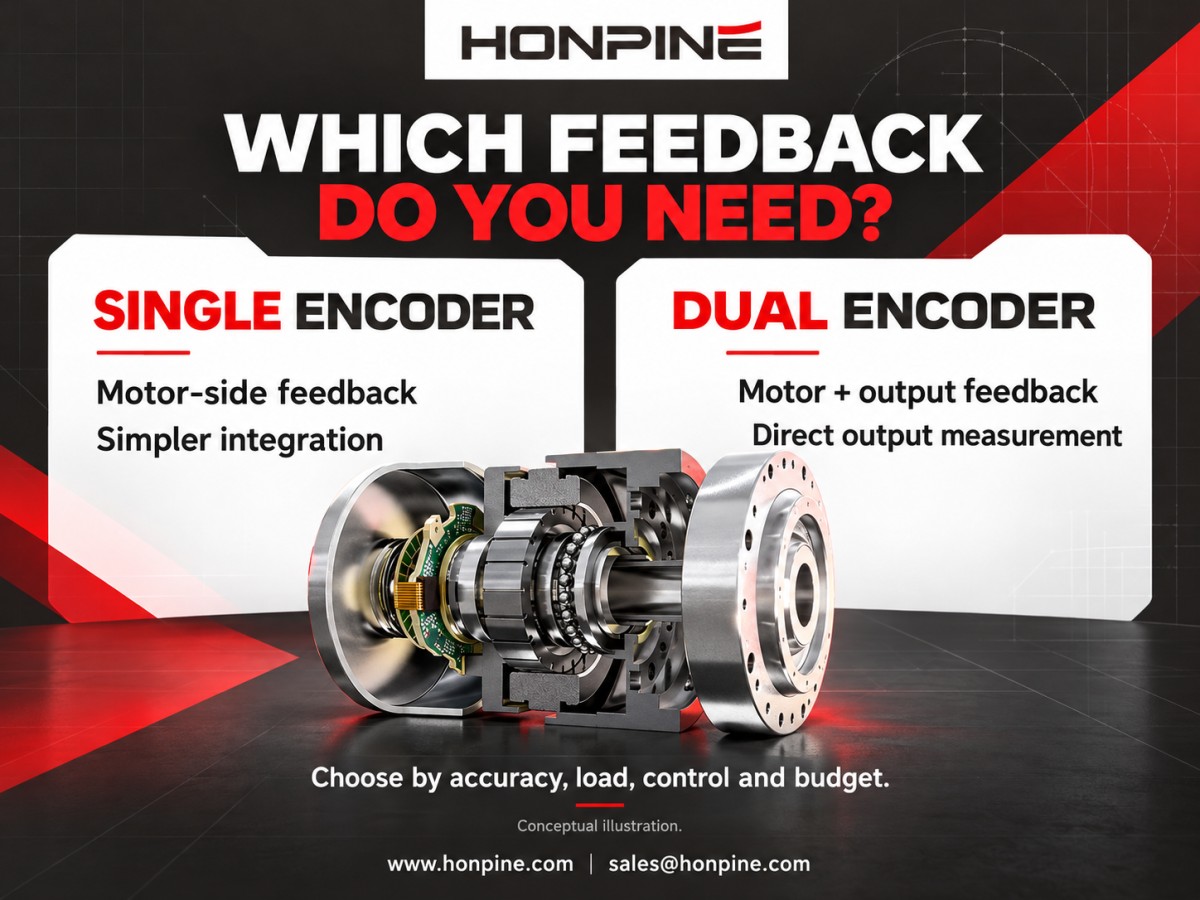
Single vs Dual Encoder Robot Joint Modules: Comparison
How Can Dual Encoders Contribute to Robot Functional Safety?
Dual feedback can contribute to a safety architecture, but two encoders do not automatically provide Category 3, PL d, PL e or SIL 3 capability.
Position feedback for motion control and redundancy for functional safety are related but distinct design questions.
1. Channel Architecture and Common Cause Failures
Two sensors at different locations are not necessarily independent safety channels. They may share power supplies, electronics, communication paths or environmental vulnerabilities.
For the relevant ISO 13849-1 assessment, measures against common cause failure are evaluated using a points system. The commonly referenced threshold is at least 65 points out of 100, not “CCF ≤65%.”
Different mounting locations or communication protocols alone do not demonstrate compliance.
2. Integration with the Required Safety Functions
Safety-related feedback must be integrated into the complete sensing, logic and drive architecture.
Depending on the application, the required functions may involve safe stopping, speed limitation, position limitation or brake control.
Fault thresholds and response times must be derived from the system requirements. A fixed encoder disagreement limit, such as ±0.5°, should not be treated as a universal setting.
For collaborative applications using power and force limiting, acceptable contact conditions depend on factors including the affected body region, contact type, force and pressure. A single 150 N limit is not a universal criterion for safe human–robot contact.
3. Reliability and Diagnostic Coverage
A safety assessment considers architecture, component reliability, diagnostic coverage and common cause failures.
The probability of a dangerous failure per hour, or PFHD, cannot be calculated simply by placing two encoder failure-rate values in parallel.
For reference, the PFHD bands associated with PL d and PL e are:
PL d: 10⁻⁷ ≤ PFHD < 10⁻⁶ per hour.
PL e: 10⁻⁸ ≤ PFHD < 10⁻⁷ per hour.
Meeting a numerical band alone does not establish the performance level; the other applicable requirements must also be satisfied.
4. Fault Detection and a Suitable Safety Response
A properly designed system can use feedback disagreement to detect certain faults and initiate an appropriate response.
However, encoder count alone does not determine whether a system is fail-safe. A single physical encoder can contain independent measurement channels and diagnostics intended for safety-related applications, provided that it is integrated with a suitable safety controller.
Therefore, it is incorrect to assume that every single encoder system becomes uncontrolled after any encoder fault, or that every dual encoder system meets a particular safety integrity level.
Why Can Dual Encoder Feedback Be Useful in Humanoid Robot Joints?
Humanoid robots combine many joints with changing loads, balance requirements and frequent interaction with the environment.
These characteristics make accurate joint-state feedback valuable. However, the sensing architecture varies by robot design, and dual encoders should not be assumed to be universal.
Better Observation of Transmission Behavior
In a geared joint, motor movement and output movement may differ because of backlash, transmission error or elastic deformation.
A motor-side encoder measures only the motor position. An output encoder adds direct information about the actual joint angle.
This can improve the joint-position information available to the robot controller.
Measurement of Load-Dependent Deflection
When a robot transfers its weight, lands a foot or handles an external load, its joints and transmission components may deflect.
A deliberately compliant joint, such as a series elastic actuator, may exhibit additional relative motion across its elastic element.
Measuring both sides of the transmission can help observe this behavior. When combined with an appropriate model, the feedback may support control and estimation.
However, dual encoders alone do not ensure dynamic balance. Overall performance also depends on the robot’s mechanical design, inertial sensing, contact information, state estimation and control algorithms.
Absolute Output Position at Startup
An absolute output encoder can report joint position within its measurement range at power-up, reducing the need for a homing movement.
This capability comes from the encoder’s absolute measurement technology, not from having two encoders.
A single encoder can also be absolute, while a dual encoder arrangement may use incremental sensors.
Calibration, turn tracking where required, and startup checks remain necessary. Knowing the joint angle at power-up does not by itself guarantee that a humanoid robot can safely stand or begin moving.
How to Choose Between Single and Dual Encoder Joint Modules?
Begin with the requirements of the complete robot, then determine what feedback is needed at each joint.
Consider the following questions:
What output positioning accuracy and repeatability are required?
How much backlash, lost motion and torsional deflection occur under the expected load?
Will force control use motor-current estimation, an elastic-element model, a joint torque sensor or an end-effector force/torque sensor?
Does the controller support dual-loop operation and suitable tuning?
Is absolute output position required at startup?
What diagnostics and safety functions must the system provide?
Does the performance benefit justify the additional integration cost?
A single encoder can be an effective choice when the complete system meets its requirements with motor-side feedback.
A dual encoder robot joint module is worth considering when direct output measurement offers a clear advantage in positioning, transmission monitoring or compliant-joint control.
If you are selecting robot joint modules for a new project, discuss your positioning targets, load profile, force control strategy and feedback requirements with HONPINE.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 What’s the Difference Between Single and Dual Encoder Robot Joint Modules?Does your robot need a dual encoder joint module, or is a single encoder enough? The answer depends on positioning requirements, transmission behavior, force control strategy and budget. This guide compares motor-side and output-side feedback, explains where dual encoders can improve control, and examines their costs and limitations. Learn when a single encoder can meet your needs and when additional output feedback is worth considering.
 RV vs Harmonic Reducer: How to Choose the Right Gearbox for Robot Joints?RV vs harmonic reducer: which gearbox is right for your robot joint? The answer depends on torque, rigidity, accuracy, installation space and operating conditions. This guide compares their working principles and five key performance factors, then explains how to evaluate joint loads, reducer life, temperature and lubrication. Whether you are designing a robot base, shoulder, elbow or wrist, use these considerations to match the reducer to the requirements of each joint.
 How to Find a Reliable Robotic Joint Actuator Supplier?Choosing the right robotic joint actuator supplier is essential for reliable performance, smooth integration and long-term project success. Beyond product specifications, you need to understand a supplier’s technical expertise, production capacity and after-sales support. In this guide, Allen Li, Founder of HONPINE, explains how to assess these three factors when sourcing harmonic and planetary joint actuators for robotics and industrial automation.
 Harmonic Reducer vs. Harmonic Rotary Actuator: Which Is Better for CNC Machine Tools?Choosing between a harmonic reducer and a harmonic rotary actuator is an important decision in CNC machine tool design. Both solutions offer high-precision motion control, but they differ in integration, installation requirements, rigidity, and system flexibility. For CNC fourth-axis rotary tables and compact five-axis machining systems, selecting the right harmonic drive can significantly influence machine performance. In this article, HONPINE Technical Director Theodore Li compares harmonic reducers and harmonic rotary actuators to help engineers identify the most suitable solution for their CNC applications.
 How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?I'm Theodore Li, Technical Director at HONPINE. Choosing harmonic joint actuators for a 7-DOF robotic arm starts with the torque, weight, and installation needs of each joint. This guide uses a TCHL 20 shoulder and TCHL 14 wrist configuration as an example, then explores torque sensing, compliant control, and HAG Series considerations for demanding robotic applications.
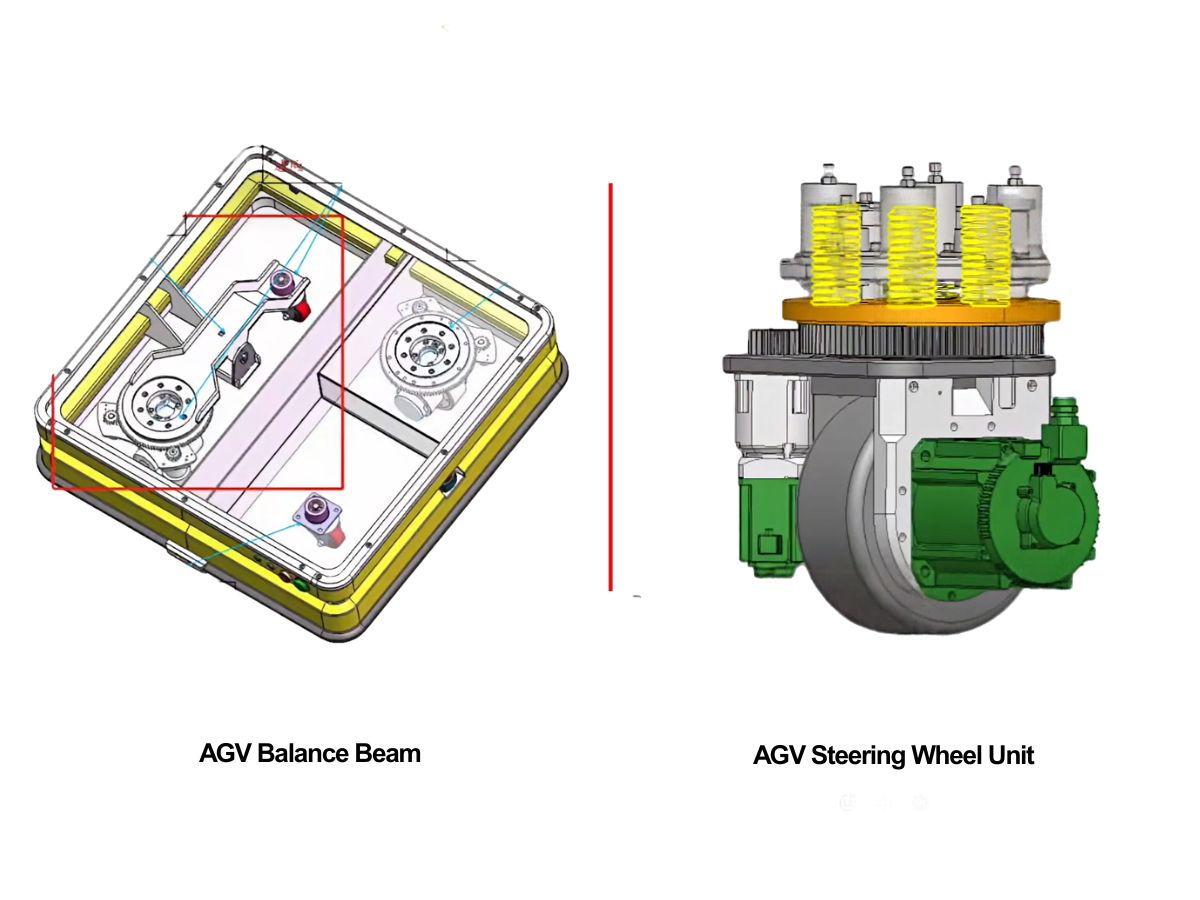
 AGV Suspension: Should You Choose a Balance Beam or a Spring-Loaded Steering Drive Unit?Choosing an AGV suspension system starts with the vehicle’s load range and floor conditions. Balance beams and spring-loaded steering drive units offer different approaches to maintaining wheel contact and managing wheel loads. This HONPINE guide compares both options and explains how to evaluate traction, suspension travel, installation space, and maintenance before choosing a configuration.



Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 What’s the Difference Between Single and Dual Encoder Robot Joint Modules?Does your robot need a dual encoder joint module, or is a single encoder enough? The answer depends on positioning requirements, transmission behavior, force control strategy and budget. This guide compares motor-side and output-side feedback, explains where dual encoders can improve control, and examines their costs and limitations. Learn when a single encoder can meet your needs and when additional output feedback is worth considering.
 RV vs Harmonic Reducer: How to Choose the Right Gearbox for Robot Joints?RV vs harmonic reducer: which gearbox is right for your robot joint? The answer depends on torque, rigidity, accuracy, installation space and operating conditions. This guide compares their working principles and five key performance factors, then explains how to evaluate joint loads, reducer life, temperature and lubrication. Whether you are designing a robot base, shoulder, elbow or wrist, use these considerations to match the reducer to the requirements of each joint.
 How to Find a Reliable Robotic Joint Actuator Supplier?Choosing the right robotic joint actuator supplier is essential for reliable performance, smooth integration and long-term project success. Beyond product specifications, you need to understand a supplier’s technical expertise, production capacity and after-sales support. In this guide, Allen Li, Founder of HONPINE, explains how to assess these three factors when sourcing harmonic and planetary joint actuators for robotics and industrial automation.
 Harmonic Reducer vs. Harmonic Rotary Actuator: Which Is Better for CNC Machine Tools?Choosing between a harmonic reducer and a harmonic rotary actuator is an important decision in CNC machine tool design. Both solutions offer high-precision motion control, but they differ in integration, installation requirements, rigidity, and system flexibility. For CNC fourth-axis rotary tables and compact five-axis machining systems, selecting the right harmonic drive can significantly influence machine performance. In this article, HONPINE Technical Director Theodore Li compares harmonic reducers and harmonic rotary actuators to help engineers identify the most suitable solution for their CNC applications.
 How to Choose Harmonic Joint Actuators for a 7-DOF Robotic Arm?I'm Theodore Li, Technical Director at HONPINE. Choosing harmonic joint actuators for a 7-DOF robotic arm starts with the torque, weight, and installation needs of each joint. This guide uses a TCHL 20 shoulder and TCHL 14 wrist configuration as an example, then explores torque sensing, compliant control, and HAG Series considerations for demanding robotic applications.
 AGV Suspension: Should You Choose a Balance Beam or a Spring-Loaded Steering Drive Unit?Choosing an AGV suspension system starts with the vehicle’s load range and floor conditions. Balance beams and spring-loaded steering drive units offer different approaches to maintaining wheel contact and managing wheel loads. This HONPINE guide compares both options and explains how to evaluate traction, suspension travel, installation space, and maintenance before choosing a configuration.
 Hollow Rotary Platform Motor Matching: A Complete GuideSelecting the right motor for a hollow rotary platform is essential for achieving precise positioning, stable operation, and efficient automation. This guide explains how to match servo motors, stepper motors, and brushless DC motors with hollow rotary platforms based on torque, speed, inertia, accuracy, and installation requirements. Explore practical motor selection guidelines, typical application combinations, and space-saving mounting solutions to find the right configuration for your automation project.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.