Why Do Robot Joint Modules Use Dual Encoders?
Dual encoder robot joints are becoming increasingly important in high-performance robotics. But adding a second encoder is not simply a matter of installing another sensor.
The real purpose is to answer two different questions:
How much has the motor moved?
and
How much has the robot joint actually moved?
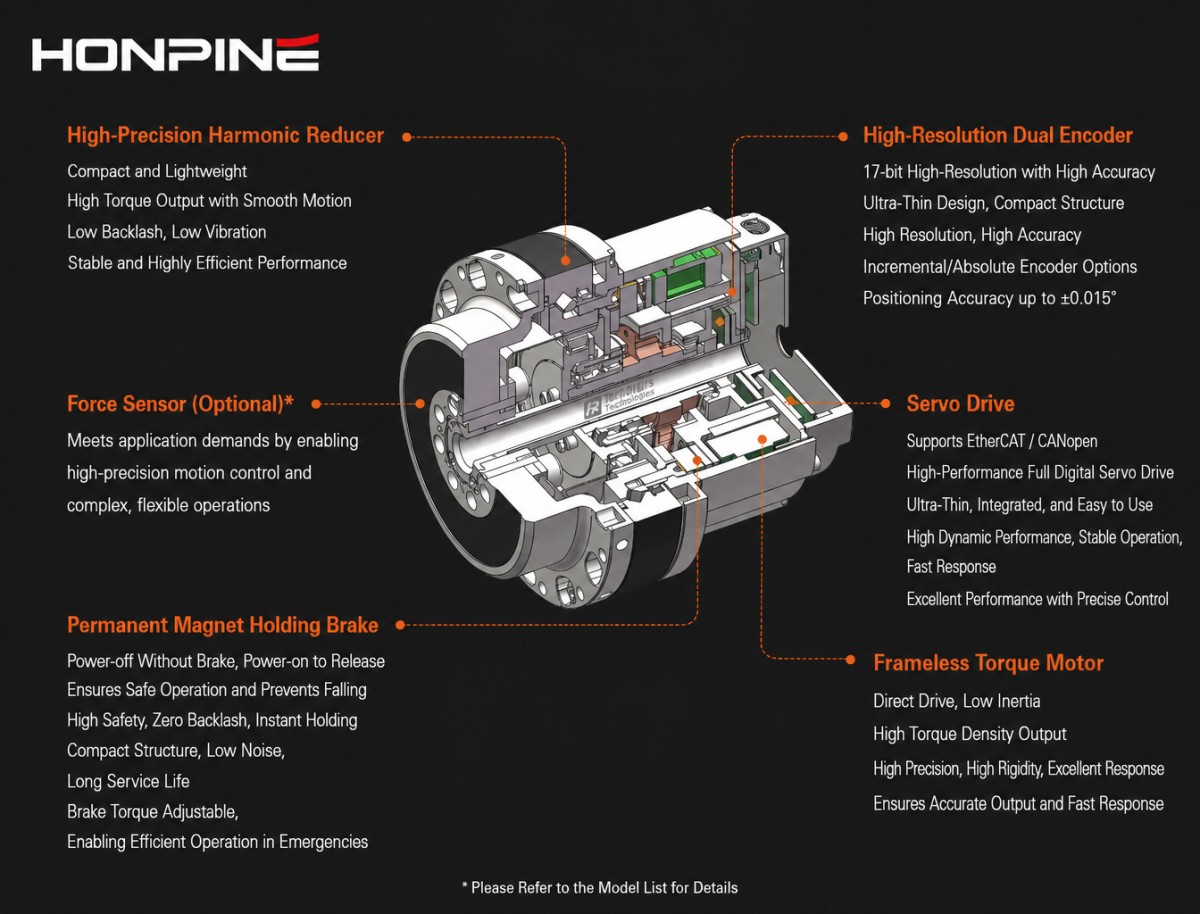
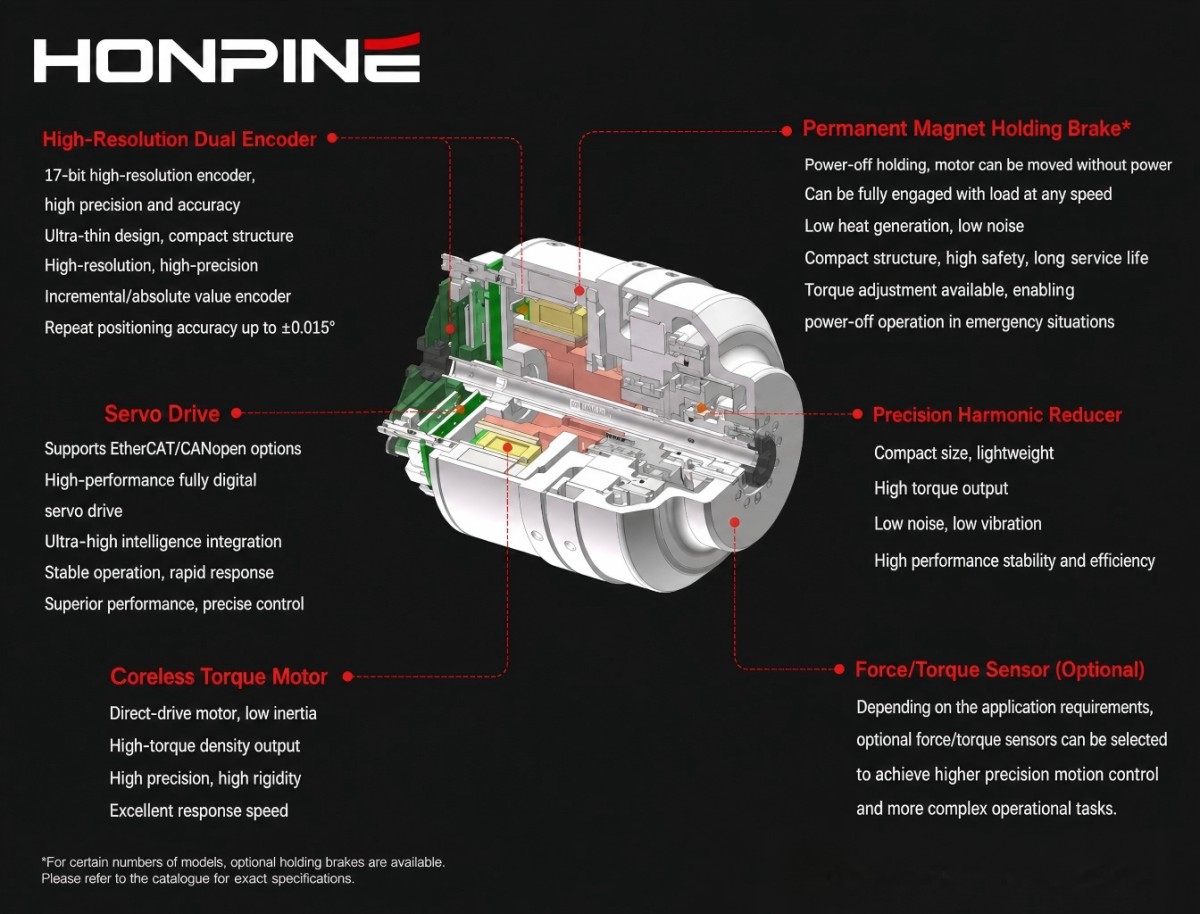
In a robot joint module consisting of a frameless torque motor, precision reducer, encoder and output flange, the motor-side encoder can accurately measure motor position and speed. However, the actual joint output can still be affected by transmission error, torsional deformation, friction, thermal drift, assembly tolerances and changes in external load.
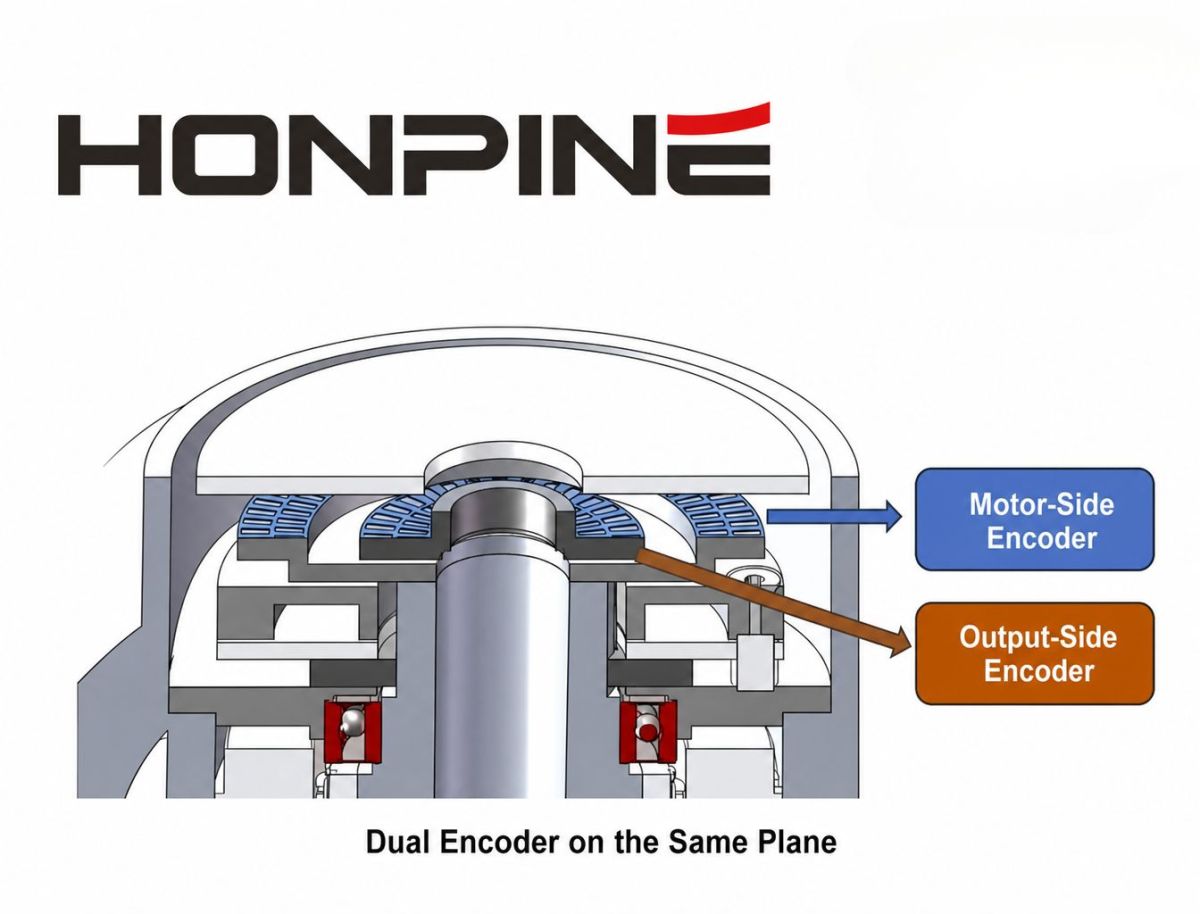
This is why a dual encoder robot joint can provide a more complete feedback architecture. One encoder monitors the motor side, while the other measures the joint output side. Together, they allow the controller to observe both the motor dynamics and the actual joint position.
What Is a Dual Encoder Robot Joint?
A typical robot joint dual encoder architecture can be simplified as:
Motor → Motor-Side Encoder → Precision Reducer → Output-Side Encoder → Joint Output
The motor-side encoder is installed near the motor rotor or input shaft. It primarily provides high-speed feedback for motor commutation, field-oriented control (FOC), velocity control and motor state estimation.
The output-side encoder, also known as a joint-side encoder, is installed after the reducer and measures the actual angular position of the robot joint.
This architecture is commonly described as:
Dual encoder
Dual feedback
Dual-loop control
Motor-side and joint-side feedback
The two encoders do not necessarily have to use the same technology. Depending on the application, a robot joint may use incremental encoders, single-turn absolute encoders or multi-turn absolute encoders.
Why Is a Motor-Side Encoder Not Enough?
In a conventional single-encoder robot joint, the encoder is usually installed on the motor side.
The controller knows the motor position and calculates the theoretical output position according to the reduction ratio:
θout ≈ θmotor / N
where N is the reduction ratio.
This approach works well when the transmission system can be considered sufficiently rigid and predictable.
However, a real robot joint is not an ideal rigid transmission system.
The reducer may introduce transmission error, while flexible components can deform under load. Bearings, couplings and output flanges can also introduce small mechanical deviations. Temperature changes may further affect both the mechanical structure and encoder measurements.
As a result:
Calculated Joint Position ≠ Actual Joint Position
This difference is one of the main reasons why output-side encoders are used in high-performance robot joints.
A secondary encoder can provide additional feedback for identifying and compensating transmission errors, especially in robot joints affected by flexibility, backlash, friction and other mechanical disturbances.
The Core Advantage of Dual Encoders: Measuring What Happens After the Reducer
The most important concept behind a dual encoder actuator is simple:
The motor-side encoder measures the input side of the transmission.
The output-side encoder measures the actual joint output.
The controller can then compare the two feedback signals and identify differences between the motor motion and the joint motion.
For example, the motor may rotate to the commanded position while the output flange is still slightly displaced because of torsional deformation, transmission error or load-dependent mechanical behavior.
A single-encoder system may assume:
The motor has reached the commanded position, so the joint has reached the commanded position.
A dual encoder system can identify:
The motor has reached the commanded position, but the joint output still has a position error.
This is one of the fundamental advantages of dual-loop feedback in robot joint modules.
1. Improve Robot Joint Position Control
One of the main advantages of a dual encoder architecture is that the position loop can use feedback from the actual joint output.
In a conventional motor-side feedback system, the position controller primarily observes motor position.
With dual feedback, the control architecture can separate the two functions:
Motor Encoder → Motor Control
Output Encoder → Joint Position Feedback
This allows the controller to regulate not only the motor but also the actual output position after the reducer.
This architecture is particularly useful for:
High-precision robot joints
Collaborative robots
Precision motion systems
CNC rotary axes
High-performance servo mechanisms
For applications requiring accurate trajectory tracking, output-side position feedback can help reduce the influence of transmission-related errors on the final joint position.
2. Measure and Compensate Reducer Transmission Error
A common misunderstanding is that a dual encoder can simply “eliminate backlash.”
This is not technically accurate.
A dual encoder robot joint does not mechanically eliminate backlash. Instead, the second encoder allows the control system to measure the difference between motor-side and output-side motion and compensate for part of the transmission error through control algorithms.
Depending on the reducer and mechanical design, relevant error sources may include:
Transmission error
Torsional deformation
Hysteresis
Friction
Elastic deformation
Assembly error
Thermal drift
By comparing motor-side and joint-side position feedback, the controller can build an error model and apply compensation according to joint position, direction, speed, load and other operating conditions.
Therefore, a more accurate description is:
Dual encoders enable transmission-error measurement and compensation.
Rather than:
Dual encoders eliminate backlash.
This distinction is important when evaluating the actual performance of a harmonic drive robot joint or other precision reducer-based actuator.
3. Improve Actual Joint Position Feedback
High encoder resolution does not automatically mean high robot positioning accuracy.
Three technical concepts should be clearly distinguished:
Resolution
Resolution describes the smallest position increment that an encoder can distinguish.
For example, a 23-bit single-turn encoder provides:
2²³ = 8,388,608 counts per revolution
The theoretical angular increment is approximately:
0.154 arcsec per count
However, this is encoder resolution, not the overall positioning accuracy of the robot joint.
Accuracy
Accuracy describes how closely the measured position corresponds to the actual physical position.
Repeatability
Repeatability describes how consistently the system returns to the same position when the same motion is repeated.
Therefore:
High Encoder Resolution ≠ High System Accuracy
The final performance of a robot joint depends on the complete system, including encoder accuracy, reducer transmission error, bearing runout, mechanical stiffness, thermal effects, calibration and control algorithms.
This is why dual encoder feedback should be evaluated as part of the complete motion-control architecture rather than by encoder bit count alone.
4. Separate Motor Motion From Actual Joint Motion
This is another important advantage of a robot joint dual encoder architecture.
Consider a robot joint using a 100:1 reduction ratio.
The motor may rotate through a relatively large angle while the output joint rotates only a small fraction of that angle.
At the same time, the reducer and mechanical structure may deform slightly as the external load changes.
The controller can therefore calculate a theoretical joint position from the motor encoder, but this does not necessarily represent the actual output position.
The output encoder provides direct feedback from the joint side.
The control system can therefore observe two different states:
Motor Dynamics
and
Joint Dynamics
This distinction becomes increasingly important in high-speed robot motion, dynamic load changes and high-precision trajectory control.
Can Dual Encoders Prevent Position Loss After Power-Off?
The answer is:
They can help, but dual encoders alone do not automatically eliminate homing.
Whether a robot joint can retain its position after power loss depends mainly on the encoder type and the multi-turn position retention mechanism.
Incremental Encoder
An incremental encoder generally does not retain absolute position information after power loss and may require a reference or homing procedure.
Single-Turn Absolute Encoder
A single-turn absolute encoder can identify the angular position within one revolution, but it does not by itself provide unlimited multi-turn position information.
Multi-Turn Absolute Encoder
A multi-turn absolute encoder can provide both single-turn position and accumulated rotational position over multiple revolutions.
Multi-turn position retention can be implemented using different technologies, including battery-backed systems, mechanical counting mechanisms and battery-free position retention technologies.
For example, Oriental Motor's ABZO encoder uses a battery-free mechanical absolute position system that can retain position information after power is removed.
Therefore, the engineering relationship is better described as:
Dual Encoder + Appropriate Multi-Turn Absolute Feedback → Potentially Reduced or Eliminated Conventional Homing
rather than:
Dual Encoder → Automatically Eliminates Homing
Can Dual Encoders Improve Robot Functional Safety?
Yes, but an important distinction must be made:
Two encoders do not automatically mean functional safety redundancy.
If two encoders are simply connected to a conventional controller without appropriate diagnostics, fault detection and safety architecture, the system cannot automatically claim PL d, PL e, SIL 2 or SIL 3.
The value of dual feedback in safety-related applications is that the controller can compare two different position measurements.
For example:
Motor Encoder Position ≠ Joint Encoder Position
may indicate:
Encoder failure
Mechanical transmission failure
Reducer damage
Shaft or coupling problems
Unexpected mechanical displacement
Communication or signal errors
The control system can then detect the abnormal condition and execute an appropriate fault response.
IEC 61800-5-3 addresses safety-related encoders, while IEC 61800-5-2 covers safety-related functions for power drive systems.
Therefore, the technically correct statement is:
Dual encoders can support a functional-safety architecture, but the final PL or SIL capability depends on the complete safety-related system, diagnostics, architecture and validation.
How Do Dual Encoders Relate to Functional Safety Standards?
Functional safety in a robot joint is not determined by a single encoder.
It is based on the complete safety-related control system.
Relevant standards may include:
IEC 61508
Provides the general framework for functional safety and Safety Integrity Levels (SIL).
IEC 61800-5-2
Defines safety-related functions for power drive systems, including functions such as Safe Torque Off (STO) and other drive-related safety functions.
IEC 61800-5-3
Provides requirements for safety-related encoders used in functional-safety applications.
EN ISO 13849-1
Addresses safety-related parts of control systems and defines Performance Levels (PL).
ISO 10218-1:2025
Specifies safety requirements for industrial robot systems.
ISO 10218-2:2025
Addresses safety requirements for industrial robot applications and robot cells.
The key point is that a dual encoder can be part of a safety-related feedback architecture, but the encoder count alone does not determine the final safety level.
System architecture, diagnostic coverage, fault response, common-cause failure protection and validation must all be considered.
Dual Encoder vs. Single Encoder Robot Joints
The choice between a single encoder and a dual encoder depends on the application.
Feature Single Encoder Dual Encoder
Motor position feedback Yes Yes
Direct output position feedback Usually no Yes
Transmission error monitoring Limited Improved
Dual-loop control Limited Yes
Reducer error compensation Limited Improved
Multi-turn absolute position Depends on encoder Depends on encoder
Fault cross-checking Limited Improved
System complexity Lower Higher
Cost Lower Higher
Suitable for high-performance joints Application dependent Strong advantage
A single encoder may be sufficient for cost-sensitive robot joints or systems where the transmission accuracy is already adequate.
A dual encoder architecture becomes more attractive when the application requires high positioning performance, transmission-error compensation, advanced motion control or additional position diagnostics.
Why Are Dual Encoders Not Used in Every Robot Joint?
If dual encoders provide additional feedback, why not use them everywhere?
The answer is system complexity.
Adding an output encoder increases:
BOM cost
Mechanical integration complexity
Wiring requirements
EMC design requirements
Calibration requirements
Controller complexity
Diagnostic requirements
Assembly requirements
The output-side encoder can also be sensitive to mechanical installation errors.
Encoder eccentricity, shaft runout, flange deformation and coupling errors can all influence the measured output position.
Therefore, the objective is not to install as many sensors as possible.
The objective is to use the right feedback architecture for the required robot joint performance.
Typical Dual Encoder Robot Joint Architecture
A high-performance robot joint can be understood as three main feedback layers.
Motor-Side Feedback
The motor-side encoder primarily supports:
Commutation
Field-Oriented Control (FOC)
Current and velocity control
Motor position feedback
The feedback needs to be fast and stable enough for dynamic motor control.
Joint-Side Feedback
The joint-side encoder primarily provides:
Actual joint position
Output position feedback
Transmission-error monitoring
Mechanical state monitoring
Because it is installed after the reducer, it provides information that cannot be obtained directly from the motor-side encoder.
Controller
The controller combines both feedback sources:
Motor Position → Motor State
Output Position → Joint State
Position Difference → Transmission and Mechanical Error Information
This creates a more complete feedback loop for the robot joint.
Dual Encoders Are About More Than Higher Accuracy
The most important reason for using two encoders is not simply to increase encoder resolution.
It is to make the measurement target more complete.
A single encoder primarily measures:
Motor
A dual encoder system measures:
Motor + Joint
This allows the control system to distinguish between motor movement and actual joint movement.
That distinction is particularly valuable when the robot joint includes a high-ratio precision reducer such as a harmonic drive or RV reducer.
When Should You Use a Dual Encoder Robot Joint?
A dual encoder architecture is worth considering when the robot joint requires one or more of the following:
High-precision joint positioning
When the final output position matters more than the calculated motor position.
Transmission-error compensation
When reducer and mechanical transmission errors need to be measured and compensated.
Advanced motion control
When the control system needs accurate feedback from both the motor and joint sides.
Absolute multi-turn positioning
When the robot needs to retain joint position information after power loss.
Position-based diagnostics
When motor-side and joint-side positions need to be continuously compared to detect abnormal mechanical behavior.
Functional-safety architecture
When redundant or cross-checked position feedback is required as part of a complete safety-related control system.
Why Dual Encoder Feedback Matters for Next-Generation Robot Actuators?
As collaborative robots, humanoid robots and high-performance industrial robots continue to demand higher precision, faster response and better diagnostic capabilities, robot joint architectures are becoming more sophisticated.
The traditional structure:
Motor + Reducer + Encoder
is increasingly evolving toward:
Motor + Motor Encoder + Precision Reducer + Joint Encoder + Controller
The key change is not simply the addition of another sensor.
It is the transition from estimating the joint position from motor motion to directly measuring the actual joint state.
For robot joints using harmonic reducers, this distinction can be particularly important. Precision reducers provide high reduction ratios, high torque density and compact mechanical structures, but the final joint performance is still influenced by transmission error, torsional stiffness, thermal effects, mechanical tolerances and external loads.
A dual encoder architecture gives the controller access to both sides of the transmission chain.
This provides a stronger foundation for:
High-precision position control
Transmission-error compensation
Joint-state monitoring
Dual-loop motion control
Advanced robot motion control
Selected functional-safety architectures
In other words, a dual encoder is not simply “one more sensor.”
It creates a more complete input–transmission–output feedback chain inside the robot joint.
For next-generation robot actuators, this shift from estimating joint position to directly measuring joint behavior can be more valuable than simply increasing encoder resolution.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
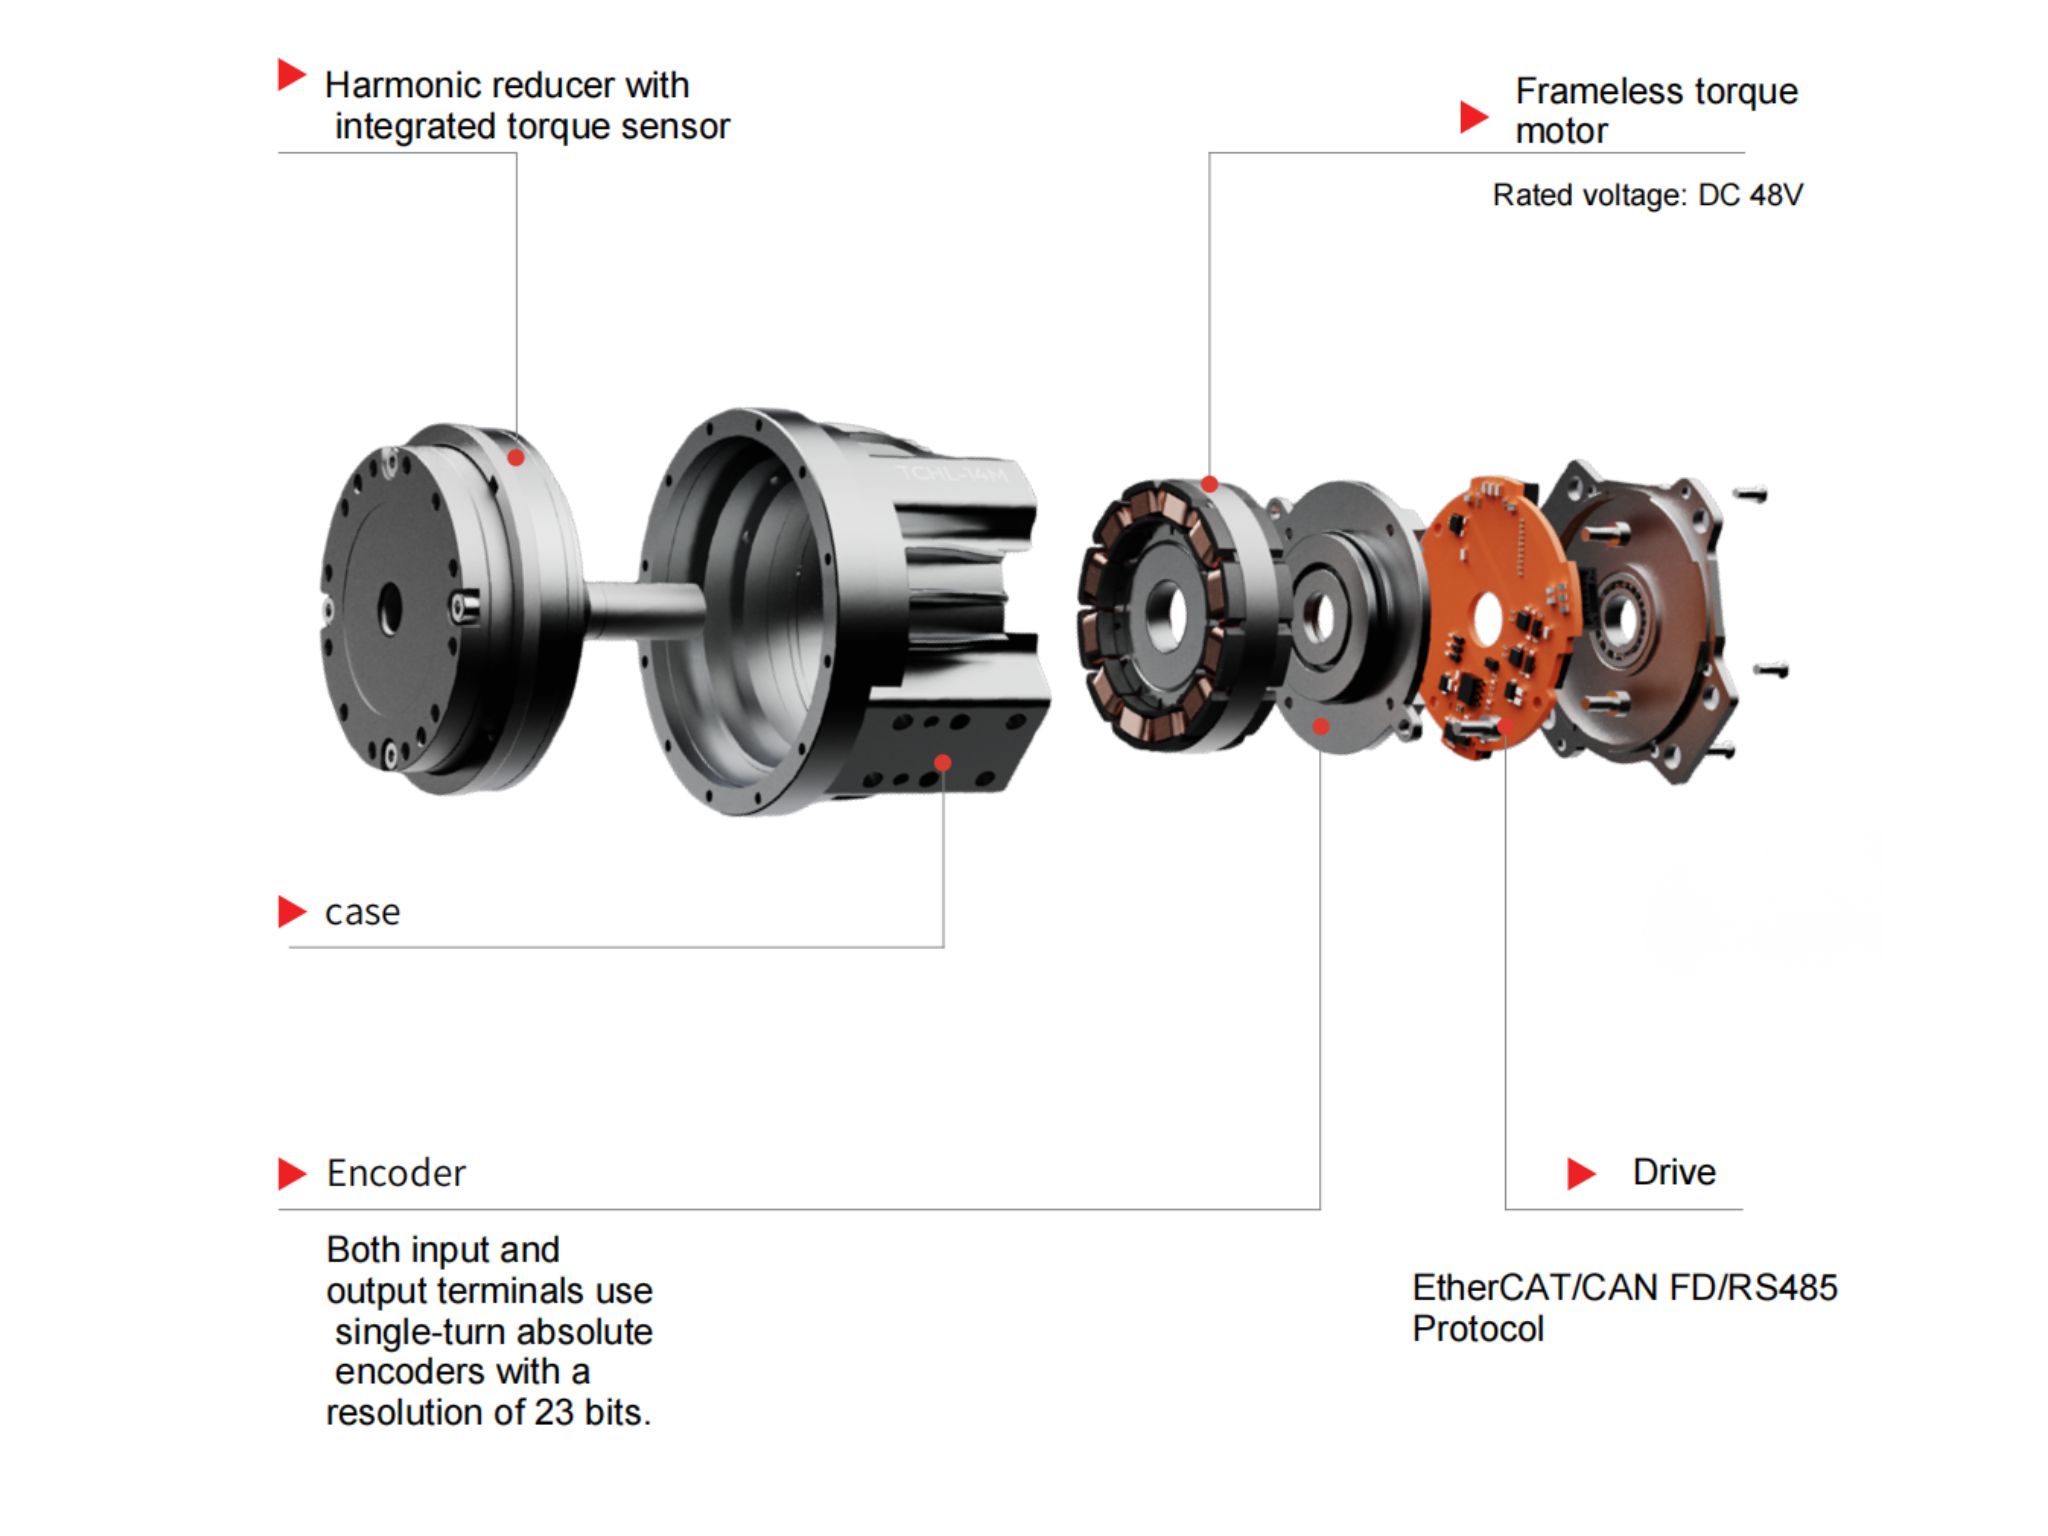
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 H1: Harmonic Rotary Actuators for Semiconductor Equipment: Precision Motion, Hollow-Shaft Design and FOC ControlHello everyone, I’m Theodore Li, Technical Director at HONPINE. In semiconductor manufacturing equipment, rotary motion is not simply about making a mechanism rotate. Limited installation space, cable and tube routing, low-speed stability, precise positioning and continuously adjustable motion profiles can all influence the performance of the machine. This is why harmonic rotary actuators are becoming an important motion solution for semiconductor equipment. In this article, I will discuss how harmonic transmission, FOC-based motor control, encoder feedback, large hollow-shaft design and flexible mechanical interfaces work together to meet practical semiconductor motion requirements, based on our experience with developing equipment, overhead transport, wafer handling, cleaning and crystal-growth applications.
 Outdoor Robot Joint Solution: Harmonic Joint Module with Built-in Torque SensorHello everyone, I’m Theodore Li, Technical Director at HONPINE. As robots move beyond controlled factory environments, outdoor robotic applications are creating new requirements for robot joint design. Rain, dust, humidity, temperature fluctuations, low-temperature conditions, and unpredictable external loads can all affect how a robotic joint performs in the field. In these environments, a joint needs to provide more than precise rotation. It also needs reliable torque feedback, suitable environmental protection, stable operation under changing temperatures, and practical mechanical integration. In this article, I will explain the key engineering considerations behind our outdoor robot joint solution, including the harmonic joint module, built-in torque sensor, IP65 protection, low-temperature lubrication, cable outlet protection, and mechanical integration, based on our experience with outdoor robotic applications such as solar panel installation, construction, and cleaning robots.
 Multi-Robot Collaboration: From Single-Robot Intelligence to System IntelligenceHello, I’m Allen Li, Founder of HONPINE. As robotics continues to evolve, I believe the next major step will not come only from making individual robots more intelligent, but from enabling multiple robots to work together as coordinated systems. Multi-robot collaboration introduces new requirements for communication, task allocation, motion coordination, state awareness, and safety. This evolution also changes the role of the robot joint. A future intelligent robot joint will need to do more than generate precise motion. With technologies such as dual encoders, torque sensing, integrated drives, real-time communication, and safety functions, the robot joint can become an intelligent motion node connecting robot intelligence with physical movement. In this article, I would like to share how I see the relationship between multi-robot collaboration, system intelligence, and the next generation of HONPINE robot joint modules.
 RV Reducer for Welding Positioners: Selection and Torque Calculation for Heavy-Duty Welding ApplicationsSelecting the right RV reducer for a welding positioner requires more than simply matching the reducer to the workpiece weight. A heavy-duty welding positioner must provide sufficient output torque, high torsional rigidity, stable low-speed rotation, accurate positioning, and reliable performance during acceleration, deceleration, and reversing. In this article, we explain how to select an RV reducer and servo motor for a welding positioner by calculating output speed, reduction ratio, workpiece inertia, gravity load torque, acceleration torque, motor torque, and peak torque. A practical 500 kg welding positioner example is also used to show how these parameters affect RV reducer selection.
 Types of Robot Joint Motors: Model Selection, Advantages and DisadvantagesRobot joint motors are one of the key components that determine the performance, precision, efficiency, and load capacity of a robot. Depending on the application, robot joints can use electric, hydraulic, pneumatic, or other drive technologies. Among them, electric-drive solutions have become the mainstream choice for modern robots, especially humanoid robots, industrial robots, collaborative robots, and mobile robots. Electric robot joint motors can be further divided according to their transmission methods, including harmonic drive, planetary reducer, cycloidal reducer, ball screw, and direct drive solutions. Each type has its own advantages and disadvantages in terms of precision, torque density, efficiency, impact resistance, size, cost, and backdrivability. Understanding these differences is essential for selecting the right robot joint motor for a specific application.
 Hollow Rotary Platform vs. Harmonic Rotary Actuator: Application Comparison and InterchangeabilityHello everyone, I’m Theodore Li, Technical Director at HONPINE. For engineers designing precision rotary stations for industrial automation, one question often comes up: when a machine requires high-precision rotation, indexing, or rotary positioning, should you choose a hollow rotary platform or a harmonic rotary actuator? Can they be used interchangeably? Although both are precision rotary motion solutions, their mechanical structures and application characteristics are quite different. In actual equipment, choosing the wrong solution can lead to insufficient load capacity, inadequate rigidity, vibration, speed limitations, or reduced service life. In this article, I’ll compare their application characteristics and explain where they can be used interchangeably, where one is more suitable than the other, and what engineers should check before making a replacement.

Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Outdoor Robot Joint Solution: Harmonic Joint Module with Built-in Torque SensorHello everyone, I’m Theodore Li, Technical Director at HONPINE. As robots move beyond controlled factory environments, outdoor robotic applications are creating new requirements for robot joint design. Rain, dust, humidity, temperature fluctuations, low-temperature conditions, and unpredictable external loads can all affect how a robotic joint performs in the field. In these environments, a joint needs to provide more than precise rotation. It also needs reliable torque feedback, suitable environmental protection, stable operation under changing temperatures, and practical mechanical integration. In this article, I will explain the key engineering considerations behind our outdoor robot joint solution, including the harmonic joint module, built-in torque sensor, IP65 protection, low-temperature lubrication, cable outlet protection, and mechanical integration, based on our experience with outdoor robotic applications such as solar panel installation, construction, and cleaning robots.
 RV Reducer for Welding Positioners: Selection and Torque Calculation for Heavy-Duty Welding ApplicationsSelecting the right RV reducer for a welding positioner requires more than simply matching the reducer to the workpiece weight. A heavy-duty welding positioner must provide sufficient output torque, high torsional rigidity, stable low-speed rotation, accurate positioning, and reliable performance during acceleration, deceleration, and reversing. In this article, we explain how to select an RV reducer and servo motor for a welding positioner by calculating output speed, reduction ratio, workpiece inertia, gravity load torque, acceleration torque, motor torque, and peak torque. A practical 500 kg welding positioner example is also used to show how these parameters affect RV reducer selection.
 Types of Robot Joint Motors: Model Selection, Advantages and DisadvantagesRobot joint motors are one of the key components that determine the performance, precision, efficiency, and load capacity of a robot. Depending on the application, robot joints can use electric, hydraulic, pneumatic, or other drive technologies. Among them, electric-drive solutions have become the mainstream choice for modern robots, especially humanoid robots, industrial robots, collaborative robots, and mobile robots. Electric robot joint motors can be further divided according to their transmission methods, including harmonic drive, planetary reducer, cycloidal reducer, ball screw, and direct drive solutions. Each type has its own advantages and disadvantages in terms of precision, torque density, efficiency, impact resistance, size, cost, and backdrivability. Understanding these differences is essential for selecting the right robot joint motor for a specific application.
 Hollow Rotary Platform vs. Harmonic Rotary Actuator: Application Comparison and InterchangeabilityHello everyone, I’m Theodore Li, Technical Director at HONPINE. For engineers designing precision rotary stations for industrial automation, one question often comes up: when a machine requires high-precision rotation, indexing, or rotary positioning, should you choose a hollow rotary platform or a harmonic rotary actuator? Can they be used interchangeably? Although both are precision rotary motion solutions, their mechanical structures and application characteristics are quite different. In actual equipment, choosing the wrong solution can lead to insufficient load capacity, inadequate rigidity, vibration, speed limitations, or reduced service life. In this article, I’ll compare their application characteristics and explain where they can be used interchangeably, where one is more suitable than the other, and what engineers should check before making a replacement.
 How HONPINE Manufactures Precision Harmonic Reducers: Technology, Quality and Manufacturing Challenges?A precision harmonic reducer is more than a compact high-ratio transmission component. Its actual performance depends on how accurately every critical component is designed, manufactured, assembled, and tested. Tooth profile accuracy, flexspline material, heat treatment, machining tolerances, wave generator geometry, assembly precision, and production consistency can all influence backlash, torsional stiffness, efficiency, durability, and positioning accuracy. For robotics, CNC equipment, semiconductor manufacturing, optical inspection, and other precision automation applications, these factors become even more important. This article explores how HONPINE manufactures precision harmonic reducers, the key technologies and manufacturing challenges involved, and why stable production capability is essential for achieving reliable transmission performance at scale.
 HONPINE HAG Harmonic Joint Actuator Real Load Test for Heavy Duty Robot ArmTest the HONPINE HAG40 harmonic joint actuator with an 80 kg payload, 800 N·m peak torque and 557 N·m rated torque for heavy-duty robotic arms.
 Small Size DD Motor for Precision Rotary Motion and Industrial AutomationAs industrial automation equipment becomes smaller, faster, and more precise, rotary motion systems require higher performance within increasingly limited installation space. A Small Size DD Motor provides a direct-drive solution that eliminates the need for a conventional reduction gearbox, offering a direct torque transmission path, high dynamic response, and precise rotary motion control. From 3C electronics and semiconductor equipment to laser processing, inspection systems, and precision rotary tables, Direct Drive Motor technology offers a compact alternative to traditional geared systems. However, when applications require higher output torque and torque density, a Harmonic Servo Actuator may be a more suitable solution. This article explains the working principles, advantages, applications, and key selection factors of small DD motors, while comparing direct-drive and harmonic actuator architectures from an engineering perspective.
 How to Choose a Robot Joint Motor for Better End-Effector Performance?
Choosing a robot joint motor is not only about selecting the highest torque or the smallest joint. The performance of a robotic arm is ultimately determined by what happens at the end-effector. Tool mass, payload, center of gravity, rotational inertia, motion speed, acceleration, and settling performance can all influence the requirements of each robot joint. Depending on the application, a harmonic joint motor or planetary joint motor may provide a different balance between torque, speed, compactness, and system dynamics. This article explains how to select a robot joint motor by starting with end-effector requirements and evaluating the complete robotic arm as a motion system. How to Size Robot Joint Modules for a Robotic Arm? A Practical Engineering Guide?Choosing a suitable robot joint module is one of the most important decisions when designing a robotic arm. The right selection is not determined by payload or rated torque alone. Link mass, center of gravity, rotational inertia, acceleration, joint weight, torque density, installation space, and operating cycle can all affect the final joint requirements. An oversized joint may increase the robot's mass and inertia, while an undersized joint can limit motion performance and reliability. This guide explains a practical engineering approach to selecting a robot joint module, helping robotic arm designers evaluate torque, weight, dimensions, dynamic performance, and system integration before finalizing their joint architecture.