Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint Motors
Can robots detect and respond to touch in a human-like way? In 2026, harmonic robot joint motors with integrated torque sensors are helping advance contact sensing and responsive interaction in embodied AI.
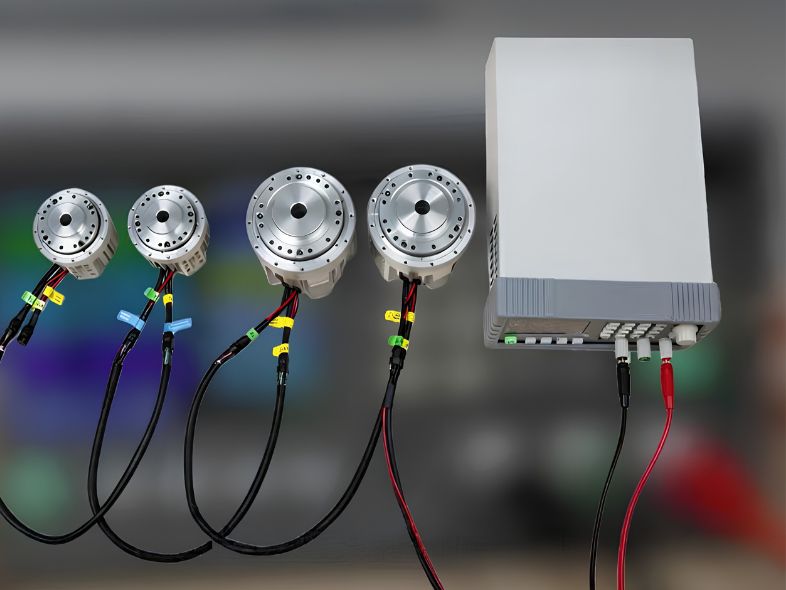
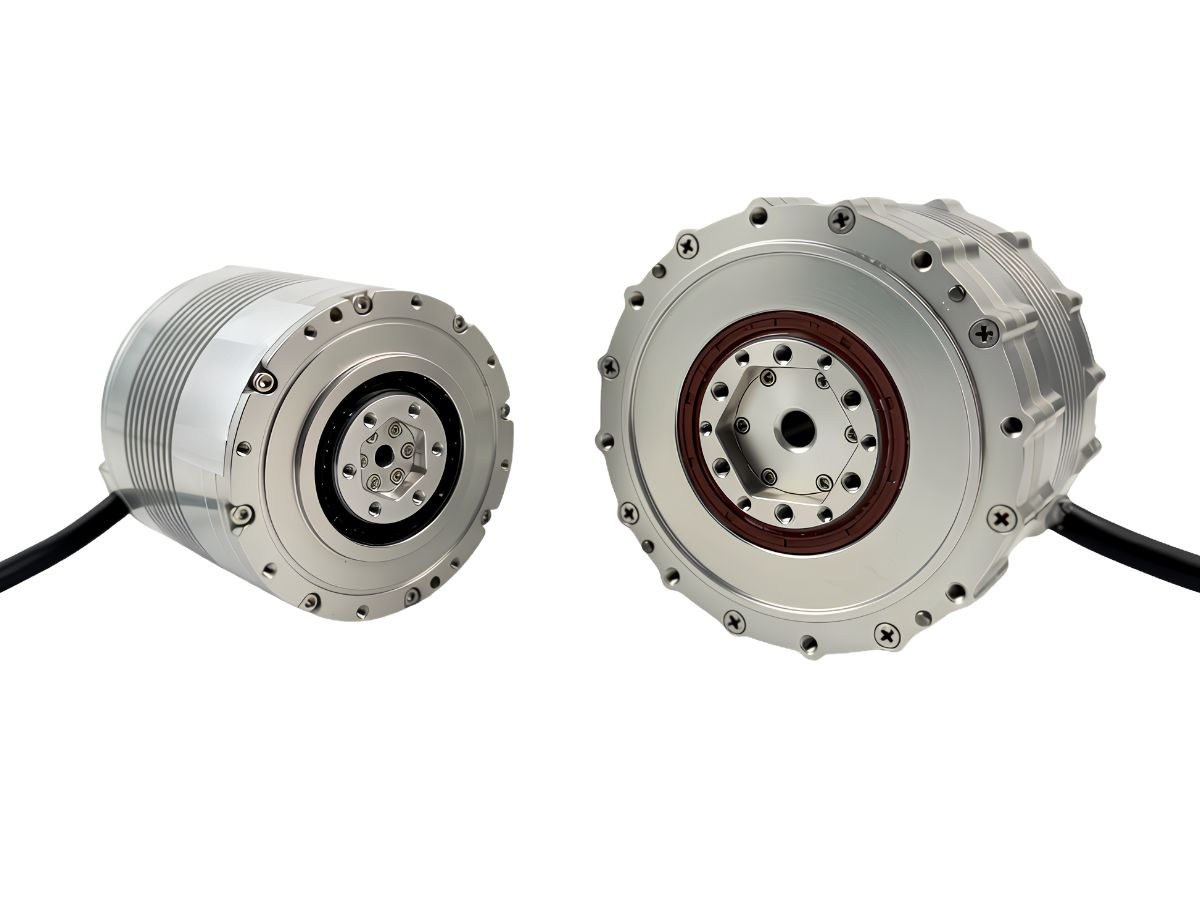
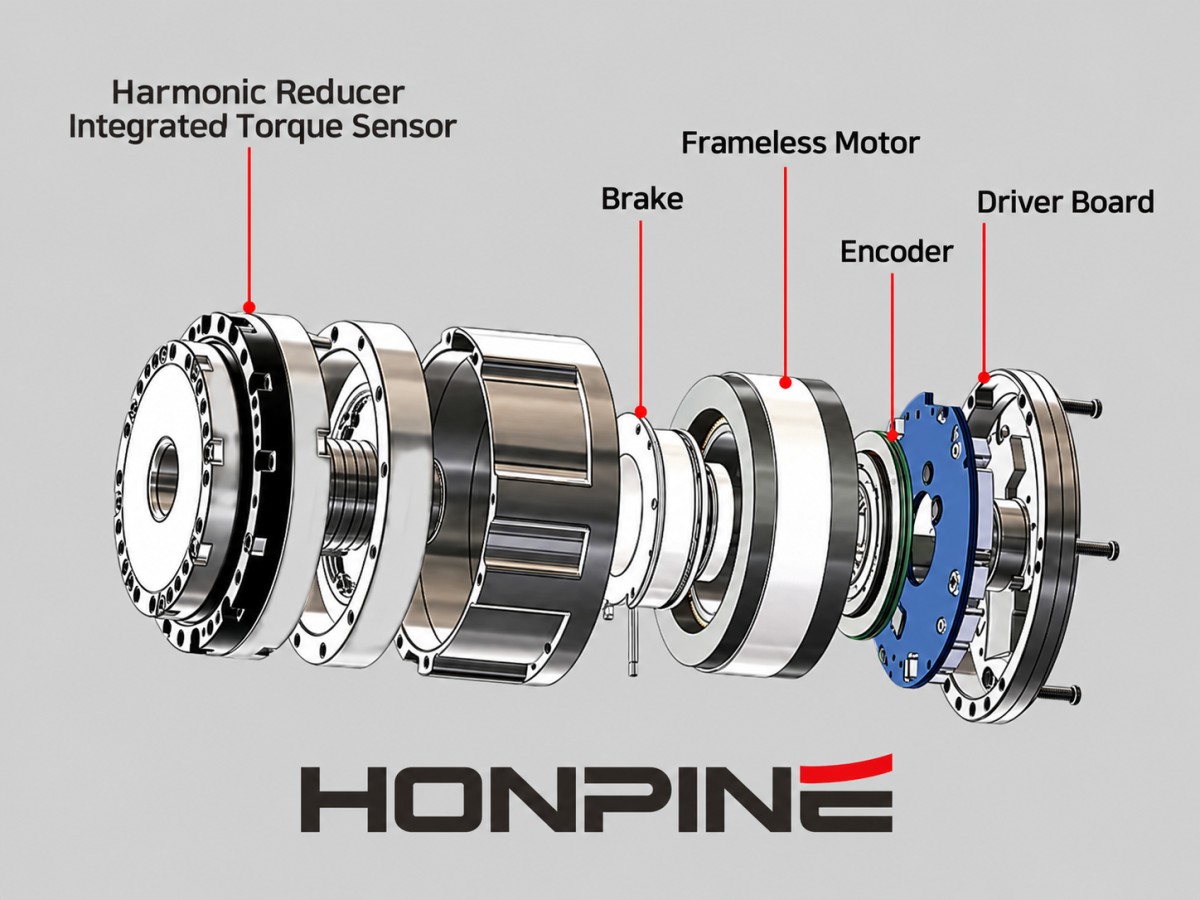
Hello, I’m Allen Li, founder of HONPINE. Today, I’ll introduce the HONPINE HAG force-controlled harmonic robot joint motorand demonstrate how it detects external forces and responds with smooth, compliant motion.
HONPINE HAG Touch-Sensing Demonstration
Real-Time Detection of Light Contact
When a small external force is applied to the end of the lever arm, the HONPINE HAG robot joint motor detects it and responds in real time. This sensitive response allows the joint to react to light contact, bringing robotic interaction closer to the responsiveness we associate with human touch.
The joint module also detects when the external force is removed, providing real-time feedback as contact conditions change.
Smooth, Compliant Hand-Guided Motion
When guided with a very light force, the joint follows the movement smoothly and compliantly, rather than resisting with a rigid response.
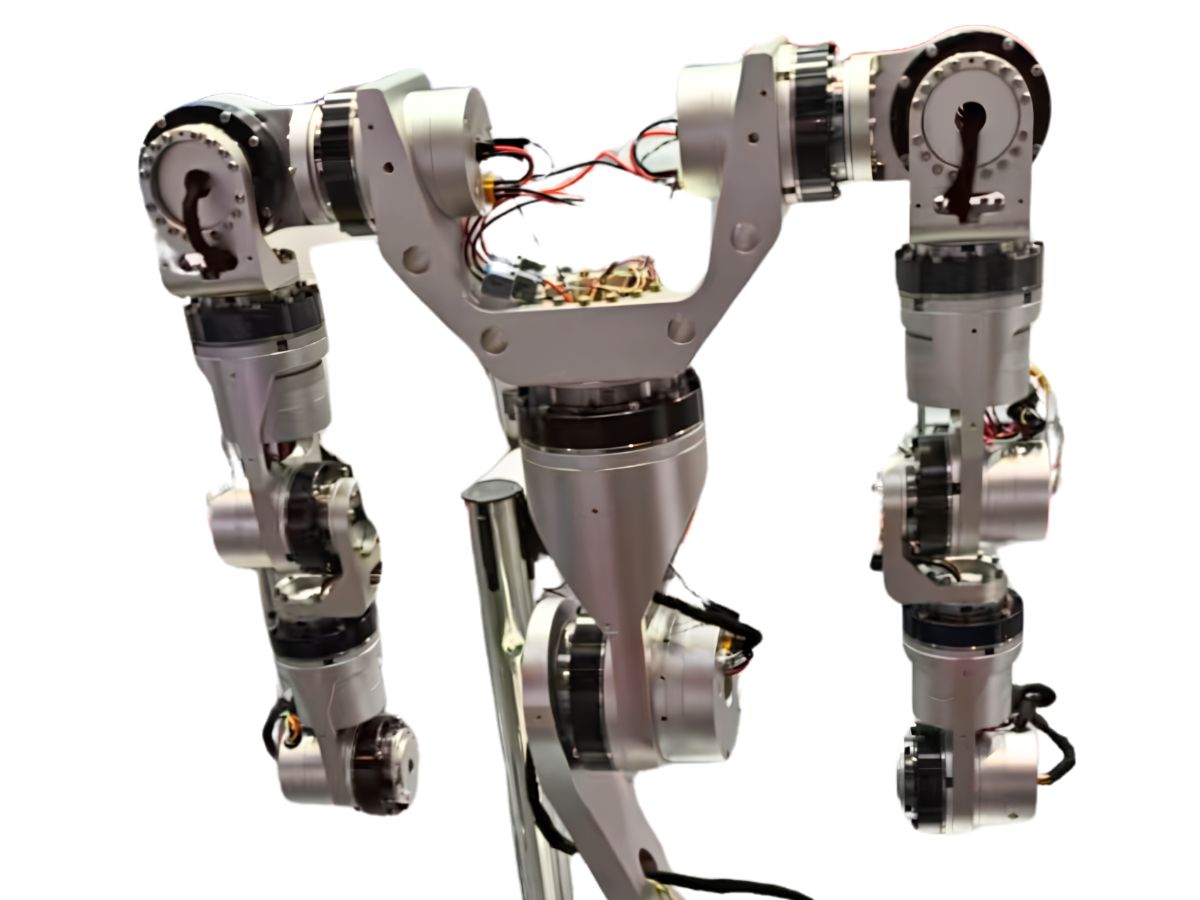
This ability to detect contact and respond with controlled, compliant motion provides an important foundation for complex robotic movements, flexible interaction, and safer human–robot collaboration.
For robots moving beyond demonstrations and into practical applications, responsive force control is an essential part of reliable physical interaction.
Engineering Advances Behind HONPINE Force-Controlled Robot Joint Motors
Core Technologies for Precise Force Control
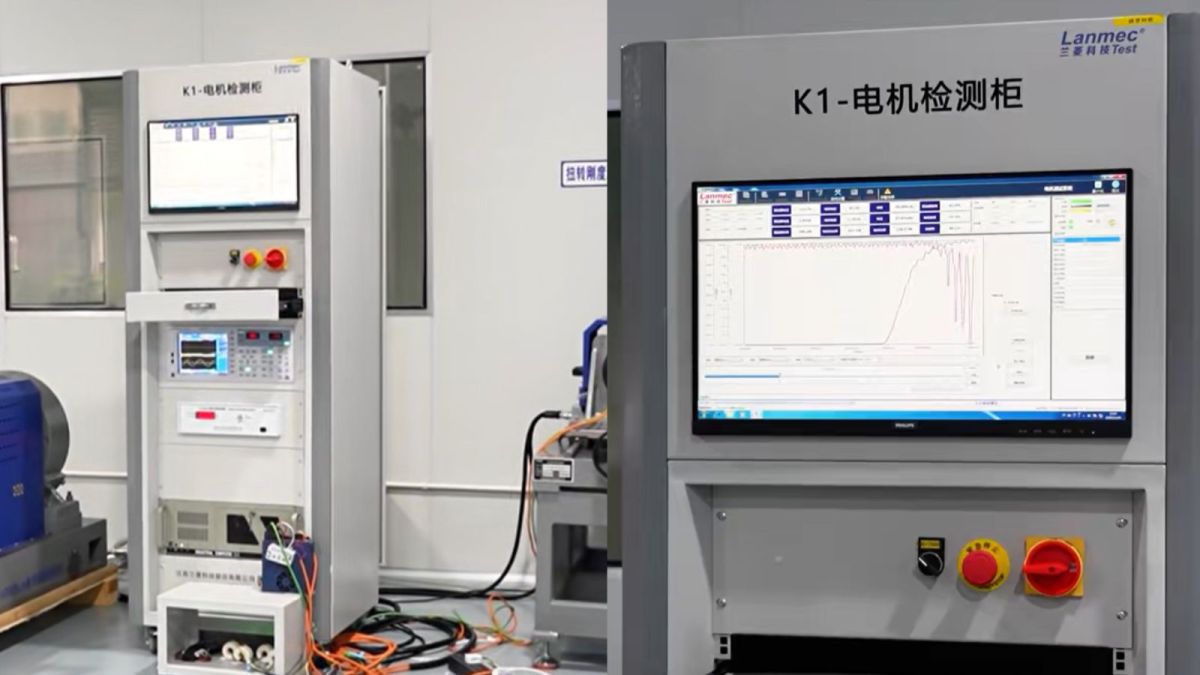
HONPINE’s development work focuses on several core technologies: torque-based force control, nonlinear friction identification, real-time motor winding resistance monitoring, high-precision sampling for force control, and external load inertia identification.
These technologies work together to support sensitive force detection and smooth, compliant movement in an integrated joint module.
Modular Design and Fully Closed-Loop Control
By bringing these technologies together, we have developed modular, lightweight, and cost-effective robot joint motors designed for intelligent control, greater integration, and easier installation.
The HONPINE HAG harmonic joint module supports fully closed-loop control and continuous 360° rotation, with a specified force-control accuracy of less than 1%.
HONPINE HAG Harmonic Joint Module: Key Specifications
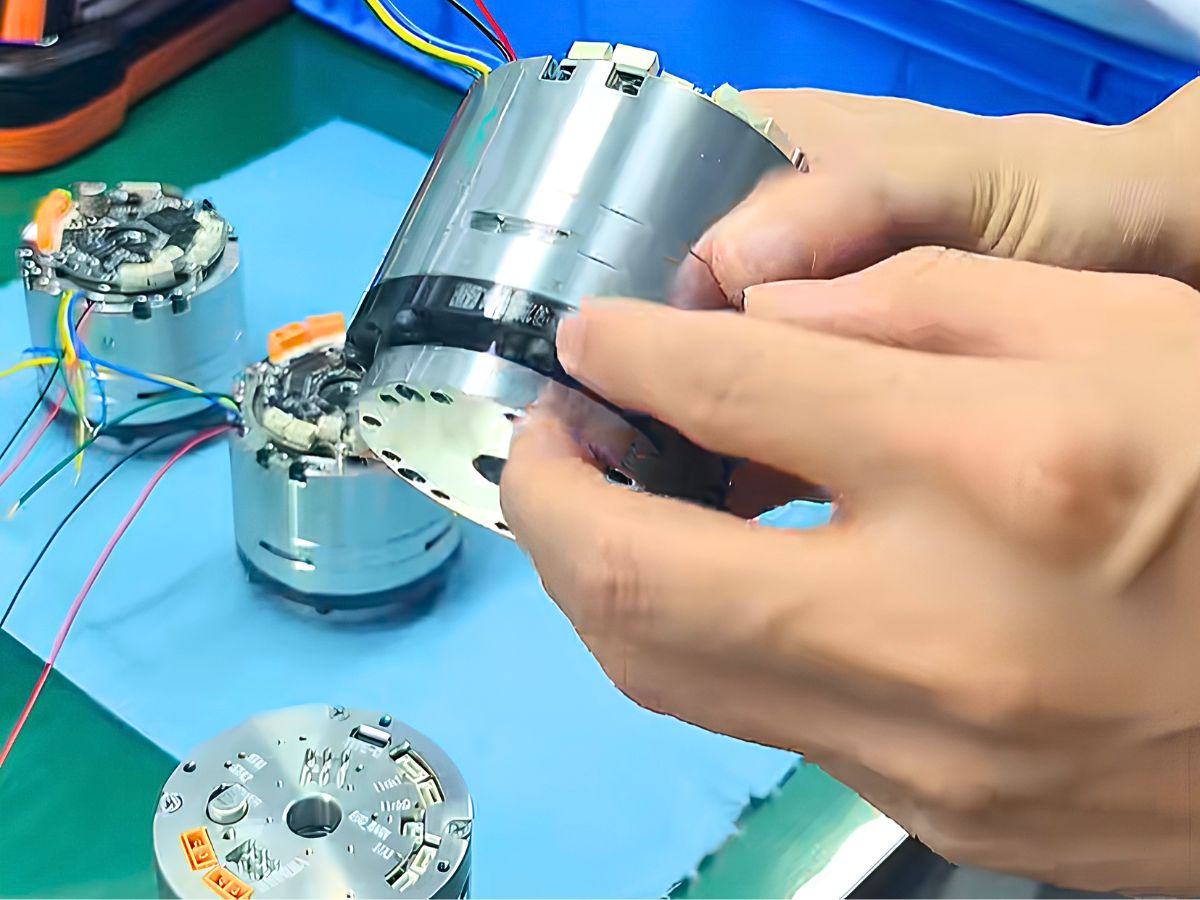
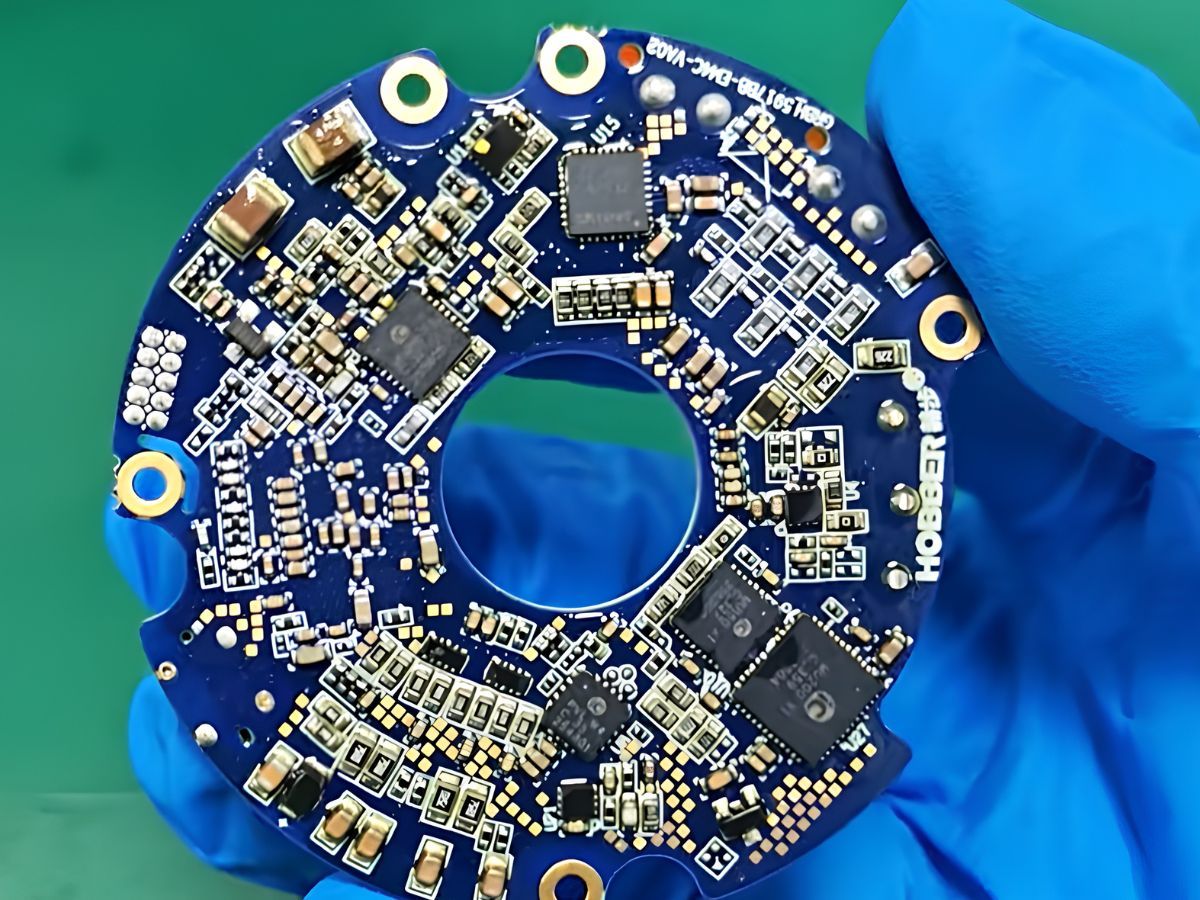
The HAG module combines precise positioning with force-controlled interaction. Its integrated drive-and-encoder design incorporates four iC-Haus chips, supporting a compact and highly integrated architecture.
The performance figures presented here are based on actual dynamometer measurements and calibration.
Our Vision: Robot Joint Modules Built for Real Industrial Applications
Measuring Performance Beyond Degrees of Freedom
Joint service life, force-control accuracy, module maintainability, and overall system cost are becoming more meaningful measures of robotic technology than the number of degrees of freedom alone.
At HONPINE, these priorities guide our development of harmonic robot joint modules.
Bringing Humanoid Robots into Industrial Environments
We believe humanoid robots should be more than showpieces for staged demonstrations. They should be capable of practical deployment in industrial environments and deliver real benefits to people.
Our goal is to provide the underlying joint technology that helps make this possible: precise motion, responsive force control, integrated construction, and a practical approach to cost and maintenance.
What questions or expectations do you have about the next generation of robot joint motors?
Learn More About HONPINE HAG Robot Joint Motors
Explore how the HONPINE HAG force-controlled harmonic robot joint motor could fit your robotics project.
Contact HONPINE for detailed specifications, touch-response demonstrations, and application discussions.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
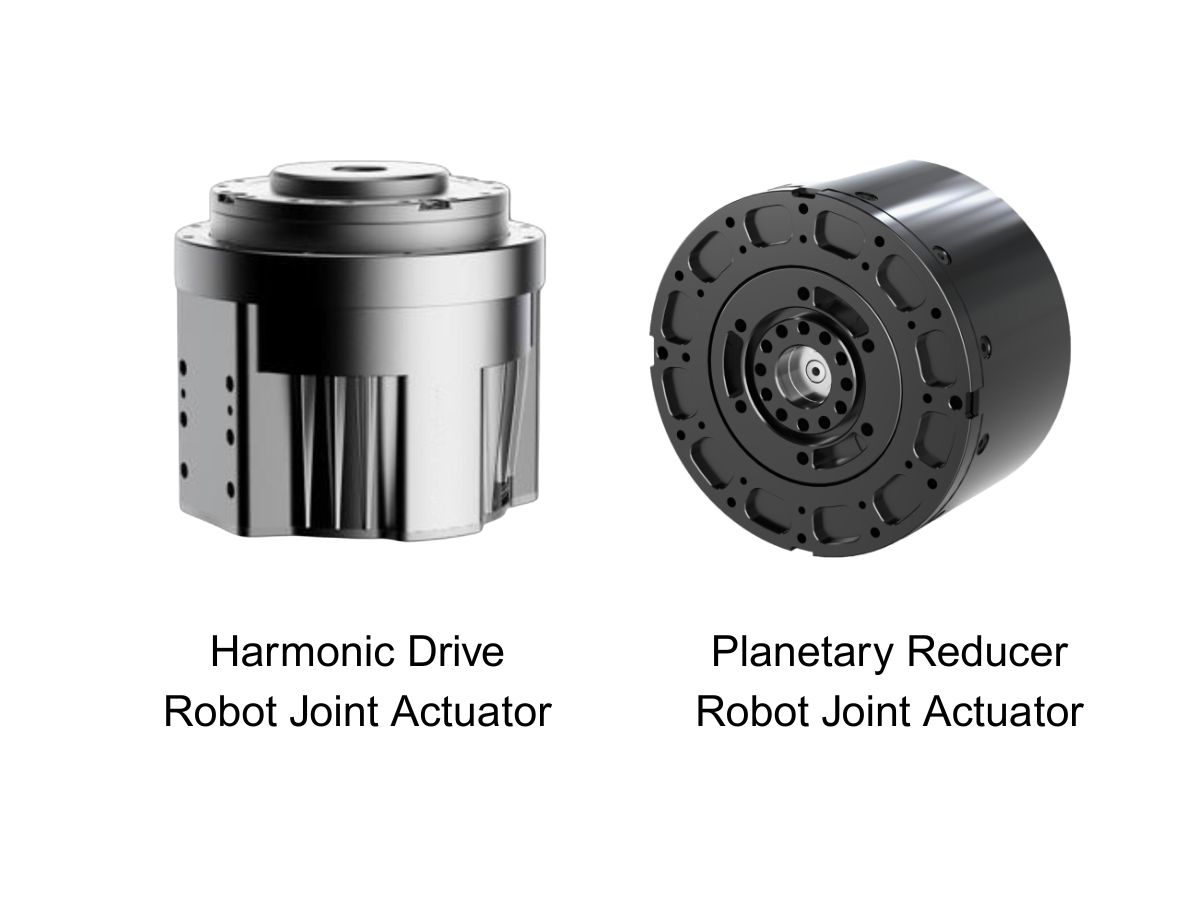
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
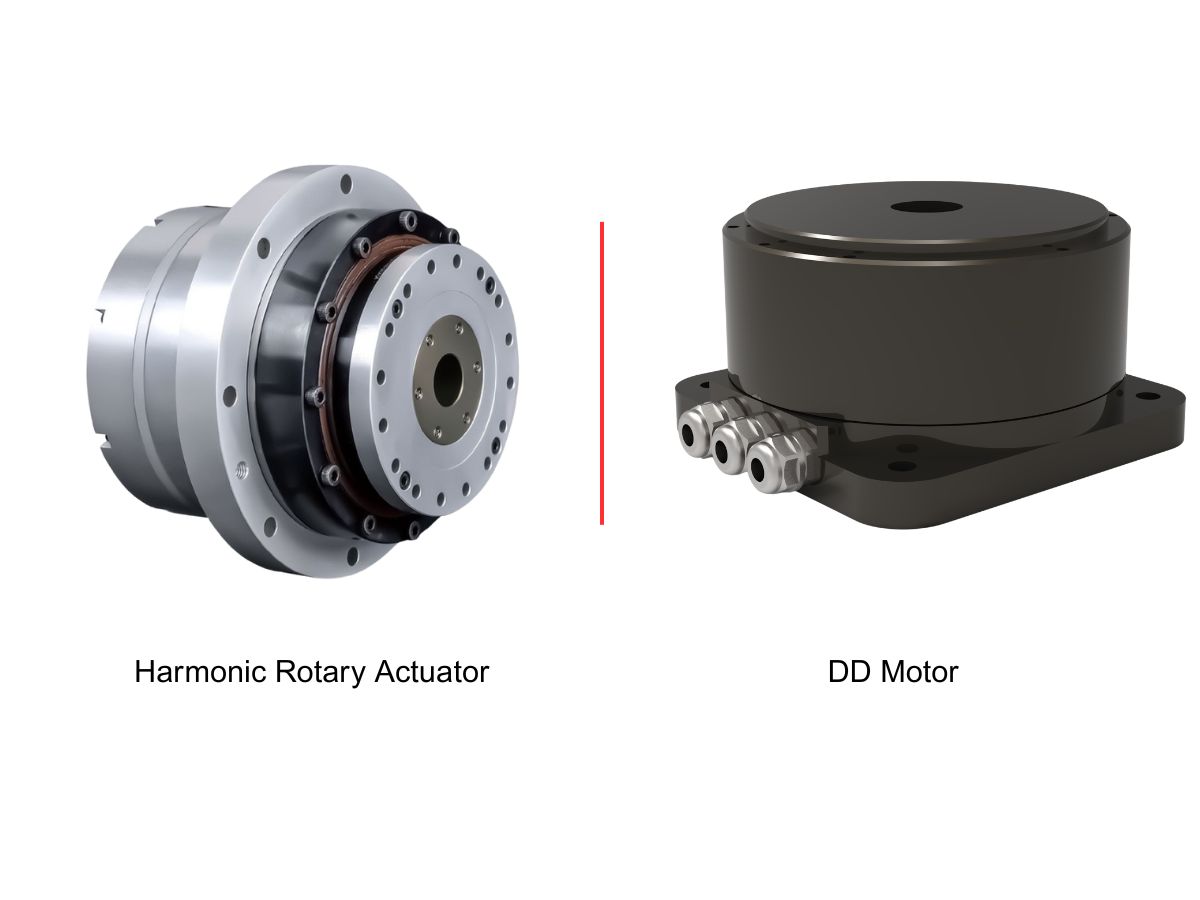
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
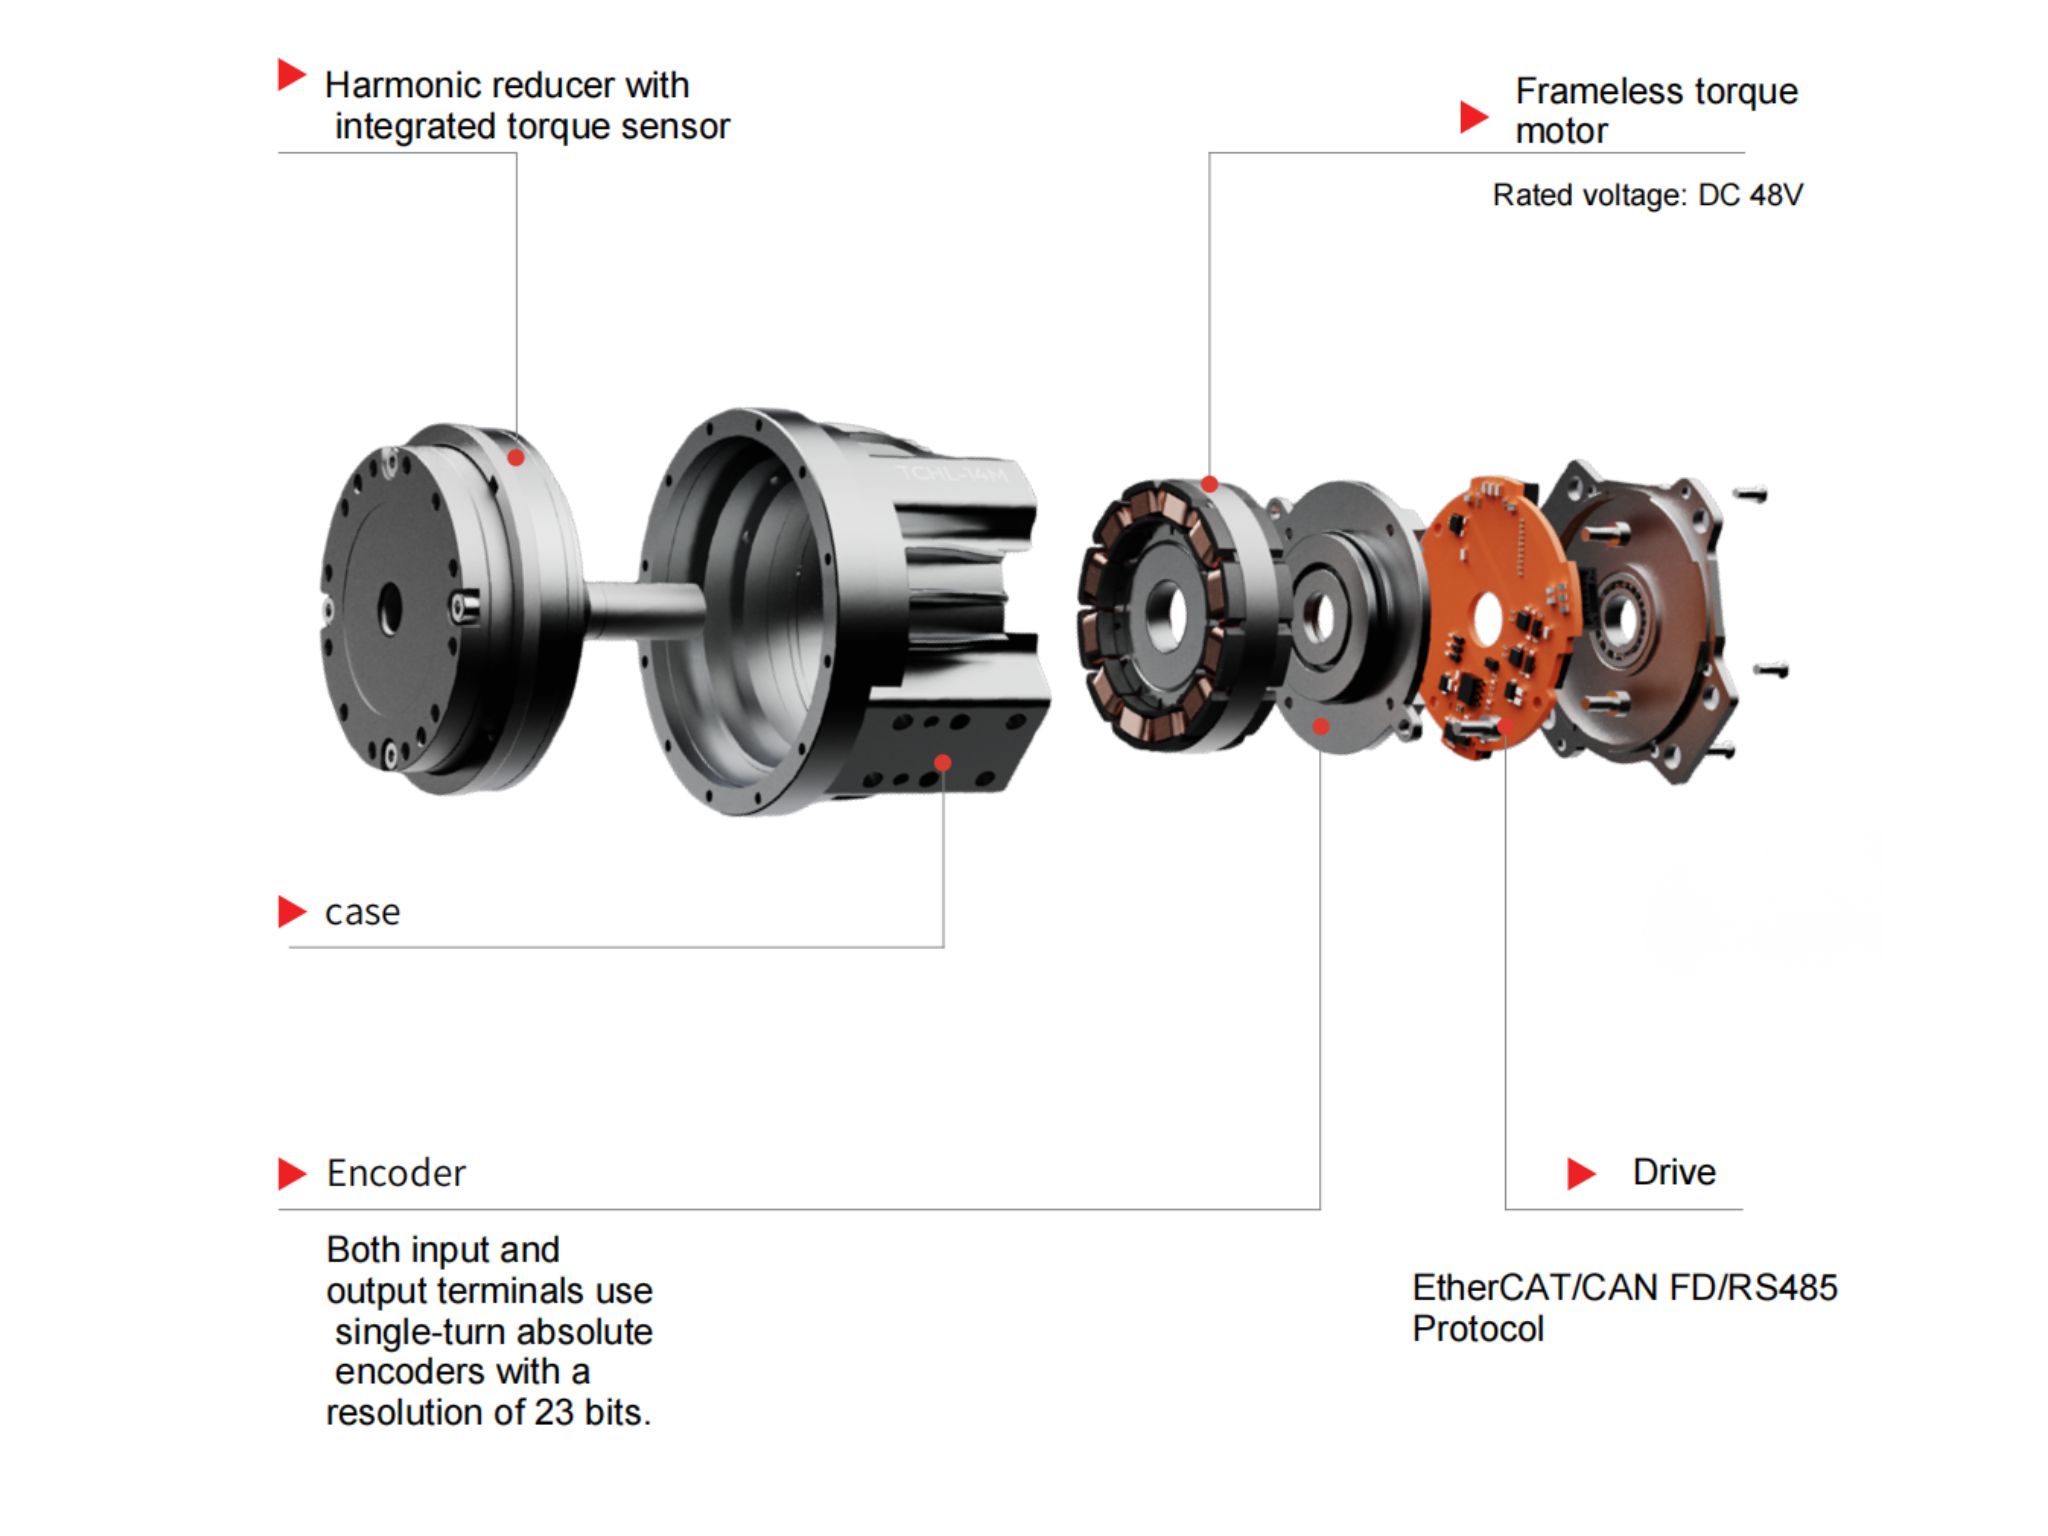
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.
 High-Precision Hollow Harmonic Rotary Actuator for CNC Machines and Heavy-Duty Rotary AxesHONPINE 58 Series Hollow Harmonic Rotary Actuator is designed for CNC rotary tables, precision rotary axes, laser processing equipment, and heavy-duty rotary positioning applications. With a 50 mm hollow bore, up to 2,722 N·m peak torque, integrated crossed roller bearing, multi-turn absolute encoder options, positioning accuracy below 30 arcsec, and repeat positioning accuracy below 5 arcsec, it combines high torque capacity with precision rotary motion and flexible mechanical integration.
 How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?HONPINE JRM planetary robot joint modules are designed for long-duration and high-load robotic operation. This article examines how motor electromagnetic optimization, high-efficiency planetary transmission, GaN-based drive technology, and system-level low-loss design help control temperature rise. Using the C6345 planetary robot joint module as a test example, HONPINE also presents full-load thermal validation under continuous operation, including motor efficiency up to 92%, planetary gearbox efficiency up to 97%, and a final equilibrium temperature of 61.42°C at a 25°C ambient temperature.
 Direct Drive Motor Sizing: A Complete Guide to Torque Calculation and SelectionSelecting a direct drive motor for a precision rotary system requires more than matching motor torque to the equipment weight. Engineers need to evaluate gravity torque, inertial torque, wind torque, friction, rotational inertia, speed, acceleration, duty cycle, and positioning requirements. In this guide, Theodore Li, Technical Director at HONPINE, explains a practical approach to direct drive motor sizing and torque calculation using an azimuth and elevation turntable as an engineering example. The article covers continuous and peak torque calculation, motor selection criteria, and the application of frameless direct drive motors in integrated rotary systems.
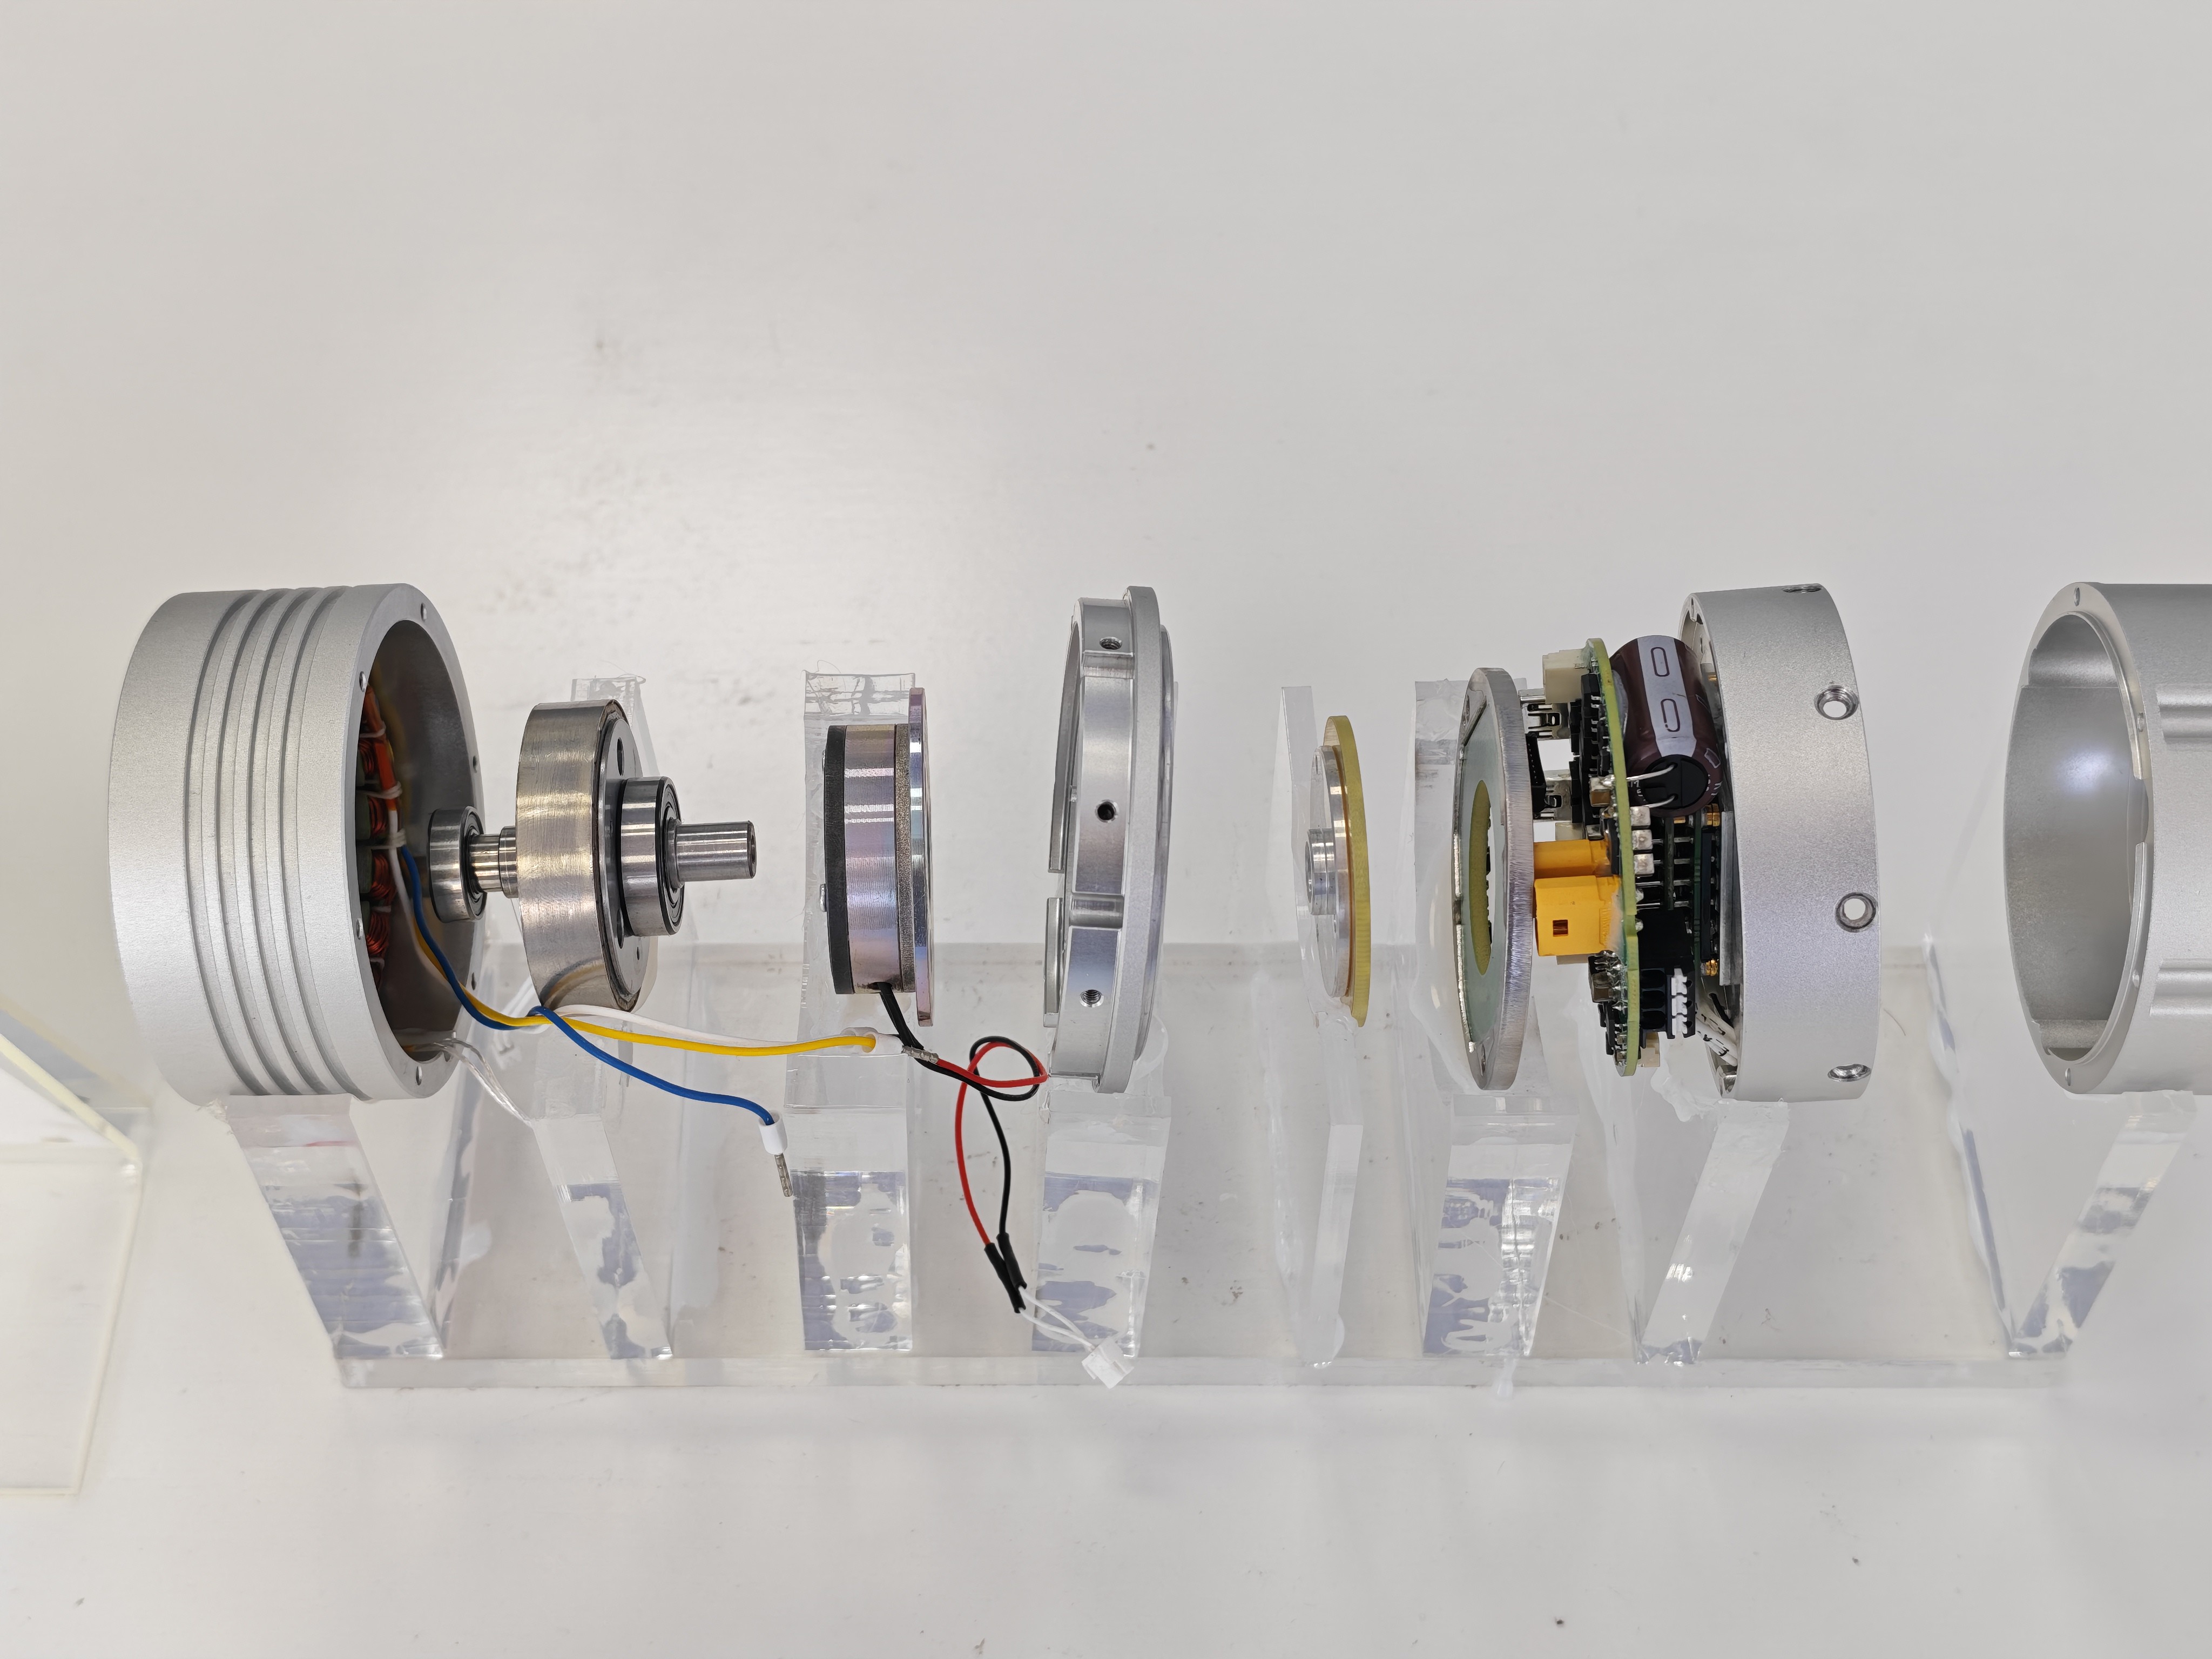
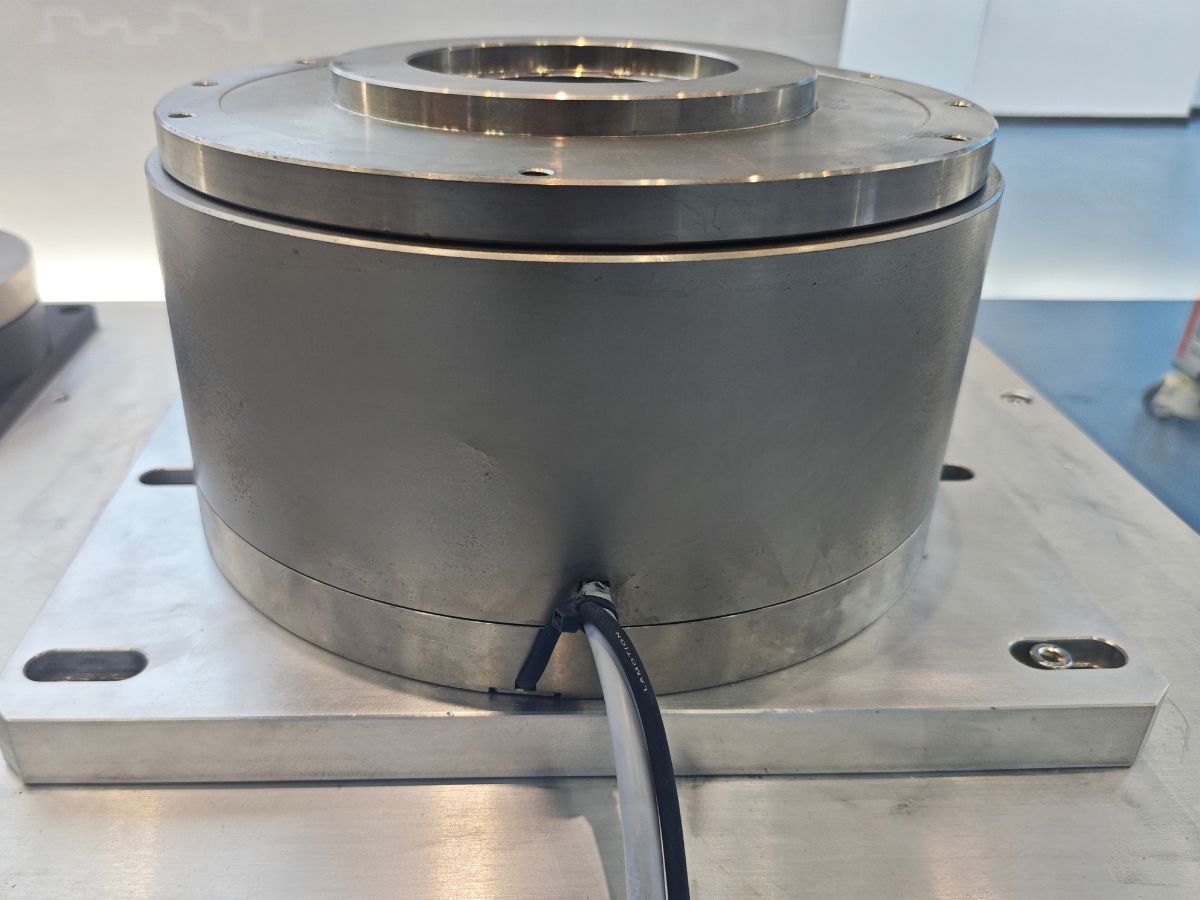
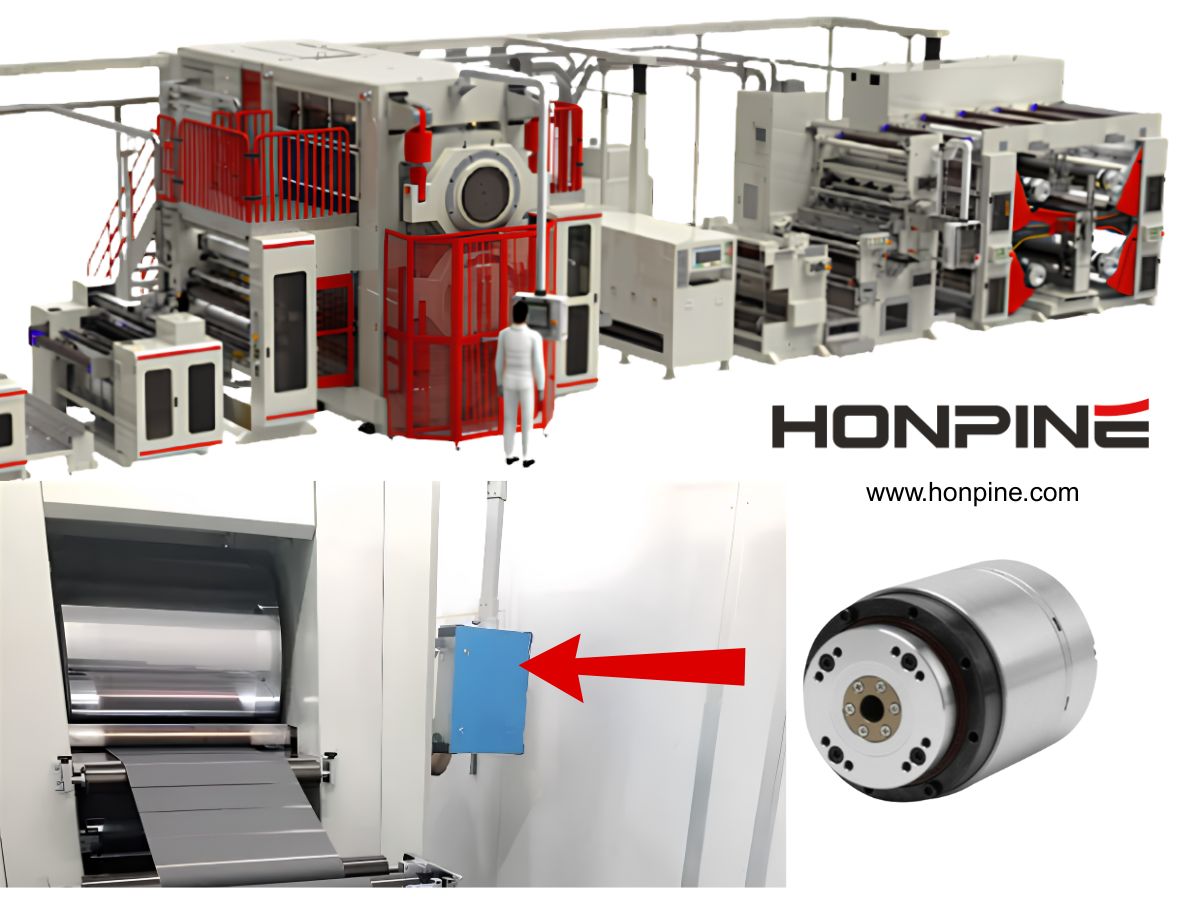
 Harmonic Rotary Actuator for Lithium Battery Roller Press EquipmentLithium battery manufacturing equipment requires higher precision, stability, and integration efficiency as production processes continue to evolve. In roller press equipment, accurate roller positioning, pressure control, and dynamic response are critical for ensuring electrode quality and consistency.
HONPINE harmonic rotary actuators provide high precision, high rigidity, fast response, and compact integration for lithium battery roller press equipment. With near-zero backlash, high torque density, and reliable motion control performance, they help improve equipment accuracy and production stability.
Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Can Robots Feel Touch? HONPINE HAG Force-Controlled Harmonic Robot Joint MotorsCan robots respond to a gentle touch? The HONPINE HAG robot joint motor with torque sensor combines a harmonic reducer, integrated torque sensing, and closed-loop control to detect external forces and support smooth, compliant motion. In this article, HONPINE founder Allen Li demonstrates the module's response to light contact and hand-guided movement, explains its key force-control technologies, and shares the vision behind joint modules designed for practical industrial robotics.
 Does a Higher Gearbox Ratio Mean More Torque? Planetary, Harmonic, and RV Gearboxes ExplainedDoes a higher gearbox ratio mean more torque? This engineering guide explains the relationship between gearbox ratio, output torque, and output speed, and compares planetary gearboxes, harmonic gearboxes, and RV gearboxes. Learn why reduction ratio alone cannot determine gearbox torque capacity, efficiency, dynamic response, precision, or service life, and what engineers should consider when selecting a gearbox for robotics, CNC machines, servo systems, and industrial motion control.
 High-Precision Hollow Harmonic Rotary Actuator for CNC Machines and Heavy-Duty Rotary AxesHONPINE 58 Series Hollow Harmonic Rotary Actuator is designed for CNC rotary tables, precision rotary axes, laser processing equipment, and heavy-duty rotary positioning applications. With a 50 mm hollow bore, up to 2,722 N·m peak torque, integrated crossed roller bearing, multi-turn absolute encoder options, positioning accuracy below 30 arcsec, and repeat positioning accuracy below 5 arcsec, it combines high torque capacity with precision rotary motion and flexible mechanical integration.
 How Does the HONPINE JRM Planetary Robot Joint Module Address Temperature Rise in Continuous Operation?HONPINE JRM planetary robot joint modules are designed for long-duration and high-load robotic operation. This article examines how motor electromagnetic optimization, high-efficiency planetary transmission, GaN-based drive technology, and system-level low-loss design help control temperature rise. Using the C6345 planetary robot joint module as a test example, HONPINE also presents full-load thermal validation under continuous operation, including motor efficiency up to 92%, planetary gearbox efficiency up to 97%, and a final equilibrium temperature of 61.42°C at a 25°C ambient temperature.
 Direct Drive Motor Sizing: A Complete Guide to Torque Calculation and SelectionSelecting a direct drive motor for a precision rotary system requires more than matching motor torque to the equipment weight. Engineers need to evaluate gravity torque, inertial torque, wind torque, friction, rotational inertia, speed, acceleration, duty cycle, and positioning requirements. In this guide, Theodore Li, Technical Director at HONPINE, explains a practical approach to direct drive motor sizing and torque calculation using an azimuth and elevation turntable as an engineering example. The article covers continuous and peak torque calculation, motor selection criteria, and the application of frameless direct drive motors in integrated rotary systems.
 How Integrated Robot Joint Modules Are Reshaping Robot Wiring and Control Architecture?Integrated robot joint modules are changing how robots are designed by combining the motor, reducer, drive, encoder, and sensing components into a compact motion unit. Compared with traditional distributed architectures, this integrated approach can reduce cable complexity, simplify power and communication connections, and support more compact robot structures. As humanoid robots demand higher levels of motion coordination, response speed, precision, and integration, robot joint modules are becoming an increasingly important interface between intelligent control systems and physical movement. This article explains how integrated robot joint modules reshape robot wiring and control architecture, using the HONPINE TCHL harmonic drive robot joint module as an example.
 Force-Controlled Harmonic Joint Modules: A Key Solution for Robot CommercializationAs robots move from precise positioning toward physical interaction, joint-level torque feedback is becoming increasingly important. A force-controlled robot joint module allows the robot to sense changes in output torque and respond more appropriately to external loads, supporting compliant motion, contact detection, and force-controlled applications. HONPINE HAG and HAU harmonic joint modules integrate torque sensing directly into the joint, enabling torque closed-loop control, 360° continuous output rotation, less than 1% torque control accuracy, and a 50 Hz torque bandwidth. This integrated design also maintains consistent dimensions between force-controlled and non-force-controlled configurations, providing a flexible joint platform for robot manufacturers.
 6 Key Advantages of the HONPINE JRM Planetary Joint ModuleHigh-performance quadruped robots require joint modules that can respond quickly, maintain precise positioning, withstand repeated impacts, and deliver stable torque under demanding operating conditions. The HONPINE JRM planetary joint module combines high positioning accuracy, low backlash, fast three-loop response, high static rigidity, strong overload capability, and a wide operating temperature range. With clearly defined continuous and overload operating limits, the JRM is designed to balance dynamic performance with long-term reliability. This article introduces six key advantages of the HONPINE JRM planetary joint module and explains why it is suitable for industrial inspection quadrupeds, specialized inspection robots, explosion-proof quadruped robots, and other high-performance robotic platforms.
 Robot Joint Module Solutions for Humanoid Robot Arms and LegsHumanoid robots require different joint characteristics across the shoulder, elbow, wrist, hip, knee, and ankle. Smaller joints prioritize low weight and fast response, while larger joints require higher torque density, load capacity, and reliability. A suitable robot joint module should therefore be matched to the specific torque, weight, range of motion, and control requirements of each joint. In this article, HONPINE uses the HPJM harmonic joint module series as an example to present a joint configuration solution for humanoid robot upper and lower limbs, covering torque requirements from small wrist and finger joints to high-load hip joints.