Ultra-Compact Harmonic Joint Module with a 6 mm Hollow Shaft
Meet the HONPINE HPJM harmonic joint module, an ultra-compact integrated robot joint actuator designed for applications where installation space, cable routing, and motion-control precision are critical. Despite its compact size and high level of integration, this module features a 6 mm through-hole for internal cable routing. It is suitable for humanoid robots, drones, optical platforms, and precision automation systems that require compact, high-performance rotary joints.
In this article, Theodore Li, Technical Director at HONPINE, introduces the key specifications, structural design, and engineering advantages of the HPJM harmonic joint module.
HONPINE HPJM Harmonic Joint Module: Key Specifications
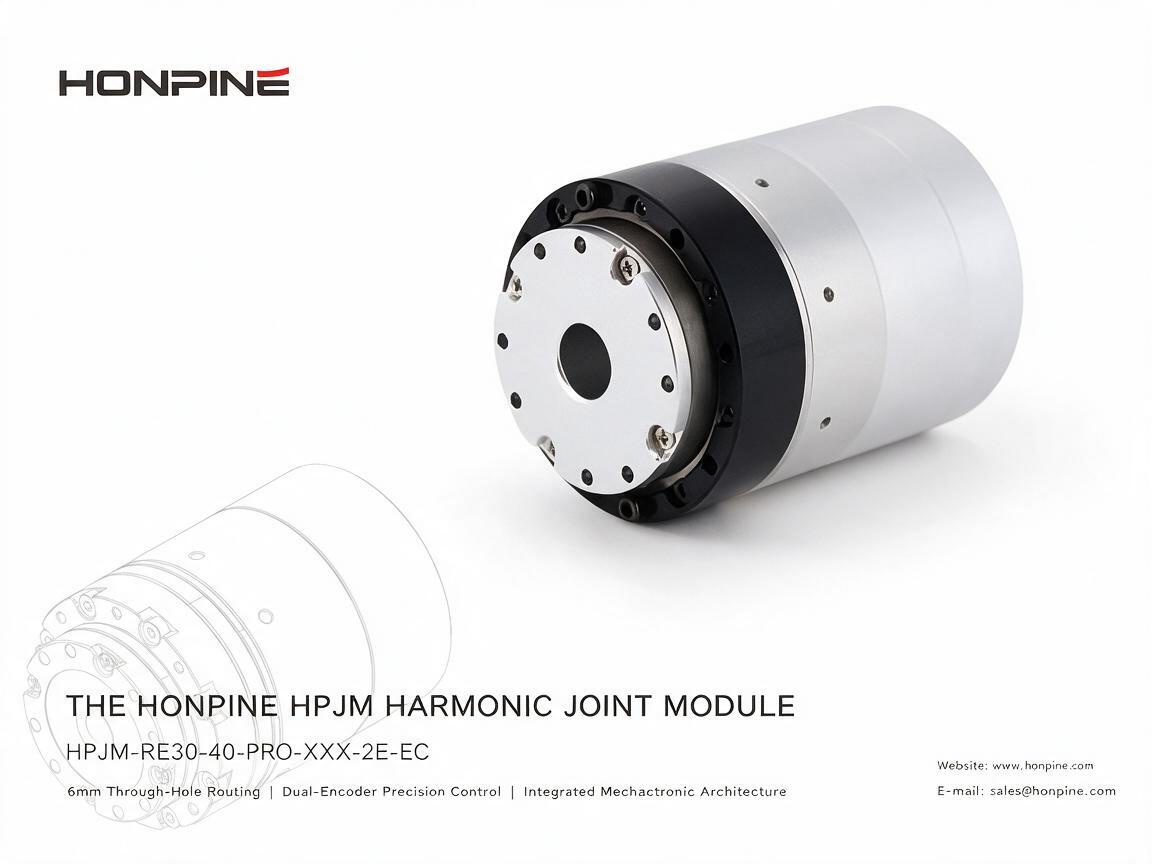
The HONPINE HPJM harmonic joint module, identified in the engineering drawing as HPJM-RE30-40-PRO-XXX-2E-EC, combines a compact hollow-shaft design, dual-encoder feedback, and a highly integrated mechatronic architecture (MEA).
Its key structural advantages include a 6 mm through-hole for cable routing, an integrated motor and drive system, and a dual-encoder configuration designed to support precise motion control.
Why Choose the HONPINE HPJM Harmonic Joint Module?
1. Highly Integrated Mechatronic Design
The HPJM integrates a harmonic reducer, frameless torque motor, 16-bit encoder, and FOC (field-oriented control) drive into a compact housing measuring Ø57 × 60.5 mm.
Instead of separately selecting and integrating a motor, reducer, encoder, and drive, customers receive a highly integrated joint module designed to simplify system development. This can reduce component-matching work, shorten integration time, and accelerate robot development.
For robot manufacturers, this integrated architecture helps streamline mechanical and electrical design while reducing the complexity of joint-level assembly and commissioning.
2. 6 mm Through-Hole for Internal Cable Routing
One of the HPJM's key features is its Ø6 mm hollow shaft, which provides a through-hole for routing cables and, where the application design permits, pneumatic lines through the center of the joint.
Internal routing helps reduce external cable interference and can minimize cable twisting or snagging during joint rotation, depending on the routing arrangement and permitted rotation range.
This feature is particularly valuable in humanoid robots and compact robotic systems, where multiple cables must pass through tightly constrained joint structures. Compared with a non-hollow design of similar dimensions, a through-hole configuration offers greater flexibility for internal cable routing.
3. Dual EtherCAT Interfaces for Daisy-Chain Networking
The engineering drawing identifies two EtherCAT connectors: EtherCAT_Input and EtherCAT_Output, using X1002WVS-04L connectors.
This input/output configuration supports daisy-chain networking, allowing multiple joint modules to be connected in sequence rather than requiring a separate point-to-point communication cable for every joint.
For humanoid robots with more than 20 joints, a daisy-chain architecture can help reduce cabling complexity and simplify system wiring.
The PRO version also includes a separate firmware download interface, allowing individual module firmware updates without relying exclusively on the main communication connection.
Actual network topology, supported node count, and firmware-update procedures should be confirmed against the selected model and controller configuration.
4. Rear-Mounted Electrical Interfaces
The power connector, communication interfaces, and firmware download port are concentrated on the rear face of the module. The drawing identifies the power connector as A1257WV-S-2P.
This rear-mounted layout keeps the output flange and radial surfaces free from protruding connectors and external cable outlets. It can simplify mechanical integration, reduce interference with surrounding structures, and facilitate enclosure design.
For robot joints that require large angular movements or installation inside a compact arm housing, this arrangement provides greater flexibility in connector placement and cable management.
The final design should still account for connector clearance, cable bending radius, thermal management, and the intended rotation range.
5. Symmetrical Mounting Flanges for Flexible Installation
The HPJM features symmetrical mounting interfaces on both ends, helping simplify mechanical integration across different robot joint positions.
According to the supplied drawing information, the mounting configuration includes Ø38 mm and Ø37.5 mm bolt-circle patterns, eight M2.5 threaded holes, and three M2 through-holes.
This symmetrical arrangement can make the same joint module adaptable to different installation orientations, potentially supporting shoulder, elbow, wrist, and hip joint applications, subject to the mechanical requirements of each joint.
For robot manufacturers, a common mounting interface can help reduce the number of mechanical variants, simplify spare-parts management, and improve modularity across a robotic platform.
6. Low Backlash and High Shock-Torque Capability
The HPJM uses harmonic transmission technology, which is known for its low-backlash characteristics. The supplied specifications indicate an output positioning accuracy of approximately 0.67 arcmin and a shock-torque capability of approximately 1.8 times the rated torque.
These characteristics can be beneficial in robotic applications involving frequent direction changes, acceleration and deceleration, and transient mechanical loads.
However, backlash, positioning accuracy, repeatability, and lost motion are different performance indicators. The actual output performance depends on the selected model, load conditions, control configuration, and measurement method. Similarly, the allowable shock torque must be interpreted according to the manufacturer's rating conditions and should not be treated as a continuous operating torque.
For applications such as humanoid robots and precision automation equipment, engineers should evaluate these parameters together with rated torque, peak torque, torsional stiffness, speed, and thermal performance.
Applications of the HONPINE HPJM Harmonic Joint Module
Humanoid Robots
Humanoid robots require compact joint modules that can fit within limited limb space while supporting precise motion control and integrated cable routing. The HPJM's compact housing, hollow shaft, and integrated drive architecture make it a candidate for shoulder, elbow, wrist, and hip joint designs, subject to the torque and dynamic requirements of each joint.
Drones and Compact Robotic Systems
In compact robotic platforms and selected drone-related mechanisms, installation space and component integration are important design considerations. An integrated harmonic joint module can simplify the assembly of rotary mechanisms where its weight, torque, speed, and power requirements match the application.
Optical Platforms and Precision Automation
Optical positioning systems and precision automation equipment may require compact rotary drives with controlled motion and repeatable positioning. The HPJM can be evaluated for these applications based on the required angular accuracy, vibration characteristics, motion profile, and environmental conditions.
The HONPINE HPJM harmonic joint module combines a compact hollow-shaft structure, integrated motor and drive components, dual-encoder architecture, and EtherCAT connectivity in a single rotary joint solution.
Its 6 mm through-hole helps accommodate internal cable routing, while its rear-mounted connectors and symmetrical mounting interfaces provide flexibility for mechanical integration. These features make the HPJM worth considering for humanoid robots, compact robotic systems, optical platforms, and precision automation applications.
If you are developing a compact robot joint or looking for an integrated harmonic joint actuator, contact HONPINE for detailed specifications, engineering drawings, and model selection support.
Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 How Does a Harmonic Joint Actuator with a Torque Sensor Improve Robot Force Control?Learn how the HONPINE TCHL harmonic joint actuator uses an integrated output torque sensor to support force feedback, collision detection, compliant assembly, rehabilitation robotics, and teleoperation.
 Ultra-Compact Harmonic Joint Module with a 6 mm Hollow ShaftAs humanoid robots and compact robotic systems evolve, joint modules must deliver high torque density, precise motion control, and flexible cable routing within increasingly limited installation space. The HONPINE HPJM-RE30-40-PRO harmonic joint module addresses these challenges with a compact design, a 6 mm hollow shaft, dual-encoder feedback, and an integrated motor and FOC drive. In this article, we explore its key design features and explain how its hollow-shaft structure, EtherCAT connectivity, and flexible mounting options support the development of humanoid robots, drones, optical platforms, and precision automation equipment.
 Harmonic Drive Actuator Accuracy: Why It Should Be Evaluated at Four LevelsHarmonic drive actuator accuracy involves more than encoder resolution. Why should engineers evaluate it at four levels? Resolution, repeatability, unidirectional positioning accuracy, and bidirectional positioning accuracy describe different aspects of motion performance. Understanding these differences helps engineers select harmonic rotary actuators for semiconductor equipment, EFEM systems, and 3C automation without confusing theoretical encoder increments with actual positioning performance.
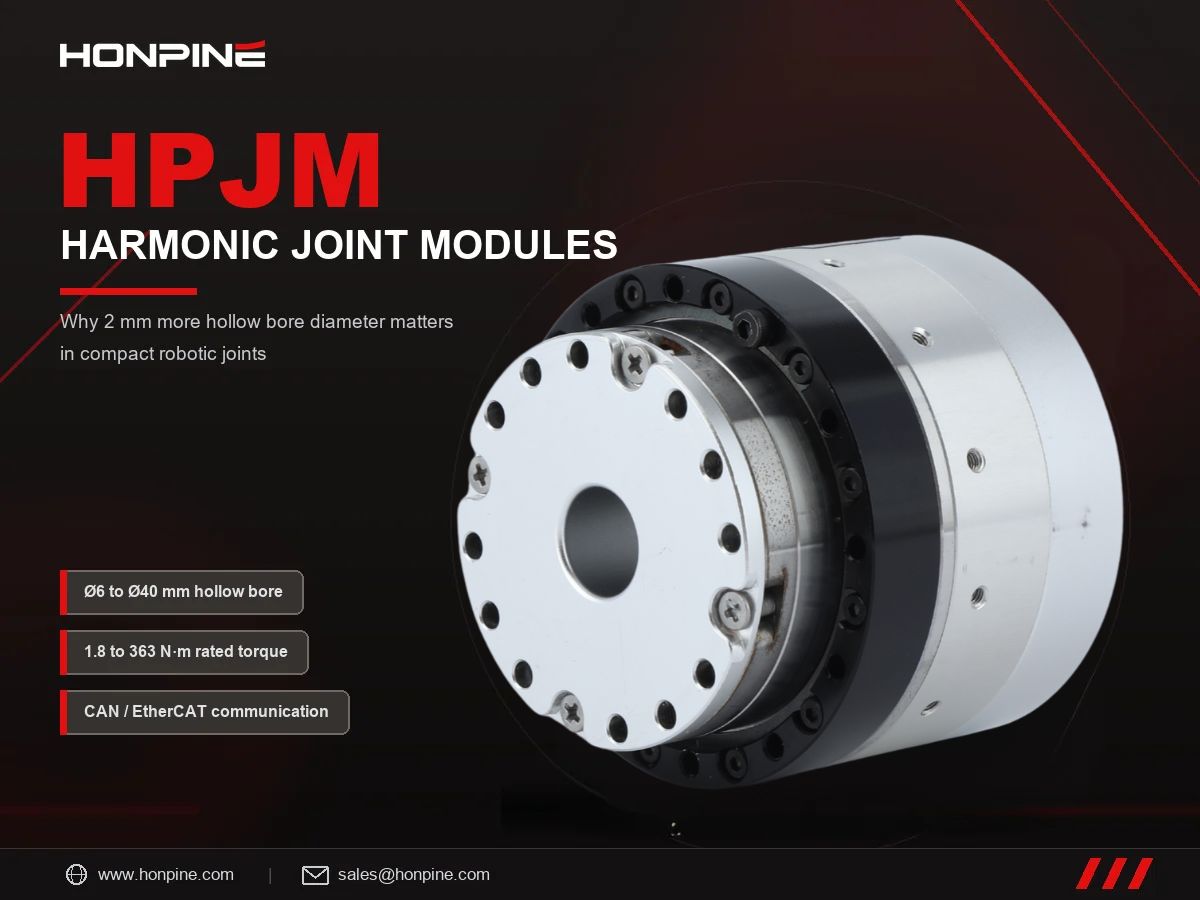
 Why Do Many Customers Choose HONPINE HPJM Harmonic Joint Modules for Just 2 mm More Hollow Bore Diameter?Why do many customers choose HONPINE HPJM harmonic joint modules for just 2 mm more hollow bore diameter? In compact robotic joints, this small dimensional difference can create a surprisingly large increase in available space. Because the cross-sectional area of a circular bore increases with the square of its diameter, an extra 2 mm can significantly improve internal cable routing and simplify system integration. This article examines the impact of hollow bore diameter, compares selected HONPINE HPJM models with comparable harmonic joint modules, and explains why bore size matters in humanoid robots, collaborative robots, and industrial automation.
 Harmonic Drive Backlash in Arcmin: What the Specification Really Tells YouChoosing the right force control harmonic joint actuator involves more than comparing torque and dimensions. Torque sensor specifications, encoder feedback, communication protocols, functional safety, and hollow-shaft size can all affect system integration and control performance. In this guide, HONPINE Technical Director compares the TCHL and HAG harmonic joint actuator series, explaining their key differences and providing a practical selection framework for humanoid robots, collaborative manipulators, precision assembly, polishing, and other force-controlled applications.
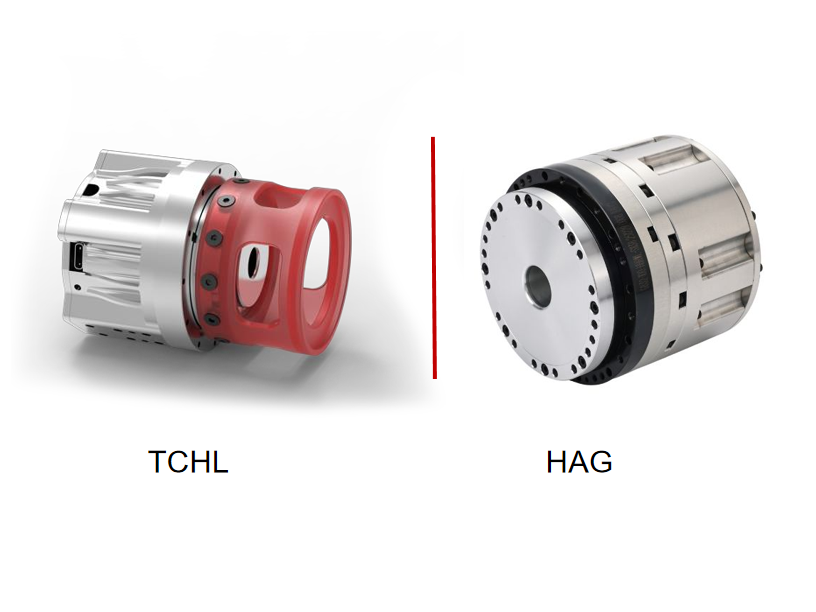
 How to Choose a Force Control Harmonic Joint Actuator? An In-Depth Comparison of HONPINE TCHL and HAGChoosing the right force control harmonic joint actuator involves more than comparing torque and dimensions. Torque sensor specifications, encoder feedback, communication protocols, functional safety, and hollow-shaft size can all affect system integration and control performance. In this guide, HONPINE Technical Director compares the TCHL and HAG harmonic joint actuator series, explaining their key differences and providing a practical selection framework for humanoid robots, collaborative manipulators, precision assembly, polishing, and other force-controlled applications.

Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
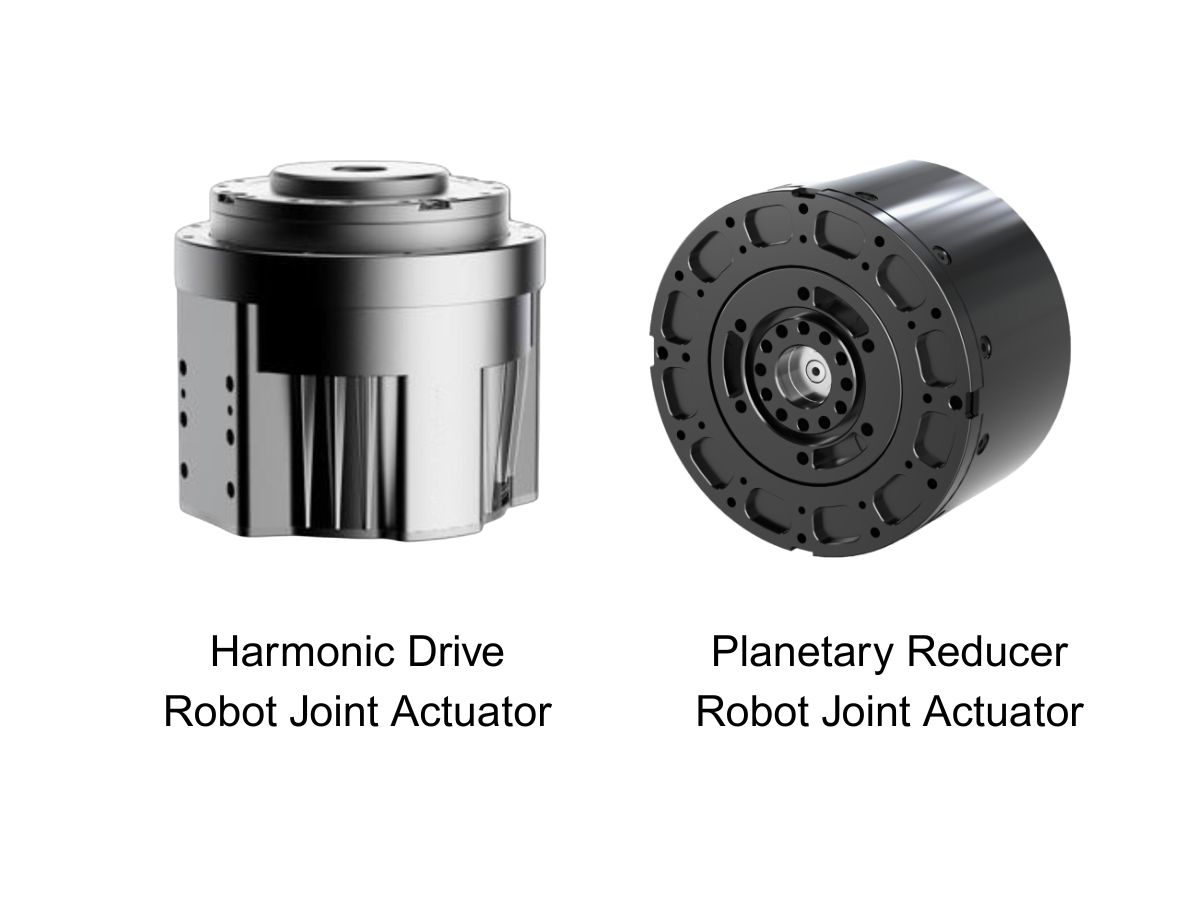
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
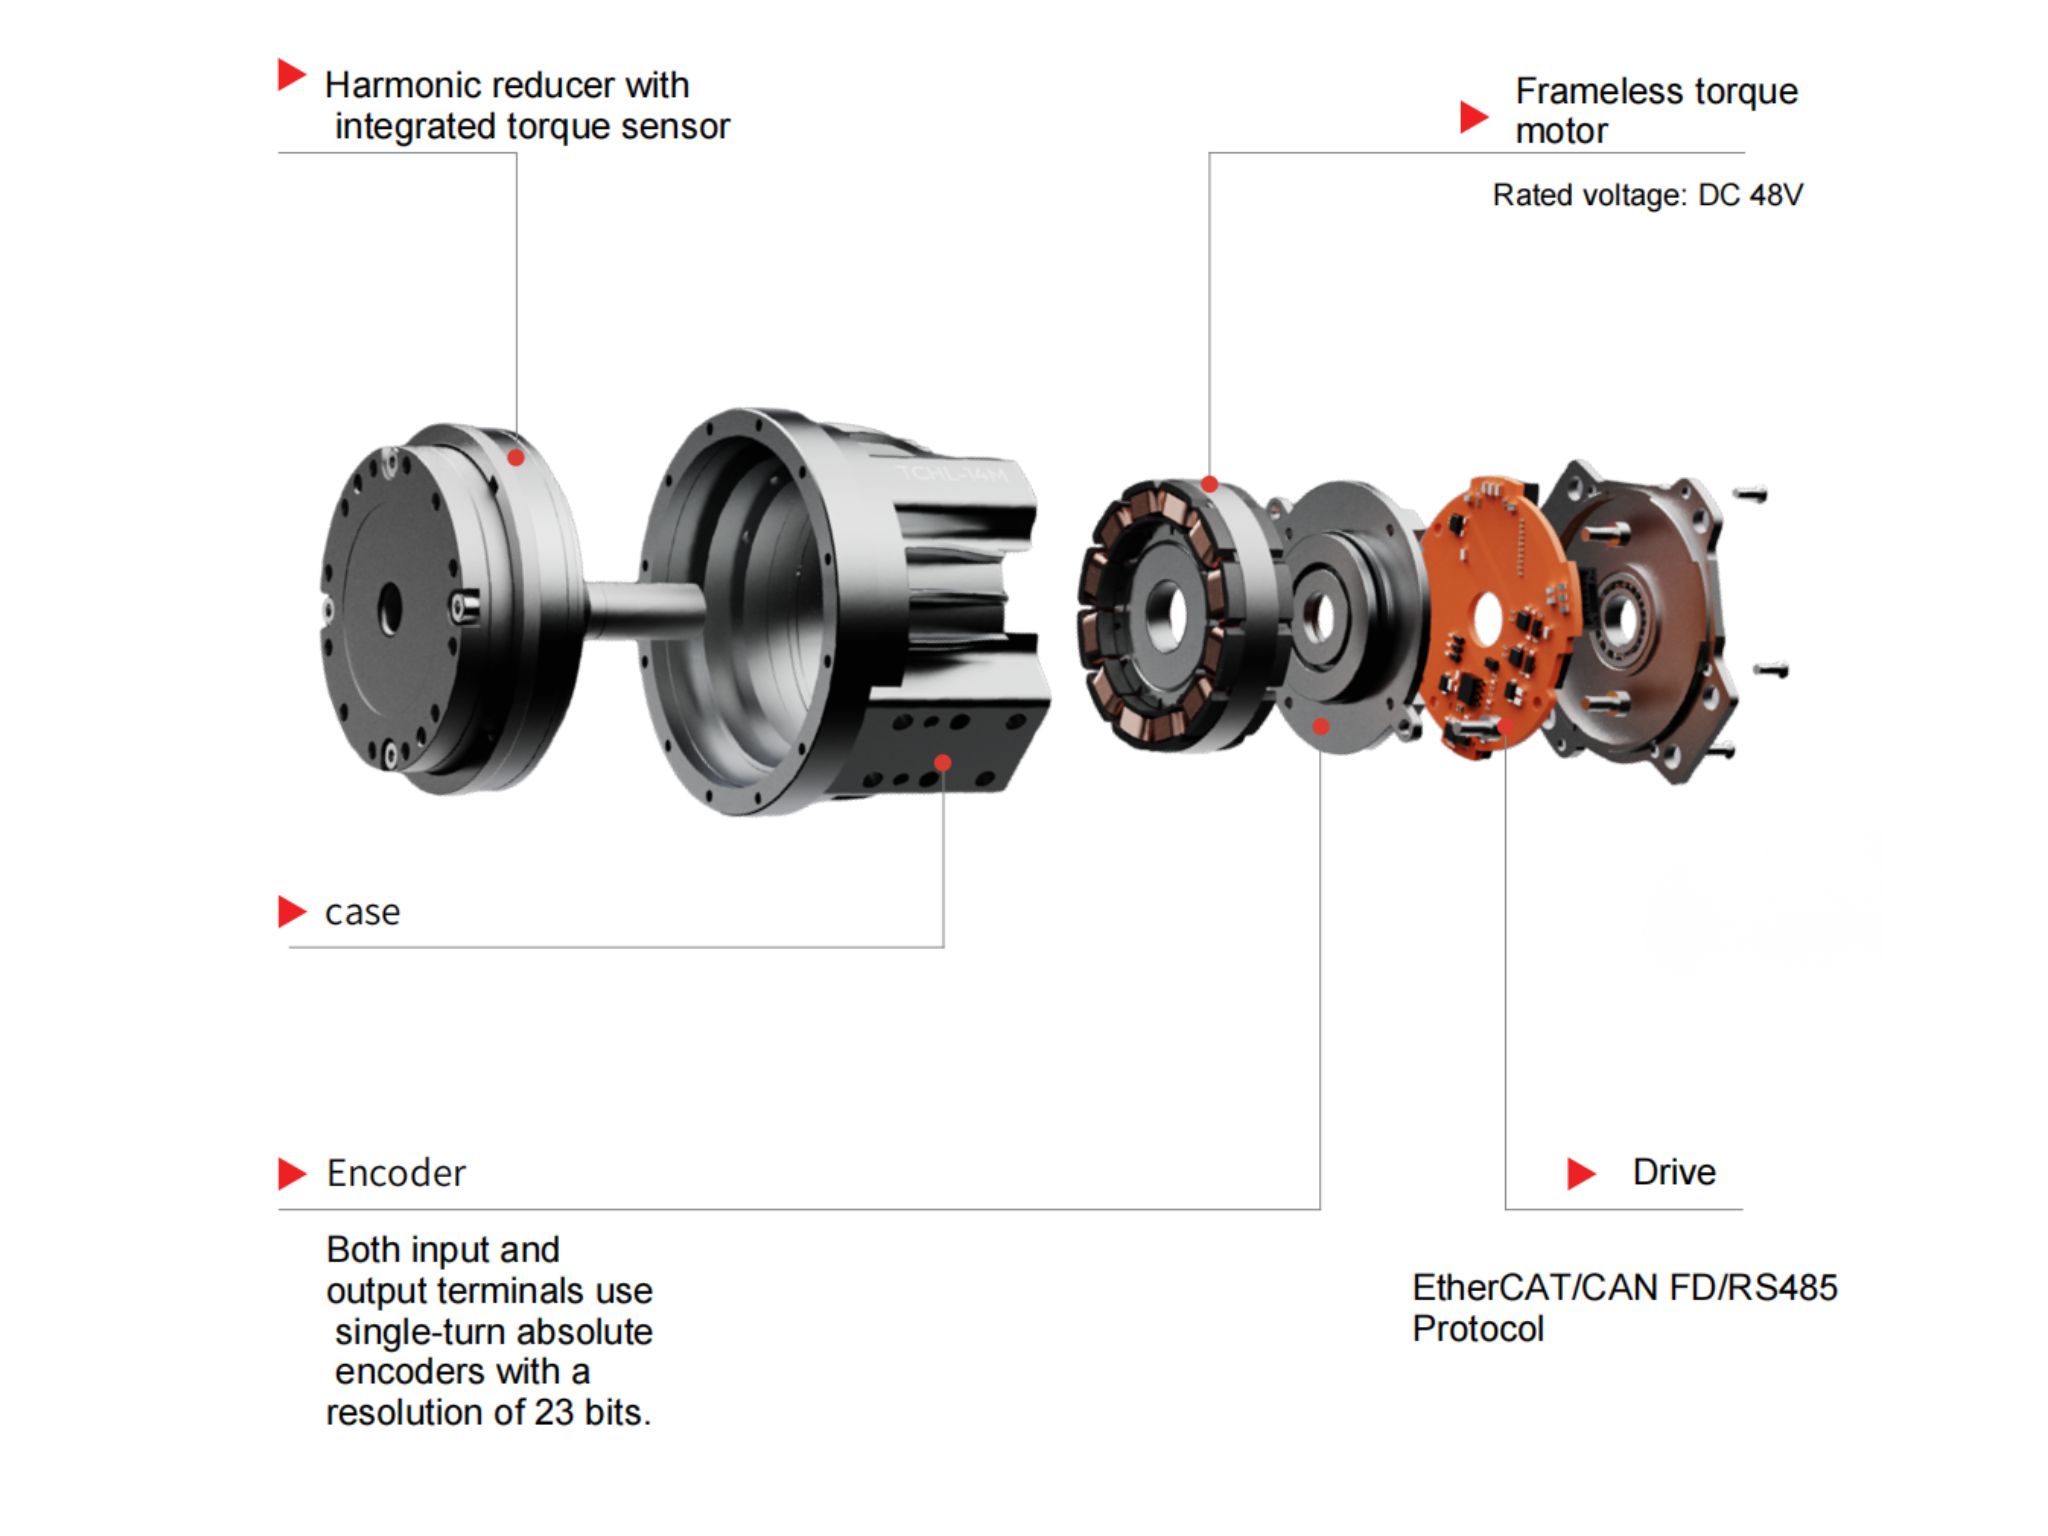
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 How Does a Harmonic Joint Actuator with a Torque Sensor Improve Robot Force Control?Learn how the HONPINE TCHL harmonic joint actuator uses an integrated output torque sensor to support force feedback, collision detection, compliant assembly, rehabilitation robotics, and teleoperation.
 Ultra-Compact Harmonic Joint Module with a 6 mm Hollow ShaftAs humanoid robots and compact robotic systems evolve, joint modules must deliver high torque density, precise motion control, and flexible cable routing within increasingly limited installation space. The HONPINE HPJM-RE30-40-PRO harmonic joint module addresses these challenges with a compact design, a 6 mm hollow shaft, dual-encoder feedback, and an integrated motor and FOC drive. In this article, we explore its key design features and explain how its hollow-shaft structure, EtherCAT connectivity, and flexible mounting options support the development of humanoid robots, drones, optical platforms, and precision automation equipment.
 Harmonic Drive Actuator Accuracy: Why It Should Be Evaluated at Four LevelsHarmonic drive actuator accuracy involves more than encoder resolution. Why should engineers evaluate it at four levels? Resolution, repeatability, unidirectional positioning accuracy, and bidirectional positioning accuracy describe different aspects of motion performance. Understanding these differences helps engineers select harmonic rotary actuators for semiconductor equipment, EFEM systems, and 3C automation without confusing theoretical encoder increments with actual positioning performance.
 Why Do Many Customers Choose HONPINE HPJM Harmonic Joint Modules for Just 2 mm More Hollow Bore Diameter?Why do many customers choose HONPINE HPJM harmonic joint modules for just 2 mm more hollow bore diameter? In compact robotic joints, this small dimensional difference can create a surprisingly large increase in available space. Because the cross-sectional area of a circular bore increases with the square of its diameter, an extra 2 mm can significantly improve internal cable routing and simplify system integration. This article examines the impact of hollow bore diameter, compares selected HONPINE HPJM models with comparable harmonic joint modules, and explains why bore size matters in humanoid robots, collaborative robots, and industrial automation.
 Harmonic Drive Backlash in Arcmin: What the Specification Really Tells YouChoosing the right force control harmonic joint actuator involves more than comparing torque and dimensions. Torque sensor specifications, encoder feedback, communication protocols, functional safety, and hollow-shaft size can all affect system integration and control performance. In this guide, HONPINE Technical Director compares the TCHL and HAG harmonic joint actuator series, explaining their key differences and providing a practical selection framework for humanoid robots, collaborative manipulators, precision assembly, polishing, and other force-controlled applications.
 How to Choose a Force Control Harmonic Joint Actuator? An In-Depth Comparison of HONPINE TCHL and HAGChoosing the right force control harmonic joint actuator involves more than comparing torque and dimensions. Torque sensor specifications, encoder feedback, communication protocols, functional safety, and hollow-shaft size can all affect system integration and control performance. In this guide, HONPINE Technical Director compares the TCHL and HAG harmonic joint actuator series, explaining their key differences and providing a practical selection framework for humanoid robots, collaborative manipulators, precision assembly, polishing, and other force-controlled applications.
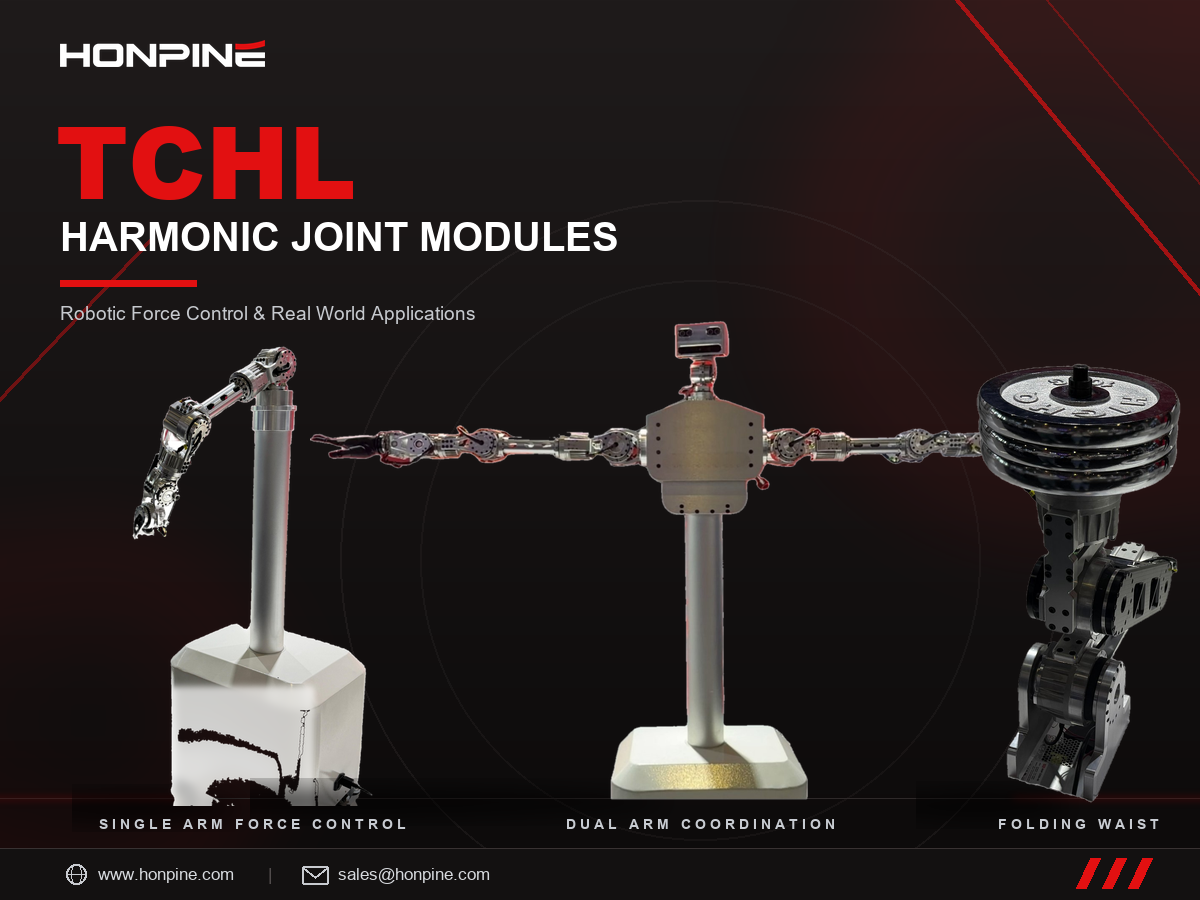
 HONPINE TCHL Harmonic Joint Modules: Robotic Force Control and Real-World ApplicationsHello everyone, I’m Theodore Li, Technical Director at HONPINE.
HONPINE TCHL harmonic joint modules have been deployed in a range of robotic motion-control applications, including dual-arm humanoid robots, single-arm compliant force control, and folding waist mechanisms for wheeled humanoid robots. As integrated motion components, they support a wide range of applications in robotics, intelligent manufacturing, and industrial automation.
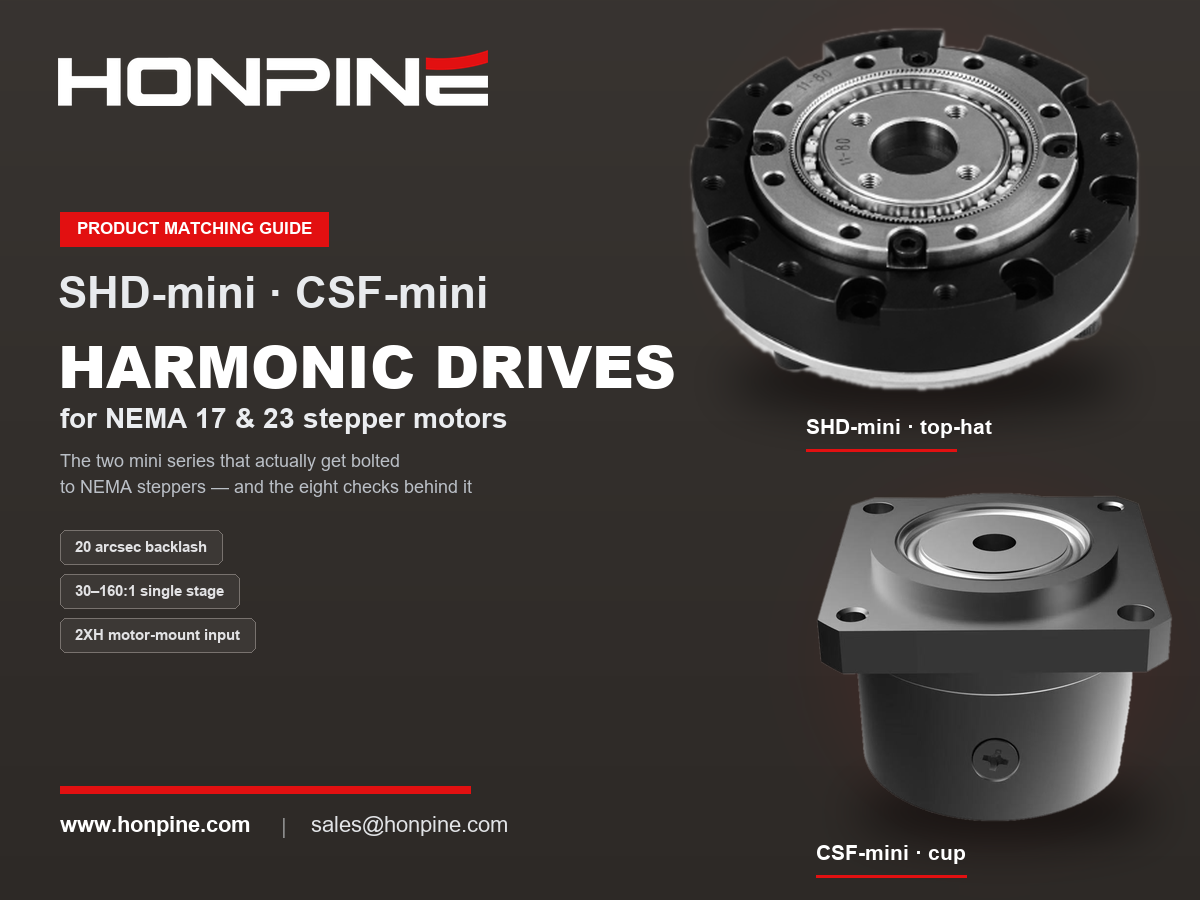
From core components to integrated motion units, HONPINE showcases the possibilities of precision transmission technology across different robotic applications through a diverse product portfolio and practical motion demonstrations. NEMA 17 & NEMA 23 Harmonic Drive Matching Guide: Pairing Stepper Motors with Harmonic ReducersPairing a stepper motor with a harmonic drive is not a budget compromise. A stepper's weak points — the coarse step angle, torque collapse above roughly 400 rpm, and the lack of a precision transmission — are exactly what a harmonic drive fixes: it pulls the operating point into the low-speed, high-torque sweet spot, refines a 1.8° step angle into arc-second resolution, and delivers near-zero backlash. This guide explains what NEMA frame sizes mean at the mounting interface, which harmonic frames match NEMA 17 and NEMA 23, the eight checks to run in order — including the input-side no-load starting torque most often missed — and the pairing's real weakness: silent failure. Includes HONPINE SHD and CSF specifications.
 Harmonic vs. RV Reducers for Lithium Battery Robotic Arms: A Joint-by-Joint Selection GuideIn lithium battery plants, reducer selection for a robotic arm is not about finding one "best" gearbox — it is about dividing work by joint. RV reducers take the shoulder and elbow (J1–J3), where stiffness, shock resistance, and long life matter most; harmonic reducers take the wrist (J4–J6), where near-zero backlash, high torque density, and low weight decide positioning accuracy. Planetary gearboxes cover long-travel Cartesian transfer at lower cost. Lithium battery production then adds three stricter filters: extreme repeatability (±0.02–0.05 mm), 24/7 high-duty cycles, and zero tolerance for metal particle contamination. This guide explains the logic behind joint-by-joint selection, compares the three reducer types, and maps typical configurations for every station.