HONPINE TCHL Harmonic Joint Modules: Robotic Force Control and Real-World Applications
Hello everyone, I’m Theodore Li, Technical Director at HONPINE.
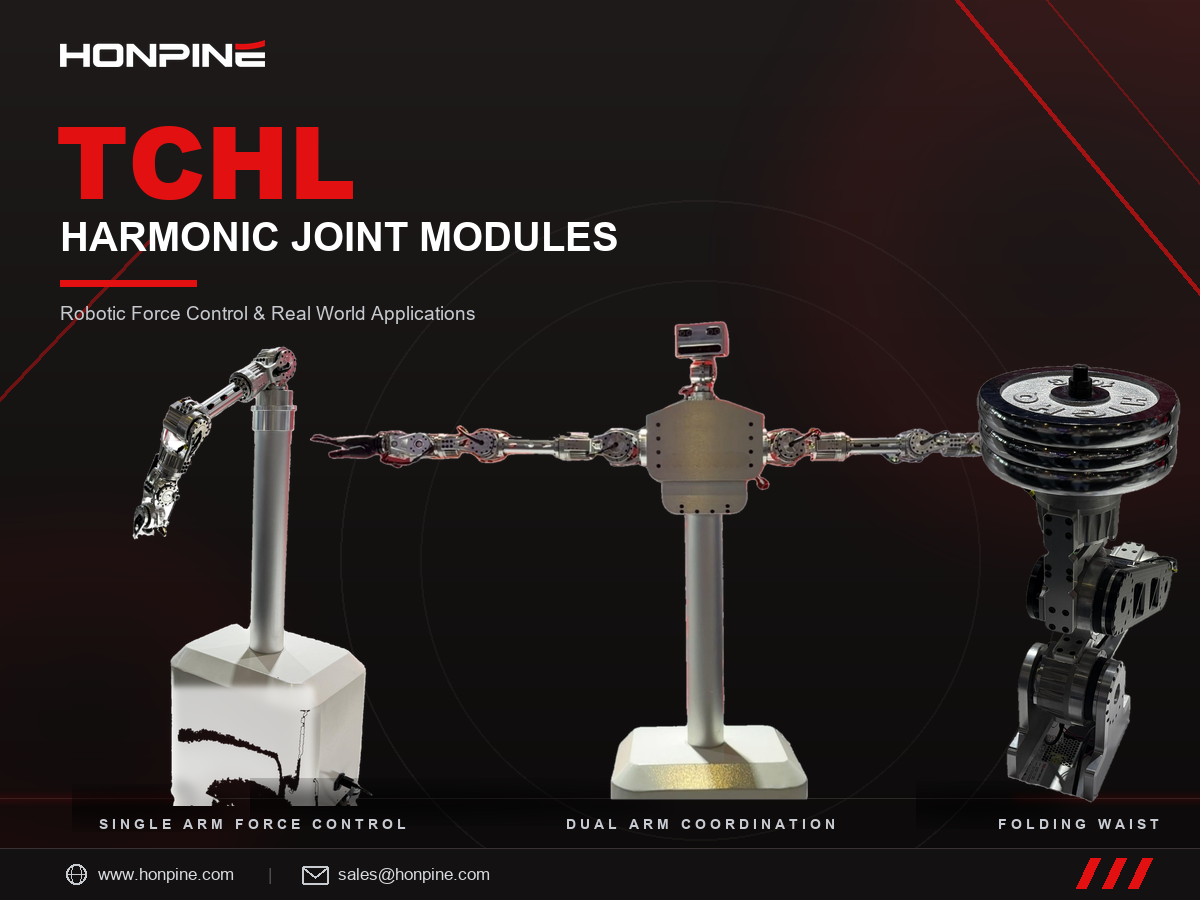
HONPINE TCHL harmonic joint modules have been deployed in a range of robotic motion-control applications, including dual-arm humanoid robots, single-arm compliant force control, and folding waist mechanisms for wheeled humanoid robots. As integrated motion components, they support a wide range of applications in robotics, intelligent manufacturing, and industrial automation.
From core components to integrated motion units, HONPINE showcases the possibilities of precision transmission technology across different robotic applications through a diverse product portfolio and practical motion demonstrations.
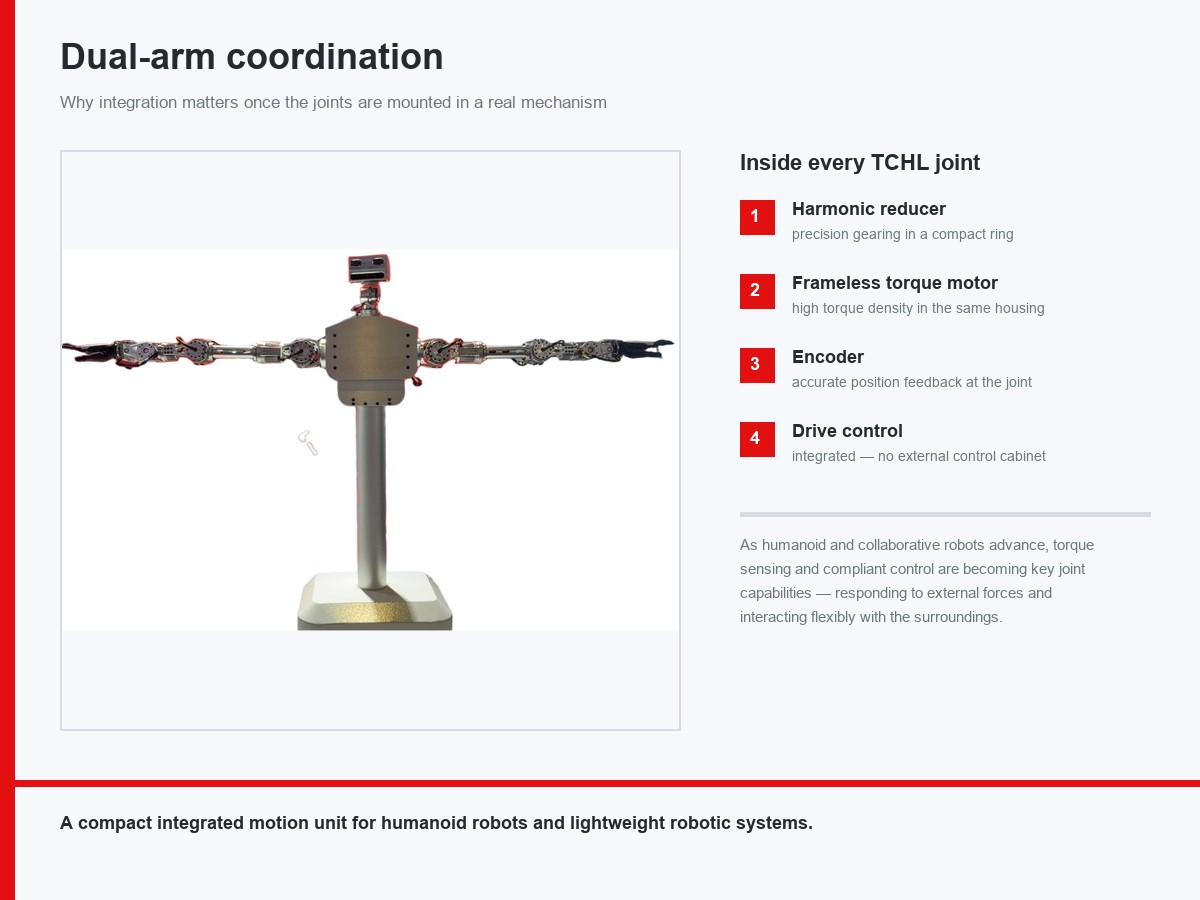
How Do TCHL Harmonic Joint Modules Support Dual-Arm Coordination?
Compared with a static demonstration of an individual joint, a dual-arm demonstration provides a more intuitive view of how integrated joint modules perform within a complete robotic mechanism.
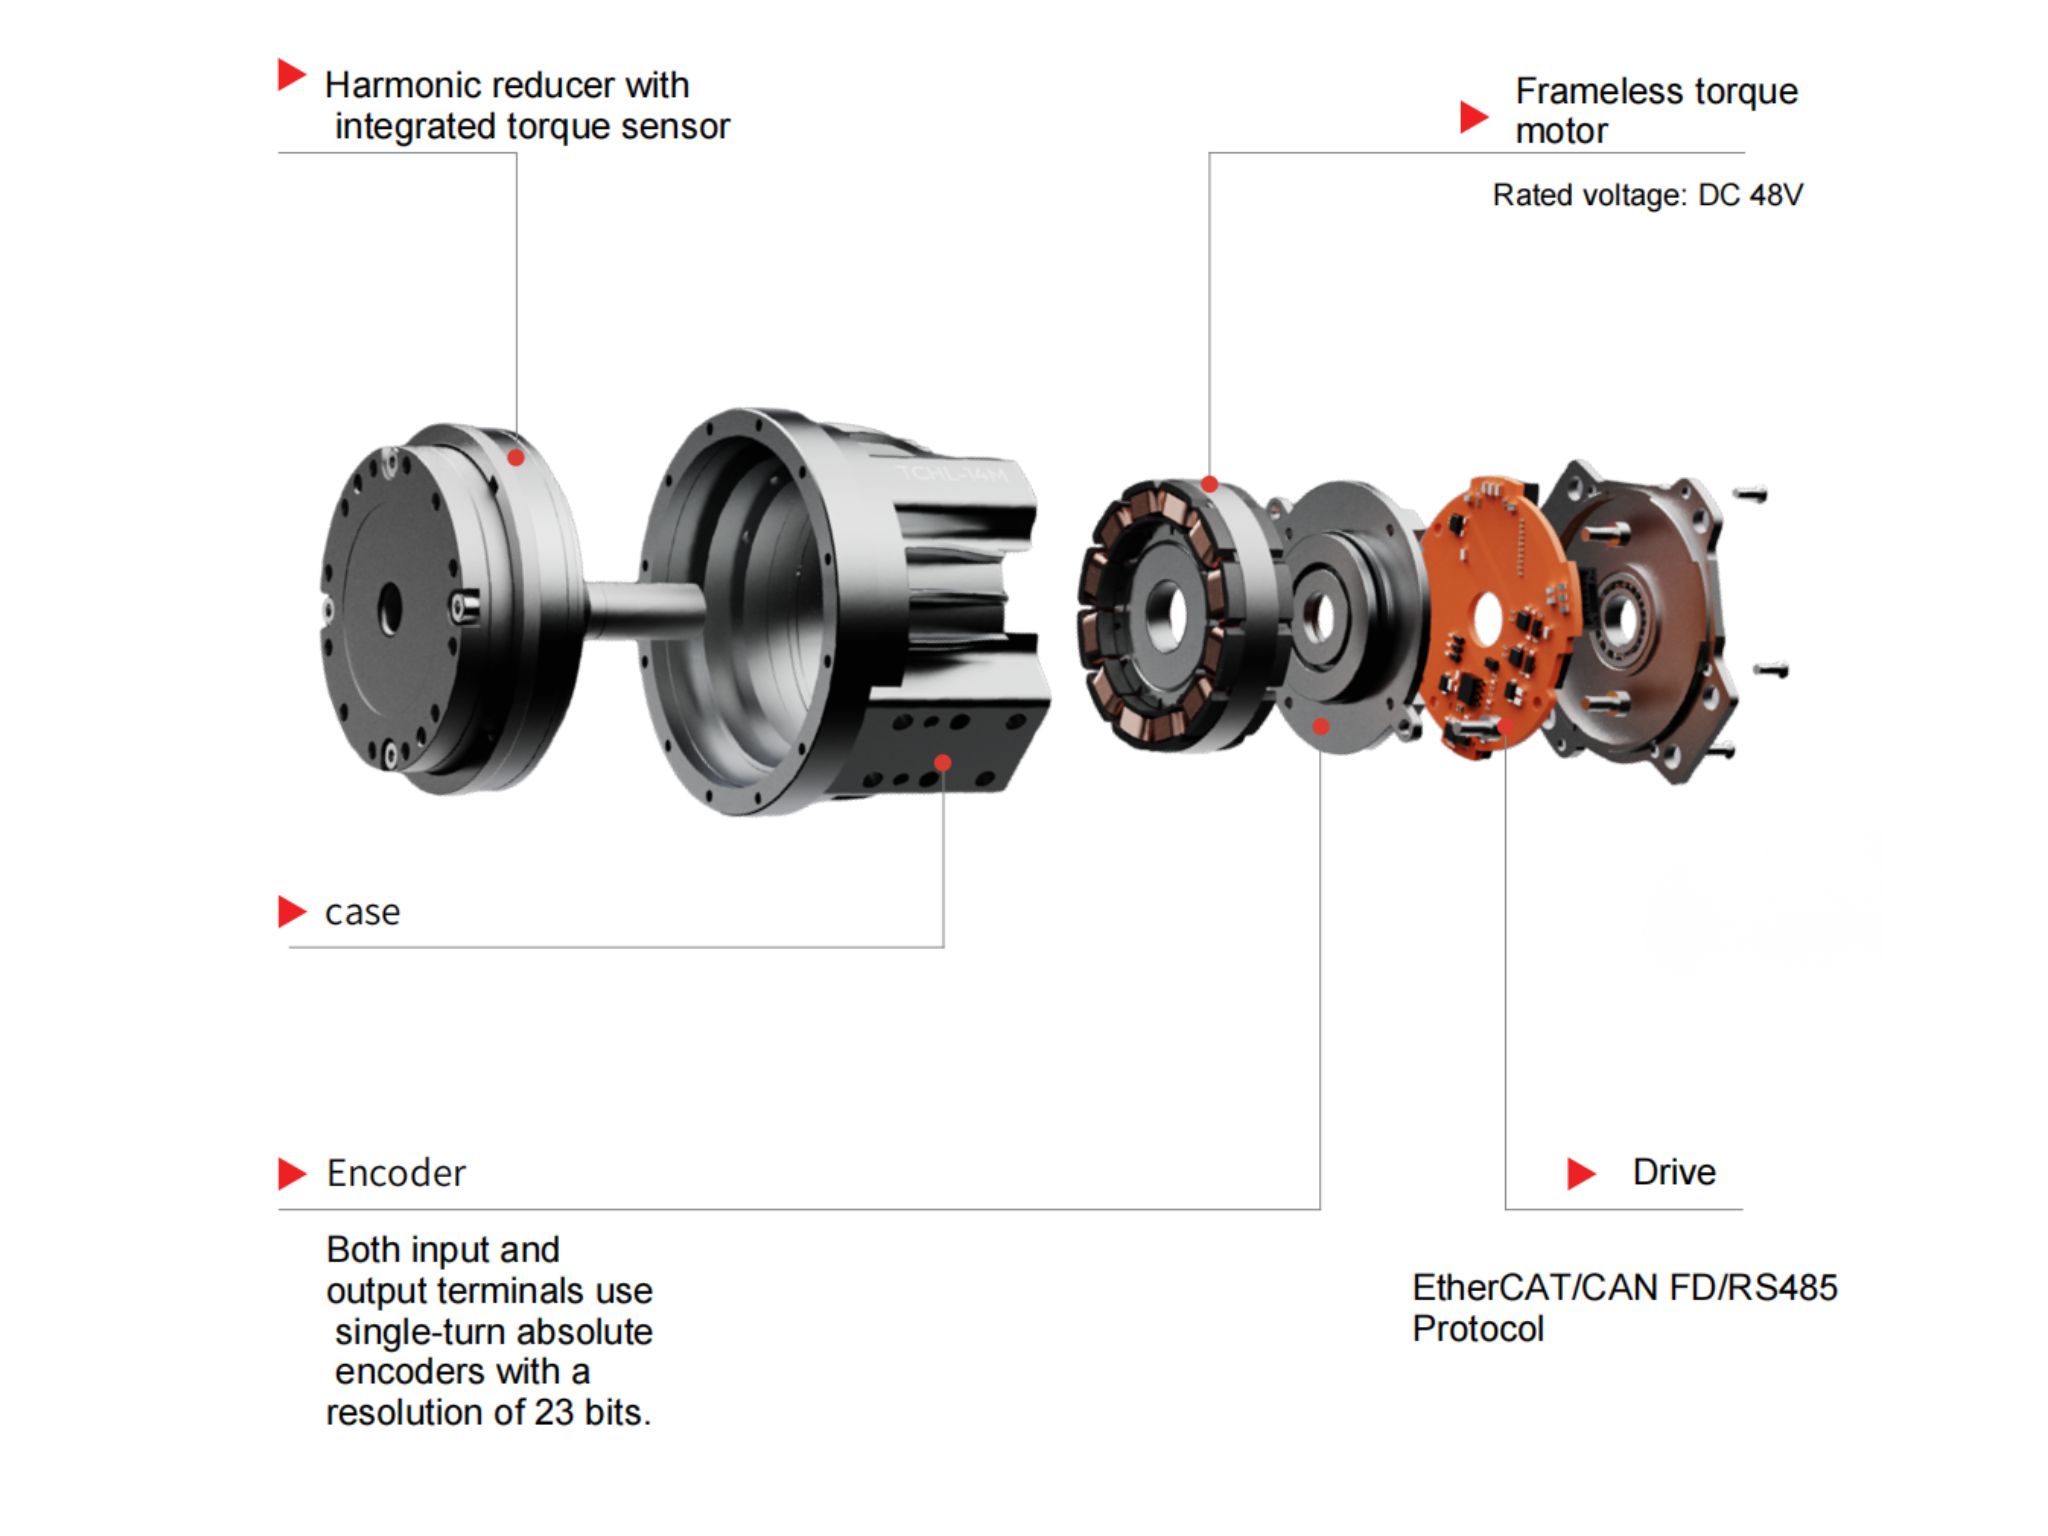
The HONPINE TCHL harmonic joint module series integrates a harmonic reducer, frameless torque motor, encoder, and drive control system into a compact, integrated structure. These modules serve as core motion units for humanoid robots and other lightweight robotic systems.
As humanoid and collaborative robots continue to advance, torque sensing and compliant control are becoming increasingly important for robotic joint performance. These capabilities help robots respond to external forces and support more flexible interactions with their surroundings.
How Does Single-Arm Compliant Force Control Extend Beyond Precise Motion to External Force Sensing?
As humanoid and collaborative robots become more widely adopted, the ability to sense external forces and achieve compliant motion is becoming increasingly important.
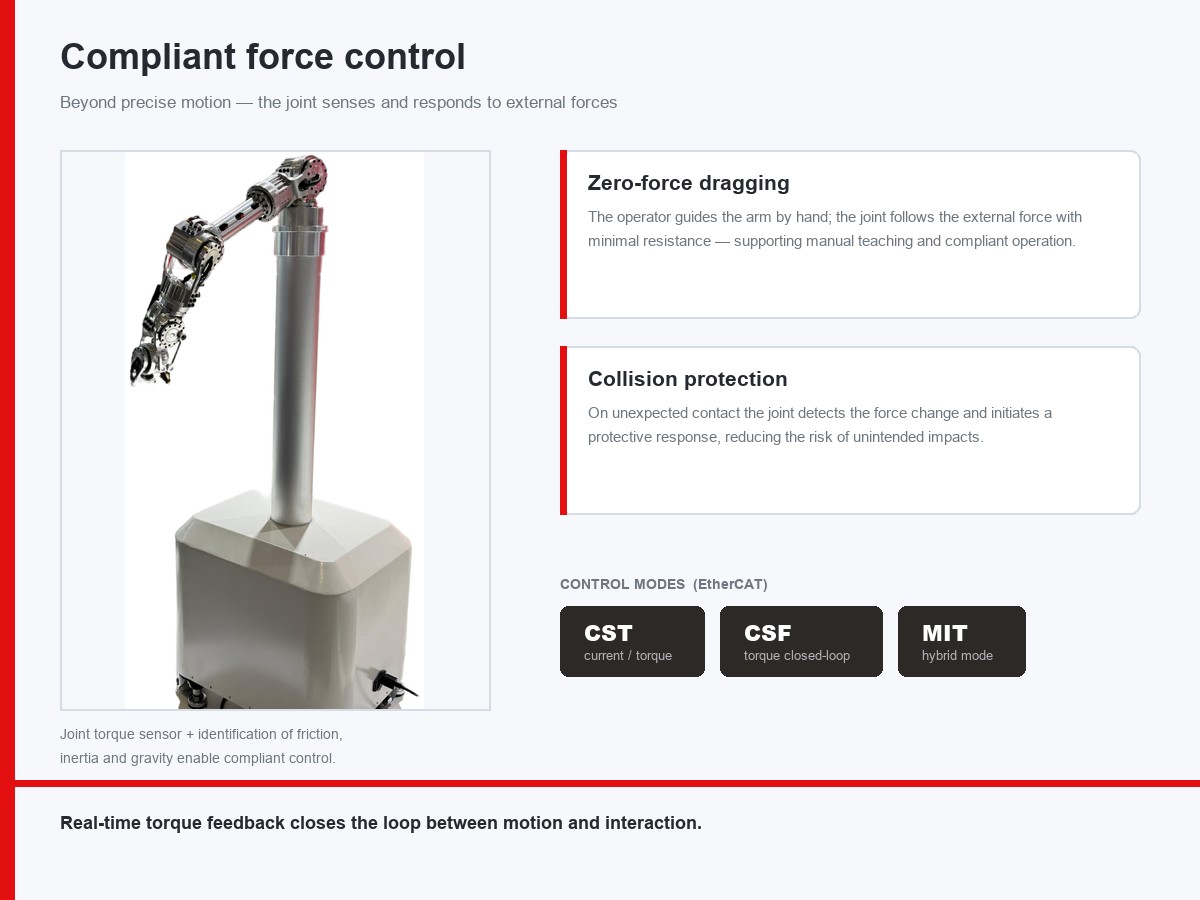
Through a dynamic single-arm force-control demonstration, HONPINE showcases two key functions: zero-force dragging and collision protection.
In zero-force dragging mode, an operator can physically guide the robotic arm by hand, allowing it to follow external forces with minimal resistance. This capability supports manual teaching and compliant robotic operations.
When the arm encounters an external collision or unexpected resistance, the system can detect changes in external force and initiate an appropriate protective response, helping reduce the risk of unintended impacts.
This demonstration uses the torque sensor integrated into the joint module to acquire torque information. Combined with the identification and compensation of parameters such as joint friction, inertia, and gravity, the system enables compliant control in the joint coordinate system.
By combining motion execution with torque sensing and interactive control, HONPINE TCHL harmonic joint modules continue to expand the capabilities of robotic joints.
How Can Torque Variations Be Made Visible in Single-Joint Force-Control Interactions?
With an integrated torque sensor, a joint module can provide real-time feedback on actual output torque and regulate its response through closed-loop control based on a target value.
This demonstration makes torque feedback and control performance easier to observe, helping users understand how a joint module senses external forces and regulates torque during operation.
To accommodate different customer development requirements, HONPINE TCHL harmonic joint module software supports CST current/torque control, CSF torque closed-loop control, and MIT control mode over EtherCAT communication, providing multiple options for robotic compliant control and secondary development.
These control options allow developers to explore different approaches to motion and torque regulation according to their application requirements and control architectures.
TCHL Harmonic Joint Modules in a Wheeled Robot Waist Mechanism
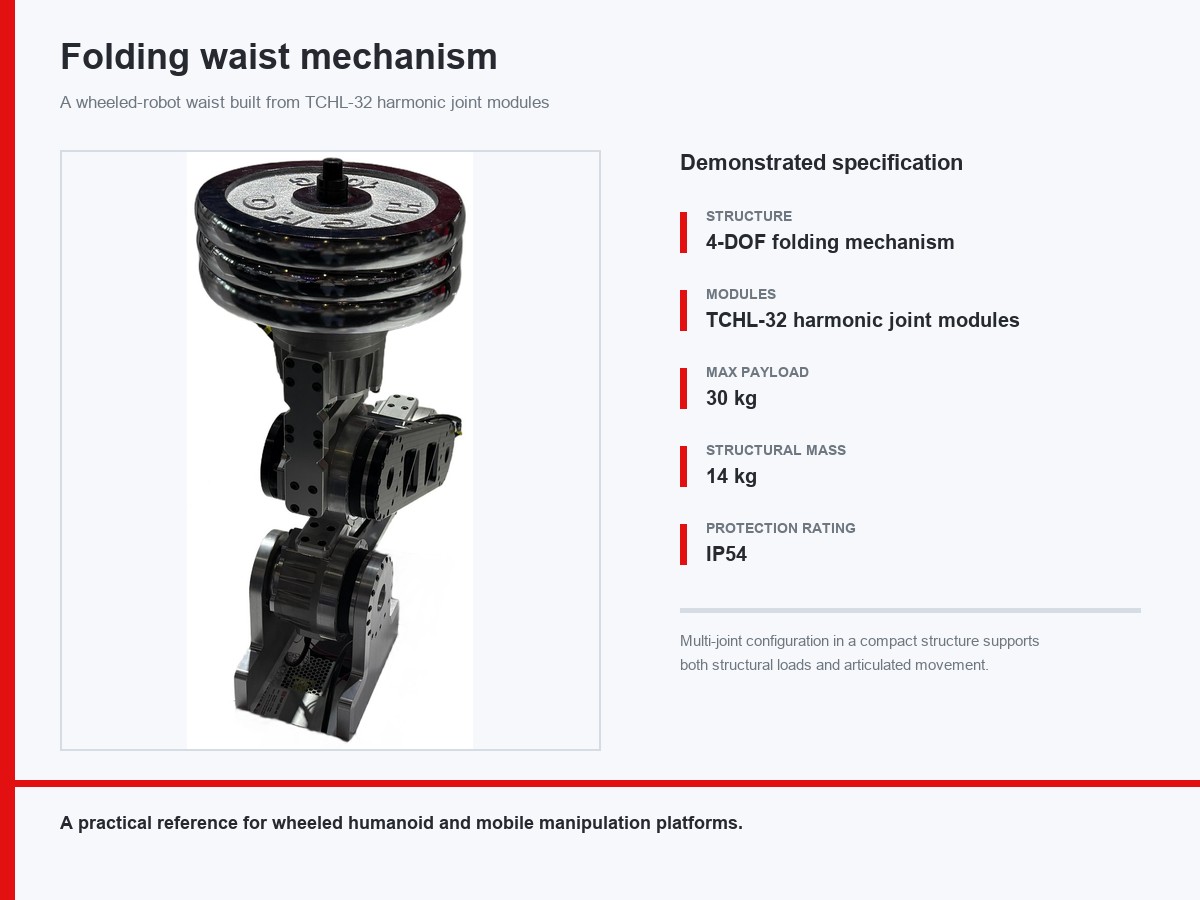
Here, we demonstrate the application of HONPINE TCHL harmonic joint modules in the waist mechanism of a wheeled robot.
The solution adopts a four-degree-of-freedom folding structure equipped with lightweight TCHL-32 series harmonic joint modules. The mechanism has a maximum payload of 30 kg, a structural mass of 14 kg, and an IP54 protection rating.
Through a multi-joint configuration and compact mechanical design, this demonstration illustrates how harmonic joint modules can be integrated into robotic waist mechanisms while supporting structural loads and articulated movement.
The design provides a practical reference for waist mechanism development in wheeled humanoid robots, mobile manipulation robots, and similar platforms. By combining multiple integrated motion units within a compact structure, it opens up additional possibilities for robotic mechanism design.
Supporting the Next Generation of Robotics and Intelligent Equipment
As the robotics industry continues to demand higher precision, lighter structures, greater integration, and improved reliability, HONPINE remains committed to advancing core technologies while leveraging its precision manufacturing and scalable production capabilities.
We support customers throughout the product development process, from initial development and validation to volume deployment, helping them address the engineering challenges associated with practical robotic applications.
Building on its core expertise in harmonic reduction technology, HONPINE will continue to develop its portfolio of precision transmission products, integrated joint modules, and robotic motion components.
Through reliable products, continuous technological innovation, and manufacturing capabilities, HONPINE aims to support the continued development of robotics and intelligent equipment.
About Author
Theodore Li serves as the Technical Director at HONPINE, overseeing the R&D strategy for replication products, guiding team selection, and managing both pre-sales and after-sales operations.

Read More
Learn more about the story of HONPINE and industry trends related to precision transmission.
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 The Role of Harmonic Drive Gears in Achieving 5–10 μm Accuracy in Dental Milling MachinesA dental milling machine is a CNC machining system used to directly process digital dental models into restorations such as crowns, bridges, veneers, inlays, and implant abutments. Dental milling machines require far higher operational accuracy and motion stability than ordinary equipment. This article explains how harmonic drive gear help dental milling machines achieve stable, continuous, and controllable operation.
 Why Are Harmonic Rotary Actuators Perfect for Medical Equipment?Harmonic rotary actuators (typically integrated systems consisting of a harmonic drive reducer, frameless torque motor, encoder, and optional brake) are regarded as key components in medical equipment. The core reason is that they simultaneously meet the most stringent medical requirements for precision, compact size, safety, and controllability. The following explanation is structured from three perspectives: technical characteristics, application scenarios, and medical value.
 High-Precision RV Reducers Perfectly Matched for Walking RobotsThe walking axis of a robot is a core component for power transmission and support. RV reducers provide extremely high rigidity, precision, and torque while maintaining a compact size and exceptional reliability, making them an ideal match for the demanding requirements of walking robot joints in terms of load capacity, impact resistance, and precision.
 Harmonic Drive Backlash in Arcmin: What the Specification Really Tells YouChoosing the right force control harmonic joint actuator involves more than comparing torque and dimensions. Torque sensor specifications, encoder feedback, communication protocols, functional safety, and hollow-shaft size can all affect system integration and control performance. In this guide, HONPINE Technical Director compares the TCHL and HAG harmonic joint actuator series, explaining their key differences and providing a practical selection framework for humanoid robots, collaborative manipulators, precision assembly, polishing, and other force-controlled applications.
 HONPINE TCHL Harmonic Joint Modules: Robotic Force Control and Real-World ApplicationsHello everyone, I’m Theodore Li, Technical Director at HONPINE.
HONPINE TCHL harmonic joint modules have been deployed in a range of robotic motion-control applications, including dual-arm humanoid robots, single-arm compliant force control, and folding waist mechanisms for wheeled humanoid robots. As integrated motion components, they support a wide range of applications in robotics, intelligent manufacturing, and industrial automation.
From core components to integrated motion units, HONPINE showcases the possibilities of precision transmission technology across different robotic applications through a diverse product portfolio and practical motion demonstrations. Why Bedside Physical Therapy Robots Need Force-Controlled Joint Modules?A therapy robot does not sell a robot arm; it sells a force applied to a human body. Pressure, rhythm and depth are the prescription, and position control cannot deliver them: soft tissue is compliant and time-varying, so one position command yields contact forces that differ several-fold between muscle and bone. Force-controlled harmonic joint modules turn contact force into a closed-loop variable - the only way to make dose repeatable, human contact safe and a therapist's technique teachable. Starting from one site photo of a bedside therapy robot, this article reads the configuration, sets out five reasons force control is unavoidable, settles HONPINE's TCHL-versus-HAG choice criterion by criterion, and gives the torque sensor resolution budget that picks the frame sizes.
 NEMA 17 & NEMA 23 Harmonic Drive Matching Guide: Pairing Stepper Motors with Harmonic ReducersPairing a stepper motor with a harmonic drive is not a budget compromise. A stepper's weak points — the coarse step angle, torque collapse above roughly 400 rpm, and the lack of a precision transmission — are exactly what a harmonic drive fixes: it pulls the operating point into the low-speed, high-torque sweet spot, refines a 1.8° step angle into arc-second resolution, and delivers near-zero backlash. This guide explains what NEMA frame sizes mean at the mounting interface, which harmonic frames match NEMA 17 and NEMA 23, the eight checks to run in order — including the input-side no-load starting torque most often missed — and the pairing's real weakness: silent failure. Includes HONPINE SHD and CSF specifications.
 Harmonic vs. RV Reducers for Lithium Battery Robotic Arms: A Joint-by-Joint Selection GuideIn lithium battery plants, reducer selection for a robotic arm is not about finding one "best" gearbox — it is about dividing work by joint. RV reducers take the shoulder and elbow (J1–J3), where stiffness, shock resistance, and long life matter most; harmonic reducers take the wrist (J4–J6), where near-zero backlash, high torque density, and low weight decide positioning accuracy. Planetary gearboxes cover long-travel Cartesian transfer at lower cost. Lithium battery production then adds three stricter filters: extreme repeatability (±0.02–0.05 mm), 24/7 high-duty cycles, and zero tolerance for metal particle contamination. This guide explains the logic behind joint-by-joint selection, compares the three reducer types, and maps typical configurations for every station.
 How to Choose High-Precision Rotary Actuators for Industrial Automation?High-precision rotary actuators play an important role in industrial automation, where positioning accuracy, repeatability, durability and installation flexibility directly affect equipment performance. HONPINE offers four main series of precision rotary actuators, including HAT, HAM and HAS harmonic rotary actuators and HPG low-backlash planetary actuators. With torque ratings ranging from 4 to 1,494 Nm across the product range, these solutions are designed for applications in semiconductor manufacturing, 3C automation, laser processing and CNC machine tools. Learn how to identify the right rotary actuator based on operating conditions, precision requirements and mechanical integration needs.

Double Click
We provide harmonic drive reducer,planetary reducer,robot joint motor,robot rotary actuators,RV gear reducer,robot end effector,dexterous robot hand
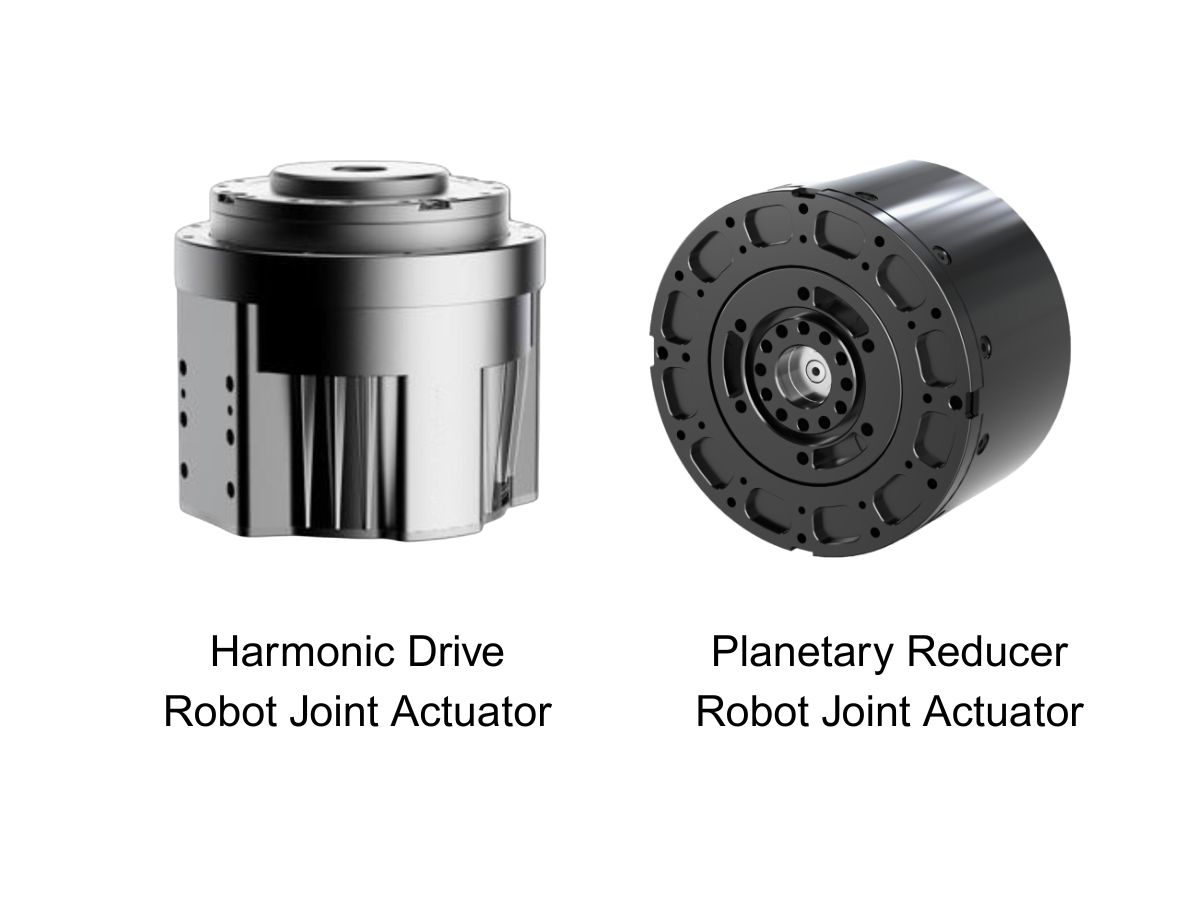
 What is robot joint actuator?How to Choose the Best Robot Rotary Joint Actuator?In core robot joint transmission solutions, planetary and harmonic rotary actuators each have their own strengths. Choosing the right type based on application requirements is essential to achieve the optimal balance between performance and cost.
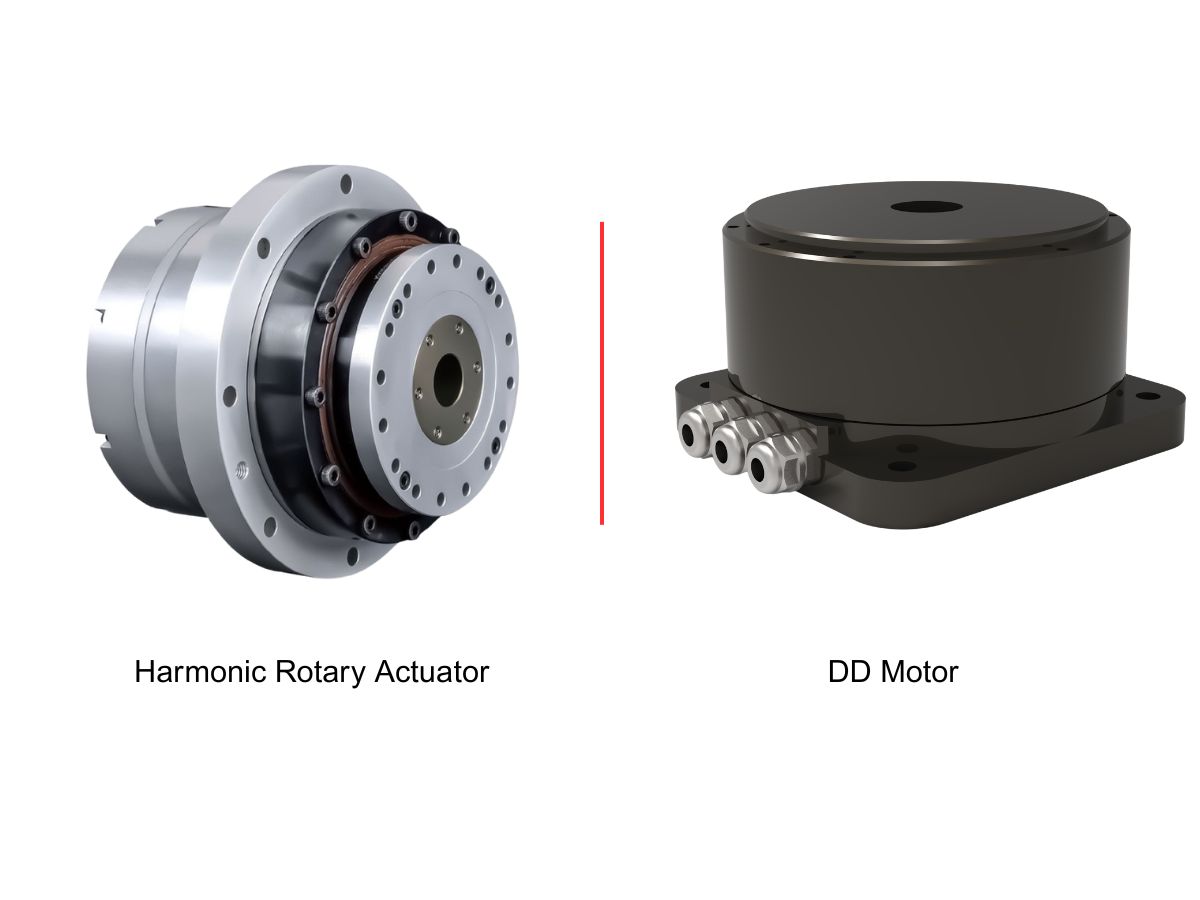
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 OMG Ultra Compact Harmonic Drive Joint Module with Built-in Torque SensorHONPINE TCHL series harmonic drive joint module is a game-changing product that achieves disruptive improvements in multiple aspects such as lightweight design, integration level, and connection convenience. This article will analyze its revolutionary enhancements with you.
 Harmonic Drive Backlash in Arcmin: What the Specification Really Tells YouChoosing the right force control harmonic joint actuator involves more than comparing torque and dimensions. Torque sensor specifications, encoder feedback, communication protocols, functional safety, and hollow-shaft size can all affect system integration and control performance. In this guide, HONPINE Technical Director compares the TCHL and HAG harmonic joint actuator series, explaining their key differences and providing a practical selection framework for humanoid robots, collaborative manipulators, precision assembly, polishing, and other force-controlled applications.
 HONPINE TCHL Harmonic Joint Modules: Robotic Force Control and Real-World ApplicationsHello everyone, I’m Theodore Li, Technical Director at HONPINE.
HONPINE TCHL harmonic joint modules have been deployed in a range of robotic motion-control applications, including dual-arm humanoid robots, single-arm compliant force control, and folding waist mechanisms for wheeled humanoid robots. As integrated motion components, they support a wide range of applications in robotics, intelligent manufacturing, and industrial automation.
From core components to integrated motion units, HONPINE showcases the possibilities of precision transmission technology across different robotic applications through a diverse product portfolio and practical motion demonstrations. NEMA 17 & NEMA 23 Harmonic Drive Matching Guide: Pairing Stepper Motors with Harmonic ReducersPairing a stepper motor with a harmonic drive is not a budget compromise. A stepper's weak points — the coarse step angle, torque collapse above roughly 400 rpm, and the lack of a precision transmission — are exactly what a harmonic drive fixes: it pulls the operating point into the low-speed, high-torque sweet spot, refines a 1.8° step angle into arc-second resolution, and delivers near-zero backlash. This guide explains what NEMA frame sizes mean at the mounting interface, which harmonic frames match NEMA 17 and NEMA 23, the eight checks to run in order — including the input-side no-load starting torque most often missed — and the pairing's real weakness: silent failure. Includes HONPINE SHD and CSF specifications.
 Harmonic vs. RV Reducers for Lithium Battery Robotic Arms: A Joint-by-Joint Selection GuideIn lithium battery plants, reducer selection for a robotic arm is not about finding one "best" gearbox — it is about dividing work by joint. RV reducers take the shoulder and elbow (J1–J3), where stiffness, shock resistance, and long life matter most; harmonic reducers take the wrist (J4–J6), where near-zero backlash, high torque density, and low weight decide positioning accuracy. Planetary gearboxes cover long-travel Cartesian transfer at lower cost. Lithium battery production then adds three stricter filters: extreme repeatability (±0.02–0.05 mm), 24/7 high-duty cycles, and zero tolerance for metal particle contamination. This guide explains the logic behind joint-by-joint selection, compares the three reducer types, and maps typical configurations for every station.
 How to Choose High-Precision Rotary Actuators for Industrial Automation?High-precision rotary actuators play an important role in industrial automation, where positioning accuracy, repeatability, durability and installation flexibility directly affect equipment performance. HONPINE offers four main series of precision rotary actuators, including HAT, HAM and HAS harmonic rotary actuators and HPG low-backlash planetary actuators. With torque ratings ranging from 4 to 1,494 Nm across the product range, these solutions are designed for applications in semiconductor manufacturing, 3C automation, laser processing and CNC machine tools. Learn how to identify the right rotary actuator based on operating conditions, precision requirements and mechanical integration needs.
 Why Are Harmonic Reducers Suitable for High-Precision Automation Equipment?Precision automation equipment depends on consistent rotary motion, reliable positioning and compact transmission design. From dispensing head orientation and component angular alignment to automated inspection indexing, harmonic reducers offer a practical solution for applications requiring low backlash and high reduction ratios in limited installation space. This article explains how harmonic reducers support repeatable motion, compares key design configurations, and outlines how to select a suitable reduction ratio and reducer structure based on load, speed, accuracy and machine cycle-time requirements.
 Why Are Servo Motors and Gear Reducers an Ideal Match?Servo motors provide fast, precise motion control, while gear reducers adapt their speed and torque to the load. This guide explains how servo motors and gear reducers work together through torque multiplication, reflected inertia reduction and finer theoretical position resolution. Learn how inertia matching, backlash, torsional stiffness and reduction ratio influence performance in robotics and industrial automation.
 How to Select and Use Robotic Joint Modules?How do you take robotic joint modules from selection to controlled motion? Using the HONPINE HPJM harmonic joint module as an example, Technical Director Theodore Li explains the key steps in mechanical installation, electrical wiring, CAN and EtherCAT configuration, and control commissioning. Learn what to confirm before integration and how to approach setup so each joint can respond correctly to your controller.
 How to Select Harmonic and RV Reducers for Each Axis of a Six-Axis Robot?What determines whether a six-axis robot joint needs a harmonic reducer or an RV reducer? The answer depends on torque, inertia, impact loads, bearing loads and installation space. This guide explains how to evaluate harmonic and RV reducers for the base, shoulder, elbow and wrist, with practical checks for stiffness, backlash and service life. Use the requirements of each axis to select a suitable reducer configuration.